


DroneVision
Drone Vision (DroneVis) is a full compatible drone library to automate computer vision algorithms on parrot drones. You can read a detailed documentation of Drone Vision docs.
DroneVis is a cutting-edge drone software library that has been specifically designed for use with the AR. Drone. It has been extensively tested both indoors and outdoors, and offers a wide range of features including adaptability in connecting to the drone, advanced computer vision algorithms, and 3 user-friendly interfaces. This makes it easy for users to take full advantage of the drone's capabilities and control it with simple commands. All of the implemented real-time data, inference, and detection achieve a minimum fps >= 4.5 on an Intel core 8 CPU.
Features
- Unified state-of-the art computer vision algoritms
- Full control over the drone
- PEP8 compliant (unified code style)
- Documented functions and classes
- Tests, high code coverage and type hints
- Clean code
- Multiple implementations for the same models
- Logger with timestamps
- Three UI for easier usage (GUI, CLI, Gesture Recognition)
Computer Vision Models
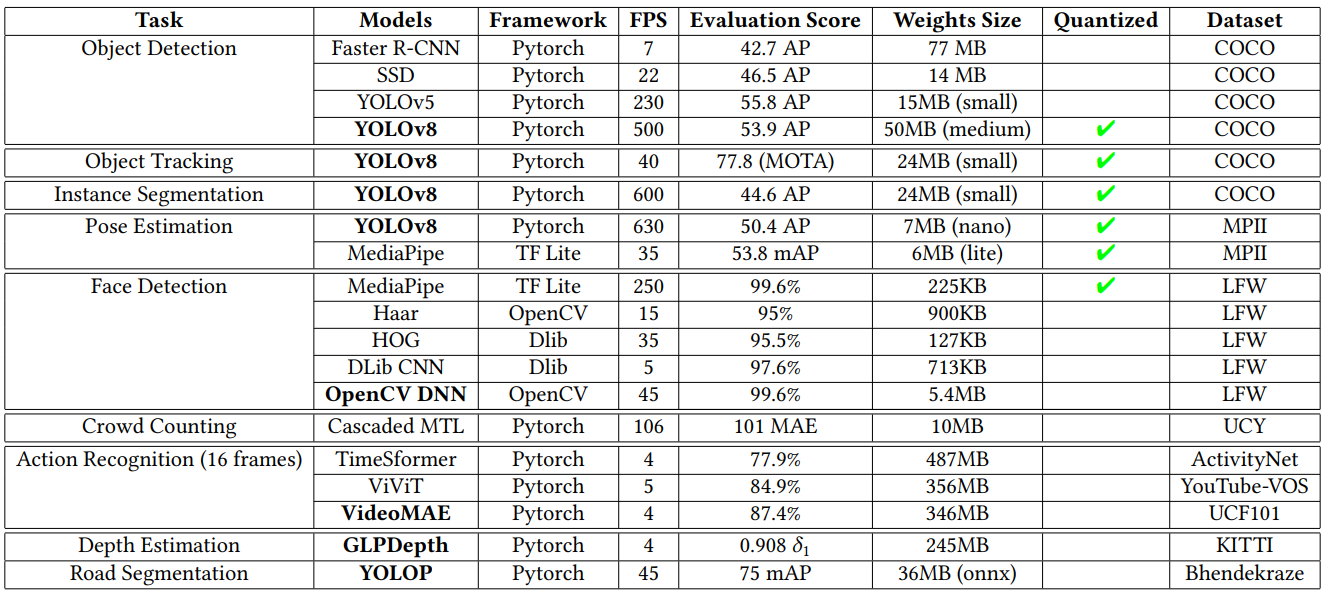
You provide a wide variety of 20+ computer vision and recommends users to the best models in terms of accuracy and speed, whilst giving users the chance to use any model of their choice.
Drone Control
- Right ➡️, Left ⬅️
- Up ⬆️, Down ⬇️
- Forward ▶️, Backward ◀️
- Takeoff 🚀, Land 🛬
- Reset 🔄, Emergency 🚨
- Rotate Left ↩️ /Right ↪️
- Hover 🔍, Calibrate 🔧
- Camera Stream 📹/Record ⏺️
- Hand Gesture Control 🖌️
How to Install
Install PyTorch
You should consider installing the version of Pytorch that corresponds to your cuda version.You start controling your drone now with just two commands:
pip install dronevis # install the library
dronevis-gui # run library GUI
Press the start button to start a demo drone simulation, and run your favourite algorithms with the stream button.

You can control your drone with our CLI:
dronevis

Getting Started
Dronevis is built with multiple modes for customizibility. You can view all the options for either runnning our GUI or CLI as follows:
dronevis --help

The default mode for running either the CLI or the GUI is the demo mode. You can alter the mode by providing "real" to --drone argument.
dronevis --drone=real # cli real drone mode
or for GUI,
dronevis-gui --drone=real # gui real drone mode
Documentation
Dronevis is developed with an extensive documentation for easier user contributions. You can check our full documentation in here to go more in-depth of how the library is structure and how to contribute your favourite model.
Citing the Project
To cite this repository:
@software{drone-vis,
  author  = {Ahmed Heakl, Fatma Youssef, Abdallah-Elbarkokry},
  title   = {Dronevis: Full compatible drone library to automate computer vision algorithms on parrot drones},
  year    = {2023},
  url     = {github.com/ahmedheakl/drone-vis},
  version = {1.3.0}
}
1 maintainer

Metadata
1 maintainer
Release files for dronevis 1.3.0
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | Provenance | Actions |
|---|---|---|---|---|
| dronevis-1.3.0.tar.gz | 74.4 kB | Without provenance | Details for dronevis-1.3.0.tar.gz |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Actions Reset |
|---|---|---|---|---|
| dronevis-1.3.0-py3-none-any.whl | Python 3 | none | any | Details for dronevis-1.3.0-py3-none-any.whl |
Total release size: 170.6 kB
Release files / dronevis-1.3.0.tar.gz
| Download URL | dronevis-1.3.0.tar.gz |
|---|---|
| Size | 74.4 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
13e8d05b2cc2b72c30a2c02ccf00992e27ef011db714ef3804b548fe50ff3086
|
|
BLAKE2b-256 checksum How to use checksums |
2967c9eddda0147b592657805c9382a3f8d7253dbcf0288fbba33cb675bd2ab7
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/4.0.2 CPython/3.8.18
|
Release files / dronevis-1.3.0-py3-none-any.whl
| Download URL | dronevis-1.3.0-py3-none-any.whl |
|---|---|
| Size | 96.2 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
3e3b726550120240209bbdcbbfdea80f370b4d03d664e1c1c76d01bea1a9829b
|
|
BLAKE2b-256 checksum How to use checksums |
2ecf4603381ee13dae5ed6d890894474cc43d4ff8147b9d1511370b9f02aafe5
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/4.0.2 CPython/3.8.18
|
Security for dronevis 1.3.0
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
No provenance found
None of the files in this release were uploaded with provenance metadata.
A note on package security
PyPI is a repository for distributing packages, not a service for auditing them. While third-party security researchers and our staff do their best to detect and remove malicious packages, PyPI cannot guarantee the quality, security or suitability of any given package.
To learn more about protecting yourself from malicious actors, visit our package security documentation.














