
IKPy


Demo
Live demos of what IKPy can do (click on the image below to see the video):
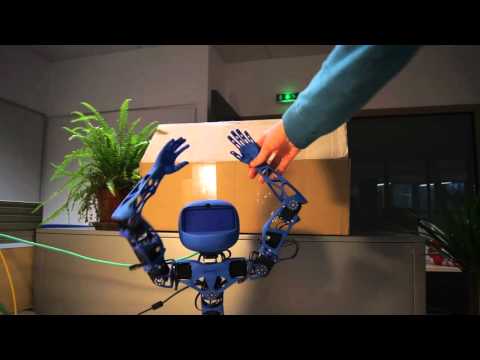
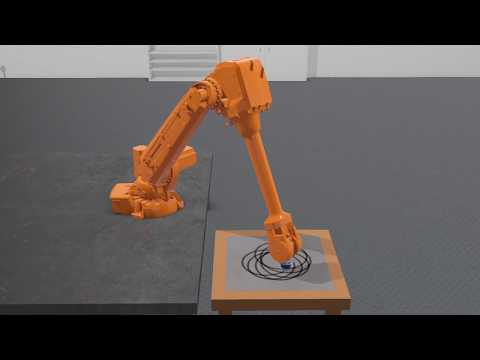
Also, a presentation of IKPy: Presentation.
Features
With IKPy, you can:
- Compute the Inverse Kinematics of every existing robot.
- Compute the Inverse Kinematics in position, orientation, or both
- Define your kinematic chain using arbitrary representations: DH (Denavit–Hartenberg), URDF, custom...
- Automatically import a kinematic chain from a URDF file.
- Support for arbitrary joint types:
revolute,prismaticand more to come in the future - Use pre-configured robots, such as baxter or the poppy-torso
- IKPy is precise (up to 7 digits): the only limitation being your underlying model's precision, and fast: from 7 ms to 50 ms (depending on your precision) for a complete IK computation.
- Plot your kinematic chain: no need to use a real robot (or a simulator) to test your algorithms!
- Define your own Inverse Kinematics methods.
- Utils to parse and analyze URDF files:

Moreover, IKPy is a pure-Python library: the install is a matter of seconds, and no compiling is required.
Installation
You have three options:
-
From PyPI (recommended) - simply run:
pip install ikpy
If you intend to plot your robot, you can install the plotting dependencies (mainly
matplotlib):pip install 'ikpy[plot]'
-
From source - first download and extract the archive, then run:
pip install ./
NB: You must have the proper rights to execute this command
Quickstart
Follow this IPython notebook.
Guides and Tutorials
Go to the wiki. It should introduce you to the basic concepts of IKPy.
API Documentation
An extensive documentation of the API can be found here.
Dependencies and compatibility
Starting with IKPy v3.1, only Python 3 is supported. For versions before v3.1, the library can work with both versions of Python (2.7 and 3.x).
In terms of dependencies, it requires numpy and scipy.
sympy is highly recommended, for fast hybrid computations, that's why it is installed by default.
matplotlib is optional: it is used to plot your models (in 3D).
Contributing
IKPy is designed to be easily customisable: you can add your own IK methods or robot representations (such as DH-Parameters) using a dedicated developer API.
Contributions are welcome: if you have an awesome patented (but also open-source!) IK method, don't hesitate to propose adding it to the library!
Links
- If performance is your main concern,
aversive++has an inverse kinematics module written in C++, which works the same way IKPy does.
2 maintainers


Metadata
2 maintainers
Release files for ikpy 3.3.1
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | Provenance | Actions |
|---|---|---|---|---|
| ikpy-3.3.1.tar.gz | 24.5 kB | Without provenance | Details for ikpy-3.3.1.tar.gz |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Actions Reset |
|---|---|---|---|---|
| ikpy-3.3.1-py3-none-any.whl | Python 3 | none | any | Details for ikpy-3.3.1-py3-none-any.whl |
Total release size: 51.2 kB
Release files / ikpy-3.3.1.tar.gz
| Download URL | ikpy-3.3.1.tar.gz |
|---|---|
| Size | 24.5 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
4aca1ab21ec2b3efadb1595b630ea5ee3087f2915d4bea535c5421cf24c5f18e
|
|
BLAKE2b-256 checksum How to use checksums |
28e6baee4966b0174e4a0b11c20f3f7c78cf34d170b8823e91ad11bd3ef268cc
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/4.0.0 CPython/3.9.12
|
Release files / ikpy-3.3.1-py3-none-any.whl
| Download URL | ikpy-3.3.1-py3-none-any.whl |
|---|---|
| Size | 26.7 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
42096934b0cde14851df940f5cd9c8f28b902c293ec13a7abd3b7e673a20de07
|
|
BLAKE2b-256 checksum How to use checksums |
e45836dd7c30ca5ce6cc05dbcf4849156c554d0626232f3e255614d3b7723b2a
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/4.0.0 CPython/3.9.12
|
Security for ikpy 3.3.1
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
No provenance found
None of the files in this release were uploaded with provenance metadata.
A note on package security
PyPI is a repository for distributing packages, not a service for auditing them. While third-party security researchers and our staff do their best to detect and remove malicious packages, PyPI cannot guarantee the quality, security or suitability of any given package.
To learn more about protecting yourself from malicious actors, visit our package security documentation.














