
JaxSim
JaxSim is a differentiable physics engine built with JAX, tailored for co-design and robotic learning applications.
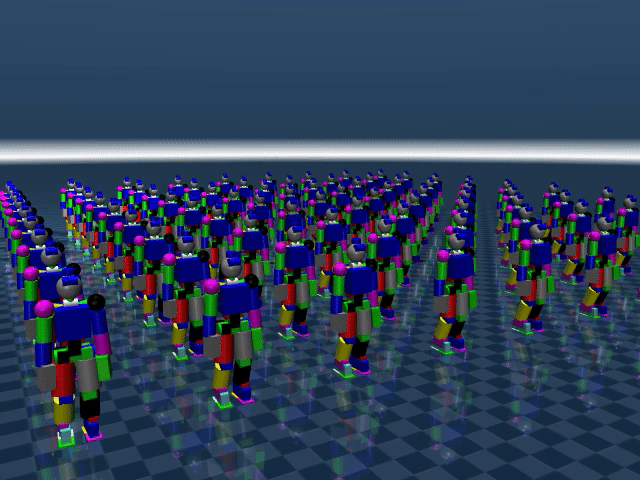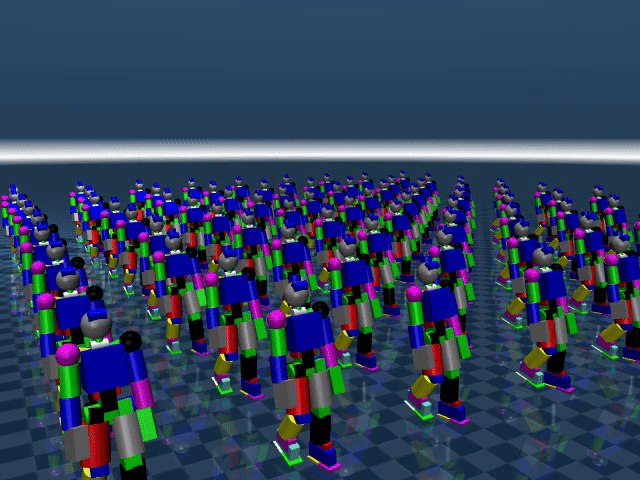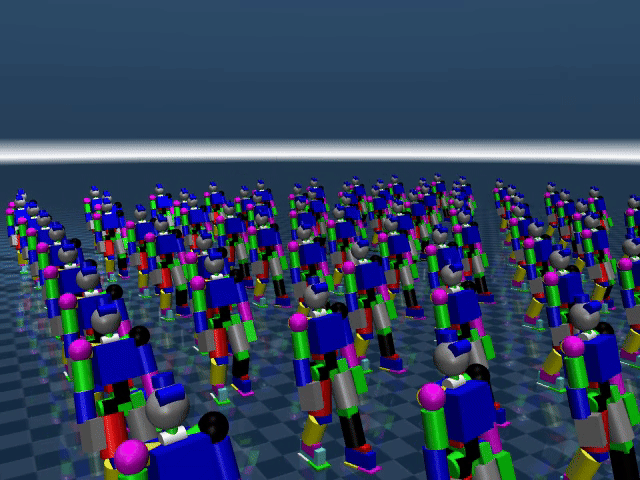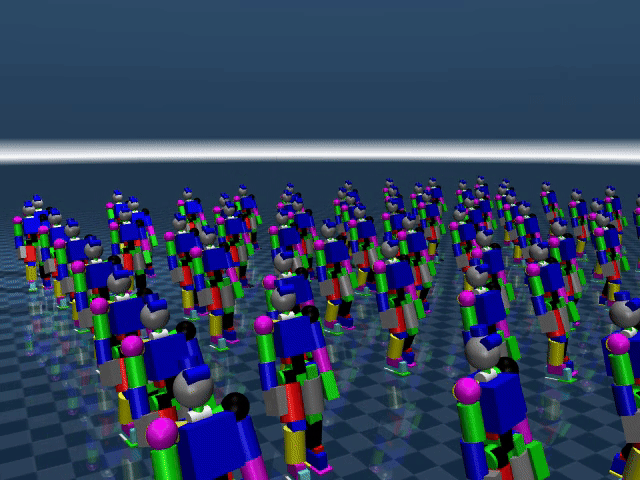 |
 |
|---|---|
 |
 |
Features
- Physically consistent differentiability w.r.t. hardware parameters.
- Closed chain dynamics support.
- Reduced-coordinate physics engine for fixed-base and floating-base robots.
- Fully Python-based, leveraging JAX following a functional programming paradigm.
- Seamless execution on CPUs, GPUs, and TPUs.
- Supports JIT compilation and automatic vectorization for high performance.
- Compatible with SDF models and URDF (via sdformat conversion).
[!WARNING] This project is still experimental. APIs may change between releases without notice.
[!NOTE] JaxSim currently focuses on locomotion applications. Only contacts between bodies and smooth ground surfaces are supported.
How to use it
import pathlib

import icub_models
import jax.numpy as jnp

import jaxsim.api as js

# Load the iCub model
model_path = icub_models.get_model_file("iCubGazeboV2_5")

joints = ('torso_pitch', 'torso_roll', 'torso_yaw', 'l_shoulder_pitch',
          'l_shoulder_roll', 'l_shoulder_yaw', 'l_elbow', 'r_shoulder_pitch',
          'r_shoulder_roll', 'r_shoulder_yaw', 'r_elbow', 'l_hip_pitch',
          'l_hip_roll', 'l_hip_yaw', 'l_knee', 'l_ankle_pitch', 'l_ankle_roll',
          'r_hip_pitch', 'r_hip_roll', 'r_hip_yaw', 'r_knee', 'r_ankle_pitch',
          'r_ankle_roll')

# Build and reduce the model
model_description = pathlib.Path(model_path)

full_model = js.model.JaxSimModel.build_from_model_description(
    model_description=model_description,
)

model = js.model.reduce(model=full_model, considered_joints=joints)

# Get the number of degrees of freedom
ndof = model.dofs()

# Initialize data and simulation
# Note that the default data representation is mixed velocity representation
data = js.data.JaxSimModelData.build(
    model=model, base_position=jnp.array([0.0, 0.0, 1.0])
)

T = jnp.arange(start=0, stop=1.0, step=model.time_step)

tau = jnp.zeros(ndof)

# Simulate
for _ in T:
    data = js.model.step(
        model=model, data=data, link_forces=None, joint_force_references=tau
    )
Check the example folder for additional use cases!
Installation
With conda
You can install the project using conda as follows:
conda install jaxsim -c conda-forge
GPU support for JAX will be automatically installed if a compatible GPU is detected.
With pixi
Note
The minimum version of
pixirequired is0.39.0.
Since the pixi.lock file is stored using Git LFS, make sure you have Git LFS installed and properly configured on your system before installation. After cloning the repository, run:
git lfs install && git lfs pull
This ensures all LFS-tracked files are properly downloaded before you proceed with the installation.
You can add the jaxsim dependency in your pixi project as follows:
pixi add jaxsim
If you are on Linux and you want to use a cuda-powered version of jax, remember to add the appropriate line in the system-requirements table, i.e. adding
[system-requirements]
cuda = "13"
if you are using a pixi.toml file or
[tool.pixi.system-requirements]
cuda = "13"
if you are using a pyproject.toml file.
With pip
You can install the project using pypa/pip, preferably in a virtual environment, as follows:
pip install jaxsim
Check pyproject.toml for the complete list of optional dependencies.
You can obtain a full installation using jaxsim[all].
If you need URDF support, follow the official instructions to install Gazebo Sim on your operating system,
making sure to obtain sdformat ≥ 13.0 and gz-tools ≥ 2.0.
You don't need to install the entire Gazebo Sim suite.
For example, on Ubuntu, it is sufficient to install the libsdformat* and gz-tools2 packages.
If you need GPU support, follow the official installation instructions of JAX.
Contributors installation (with conda)
If you want to contribute to the project, we recommend creating the following jaxsim conda environment first:
conda env create -f environment.yml
Then, activate the environment and install the project in editable mode:
conda activate jaxsim
pip install --no-deps -e .
Contributors installation (with pixi)
Note
The minimum version of
pixirequired is0.39.0.
Since the pixi.lock file is stored using Git LFS, make sure you have Git LFS installed and properly configured on your system before installation. After cloning the repository, run:
git lfs install && git lfs pull
This ensures all LFS-tracked files are properly downloaded before you proceed with the installation.
You can install the default dependencies of the project using pixi as follows:
pixi install
See pixi task list for a list of available tasks.
Documentation
The JaxSim API documentation is available at jaxsim.readthedocs.io.
Additional features
Jaxsim can also be used as a multi-body dynamics library! With full support for automatic differentiation of RBDAs (forwards and reverse mode) and automatic differentiation against both kinematic and dynamic parameters.
Using JaxSim as a multibody dynamics library
import pathlib

import icub_models
import jax.numpy as jnp

import jaxsim.api as js

# Load the iCub model
model_path = icub_models.get_model_file("iCubGazeboV2_5")

joints = ('torso_pitch', 'torso_roll', 'torso_yaw', 'l_shoulder_pitch',
          'l_shoulder_roll', 'l_shoulder_yaw', 'l_elbow', 'r_shoulder_pitch',
          'r_shoulder_roll', 'r_shoulder_yaw', 'r_elbow', 'l_hip_pitch',
          'l_hip_roll', 'l_hip_yaw', 'l_knee', 'l_ankle_pitch', 'l_ankle_roll',
          'r_hip_pitch', 'r_hip_roll', 'r_hip_yaw', 'r_knee', 'r_ankle_pitch',
          'r_ankle_roll')

# Build and reduce the model
model_description = pathlib.Path(model_path)

full_model = js.model.JaxSimModel.build_from_model_description(
    model_description=model_description,
)

model = js.model.reduce(model=full_model, considered_joints=joints)

# Initialize model data
data = js.data.JaxSimModelData.build(
    model=model,
    base_position=jnp.array([0.0, 0.0, 1.0]),
)

# Frame and dynamics computations
frame_index = js.frame.name_to_idx(model=model, frame_name="l_foot")

# Frame transformation
W_H_F = js.frame.transform(
    model=model, data=data, frame_index=frame_index
)

# Frame Jacobian
W_J_F = js.frame.jacobian(
    model=model, data=data, frame_index=frame_index
)

# Dynamics properties
M = js.model.free_floating_mass_matrix(model=model, data=data)      # Mass matrix
h = js.model.free_floating_bias_forces(model=model, data=data)      # Bias forces
g = js.model.free_floating_gravity_forces(model=model, data=data)   # Gravity forces
C = js.model.free_floating_coriolis_matrix(model=model, data=data)  # Coriolis matrix

# Print dynamics results
print(f"{M.shape=} \n{h.shape=} \n{g.shape=} \n{C.shape=}")
Credits
The RBDAs are based on the theory of the Rigid Body Dynamics Algorithms book by Roy Featherstone. The algorithms and some simulation features were inspired by its accompanying code.
The development of JaxSim started in late 2021, inspired by early versions of google/brax.
At that time, Brax was implemented in maximal coordinates, and we wanted a physics engine in reduced coordinates.
We are grateful to the Brax team for their work and for showing the potential of JAX in this field.
Brax v2 was later implemented with reduced coordinates, following an approach comparable to JaxSim. The development then shifted to MJX, which provides a JAX-based implementation of the Mujoco APIs.
The main differences between MJX/Brax and JaxSim are as follows:
- JaxSim supports out-of-the-box all SDF models with Pose Frame Semantics.
- JaxSim only supports collisions between points rigidly attached to bodies and a compliant ground surface.
Contributing
We welcome contributions from the community. Please read the contributing guide to get started.
Citing
If you use JaxSim in your work, please cite the following paper:
@article{ferretti_contact_aware_2026,
  author       = {Filippo Luca Ferretti and Diego Ferigo and Alessandro Croci and Carlotta Sartore and Omar G. Younis and Silvio Traversaro and Daniele Pucci},
  title        = {Contact-Aware Morphology Optimization via Physically Consistent Differentiable Simulation},
  journal      = {IEEE Robotics and Automation Letters},
  year         = {2026},
  doi          = {10.1109/LRA.2026.3678125}
}
People
| Authors | Maintainers |
|---|---|
  |
 |
License
2 maintainers


Metadata
2 maintainers
Release files for jaxsim 0.9.0
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | |
|---|---|---|---|
| jaxsim-0.9.0.tar.gz | 207.8 kB | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| jaxsim-0.9.0-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 382.5 kB
Release files / jaxsim-0.9.0.tar.gz
| Download URL | jaxsim-0.9.0.tar.gz |
|---|---|
| Size | 207.8 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
719e58d54c179c1aab9f071c83723b5d480915754d835fe5ba30d3993f84616e
|
|
BLAKE2b-256 checksum How to use checksums |
4d5e681efe811e72d5b57ecaeff8278cbcfdcb4653c00aeb1580ecdda75f997f
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/6.1.0 CPython/3.13.12
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.


PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Apr 29, 2026.
Transparency logRelease files / jaxsim-0.9.0-py3-none-any.whl
| Download URL | jaxsim-0.9.0-py3-none-any.whl |
|---|---|
| Size | 174.8 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
677ad750cb786dc364597d33f7455924831eb5c5668207e71fdddd61aed1b22b
|
|
BLAKE2b-256 checksum How to use checksums |
a06028d983b65aca4d7671a87a9ef938a7ba82e37eda477089450d36690b188c
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/6.1.0 CPython/3.13.12
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Apr 29, 2026.
Transparency log













