
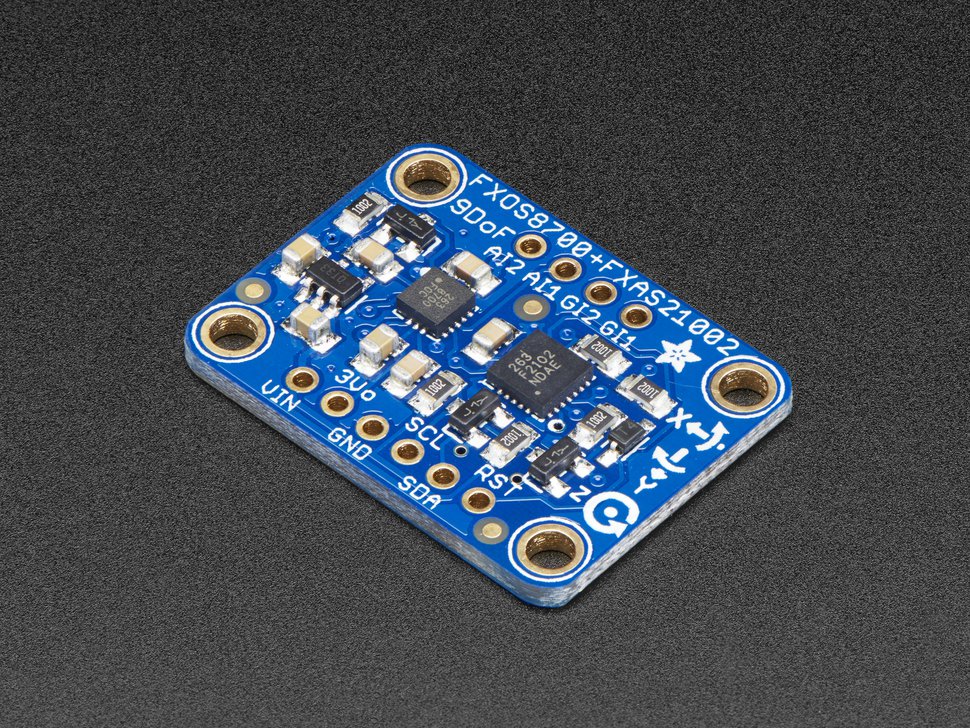
NXP IMU


Python drivers for Adafruit Precision NXP 9-DOF. This is basically a python version of Adafruit's FXOS8700 and their FXAS21002C written in C++ for the Arduino.
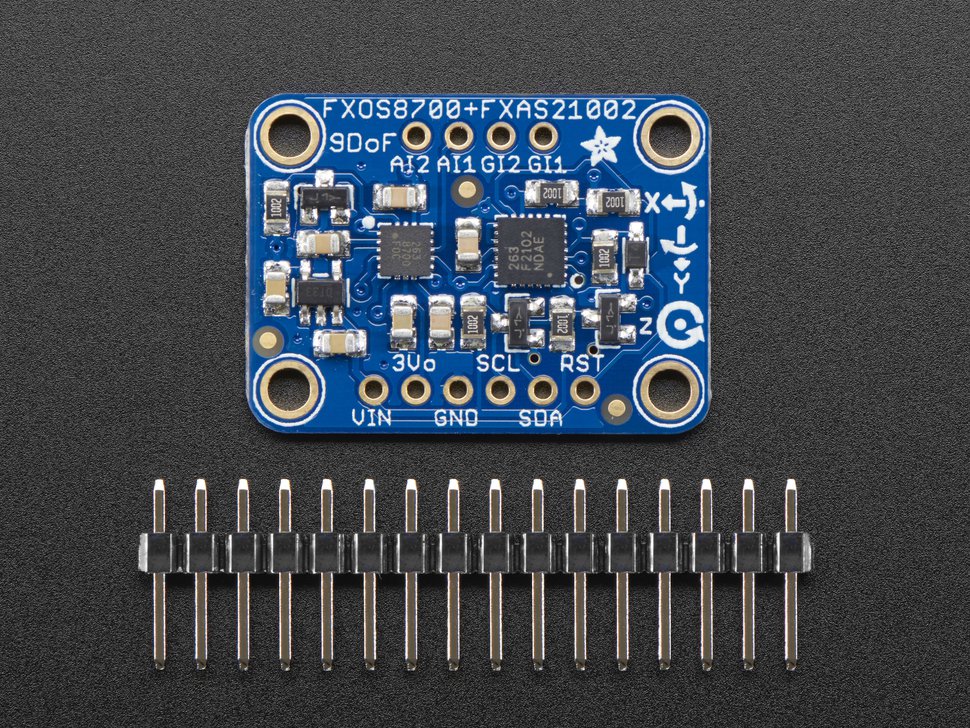
NXP Precision 9DoF
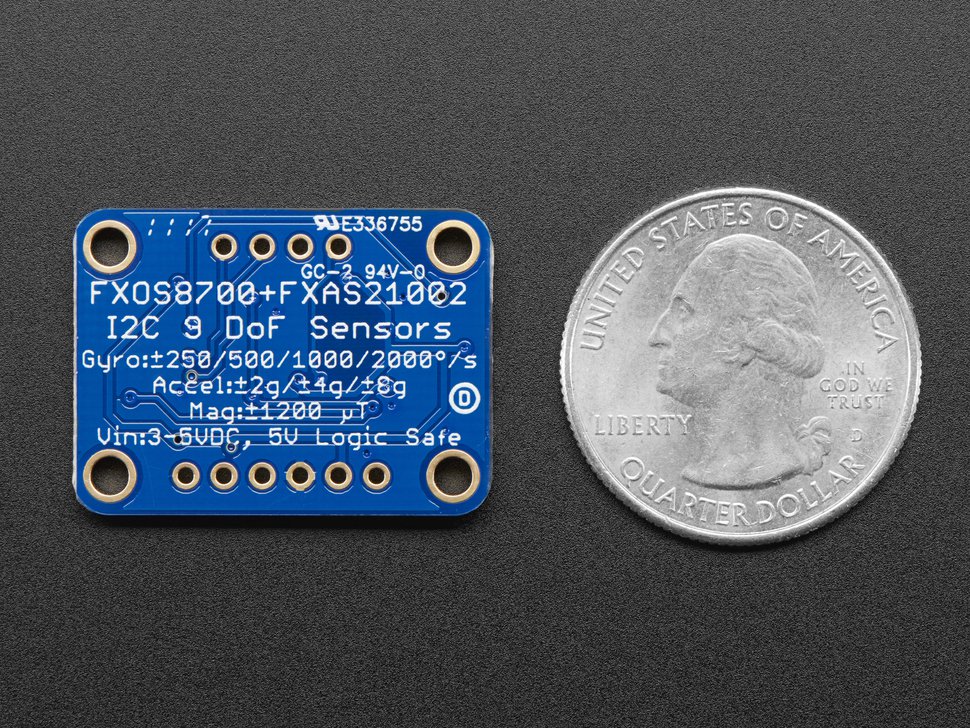
The board consists of two separate ICs, described below:
FXOS8700 3-Axis Accelerometer/Magnetometer
- 2-3.6V Supply
- ±2 g/±4 g/±8 g adjustable acceleration range
- ±1200 µT magnetic sensor range
- Output data rates (ODR) from 1.563 Hz to 800 Hz
- 14-bit ADC resolution for acceleration measurements
- 16-bit ADC resolution for magnetic measurements
FXAS21002 3-Axis Gyroscope
- 2-3.6V Supply
- ±250/500/1000/2000°/s configurable range
- Output Data Rates (ODR) from 12.5 to 800 Hz
- 16-bit digital output resolution
- 192 bytes FIFO buffer (32 X/Y/Z samples)
Setup
Usage
Verifying it is there:
sudo i2cdetect -y 1
     0  1  2  3  4  5  6  7  8  9  a  b  c  d  e  f
00:          -- -- -- -- -- -- -- -- -- -- -- -- --
10: -- -- -- -- -- -- -- -- -- -- -- -- -- -- -- 1f
20: -- 21 -- -- -- -- -- -- -- -- -- -- -- -- -- --
30: -- -- -- -- -- -- -- -- -- -- -- -- -- -- -- --
40: -- -- -- -- -- -- -- -- -- -- -- -- -- -- -- --
50: -- -- -- -- -- -- -- -- -- -- -- -- -- -- -- --
60: -- -- -- -- -- -- -- -- -- -- -- -- -- -- -- --
70: -- -- -- -- -- -- -- --
See the examples folder, but to have the IMU run at 4G and 2000
degrees per second:
#!/usr/bin/env python3

from nxp_imu import IMU, Rate
import time

# verbose will print some start-up info on the IMU sensors
imu = IMU(gs=4, dps=2000, verbose=True)

# setting a bias correction for the accel only, the mags/gyros
# are not getting a bias correction
imu.setBias((0.1,-0.02,.25), None, None)

# grab data at 10Hz
rate = Rate(10)

while True:
    header = 67
    print('-'*header)
    print("| {:17} | {:20} | {:20} |".format("Accels [g's]", " Magnet [uT]", "Gyros [dps]"))
    print('-'*header)
    for _ in range(10):
        a, m, g = imu.get()
        print('| {:>5.2f} {:>5.2f} {:>5.2f} | {:>6.1f} {:>6.1f} {:>6.1f} | {:>6.1f} {:>6.1f} {:>6.1f} |'.format(
            a[0], a[1], a[2],
            m[0], m[1], m[2],
            g[0], g[1], g[2])
        )
        time.sleep(0.50)
    print('-'*header)
    print(' uT: micro Tesla')
    print('  g: gravity')
    print('dps: degrees per second')
    print('')

    rate.sleep()
Examples
pi@nav examples $ ./test.py

========================================
FXOS8700
  Accelerometer:
    Addr: 0x1F
    Range: +/- 2 G
  Magnetometer:
    Range: +/- 1200
  Temperature: 0 C
========================================
FXAS21002C Gyro
  Addr: 0x21
  Range: +/- 250dps
  Temperature: 10 C
-----------------------------------------------
| Accels [g's]         | Orient(r,p,h) [deg]  |
-----------------------------------------------
|    0.0   -0.0    1.0 |   -0.0   -0.0    3.0 |
|    0.0   -0.0    1.0 |   -0.0   -0.0    2.9 |
|    0.0   -0.0    1.0 |   -0.0   -0.0    2.9 |
|    0.0   -0.0    1.0 |   -0.0   -0.0    2.9 |
|    0.0   -0.0    1.0 |   -0.0   -0.0    2.9 |
|    0.0   -0.0    1.0 |   -0.0   -0.0    2.9 |
|    0.0   -0.0    1.0 |   -0.0   -0.0    2.9 |
|    0.0   -0.0    1.0 |   -0.0   -0.0    2.9 |
|    0.0   -0.0    1.0 |   -0.0   -0.0    2.9 |
|    0.0   -0.0    1.0 |   -0.0   -0.0    2.9 |
-----------------------------------------------
  r: roll
  p: pitch
  h: heading
  g: gravity
deg: degree

========================================
FXOS8700
  Accelerometer:
    Addr: 0x1F
    Range: +/- 4 G
  Magnetometer:
    Range: +/- 1200
  Temperature: 25 C
========================================
FXAS21002C Gyro
  Addr: 0x21
  Range: +/- 2000dps
  Temperature: 10 C
-------------------------------------------------------------------
| Accels [g's]      |  Magnet [uT]         | Gyros [dps]          |
-------------------------------------------------------------------
|  0.04 -0.04  1.02 |  -21.5   -4.7    8.3 |    0.8   -1.4   -0.2 |
|  0.04 -0.04  1.03 |  -21.6   -5.3    8.3 |    1.2   -1.1   -0.4 |
|  0.04 -0.04  1.02 |  -21.9   -4.4   10.5 |    0.4   -0.9   -0.1 |
|  0.04 -0.04  1.02 |  -21.5   -4.8    9.9 |    1.3   -1.2    0.1 |
|  0.04 -0.04  1.02 |  -22.4   -4.9    8.7 |    1.2   -0.8   -0.2 |
|  0.04 -0.04  1.02 |  -21.7   -5.4    8.5 |    0.2   -1.6    0.0 |
|  0.04 -0.04  1.03 |  -21.9   -4.7    8.1 |    1.2   -1.2   -0.4 |
|  0.04 -0.04  1.02 |  -22.2   -4.4   10.0 |    1.5   -1.5   -0.1 |
|  0.04 -0.04  1.02 |  -22.2   -5.7    9.1 |    0.5   -1.2   -0.4 |
|  0.04 -0.04  1.02 |  -22.3   -5.0    8.0 |    0.7   -1.4   -0.6 |
-------------------------------------------------------------------
 uT: micro Tesla
  g: gravity
dps: degrees per second

Done ...
Decination Angle
Remeber, depending on where you are on the Earth, true North changes because the Earth is not a perfect sphere. You can get the declination angle for your location from: http://www.magnetic-declination.com/
Documents
The /docs folder has the datasheets for both the accel/magnetometer
and the gyros.
MIT License
Copyright (c) 2017 Kevin J. Walchko
Permission is hereby granted, free of charge, to any person obtaining a copy of this software and associated documentation files (the "Software"), to deal in the Software without restriction, including without limitation the rights to use, copy, modify, merge, publish, distribute, sublicense, and/or sell copies of the Software, and to permit persons to whom the Software is furnished to do so, subject to the following conditions:
The above copyright notice and this permission notice shall be included in all copies or substantial portions of the Software.
THE SOFTWARE IS PROVIDED "AS IS", WITHOUT WARRANTY OF ANY KIND, EXPRESS OR IMPLIED, INCLUDING BUT NOT LIMITED TO THE WARRANTIES OF MERCHANTABILITY, FITNESS FOR A PARTICULAR PURPOSE AND NONINFRINGEMENT. IN NO EVENT SHALL THE AUTHORS OR COPYRIGHT HOLDERS BE LIABLE FOR ANY CLAIM, DAMAGES OR OTHER LIABILITY, WHETHER IN AN ACTION OF CONTRACT, TORT OR OTHERWISE, ARISING FROM, OUT OF OR IN CONNECTION WITH THE SOFTWARE OR THE USE OR OTHER DEALINGS IN THE SOFTWARE.
1 maintainer

Metadata
1 maintainer
Release files for nxp-imu 0.6.2
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | |
|---|---|---|---|
| nxp_imu-0.6.2.tar.gz | 10.7 kB | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| nxp_imu-0.6.2-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 21.9 kB
Release files / nxp_imu-0.6.2.tar.gz
| Download URL | nxp_imu-0.6.2.tar.gz |
|---|---|
| Size | 10.7 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
c71ed9f1242aefb649e01b67df6f09056e4e584dbbbe827ab84512fae82425df
|
|
BLAKE2b-256 checksum How to use checksums |
c2d1a745edf6e1e8da9bbe42ea341b670c32a500e3b3af9b4eabe3949ca2cef9
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
poetry/1.0.2 CPython/3.7.5 Linux/5.3.0-29-generic
|
Release files / nxp_imu-0.6.2-py3-none-any.whl
| Download URL | nxp_imu-0.6.2-py3-none-any.whl |
|---|---|
| Size | 11.2 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
b0f389877578c2004557daf3bbfcf13396115f0b1911994f54e2834508f2e41a
|
|
BLAKE2b-256 checksum How to use checksums |
1860715b17136edba098f724b90734104d1fded385e0d0258e286d3010ddc2eb
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
poetry/1.0.2 CPython/3.7.5 Linux/5.3.0-29-generic
|














