


Orthority
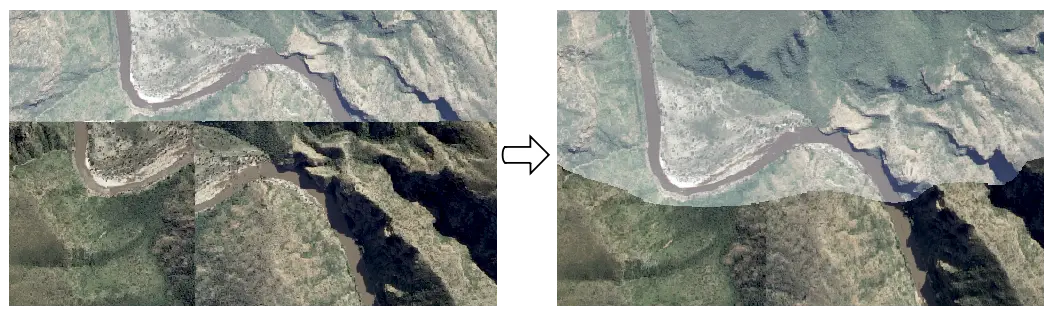
Orthority provides a command line toolkit and Python API for orthorectifying drone, aerial and satellite imagery, given a camera model and DEM. It supports common frame, and RPC camera models. Camera parameters can be read from various file formats, or image tags. Related algorithms including RPC refinement and pan-sharpening, are also provided.
Installation
Orthority is a python 3 package that can be installed with pip or conda.
pip
pip install orthorityconda
conda install -c conda-forge orthorityQuick start
Command line interface
Orthority command line functionality is accessed with the oty command, and its sub-commands:
frame: Orthorectify images with frame camera model(s) defined by interior and exterior parameter files.
exif: Orthorectify images with frame camera model(s) defined by image EXIF / XMP tags.
odm: Orthorectify images in a processed OpenDroneMap dataset that includes a DSM.
rpc: Orthorectify images with RPC camera models defined by image tags / sidecar files or parameter files.
sharpen: Pan-sharpen an image using the Gram-Schmidt method.
Get help on oty with:
oty --helpand help on an oty sub-command with:
oty <sub-command> --helpOptions for configuring output images are common to all sub-commands.
Examples
Orthorectify source.tif with the DEM in dem.tif, and frame camera model defined by int_param.yaml and ext_param.geojson interior and exterior parameters:
oty frame --dem dem.tif --int-param int_param.yaml --ext-param ext_param.geojson source.tifOrthorectify source.tif with the DEM in dem.tif, and frame camera model defined by source.tif EXIF / XMP tags:
oty exif --dem dem.tif source.tifAs above, but the create the ortho image with bilinear interpolation, a 0.5 m pixel size and deflate compression:
oty exif --dem dem.tif --interp bilinear --res 0.5 --compress deflate source.tifOrthorectify images in the OpenDroneMap dataset odm, with the dataset DSM and camera models. Ortho images are placed in odm/orthority.
oty odm --dataset-dir odm --out-dir odm/orthorityOrthorectify source.tif with the DEM in dem.tif, and RPC camera model defined by source.tif tags / sidecar files:
oty rpc --dem dem.tif source.tifAs above, but refine the RPC camera model with GCPs in source.tif tags:
oty rpc --dem dem.tif --gcp-refine tags source.tifPan-sharpen the multispectral image ms.tif with the panchromatic image pan.tif:
oty sharpen --pan pan.tif --multispectral ms.tif --out-file pan_sharp.tifAPI
Orthorectify an image using interior and exterior parameter files to generate the camera model:
import orthority as oty

# URLs of required files
url_root = 'https://raw.githubusercontent.com/leftfield-geospatial/orthority/main/tests/data/'
src_file = url_root + 'ngi/3324c_2015_1004_05_0182_RGB.tif'  # aerial image
dem_file = url_root + 'ngi/dem.tif'  # DEM covering imaged area
int_param_file = url_root + 'io/ngi_int_param.yaml'  # interior parameters
ext_param_file = url_root + 'io/ngi_xyz_opk.csv'  # exterior parameters

# create a camera model for src_file from interior & exterior parameters
cameras = oty.FrameCameras(int_param_file, ext_param_file)
camera = cameras.get(src_file)

# create Ortho object and orthorectify
ortho = oty.Ortho(src_file, dem_file, camera=camera, crs=cameras.crs)
ortho.process('ortho.tif')
Pan-sharpen a multispectral image with the matching panchromatic image:
import orthority as oty

# URLs of required files
url_root = 'https://raw.githubusercontent.com/leftfield-geospatial/orthority/main/tests/data/'
pan_file = url_root + 'pan_sharp/pan.tif'  # panchromatic drone image
ms_file = url_root + 'pan_sharp/ms.tif'  # multispectral (RGB) drone image

# create PanSharpen object and pan-sharpen
pan_sharp = oty.PanSharpen(pan_file, ms_file)
pan_sharp.process('pan_sharp.tif')
Documentation
See orthority.readthedocs.io for usage and reference documentation.
Contributing
Contributions are welcome - the online documentation has a guide. Please report bugs and make feature requests with the github issue tracker.
Licensing
Orthority is licensed under the GNU Affero General Public License v3.0 (AGPLv3).
Portions of the AGPLv3 licensed OpenDroneMap software, and BSD-style licensed OpenSfM library have been adapted and included in the Orthority package.
Acknowledgements
Special thanks to Yu-Huang Wang & the OpenDroneMap Community, National Geo-spatial Information and the Centre for Geographical Analysis for sharing imagery, DEM and aero-triangulation data that form part of the package test data.
1 maintainer

Metadata
1 maintainer
Release files for orthority 0.7.0
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | Provenance | Actions |
|---|---|---|---|---|
| orthority-0.7.0.tar.gz | 148.2 kB | With provenance | Details for orthority-0.7.0.tar.gz |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Actions Reset |
|---|---|---|---|---|
| orthority-0.7.0-py3-none-any.whl | Python 3 | none | any | Details for orthority-0.7.0-py3-none-any.whl |
Total release size: 249.4 kB
Release files / orthority-0.7.0.tar.gz
| Download URL | orthority-0.7.0.tar.gz |
|---|---|
| Size | 148.2 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
72fbea3ba31a75956ea03ae2c47413109ea8df826449eecae19b52219761825c
|
|
BLAKE2b-256 checksum How to use checksums |
89ece3b9242b77abf840227fa2ad60f0b79ce5390fc33d5bb114f1959b1d0e40
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.


PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Aug 19, 2026.
Transparency logRelease files / orthority-0.7.0-py3-none-any.whl
| Download URL | orthority-0.7.0-py3-none-any.whl |
|---|---|
| Size | 101.2 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
e740923852a35569643b802ba1976ab49cddeca67f065a6f7e62a37cc62cf5ca
|
|
BLAKE2b-256 checksum How to use checksums |
2db738721777a43dd2915fa46e85c90f33b13eab9cffe86458fa21e2aeb67446
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Aug 19, 2026.
Transparency logSecurity for orthority 0.7.0
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
Full provenance
Both files in this release have been uploaded with provenance metadata.
Attestation for orthority-0.7.0.tar.gz
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Aug 19, 2026.
Transparency logA note on package security
PyPI is a repository for distributing packages, not a service for auditing them. While third-party security researchers and our staff do their best to detect and remove malicious packages, PyPI cannot guarantee the quality, security or suitability of any given package.
To learn more about protecting yourself from malicious actors, visit our package security documentation.














