
Perceptual Control Theory
With this library you can create and run simple or complex hierarchies of perceptual control systems as well as make use of the power of the Python platform and its rich set of packages.
In the context of this library a single control system comprising a perceptual, reference, comparator and output function is called a Node. The functions therein can be configured by the user.
A hierarchy is defined by a collection of nodes.
Install
pip install pct
Import
Examples of importing the library functionality.
import pct as p
from pct.hierarchy import Hierarchy
from pct import *
How to use
Import modules from the PCT library.
from pct.nodes import PCTNode
For the purposes of this example define a world model. This would not be required if the real world is used, or a simulation such as OpenAI Gym.
def velocity_model(velocity,  force , mass):
    velocity = velocity + force / mass
    return velocity

# World value
mass = 50
Create a PCTNode, a control system unit comprising a reference, perception, comparator and output function. The default value for the reference is 1. With the history flag set, the data for each iteration is recorded for later plotting.
pctnode = PCTNode(history=True)
Call the node repeatedly to control the perception of velocity. With the verbose flag set, the control values are printed. In this case the printed values are the iteration number, the (velocity) reference, the perception, the error and the (force) output.
for i in range(40):
    print(i, end=" ")
    force = pctnode(verbose=True)
    velocity = velocity_model(pctnode.get_perception_value(), force, mass)
    pctnode.set_perception_value(velocity)
0 0.000 0.000 0.000 0.000
1 0.000 0.000 0.000 0.000
2 0.000 0.000 0.000 0.000
3 0.000 0.000 0.000 0.000
4 0.000 0.000 0.000 0.000
5 0.000 0.000 0.000 0.000
6 0.000 0.000 0.000 0.000
7 0.000 0.000 0.000 0.000
8 0.000 0.000 0.000 0.000
9 0.000 0.000 0.000 0.000
10 0.000 0.000 0.000 0.000
11 0.000 0.000 0.000 0.000
12 0.000 0.000 0.000 0.000
13 0.000 0.000 0.000 0.000
14 0.000 0.000 0.000 0.000
15 0.000 0.000 0.000 0.000
16 0.000 0.000 0.000 0.000
17 0.000 0.000 0.000 0.000
18 0.000 0.000 0.000 0.000
19 0.000 0.000 0.000 0.000
20 0.000 0.000 0.000 0.000
21 0.000 0.000 0.000 0.000
22 0.000 0.000 0.000 0.000
23 0.000 0.000 0.000 0.000
24 0.000 0.000 0.000 0.000
25 0.000 0.000 0.000 0.000
26 0.000 0.000 0.000 0.000
27 0.000 0.000 0.000 0.000
28 0.000 0.000 0.000 0.000
29 0.000 0.000 0.000 0.000
30 0.000 0.000 0.000 0.000
31 0.000 0.000 0.000 0.000
32 0.000 0.000 0.000 0.000
33 0.000 0.000 0.000 0.000
34 0.000 0.000 0.000 0.000
35 0.000 0.000 0.000 0.000
36 0.000 0.000 0.000 0.000
37 0.000 0.000 0.000 0.000
38 0.000 0.000 0.000 0.000
39 0.000 0.000 0.000 0.000
Using the plotly library plot the data. The graph shows the perception being controlled to match the reference value.
import plotly.graph_objects as go
fig = go.Figure(layout_title_text="Velocity Goal")
fig.add_trace(go.Scatter(y=pctnode.history.data['refcoll']['constant'], name="ref"))
fig.add_trace(go.Scatter(y=pctnode.history.data['percoll']['variable'], name="perc"))
This following code is only for the purposes of displaying image of the graph generated by the above code.
from IPython.display import Image
Image(url='http://www.perceptualrobots.com/wp-content/uploads/2020/08/pct_node_plot.png')
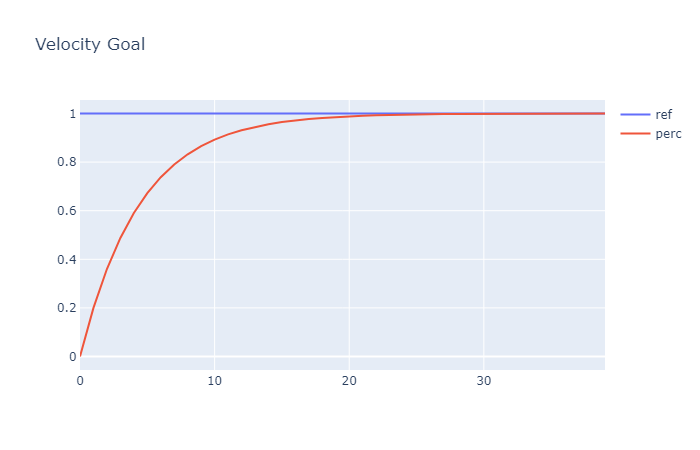
This shows a very basic example of the use of the PCT library. For more advanced functionality see the API documentation at https://perceptualrobots.github.io/pct/.
1 maintainer

Metadata
1 maintainer
Release files for pct 0.1.5
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | Provenance | Actions |
|---|---|---|---|---|
| pct-0.1.5.tar.gz | 112.8 kB | Without provenance | Details for pct-0.1.5.tar.gz |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Actions Reset |
|---|---|---|---|---|
| pct-0.1.5-py3-none-any.whl | Python 3 | none | any | Details for pct-0.1.5-py3-none-any.whl |
Total release size: 232.5 kB
Release files / pct-0.1.5.tar.gz
| Download URL | pct-0.1.5.tar.gz |
|---|---|
| Size | 112.8 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
bd63aee34a6cc944ececcf4fee08948c4cd192cf41f9c9233d219da8288223ba
|
|
BLAKE2b-256 checksum How to use checksums |
4be78ba63b133c36daaff534f4f7ce2827122ce7de6cf0113db9e261a2354a27
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/6.2.0 CPython/3.10.0
|
Release files / pct-0.1.5-py3-none-any.whl
| Download URL | pct-0.1.5-py3-none-any.whl |
|---|---|
| Size | 119.7 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
ee9a838cb53085ab58c19f2d166b41ace162c29aabe87da2bf86bd4061481374
|
|
BLAKE2b-256 checksum How to use checksums |
10616e4f91c9e9ec3689530ffa0a7498e19057268ba125356555535dd59b4a99
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/6.2.0 CPython/3.10.0
|
Security for pct 0.1.5
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
No provenance found
None of the files in this release were uploaded with provenance metadata.
A note on package security
PyPI is a repository for distributing packages, not a service for auditing them. While third-party security researchers and our staff do their best to detect and remove malicious packages, PyPI cannot guarantee the quality, security or suitability of any given package.
To learn more about protecting yourself from malicious actors, visit our package security documentation.














