
Pydiffuser


Pydiffuser is a numerical simulation framework for nonequilibrium statistical physics based on JAX.
This package mainly aims:
- to share code to implement a numerical simulation on physical models written in various forms of stochastic differential equations.
- to revisit recent research highlights in nonequilibrium statistical physics.
- to reduce the repeated code on time-series data analysis, e.g., statistical analysis of single-particle trajectory for SPT experiments.
- to provide the skeleton of stochastic modeling for anyone interested in stochastic processes.
Installation
Requirements
Python 3.10+, jax>=0.4.18, and jaxlib>=0.4.18.
From PyPI
$ pip install pydiffuser
If properly installed, you can run:
$ pydiffuser --version
pydiffuser, version 0.0.3
Quickstart
Pydiffuser provides various stochastic models that implement a numerical simulation based on the Monte Carlo method.
All Pydiffuser's models inherit an abstract class pydiffuser.models.BaseDiffusion and initiate the simulation after a method generate is called.
For the simplest case, you can produce a non-interacting Brownian motion at low Reynolds numbers as follows:
from pydiffuser.models import BrownianMotion
from pydiffuser.tracer import Ensemble, Trajectory


model = BrownianMotion()
ensemble: Ensemble = model.generate()
tracer: Trajectory = ensemble[0]  # the 0th particle
Relevant stochastic observables, such as mean-squared displacement and normalized velocity autocorrelation function, can be calculated through the methods of Trajectory and Ensemble.
tamsd = tracer.get_mean_squared_displacement(lagtime=1, rolling=True)
eamsd = ensemble.get_mean_squared_displacement(lagtime=1, rolling=False)
eatamsd = ensemble.get_mean_squared_displacement(lagtime=1, rolling=True)
You can visualize the trajectory using matplotlib:
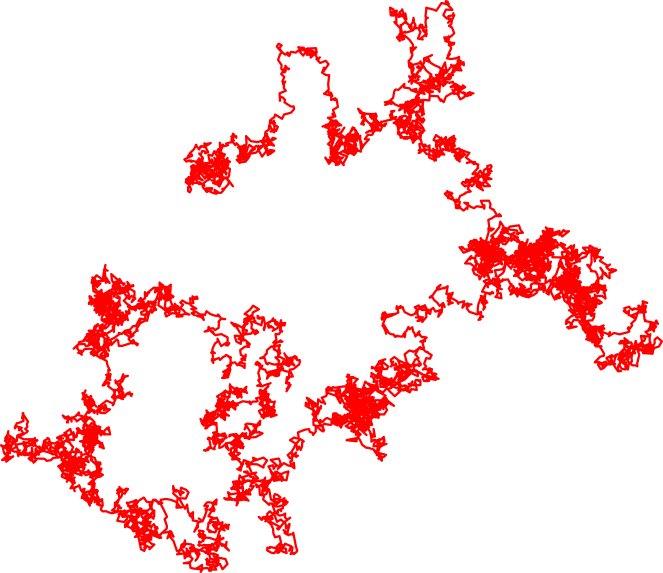
It is obtained by matplotlib.pyplot.plot(tracer.position_x1, tracer.position_x2).
CLI
List all stochastic models supported by Pydiffuser.
$ pydiffuser model list
NAME            MODEL                           CONFIG                          DIMENSION
abp             ActiveBrownianParticle          ActiveBrownianParticleConfig    2d
aoup            ActiveOUParticle                ActiveOUParticleConfig          1d, 2d, 3d
bm              BrownianMotion                  BrownianMotionConfig            1d, 2d, 3d
levy            LevyWalk                        LevyWalkConfig                  1d, 2d, 3d
mips            PhaseSeparation                 PhaseSeparationConfig           1d, 2d, 3d
rtp             RunAndTumbleParticle            RunAndTumbleParticleConfig      1d, 2d, 3d
smoluchowski    SmoluchowskiEquation            SmoluchowskiEquationConfig      1d, 2d
vicsek          VicsekModel                     VicsekModelConfig               2d
Features
How fast is it?
When generating $N$ realizations consisting of $L$ footprints, we have:
═════════════════════════════════════════════════════════════════════════════════════════════════
Model               Method              Running time [s] for N x L =
                                        10² x 10⁵          10³ x 10⁴          10⁴ x 10³
─────────────────────────────────────────────────────────────────────────────────────────────────
`loop` [*]                              3.62 (0.19)        3.45 (0.23)        3.37 (0.21)
─────────────────────────────────────────────────────────────────────────────────────────────────
`abp`               `generate`          1.95 (0.14)        1.74 (0.12)        1.59 (0.11)
`aoup`              `generate`          1.61 (0.08)        1.61 (0.15)        1.55 (0.09)
`bm`                `generate`          1.45 (0.11)        1.46 (0.13)        1.46 (0.14)
`smoluchowski`      `generate`          1.71 (0.12)        1.67 (0.15)        1.64 (0.13)
─────────────────────────────────────────────────────────────────────────────────────────────────
`bm`                `create`            1440.72 (158.16)   964.90 (83.06)     1195.41 (94.28)
═════════════════════════════════════════════════════════════════════════════════════════════════
[*]
def loop(N: int, L: int) -> float:
    """Even the most straightforward loop requires over 3 [s] for all (N, L) conditions.
    """

    t1 = time.time()

    xes = []
    for _ in range(N):
        x = []
        for _ in range(1, L):
            x.append([])
        xes.append(x)

    t2 = time.time()
    return t2 - t1
The represented running time is a mean $\mu$ (standard deviation $\sigma$) of five trials.
Observables
class pydiffuser.tracer.Trajectory ∈ class pydiffuser.tracer.Ensemble
get_incrementsget_displacement_momentget_mean_squared_displacementget_cosine_momentget_velocity_autocorrelationget_real_time
The above methods are defined in both Trajectory and Ensemble to enhance transparency.
Using Trajectory, the statistical analysis of single-particle trajectory can be accelerated.
Configuration
We introduce a configuration to deal with extensive parameter manipulation.
For instance, see config.json, which contains all parameters demanded to instantiate pydiffuser.ActiveBrownianParticle.
Every JSON of the configurations listed in CLI can be obtained as follows:
import pydiffuser as pyd
from pydiffuser.models import ActiveBrownianParticle, ActiveBrownianParticleConfig


config = ActiveBrownianParticleConfig()
config.to_json(json_path=<JSON_PATH>)
We suggest a research pipeline:
┌────┐     ┌─────────────────────┐     ┌───────────────┐     ┌──────────┐     ┌────────────┐
│JSON├──>──┤`BaseDiffusionConfig`├──>──┤`BaseDiffusion`├──>──┤`Ensemble`├──>──┤NPY | PICKLE│
└────┘ [1] └─────────────────────┘ [2] └───────────────┘ [3] └──────────┘ [4] └────────────┘
It can be automized as follows:
config = ActiveBrownianParticleConfig.from_json(json_path=<JSON_PATH>)  # [1]
model = ActiveBrownianParticle.from_config(config=config)  # [2]
ensemble = model.generate()  # [3]
ensemble.to_npy(npy_path=<NPY_PATH>)  # [4]
You can save and load any picklable object through pydiffuser.save and pydiffuser.load.
MODEL_PATH = "model.pickle"


pyd.save(obj=model, pickle_path=MODEL_PATH)  # Here, <PICKLE_PATH> = MODEL_PATH
model = pyd.load(pickle_path=MODEL_PATH)
Related Works
Hyperdiffusion of Poissonian run-and-tumble particles in two dimensions
License
Citation
@misc{jung2023pydiffuser,
  title = {Pydiffuser: a simulation framework for nonequilibrium statistical physics},
  author = {Jung, Yurim},
  year = {2023},
  note = {doi: 10.5281/zenodo.10017027},
}
1 maintainer

Metadata
1 maintainer
Release files for pydiffuser 0.0.3
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | |
|---|---|---|---|
| pydiffuser-0.0.3.tar.gz | 385.8 kB | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| pydiffuser-0.0.3-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 427.1 kB
Release files / pydiffuser-0.0.3.tar.gz
| Download URL | pydiffuser-0.0.3.tar.gz |
|---|---|
| Size | 385.8 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
3a790a9b104a4f50b7f5ffa8a4102cdccb3ff463703a7e68927ad502a12870a2
|
|
BLAKE2b-256 checksum How to use checksums |
8140312bafee8f8e8864c5ce3041955038663f21e4a8693b03fb5dfae73e04c9
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
python-requests/2.31.0
|
Release files / pydiffuser-0.0.3-py3-none-any.whl
| Download URL | pydiffuser-0.0.3-py3-none-any.whl |
|---|---|
| Size | 41.3 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
73aed9978ecf5f812e1b6f30ab78eb66e59bcce08d2568bc4c4fc110dafd23a0
|
|
BLAKE2b-256 checksum How to use checksums |
40761d62e9ebd6edb550580b20eb912a8547b5ce294b0c32f183681ca071119c
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
python-requests/2.31.0
|














