


pytransform3d
A Python library for transformations in three dimensions.
pytransform3d offers...
- operations like concatenation and inversion for most common representations of rotation (orientation) and translation (position)
- conversions between those representations
- clear documentation of transformation conventions
- tight coupling with matplotlib to quickly visualize (or animate) transformations
- the TransformManager which manages complex chains of transformations (with export to graph visualization as PNG, additionally requires pydot)
- the TransformEditor which allows to modify transformations graphically (additionally requires PyQt4/5)
- the UrdfTransformManager which is able to load transformations from URDF files (additionally requires beautifulsoup4)
- a matplotlib-like interface to Open3D's visualizer to display and animate geometries and transformations (additionally requires Open3D)
pytransform3d is used in various domains, for example:
- specifying motions of a robot
- learning robot movements from human demonstration
- sensor fusion for human pose estimation
- collision detection for robots
The API documentation can be found here.
Installation
Use pip to install the package from PyPI:
pip install pytransform3d[all]
or conda:
conda install -c conda-forge pytransform3d
Take a look at the installation instructions in the documentation for more details.
Gallery
The following plots and visualizations have been generated with pytransform3d. The code for most examples can be found in the documentation.
Left: Nao robot with URDF from Bullet3. Right: Kuka iiwa. The animation is based on pytransform3d's visualization interface to Open3D.


Visualizations based on Open3D.


Various plots based on Matplotlib.


Transformation editor based on Qt.

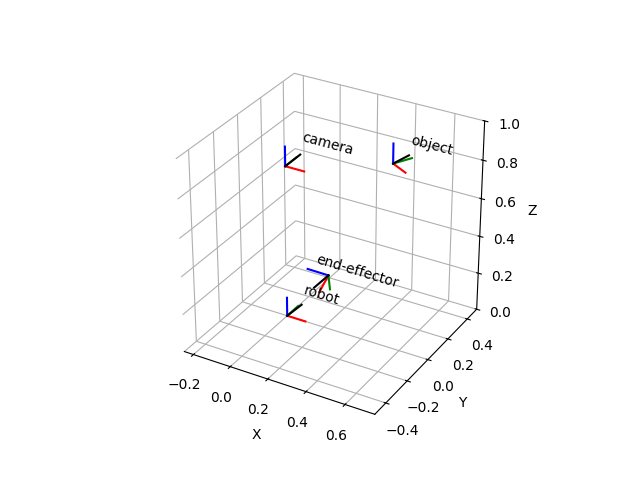
Example
This is just one simple example. You can find more examples in the subfolder
examples/.
import numpy as np
import matplotlib.pyplot as plt
from pytransform3d import rotations as pr
from pytransform3d import transformations as pt
from pytransform3d.transform_manager import TransformManager


rng = np.random.default_rng(0)

ee2robot = pt.transform_from_pq(
    np.hstack((np.array([0.4, -0.3, 0.5]),
               pr.random_quaternion(rng))))
cam2robot = pt.transform_from_pq(
    np.hstack((np.array([0.0, 0.0, 0.8]), pr.q_id)))
object2cam = pt.transform_from(
    pr.active_matrix_from_intrinsic_euler_xyz(np.array([0.0, 0.0, -0.5])),
    np.array([0.5, 0.1, 0.1]))

tm = TransformManager()
tm.add_transform("end-effector", "robot", ee2robot)
tm.add_transform("camera", "robot", cam2robot)
tm.add_transform("object", "camera", object2cam)

ee2object = tm.get_transform("end-effector", "object")

ax = tm.plot_frames_in("robot", s=0.1)
ax.set_xlim((-0.25, 0.75))
ax.set_ylim((-0.5, 0.5))
ax.set_zlim((0.0, 1.0))
plt.show()
Documentation
The API documentation can be found here.
The documentation can be found in the directory doc.
To build the documentation, run e.g. (on linux):
cd doc
make html
The HTML documentation is now located at doc/build/html/index.html.
You need the following packages to build the documentation:
pip install numpydoc sphinx sphinx-gallery sphinx-bootstrap-theme
Tests
You can use pytest to run the tests of this project in the root directory:
pytest
A coverage report will be located at htmlcov/index.html.
Note that you have to install pytest to run the tests and pytest-cov to
obtain the code coverage report.
Contributing
If you wish to report bugs, please use the issue tracker at Github. If you would like to contribute to pytransform3d, just open an issue or a pull request. The target branch for pull requests is the develop branch. The development branch will be merged to master for new releases. If you have questions about the software, you should ask them in the discussion section.
The recommended workflow to add a new feature, add documentation, or fix a bug is the following:
- Push your changes to a branch (e.g.
feature/x,doc/y, orfix/z) of your fork of the pytransform3d repository. - Open a pull request to the latest development branch. There is usually an open merge request from the latest development branch to the main branch.
- When the latest development branch is merged to the main branch, a new release will be made.
Note that there is a checklist for new features.
It is forbidden to directly push to the main branch (master). Each new version has its own development branch from which a pull request will be opened to the main branch. Only the maintainer of the software is allowed to merge a development branch to the main branch.
License
The library is distributed under the 3-Clause BSD license.
Citation
If you use pytransform3d for a scientific publication, I would appreciate citation of the following paper:
Fabisch, (2019). pytransform3d: 3D Transformations for Python.
Journal of Open Source Software, 4(33), 1159,
Bibtex entry:
@article{Fabisch2019,
  doi = {10.21105/joss.01159},
  url = {https://doi.org/10.21105/joss.01159},
  year = {2019},
  publisher = {The Open Journal},
  volume = {4},
  number = {33},
  pages = {1159},
  author = {Alexander Fabisch},
  title = {pytransform3d: 3D Transformations for Python},
  journal = {Journal of Open Source Software}
}
3 maintainers


Download files
Download the file for your platform. If you're not sure which to choose, learn more about installing packages.
Source Distribution
File details
Details for the file pytransform3d-3.2.0.tar.gz.
File metadata
- Download URL: pytransform3d-3.2.0.tar.gz
- Upload date:
- Size: 96.5 kB
- Tags: Source
- Uploaded using Trusted Publishing? No
- Uploaded via:
twine/4.0.2 CPython/3.9.13
File hashes
| Algorithm | Hash digest | |
|---|---|---|
| SHA256 |
700fd386cf536e538b789ac529f508436f96b7be8201aa12f4ca5b1a52b0afd2
|
|
| MD5 |
4d87f862a4a79244097cd4c1fb5762f6
|
|
| BLAKE2b-256 |
cb2f233b4e503f2794d2619b162bc474e0d2fa55539a7c8b01a72cbf55dc8310
|














