
real-robots

 |
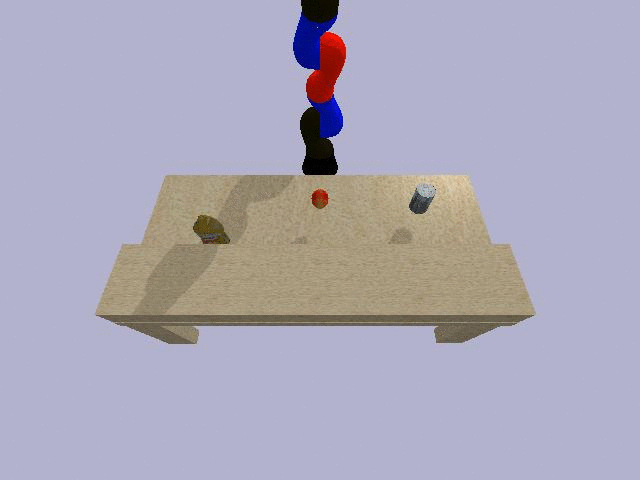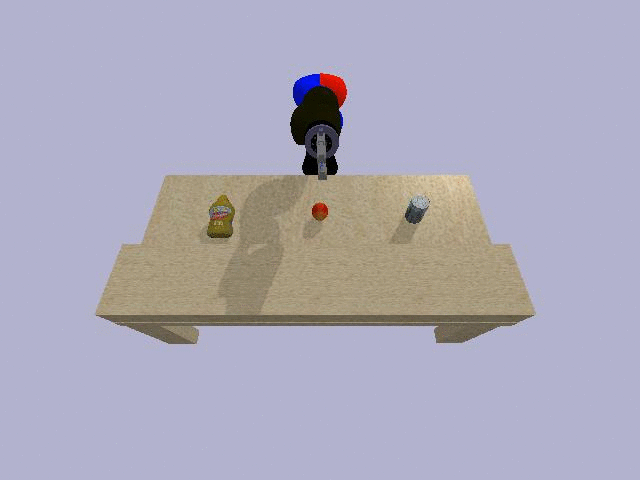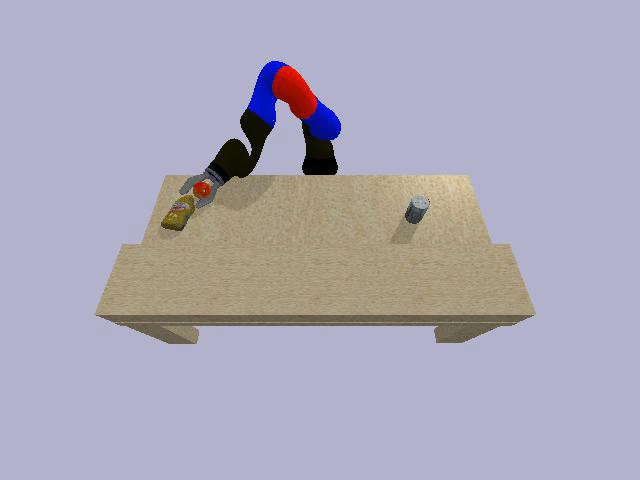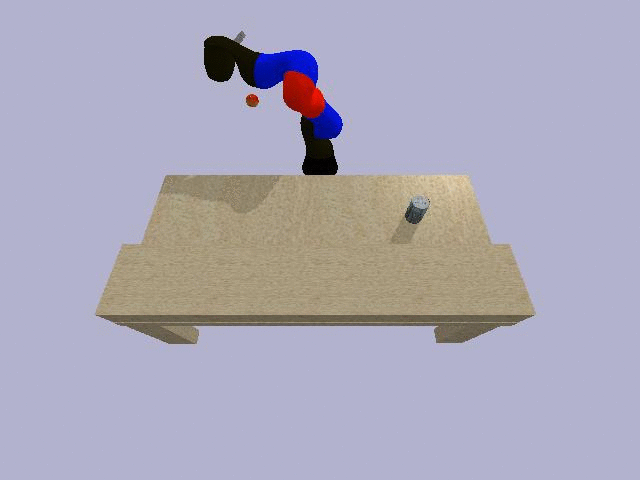 |
 |
Robots that learn to interact with the environment autonomously
Installation
pip install -U real_robots
If everything went well, then you should be able to run :
real-robots-demo
and it should (eventually) open up a small window with a little robotic arm doing random stuff.
Usage
import gym
import numpy as np
import time
import real_robots
from real_robots.policy import BasePolicy

class RandomPolicy(BasePolicy):
    def __init__(self, action_space):
        self.action_space = action_space
        self.action = action_space.sample()

    def step(self, observation, reward, done):
        if np.random.rand() < 0.05:
            self.action = self.action_space.sample()
        return self.action

env = gym.make("REALRobot2020-R2J3-v0")
pi = RandomPolicy(env.action_space)
env.render("human")

observation = env.reset()
reward, done = 0, False
for t in range(40):
    action = pi.step(observation, reward, done)
    observation, reward, done, info = env.step(action)
Local Evaluation
import gym
import numpy as np
import real_robots
from real_robots.policy import BasePolicy

class RandomPolicy(BasePolicy):
    def __init__(self, action_space):
        self.action_space = action_space
        self.action = action_space.sample()

    def step(self, observation, reward, done):
        if np.random.rand() < 0.05:
            self.action = self.action_space.sample()
        return self.action

result, detailed_scores = real_robots.evaluate(
                RandomPolicy,
                environment='R1',
                action_type='macro_action',
                n_objects=1,
                intrinsic_timesteps=1e3,
                extrinsic_timesteps=1e3,
                extrinsic_trials=3,
                visualize=False,
                goals_dataset_path='goals-REAL2020-s2020-50-1.npy.npz'
            )
# NOTE : You can find goals-REAL2020-s2020-50-1.npy.npz file in the REAL2020 Starter Kit repository
# or you can generate one using the real-robots-generate-goals command.
#
print(result)
# {'score_REAL2020': 0.06529471503519801, 'score_total': 0.06529471503519801}
print(detailed_scores)
# {'REAL2020': [0.00024387094790936833, 0.19553060745741896, 0.00010966670026571288]}
See also our FAQ.
- Free software: MIT license
Features
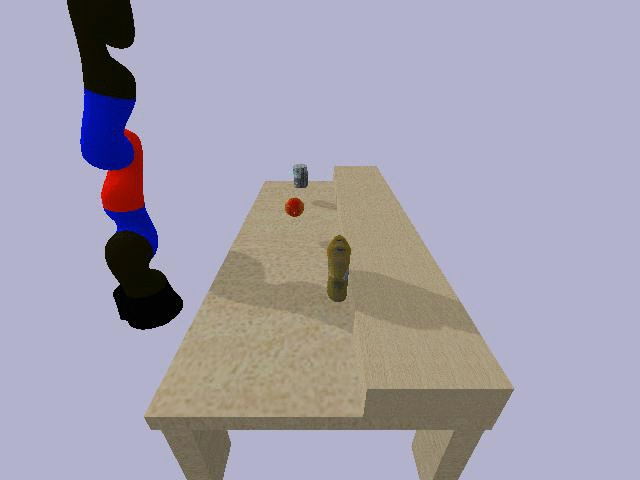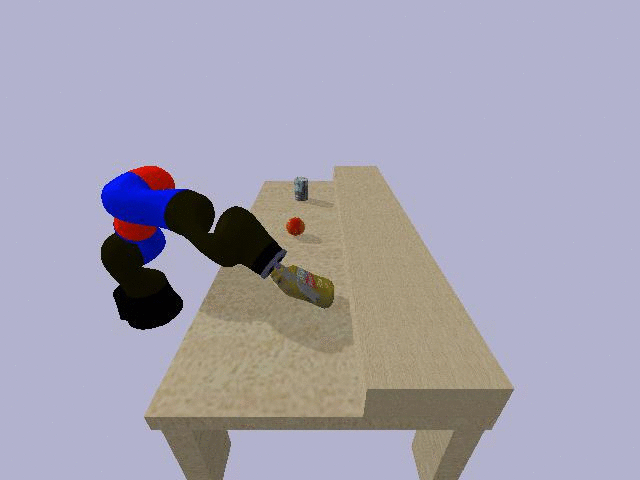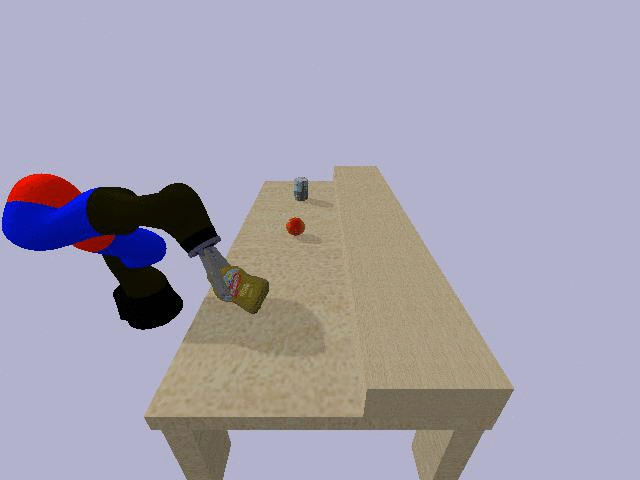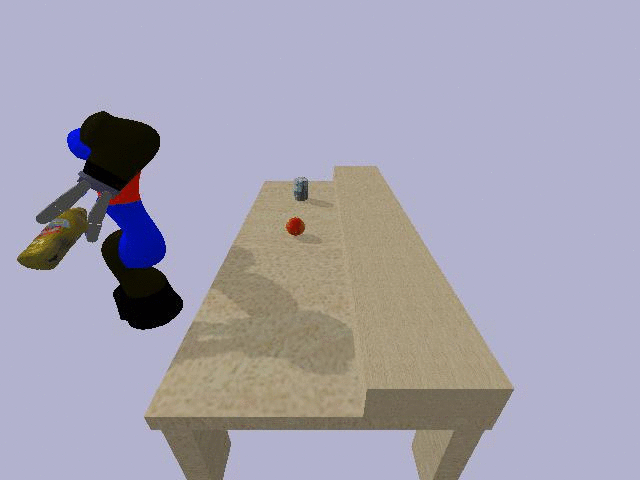
The REALRobot environment is a standard gym environment.
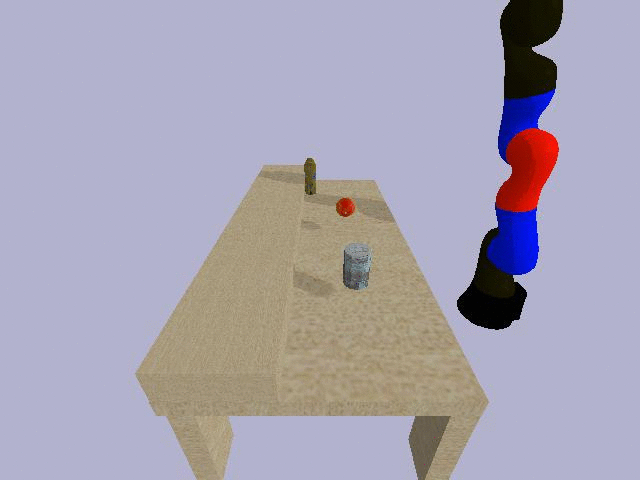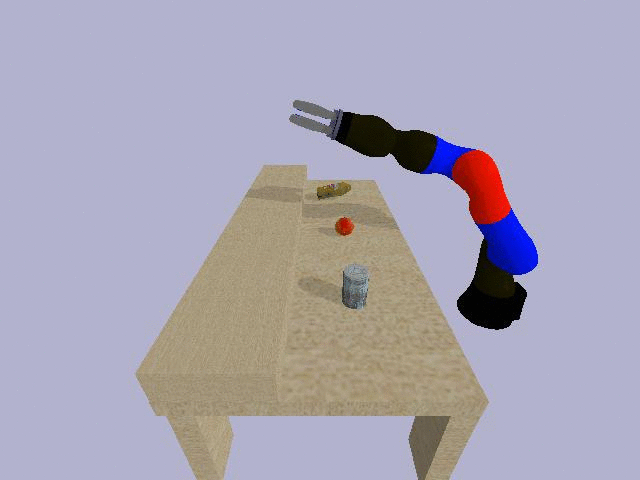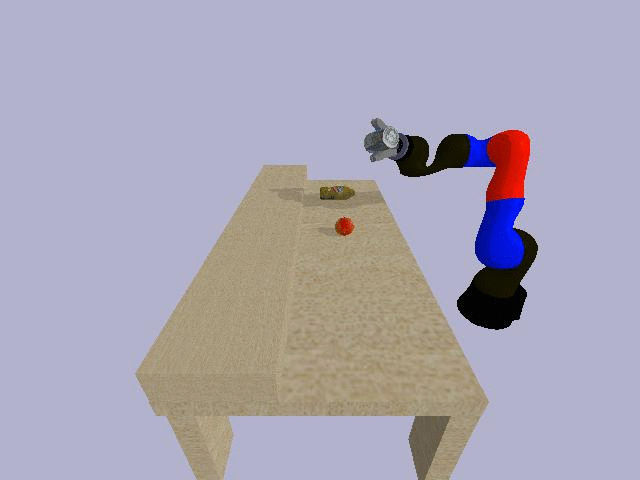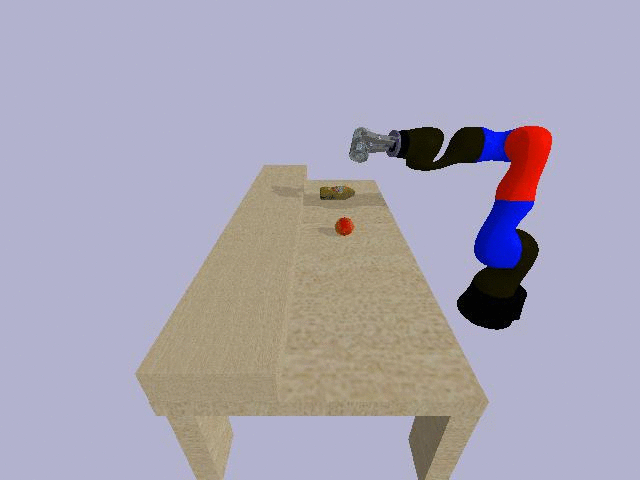
It includes a 7DoF kuka arm with a 2DoF gripper, a table with 3 objects on it and a camera looking at the table from the top.
For more info on the environment see environment.md.
Authors
- Francesco Mannella
- Emilio Cartoni
- Sharada Mohanty


Release files for real-robots 0.1.21
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | Provenance | Actions |
|---|---|---|---|---|
| real_robots-0.1.21.tar.gz | 9.1 MB | Without provenance | Details for real_robots-0.1.21.tar.gz |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Actions Reset |
|---|---|---|---|---|
| real_robots-0.1.21-py2.py3-none-any.whl | Python 2, Python 3 | none | any | Details for real_robots-0.1.21-py2.py3-none-any.whl |
Total release size: 27.2 MB
Release files / real_robots-0.1.21.tar.gz
| Download URL | real_robots-0.1.21.tar.gz |
|---|---|
| Size | 9.1 MB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
7e94526bcb70a23e53ca85f3686744356029c0a6ff8c226d9a76d8d59e81bec9
|
|
BLAKE2b-256 checksum How to use checksums |
4ed05d04f339d4d8b6602be5396bf5f074cc6fdb7b5688fd8603f1924bf13312
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/3.2.0 pkginfo/1.6.1 requests/2.24.0 setuptools/50.3.2 requests-toolbelt/0.9.1 tqdm/4.47.0 CPython/3.6.9
|
Release files / real_robots-0.1.21-py2.py3-none-any.whl
| Download URL | real_robots-0.1.21-py2.py3-none-any.whl |
|---|---|
| Size | 18.2 MB |
| Tags | Python 2 Python 3 |
|
SHA-256 checksum How to use checksums |
ead227d8025eced524629c19f6736ec251ec4a163174ac03cf8989efad0717ac
|
|
BLAKE2b-256 checksum How to use checksums |
23c9a63dbad03debd9289102f1acda1691ff98ae2290b86e2a3fbad7ce0fec2f
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/3.2.0 pkginfo/1.6.1 requests/2.24.0 setuptools/50.3.2 requests-toolbelt/0.9.1 tqdm/4.47.0 CPython/3.6.9
|
Security for real-robots 0.1.21
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
No provenance found
None of the files in this release were uploaded with provenance metadata.
A note on package security
PyPI is a repository for distributing packages, not a service for auditing them. While third-party security researchers and our staff do their best to detect and remove malicious packages, PyPI cannot guarantee the quality, security or suitability of any given package.
To learn more about protecting yourself from malicious actors, visit our package security documentation.














