


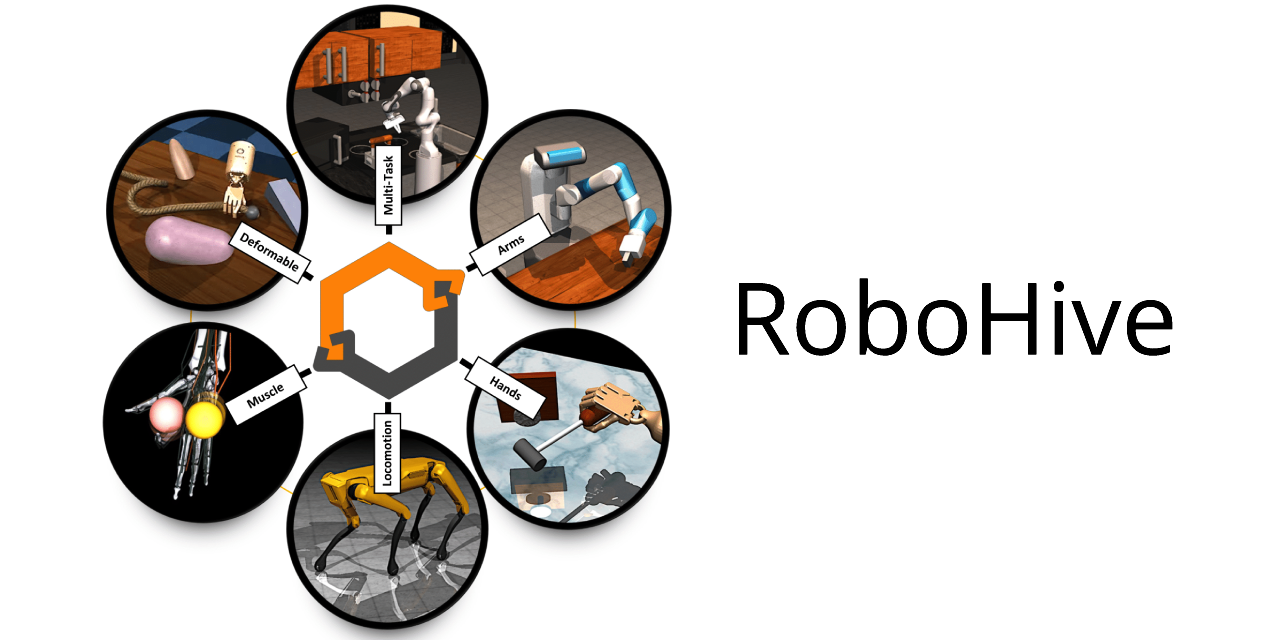
RoboHive is a collection of environments/tasks simulated with the MuJoCo physics engine exposed using the OpenAI-Gym API. Its compatible with any gym-compatible agents training framework (Stable Baselines, RLlib, TorchRL, AgentHive, etc)
Getting Started
Getting started with RoboHive is as simple as -
# Install RoboHive
pip install robohive
# Initialize RoboHive
robohive_init
# Demo an environment
python -m robohive.utils.examine_env -e FrankaReachRandom-v0
or, alternatively for editable installation -
# Clone RoboHive
git clone --recursive https://github.com/vikashplus/robohive.git; cd robohive
# Install (editable) RoboHive
pip install -e .
# Demo an environment
python -m robohive.utils.examine_env -e FrankaReachRandom-v0
See detailed installation instructions for options on mujoco-python-bindings and visual-encoders (R3M, RRL, VC), and frequently asked questions for more details.
Suites
RoboHive contains a variety of environments, which are organized as suites. Each suite is a collection of loosely related environments. The following suites are provided at the moment with plans to improve the diversity of the collection.
| Hand-Manipulation-Suite (video) |
|---|
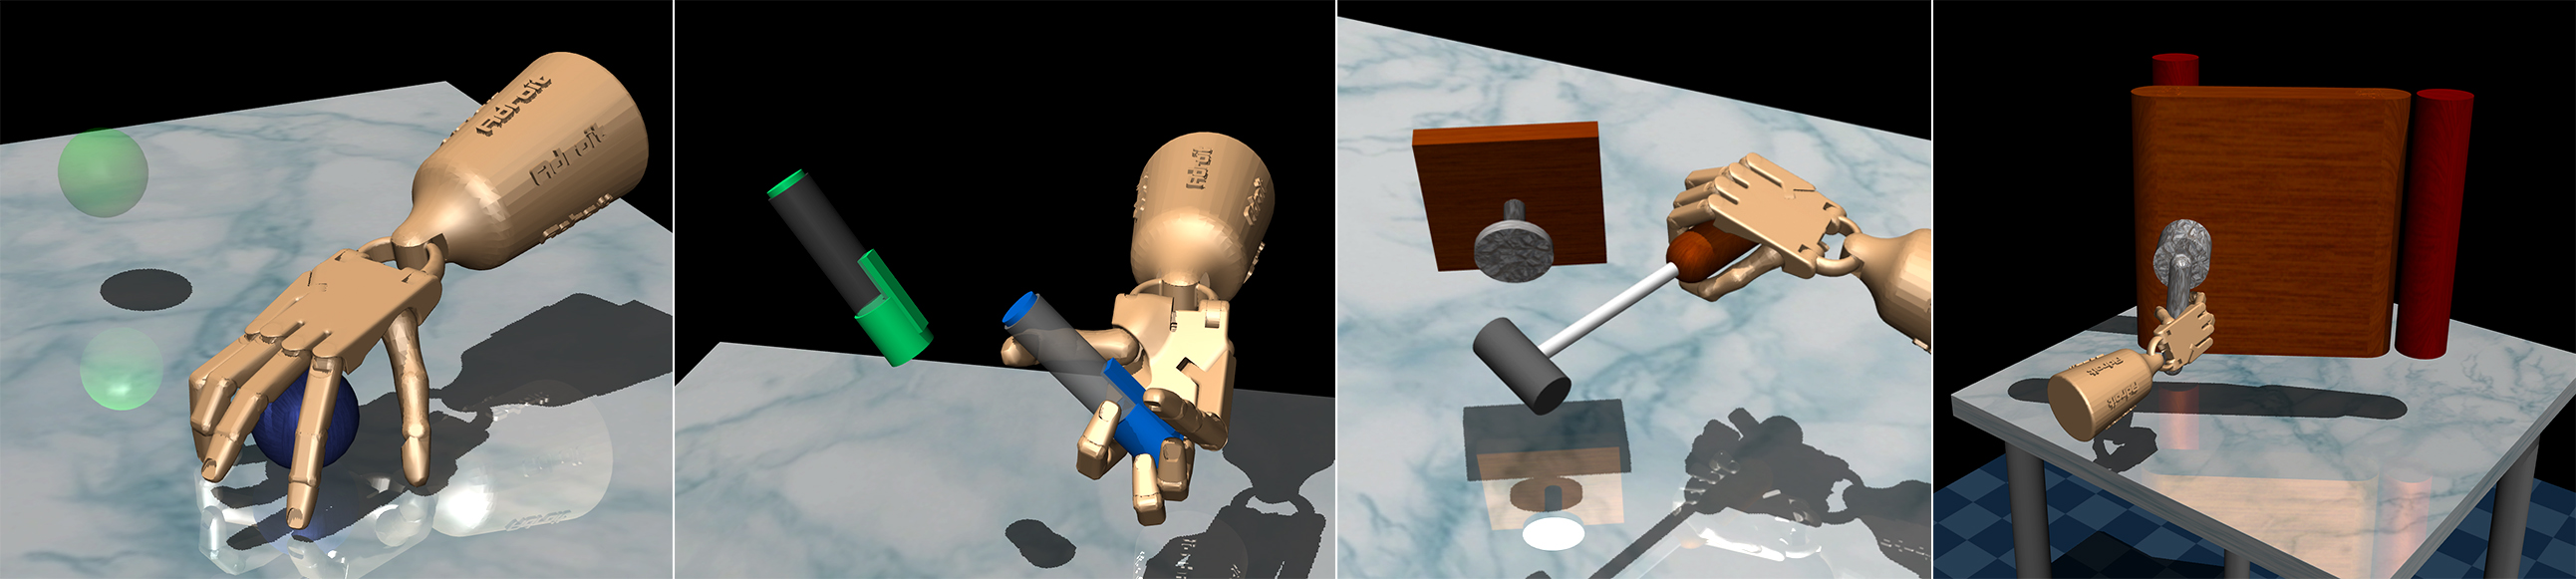 A collection of environments centered around dexterous manipulation. Standard ADROIT benchmarks introduced in Learning Complex Dexterous Manipulation with Deep Reinforcement Learning and Demonstrations, RSS2018.) are a part of this suite |
| Arm-Manipulation-Suite |
|---|
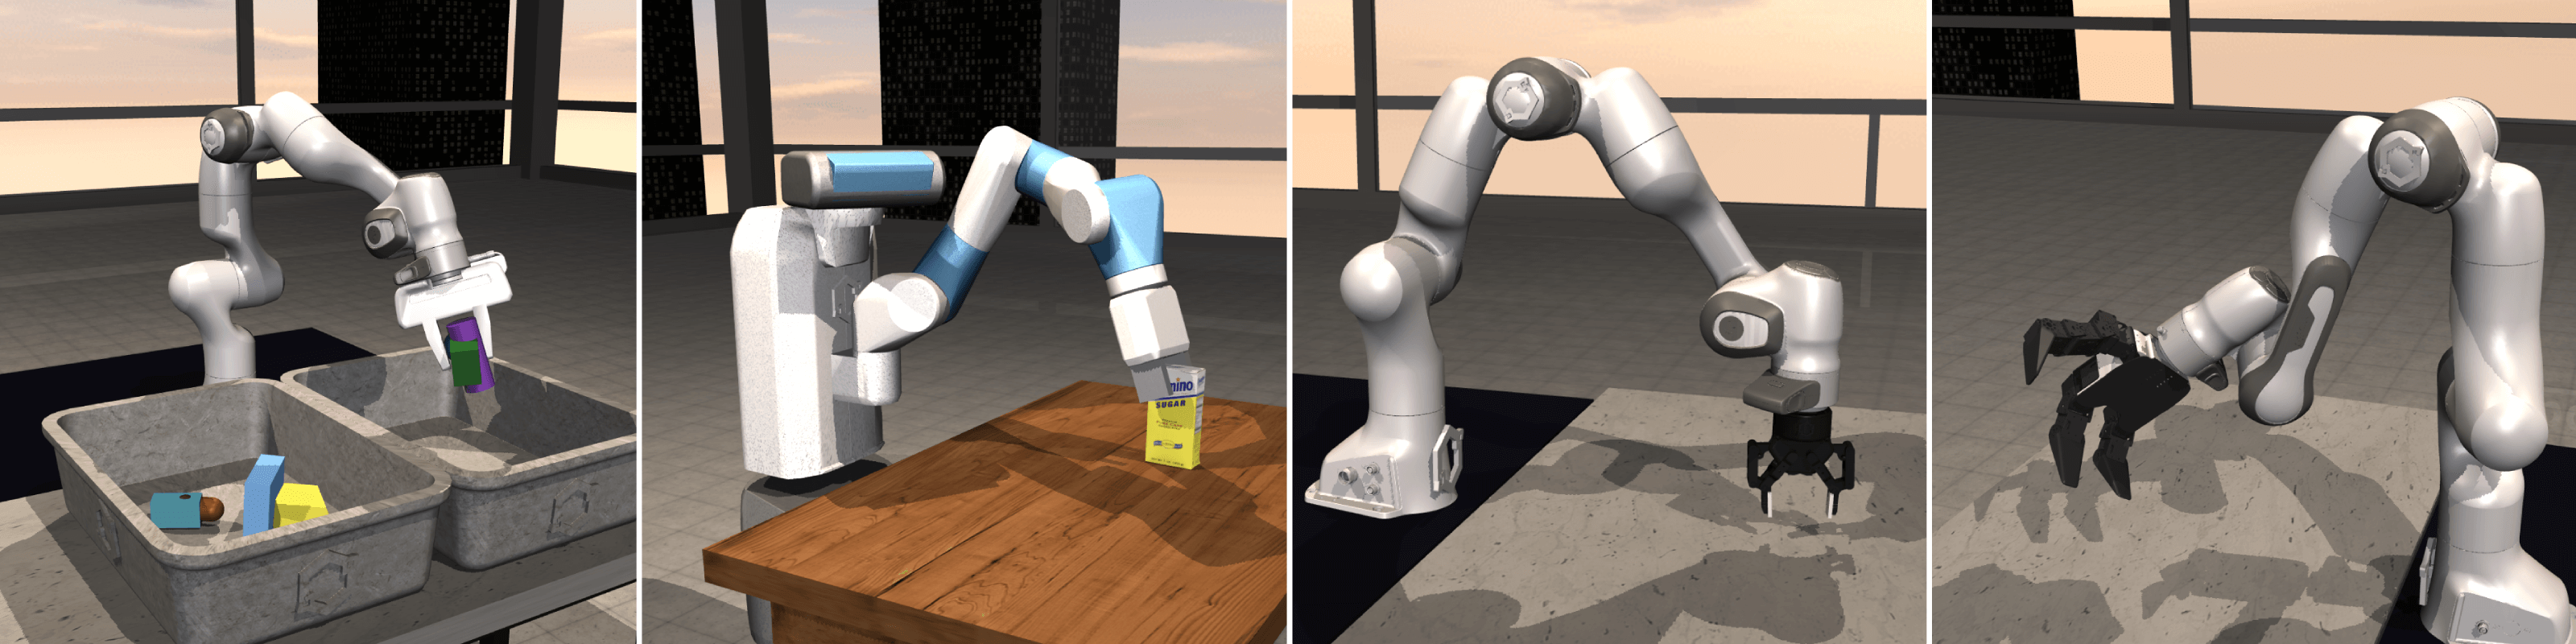 A collection of environments centered around Arm manipulation. |
| Myo-Suite (website) |
|---|
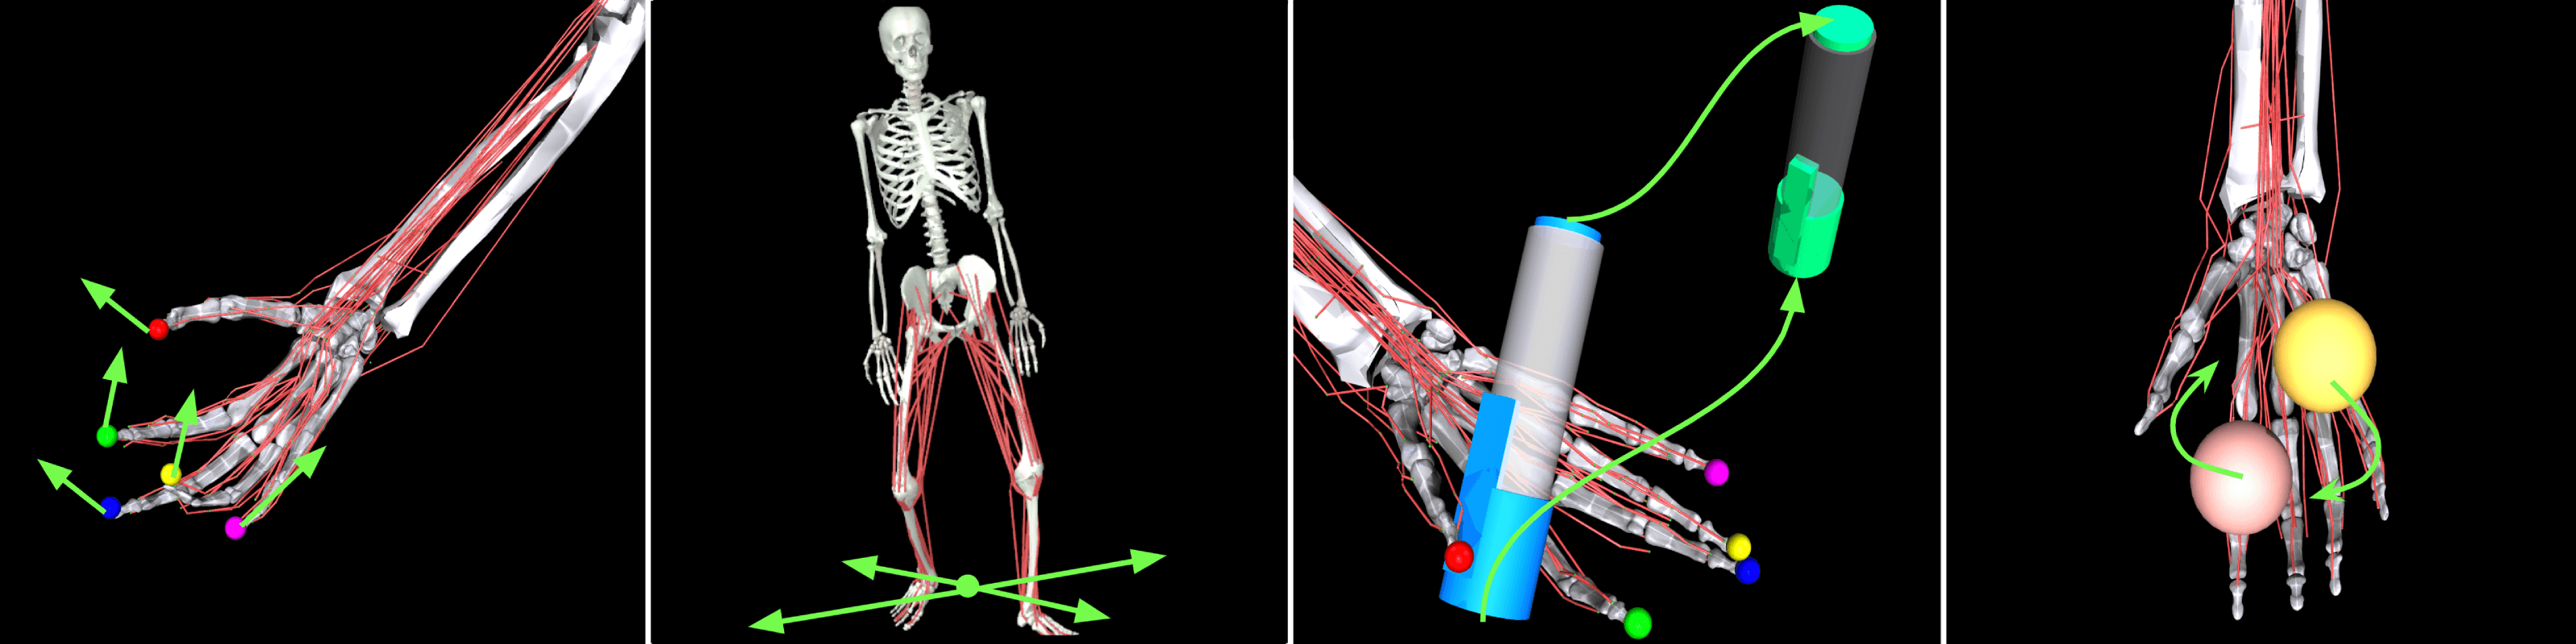 A collection of environments centered around Musculoskeletal control. |
| Myo/MyoDM-Suite (Website) |
|---|
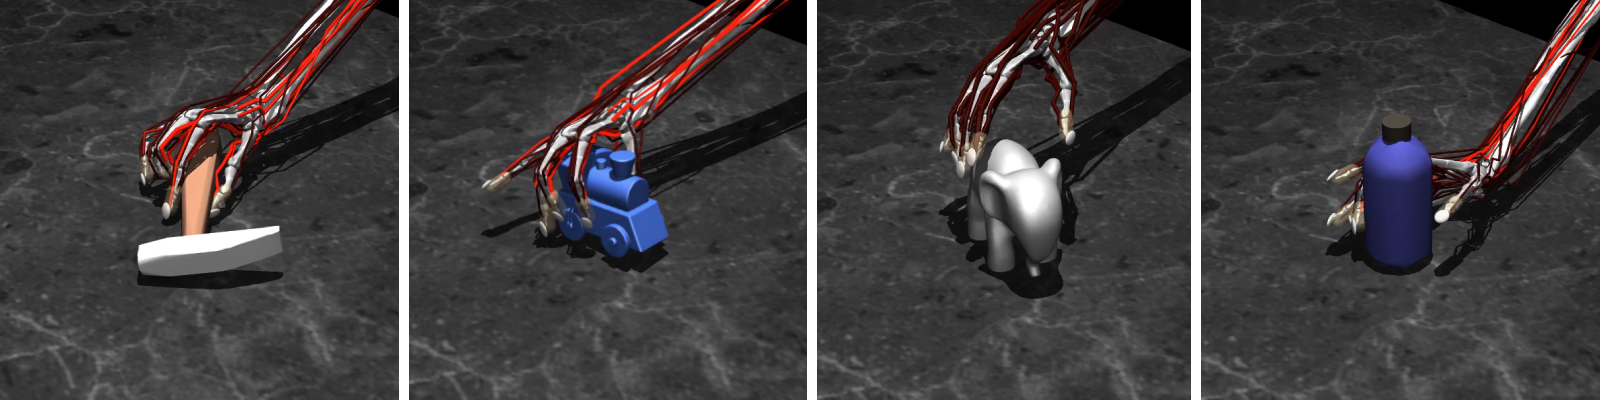 A collection of musculoskeletal environments for dexterous manipulation introduced as MyoDM in MyoDeX. |
| MultiTask Suite |
|---|
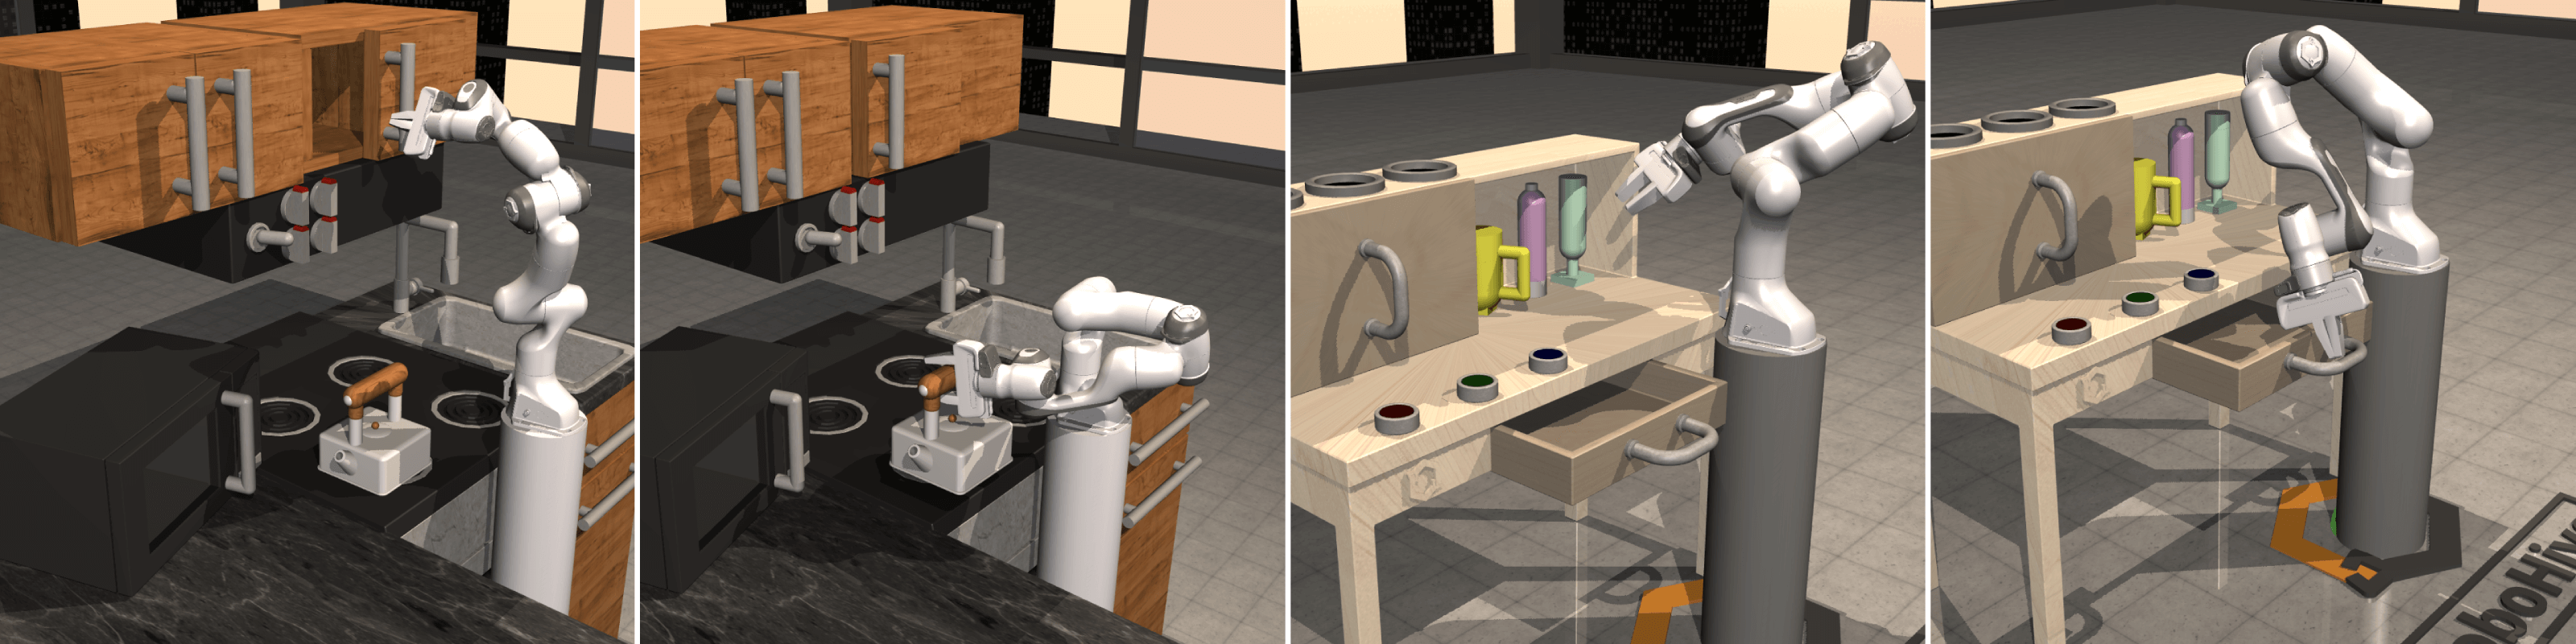 A collection of environments centered around multi-task. Standard RelayKitchen benchmarks are a part of this suite. |
- TCDM Suite (WIP)
This suite contains a collection of environments centered around dexterous manipulation. Standard TCDM benchmarks are a part of this suite
- ROBEL Suite (Coming soon)
This suite contains a collection of environments centered around real-world locomotion and manipulation. Standard ROBEL benchmarks are a part of this suite
Citation
If you find RoboHive useful in your research,
- please consider supporting the project by providing a star ⭐
- please consider citing our project by using the following BibTeX entry:
@Misc{RoboHive2020,
  title = {RoboHive -- A Unified Framework for Robot Learning},
  howpublished = {\url{https://sites.google.com/view/robohive}},
  year = {2020},
  url = {https://sites.google.com/view/robohive},
}
2 maintainers


Metadata
2 maintainers
Release files for robohive 0.7.0
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| robohive-0.7.0-py2.py3-none-any.whl | Python 3, Python 2 | none | any | Details |
Release files / robohive-0.7.0-py2.py3-none-any.whl
| Download URL | robohive-0.7.0-py2.py3-none-any.whl |
|---|---|
| Size | 13.5 MB |
| Tags | Python 2 Python 3 |
|
SHA-256 checksum How to use checksums |
7bf4edb1fa923288cb207a786331e267b19cf2f84470061a46a0c7ac890f6a23
|
|
BLAKE2b-256 checksum How to use checksums |
d300fc79392323e981f61a4563f01dcccf0ada435f269d431bd19162cc7fa5c5
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/5.0.0 CPython/3.9.18
|














