
RoboRadar
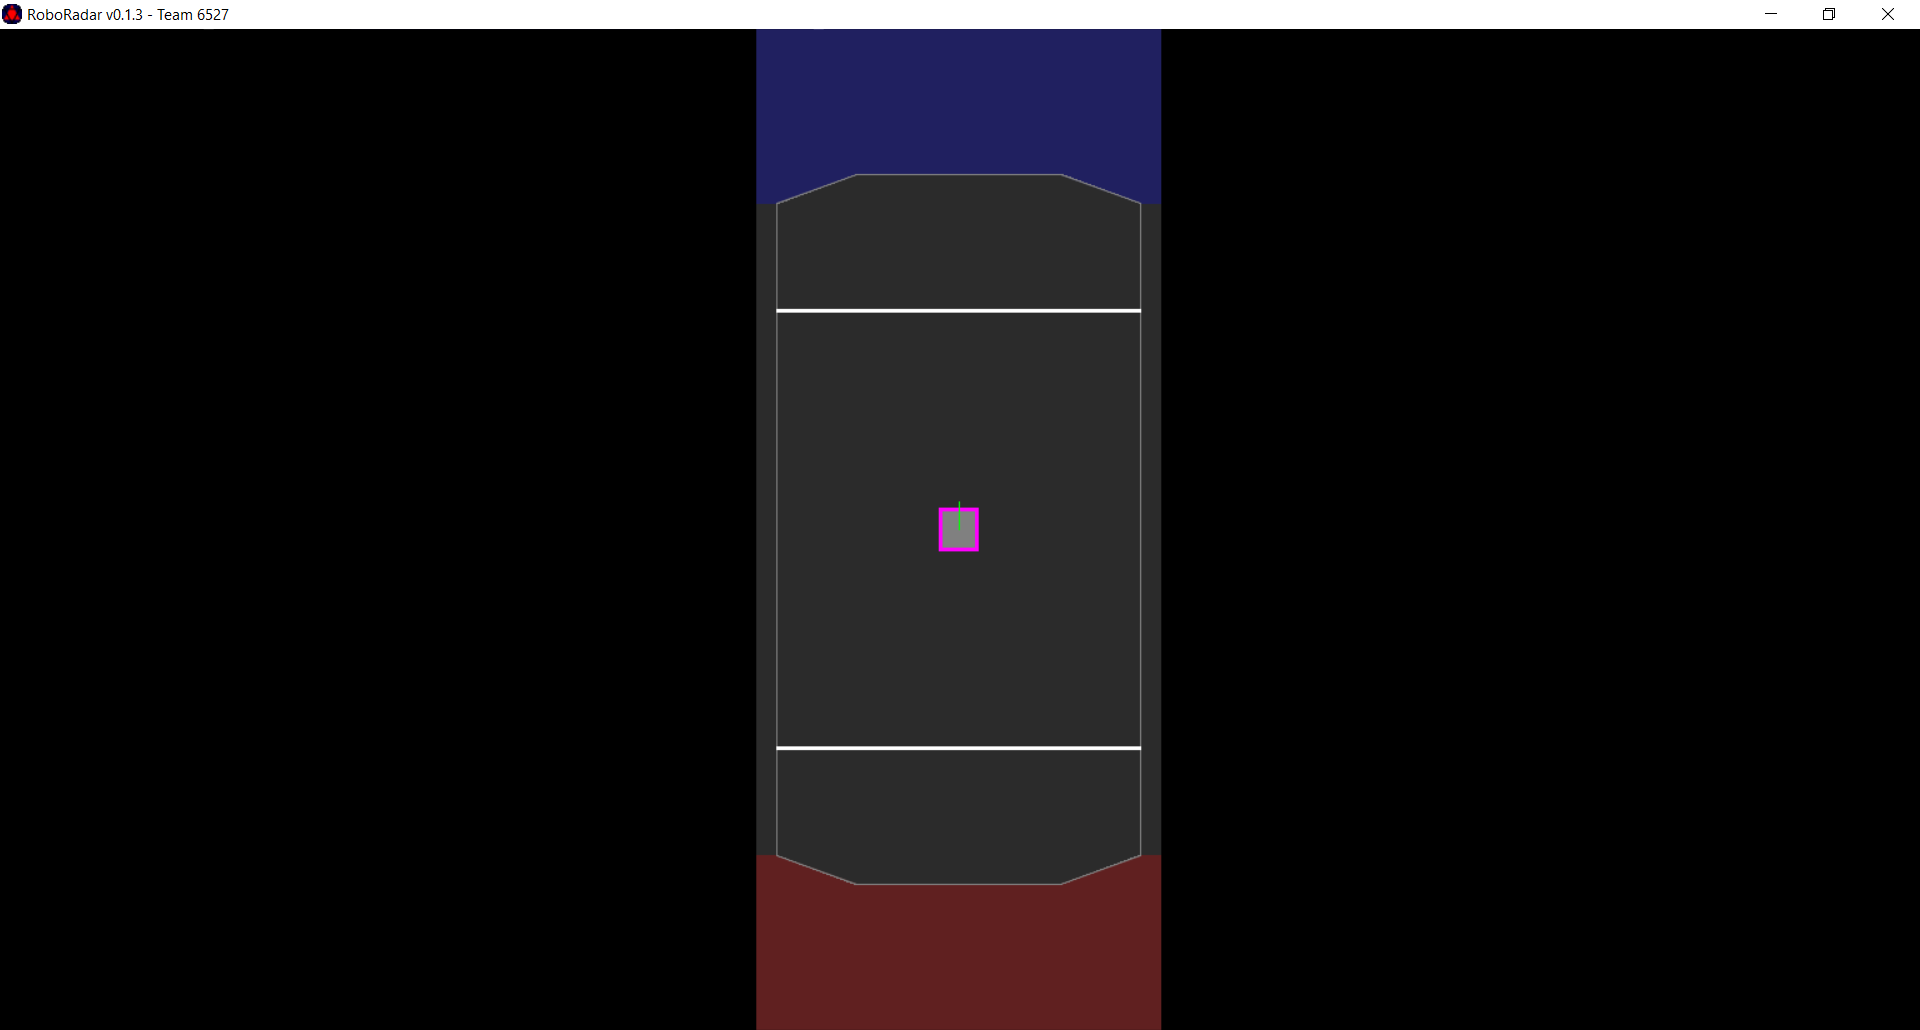
Robot position display software for FRC. This project was made to help drivers visualize where robots are located on the field using the odometry systems available in WPILIB.
Usage
After installation, there are two main ways to use the program. Independent usage is when you use the program as standalone. It will create it's own window and run as you would expect. Dependent usage is when the program is used in another program. An example would be using this as a plugin for WPILIB Shuffleboard or SmartDashboard (this is not yet implemented, but is planned).
Installation
Roboradar must be setup on both the driverstation and the robot.
Driver Station
First install python from https://www.python.org/. This has been tested with python version 3.8, however most versions after that should be compatible. After installing python run pip install roboradar in a terminal to install. Then configure the RoboRadarConfig.json. This can be done globally by editing the copy in site-packages or locally by creating a proper config file in the current working directory and starting roboradar there. Most of the defaults work fine, but you should change the team number to match your team. It is highly recommended to set the video engine to pygame in the config file. To do this, first download the most recent version via the instructions from https://www.pygame.org/wiki/GettingStarted, then change the video engine to "pygame" in the config file. To test the program run py -m roboradar.utils.dummyboxbot and py -m roboradar -l. (the L flag sets it to use localhost)
Robot
Currently, teams must send the data back to driver station manually via network tables. Java and C++ libraries are planned however. Labview support is not a priority (Submit a pull request if you get it working).
Independent Usage (running as a standalone program)
Run the command py -m roboradar. The terminal will ask for a team number if it has not been set in the config file.
If you do not want a terminal to show up, make a shortcut with the path set to pythonw -m roboradar. If you do this you MUST set the team number using the config file.
Dependent Usage (running within another program)
This will vary greatly depending on implementation. In general, you will not use a config file (it will still be used for setting default options, however). Instead, you will typically pass the data when you interface with it. (TODO: Better explanation of how to use independent)
Configuration
The RoboRadarConfig.json file is used by the program to setup operation primarily for indendent mode. A global config file is located in the package installation directory. The program will also load any file named RoboRadarConfig that is in the current working directory. This allows for local settings between different users or areas. This is a list of each configuration option, broken up by section. Each option has it's default value listed, along with a description of what the option does.
Video
Video ouput options. Most options only affect independent mode.
- ENGINE
- Default: "pygame"
- Sets the video engine to use when drawing the graphics.
- FPS
- Default: 60
- Number of FPS to run the screen at. Recommended 30, 60, or the refresh rate of the monitor.
- SCREEN_DIMENSIONS
- Default: [480,640]
- Set the starting screen width and height. The first number is width, the second is height.
- ANTIALIASING
- Default: true
- Enables or disables antialiased polygons and lines. Disable if you have performance issues.
- FILLED_POLYGONS
- Default: true
- Enable/disable filled polygons giving everything a wireframe look. Disabling is NOT RECOMMENDED.
Team
Team setting options. These will configure how it will connect to robots and display itself, among other things.
- NAME
- Default: null
- Set the team name to display. This is only a visual effect.
- NUMBER
- Default: 0
- Sets the team number to use for connecting to robots and network tables. It is highly recommended to change this before use.
Robot
Robot related options. These set up what type of robot will be used.
- NAME
- Default: null
- Name of robot type to connect to. This has yet to be implemented.
- IP_ADDRESS_FORMAT
- Default: "10.{}.{}.2"
- Format to use for the IP address. The two {} will be replaced with sections of the team number. (for example, team 6527 will become 10.65.27.2)
- IP_ADDRESS
- Default: null
- Override for the IP address. Recommended only if using a non FRC IP scheme, or connecting to the local computer.
Field
Field related options. These set up what field will be show behind the robots.
- NAME
- Default: "FRC_2020"
- Name of the field to load.
System
System related options. These change internal settings in the system.
- FORCE_RUN_AS_MODULE
- Default: true
- Forces __init__.py to be run as a module. Not really an issue when running as specified, but useful when testing in something like IDLE. This will make the program restart itself as a module.
Documentation
Documentation is currently being worked on, however in the meantime feel free to read the code.
1 maintainer

Metadata
1 maintainer
Release files for roboradar 0.3.0
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | Provenance | Actions |
|---|---|---|---|---|
| roboradar-0.3.0.tar.gz | 21.6 kB | Without provenance | Details for roboradar-0.3.0.tar.gz |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Actions Reset |
|---|---|---|---|---|
| roboradar-0.3.0-py3-none-any.whl | Python 3 | none | any | Details for roboradar-0.3.0-py3-none-any.whl |
Total release size: 54.7 kB
Release files / roboradar-0.3.0.tar.gz
| Download URL | roboradar-0.3.0.tar.gz |
|---|---|
| Size | 21.6 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
3d64519450fbdff01a2012f81bbef318bdf5cb6b9092c183e727f6dd1490c9dd
|
|
BLAKE2b-256 checksum How to use checksums |
39c006a570b3a0d04a76586b00789a52d43f64559b7adb24656b994ada54c102
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/3.1.1 pkginfo/1.5.0.1 requests/2.22.0 setuptools/41.2.0 requests-toolbelt/0.9.1 tqdm/4.40.0 CPython/3.8.0
|
Release files / roboradar-0.3.0-py3-none-any.whl
| Download URL | roboradar-0.3.0-py3-none-any.whl |
|---|---|
| Size | 33.1 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
2421e3fe8a1634b0289fb5a06d82f6f0e524ca166a012a16ca18cfaa3467029c
|
|
BLAKE2b-256 checksum How to use checksums |
af5af9a894b32cc5f3cd0982a13192f62ef08443d0654d001212709d2608461b
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/3.1.1 pkginfo/1.5.0.1 requests/2.22.0 setuptools/41.2.0 requests-toolbelt/0.9.1 tqdm/4.40.0 CPython/3.8.0
|
Security for roboradar 0.3.0
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
No provenance found
None of the files in this release were uploaded with provenance metadata.
A note on package security
PyPI is a repository for distributing packages, not a service for auditing them. While third-party security researchers and our staff do their best to detect and remove malicious packages, PyPI cannot guarantee the quality, security or suitability of any given package.
To learn more about protecting yourself from malicious actors, visit our package security documentation.














