
Learning Collision-free and Torque-limited Robot Trajectories based on Alternative Safe Behaviors


This python package provides the code to learn torque-limited and collision-free robot trajectories without exceeding limits on the position, velocity, acceleration and jerk of each robot joint.
Installation
The package can be installed by running
pip install safemotions  # for safe trajectory generation only or
pip install safemotions[train]  # to include dependencies required to train and evaluate neural networks.
Trajectory generation 
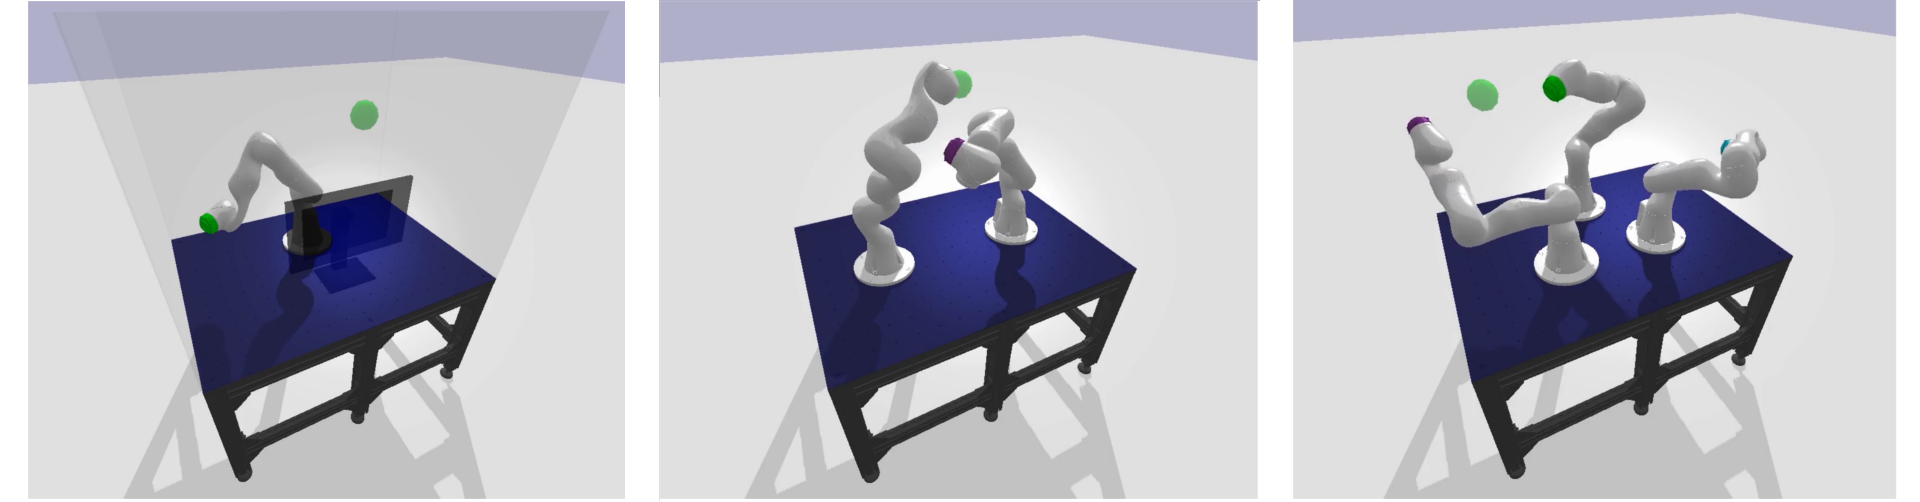
To generate a random trajectory with a single robot run
python -m safemotions.random_agent --use_gui --check_braking_trajectory_collisions --check_braking_trajectory_torque_limits --torque_limit_factor=0.6 --plot_trajectory
For a demonstration scenario with two robots run
python -m safemotions.random_agent --use_gui --check_braking_trajectory_collisions --robot_scene=1
Collision-free trajectories for three robots can be generated by running
python -m safemotions.random_agent --use_gui --check_braking_trajectory_collisions --robot_scene=2
Pretrained networks
Various pretrained networks for reaching randomly sampled target points are provided.
Make sure you use ray==1.4.1 to open the pretrained networks.
Industrial robots
To generate and plot trajectories for a reaching task with a single industrial robot run
python -m safemotions.evaluate --use_gui --plot_trajectory --plot_actual_torques --checkpoint=industrial/one_robot/collision
Trajectories for two and three industrial robots with alternating target points can be generated by running
python -m safemotions.evaluate --use_gui --checkpoint=industrial/two_robots/collision/alternating
and
python -m safemotions.evaluate --use_gui --checkpoint=industrial/three_robots/collision/alternating
Humanoid robots
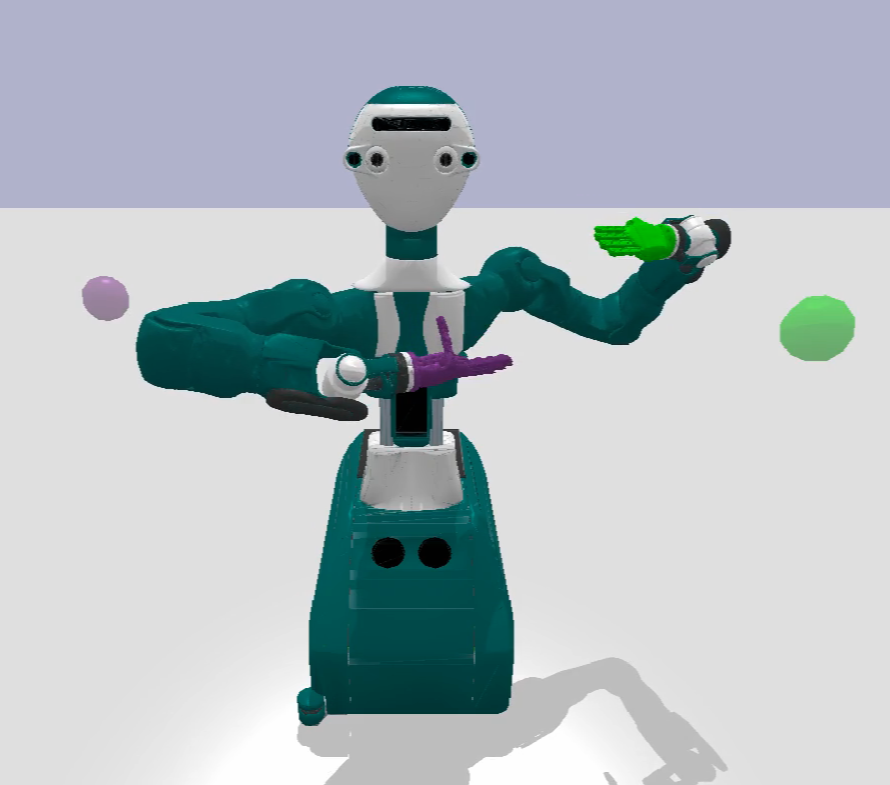
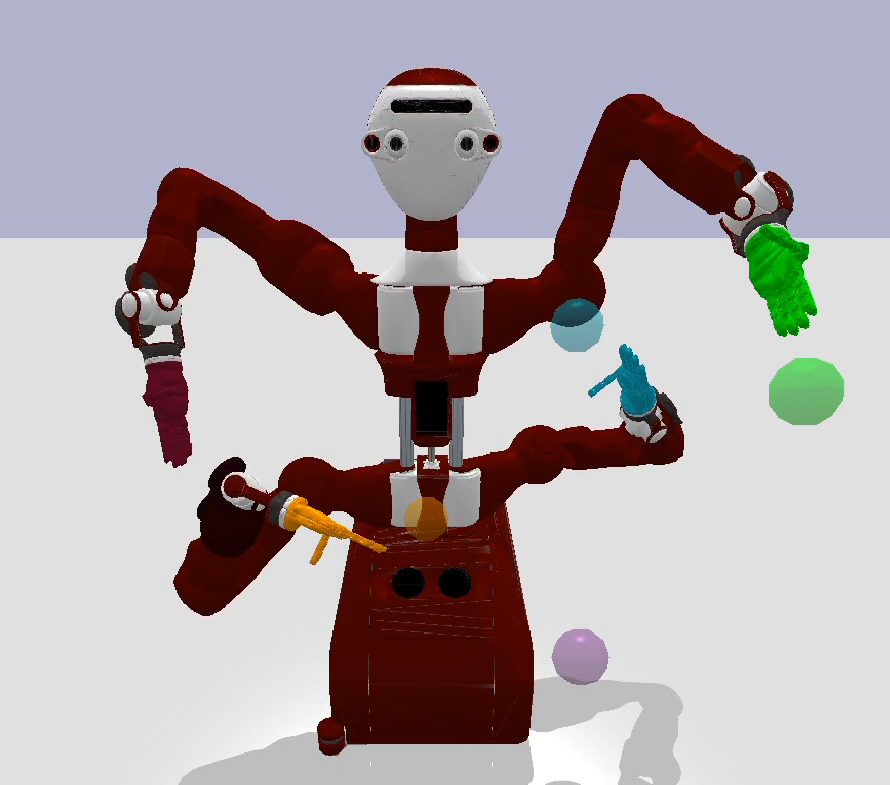
| ARMAR 6 | ARMAR 6x4 | |
|---|---|---|
 |
 |
|
| Alternating target points | --checkpoint=humanoid/armar6/collision/alternating | --checkpoint=humanoid/armar6_x4/collision/alternating |
| Simultaneous target points | --checkpoint=humanoid/armar6/collision/simultaneous | --checkpoint=humanoid/armar6_x4/collision/simultaneous |
| Single target point | --checkpoint=humanoid/armar6/collision/single | --checkpoint=humanoid/armar6_x4/collision/single |
Training
Networks can also be trained from scratch. For instance, a reaching task with a single robot can be learned by running
python -m safemotions.train --logdir=safemotions_training --name=industrial_one_robot_collision --robot_scene=0 --online_trajectory_time_step=0.1 --hidden_layer_activation=swish --online_trajectory_duration=8.0 --obstacle_scene=3 --use_target_points --target_point_sequence=0 --target_point_cartesian_range_scene=0 --target_link_offset="[0, 0, 0.126]" --target_point_radius=0.065 --obs_add_target_point_pos --obs_add_target_point_relative_pos --check_braking_trajectory_collisions --closest_point_safety_distance=0.01 --acc_limit_factor_braking=1.0 --jerk_limit_factor_braking=1.0 --punish_action --action_punishment_min_threshold=0.95 --action_max_punishment=0.4 --target_point_reached_reward_bonus=5 --pos_limit_factor=1.0 --vel_limit_factor=1.0 --acc_limit_factor=1.0 --jerk_limit_factor=1.0 --torque_limit_factor=1.0 --punish_braking_trajectory_min_distance --braking_trajectory_min_distance_max_threshold=0.05 --braking_trajectory_max_punishment=0.5 --last_layer_activation=tanh --solver_iterations=50 --normalize_reward_to_initial_target_point_distance --collision_check_time=0.033 --iterations_per_checkpoint=50 --time=200
Publication
The corresponding publication is available at https://arxiv.org/abs/2103.03793.
Disclaimer
THE SOFTWARE IS PROVIDED "AS IS", WITHOUT WARRANTY OF ANY KIND, EXPRESS OR IMPLIED, INCLUDING BUT NOT LIMITED TO THE WARRANTIES OF MERCHANTABILITY, FITNESS FOR A PARTICULAR PURPOSE AND NONINFRINGEMENT. IN NO EVENT SHALL THE AUTHORS OR COPYRIGHT HOLDERS BE LIABLE FOR ANY CLAIM, DAMAGES OR OTHER LIABILITY, WHETHER IN AN ACTION OF CONTRACT, TORT OR OTHERWISE, ARISING FROM, OUT OF OR IN CONNECTION WITH THE SOFTWARE OR THE USE OR OTHER DEALINGS IN THE SOFTWARE.
1 maintainer

Metadata
1 maintainer
Release files for safemotions 1.0.1
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| safemotions-1.0.1-py3-none-any.whl | Python 3 | none | any | Details |
Release files / safemotions-1.0.1-py3-none-any.whl
| Download URL | safemotions-1.0.1-py3-none-any.whl |
|---|---|
| Size | 16.8 MB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
7966693c8b6ce9040158c53bb47801fe19be6603207f6a1e44ff66f96cee6463
|
|
BLAKE2b-256 checksum How to use checksums |
7d699886ee8cc999450b6851290432be6e0e6b6dffb9cdae53b28af91fcc3fda
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/3.4.1 importlib_metadata/3.10.0 pkginfo/1.7.0 requests/2.25.1 requests-toolbelt/0.9.1 tqdm/4.59.0 CPython/3.8.8
|














