
SphereSnap
A quick and easy to use library for reprojecting various image types. (inspired by http://paulbourke.net/panorama/sphere2persp/ ).
The module will use CuPy if detected for accelerating computation. The library can be use simply for reprojecting from one format to another but
also for more sophisticated usecases of manipulating parts of the image or polygons.
Examples and usecases
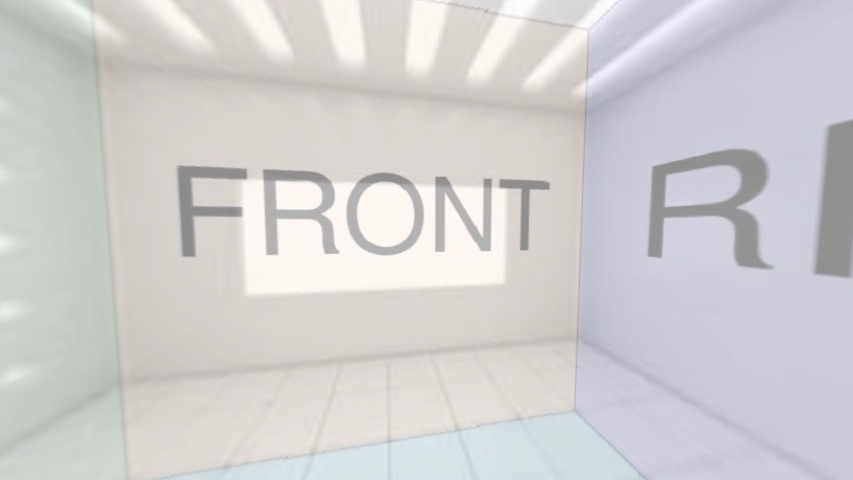
Reprojecting equirectangular image into pinhole-camera images with customizable FoV and resolution
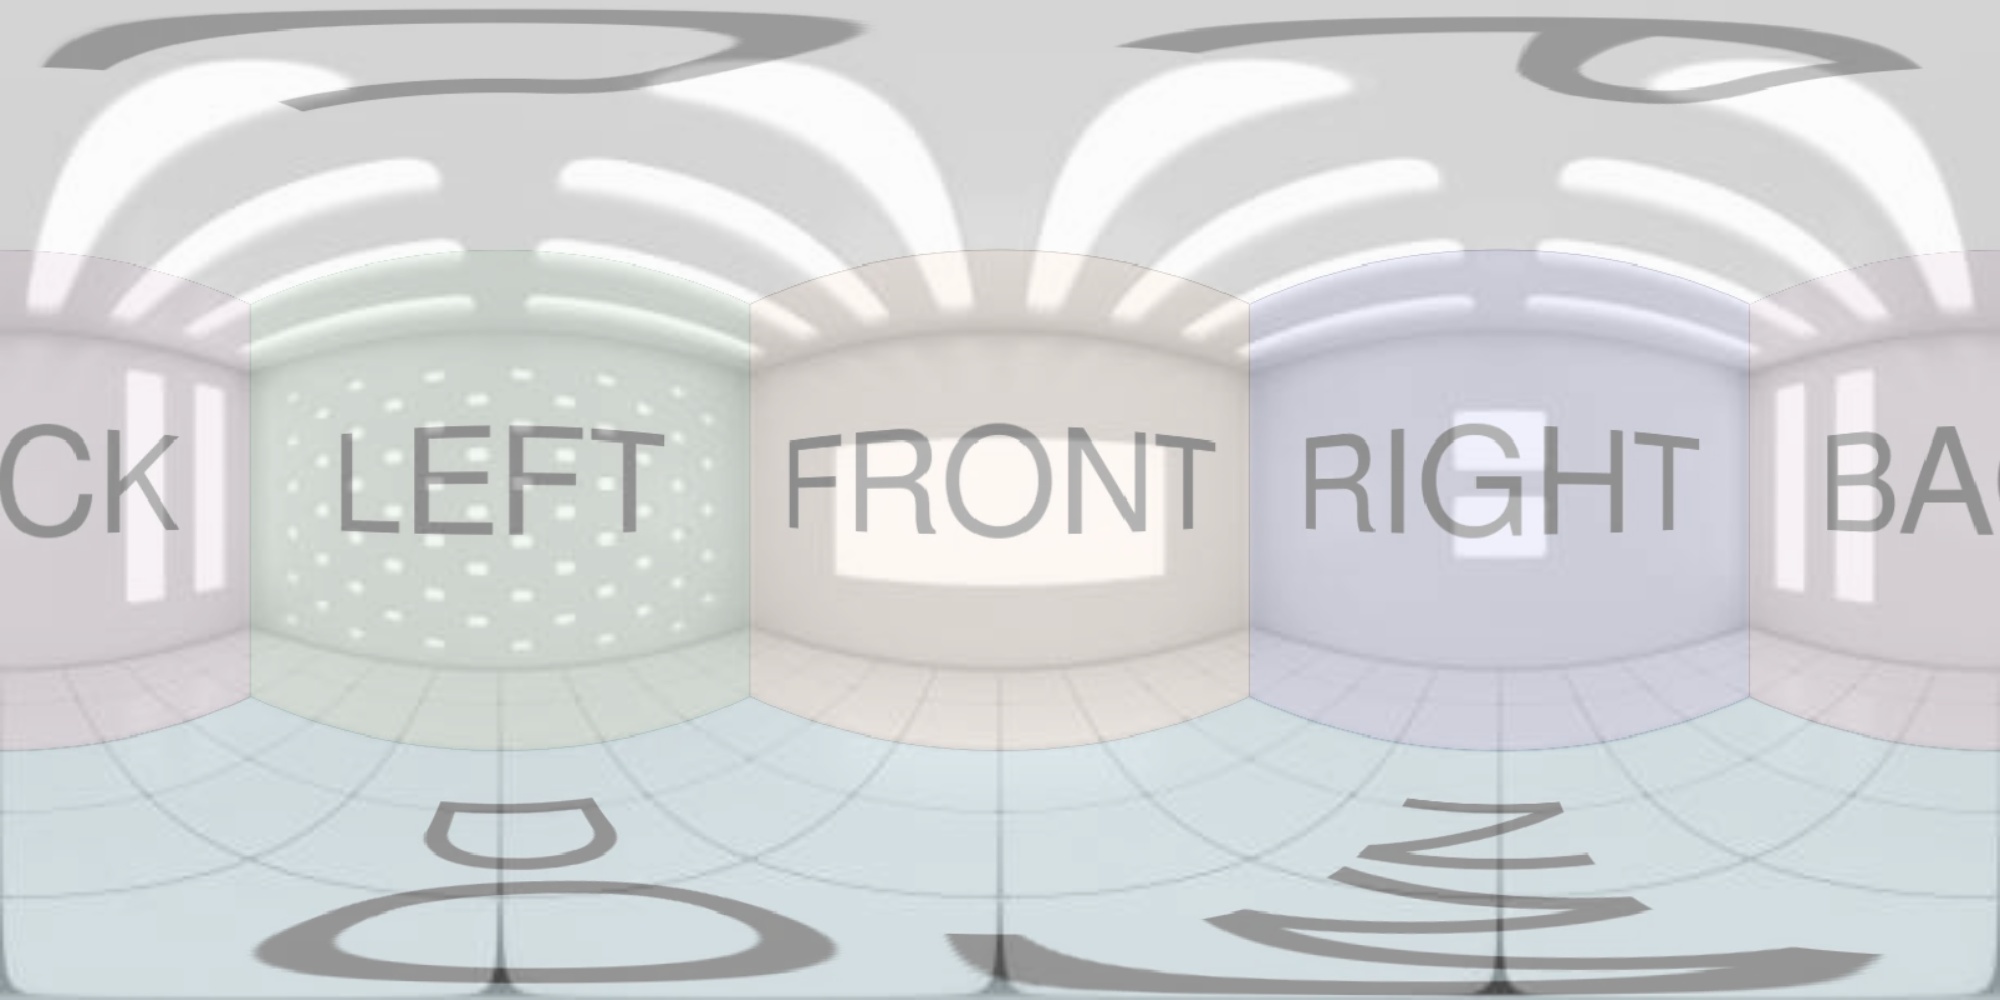
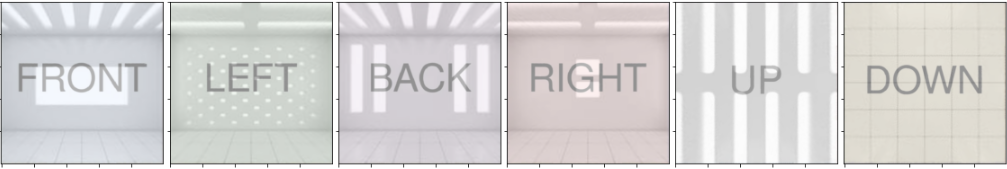
Create equirectangular image using cubemap faces
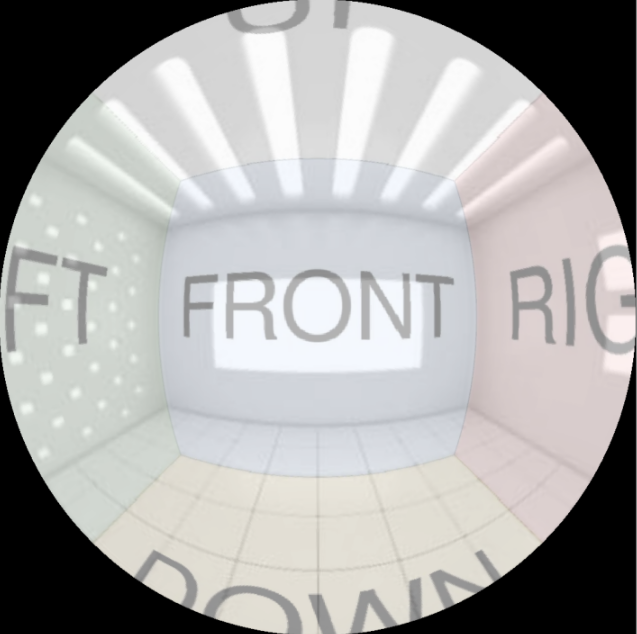
Create fisheye images from equirectangular or cubemap images
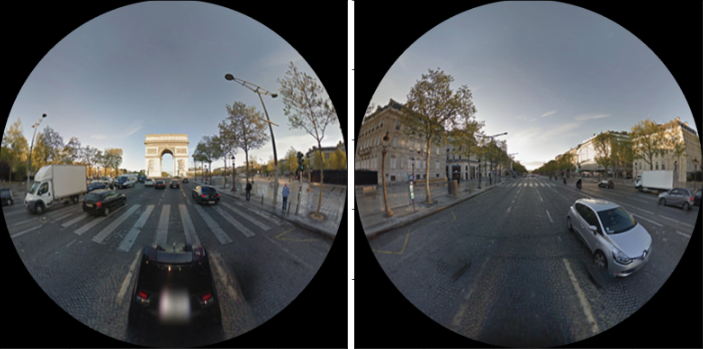
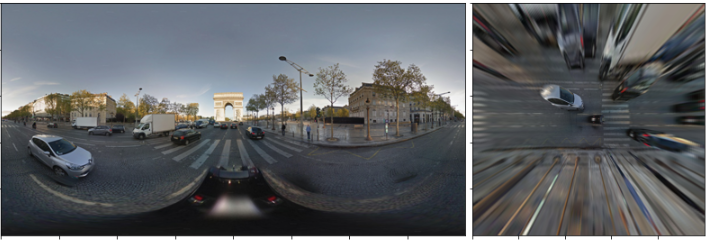
Create top view images from equirectangular/fisheye/planar images
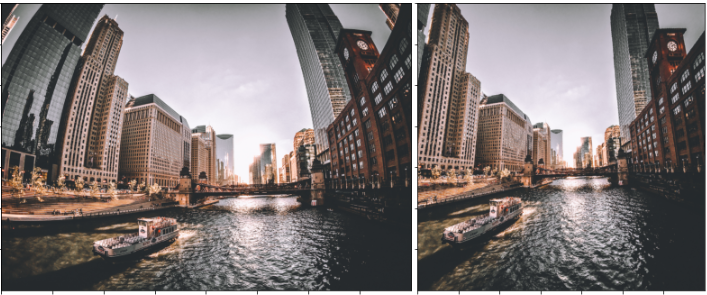
Correct radially distorted images
How to use it
Module sphere_snap.reprojections contains easy to use functions for simple situations:
- equi2cubemap
- cubemap2equi
- cubemap2fisheye
- equi2fisheye
- fisheye2equi
- equi2tv
For more complex situtation SphereSnaper can be used which is more flexible
import sphere_snap.utils as snap_utils
import sphere_snap.sphere_coor_projections as sphere_proj
from sphere_snap.snap_config import SnapConfig, ImageProjectionType
from sphere_snap.sphere_snap import SphereSnap
import sphere_snap.reprojections as rpr
Snap to perspective from equirectangular
snap_config = SnapConfig( [0,0,0,1], (1400,1400),(120,120), equi_photo.shape[:2], source_img_type=ImageProjectionType.EQUI)
snap_test = SphereSnap(snap_config)
persp_img = snap_test.snap_to_perspective(equi_photo)
Reproject equirectangular into 6 planar images of 90 degrees FoV (Cubemap)
def get_cube_map_faces(face_size=1440, source_img_hw=(2000,4000), source_img_type=ImageProjectionType.EQUI):

    snap_configs = [SnapConfig( rot(90*i,0), (face_size,face_size),(90,90), source_img_hw, source_img_type=source_img_type)
                        for i in range(4)]
    # top
    snap_configs.append(SnapConfig( rot(0,90), (face_size,face_size),(90,90), source_img_hw, source_img_type=source_img_type))
    # bottom
    snap_configs.append(SnapConfig( rot(0,-90), (face_size,face_size),(90,90), source_img_hw, source_img_type=source_img_type))
    return snap_configs

cube_configs = get_cube_map_faces(face_size=1440, source_img_hw=equi_img.shape[:2])
cube_faces_snaps = [SphereSnap(c) for c in cube_configs]
cumbe_faces_imgs = [snap.snap_to_perspective(equi_img) for snap in cube_faces_snaps]
or
cube_faces_imgs = rpr.equi2cubemap(equi_img)
Reproject a planar image into equirectangular
reconstructed_equi = SphereSnap.merge_multiple_snaps((1000,2000),
                                                     cube_faces_snaps, # snap object specifies destination position
                                                     cumbe_faces_imgs[::-1], # snap image contains planar image pixels
                                                     target_type=ImageProjectionType.EQUI, # destination image type
                                                     merge_method="max")
Reproject a planar image into fisheye 180
reconstructed_fisheye = SphereSnap.merge_multiple_snaps((1000,1000),
                                                    cube_faces_snaps, # snap object specifies destination position
                                                    cumbe_faces_imgs, # snap image contains planar image pixels
                                                    target_type=ImageProjectionType.FISHEYE_180, # destination image type
                                                    merge_method="max")
Snap to perspective from fisheye 180
snap_config = SnapConfig( rot(45,1), (1400,1400),(100,100), reconstructed_fisheye.shape[:2], source_img_type=ImageProjectionType.FISHEYE_180)
snap_test = SphereSnap(snap_config)
persp_img = snap_test.snap_to_perspective(reconstructed_fisheye)
Reproject fisheye 180 to equirectangular
snap_configs = [SnapConfig( rot(yaw,pitch), (800,800),(90,90), fisheye180_img.shape[:2], source_img_type=ImageProjectionType.FISHEYE_180)
                    for yaw,pitch in [[-45,-45],[45,-45],[-45,45],[45,45],[0,0]]]
snaps = [SphereSnap(c) for c in snap_configs]
snap_imgs = [snap.snap_to_perspective(fisheye180_img) for snap in snaps]

reconstructed_equi = SphereSnap.merge_multiple_snaps((1000,2000),
                                                     snaps, # snap object specifies destination position
                                                     snap_imgs, # snap image contains planar image pixels
                                                     target_type=ImageProjectionType.EQUI, # destination image type
                                                     merge_method="max")
1 maintainer

Metadata
1 maintainer
Release files for sphere-snap 1.0.3
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Actions Reset |
|---|---|---|---|---|
| sphere_snap-1.0.3-py3-none-any.whl | Python 3 | none | any | Details for sphere_snap-1.0.3-py3-none-any.whl |
Release files / sphere_snap-1.0.3-py3-none-any.whl
| Download URL | sphere_snap-1.0.3-py3-none-any.whl |
|---|---|
| Size | 24.6 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
4bd31241499aa3aa42699b5181f42a226dc0ff5d3f0614599da0c3eef41026a9
|
|
BLAKE2b-256 checksum How to use checksums |
e7861c51930884199f59b68cd52ed650b64ab2327f963e1e5b3bd13652be9718
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/4.0.2 CPython/3.9.5
|
Security for sphere-snap 1.0.3
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
No provenance found
None of the files in this release were uploaded with provenance metadata.
A note on package security
PyPI is a repository for distributing packages, not a service for auditing them. While third-party security researchers and our staff do their best to detect and remove malicious packages, PyPI cannot guarantee the quality, security or suitability of any given package.
To learn more about protecting yourself from malicious actors, visit our package security documentation.














