
tinyik
tinyik is a simple and naive inverse kinematics solver.
It defines the actuator as a set of links and revolute joints from an origin. Here is the example of a robot arm that consists of two joints that rotate around z-axis and two links of 1.0 length along x-axis:
>>> import tinyik
>>> arm = tinyik.Actuator(['z', [1., 0., 0.], 'z', [1., 0., 0.]])
Since the joint angles are zero by default, the end-effector position is at (2.0, 0, 0):
>>> arm.angles
array([ 0.,  0.])
>>> arm.ee
array([ 2.,  0.,  0.])
Sets the joint angles to 30 and 60 degrees to calculate a new position of the end-effector:
>>> import numpy as np
>>> arm.angles = [np.pi / 6, np.pi / 3]  # or np.deg2rad([30, 60])
>>> arm.ee
array([ 0.8660254,  1.5      ,  0.       ])
Sets a position of the end-effector to calculate the joint angles:
>>> arm.ee = [2 / np.sqrt(2), 2 / np.sqrt(2), 0.]
>>> arm.angles
array([  7.85398147e-01,   3.23715739e-08])
>>> np.round(np.rad2deg(arm.angles))
array([ 45.,   0.])
Optionally, it has the visualization feature. Passes the actuator to it to visualize its structure:
>>> leg = tinyik.Actuator([[.3, .0, .0], 'z', [.3, .0, .0], 'x', [.0, -.5, .0], 'x', [.0, -.5, .0]])
>>> leg.angles = np.deg2rad([30, 45, -90])
>>> tinyik.visualize(leg)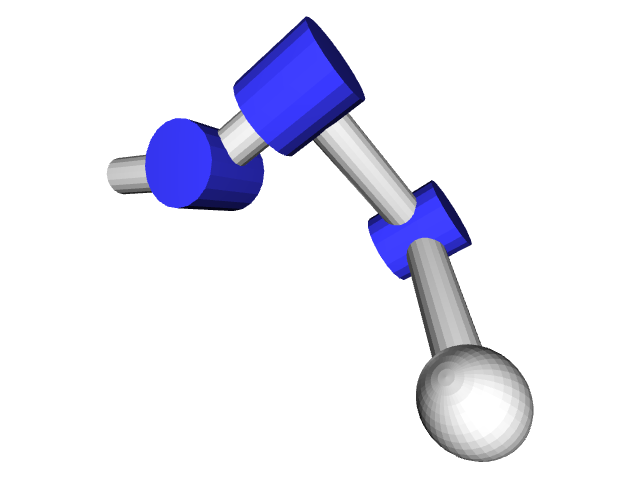
Passes with the target position, can compare before and after the IK. The gray links are before IK and the white links are after it. The red sphere is the target position:
>>> tinyik.visualize(leg, target=[.8, .0, .8])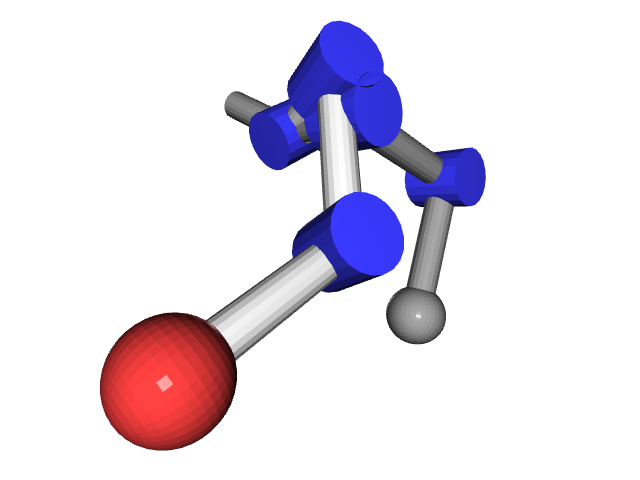
Installation
$ pip install tinyikWith the visualization feature:
$ pip install tinyik[viz]1 maintainer

Metadata
1 maintainer
Release files for tinyik 2.2.1
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | Provenance | Actions |
|---|---|---|---|---|
| tinyik-2.2.1.tar.gz | 7.8 kB | Without provenance | Details for tinyik-2.2.1.tar.gz |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Actions Reset |
|---|---|---|---|---|
| tinyik-2.2.1-py3-none-any.whl | Python 3 | none | any | Details for tinyik-2.2.1-py3-none-any.whl |
Total release size: 16.2 kB
Release files / tinyik-2.2.1.tar.gz
| Download URL | tinyik-2.2.1.tar.gz |
|---|---|
| Size | 7.8 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
a8898489afea50a5e81d790eb81adafd04d6f47e53282bcb027afe432dc10ef7
|
|
BLAKE2b-256 checksum How to use checksums |
92b23755c90a221838b1d234770ee5da696dccfc4446371c7beff84857c3d5c1
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
poetry/1.0.5 CPython/3.8.2 Windows/10
|
Release files / tinyik-2.2.1-py3-none-any.whl
| Download URL | tinyik-2.2.1-py3-none-any.whl |
|---|---|
| Size | 8.5 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
f5bb07d5eb99a98dd95d937f1d39bfb009d6cc988381ac5f98582075006dd179
|
|
BLAKE2b-256 checksum How to use checksums |
95329021c857f791ab91e470d840dd97d3567da4c1c20eeb881825fd542742b1
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
poetry/1.0.5 CPython/3.8.2 Windows/10
|
Security for tinyik 2.2.1
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
No provenance found
None of the files in this release were uploaded with provenance metadata.
A note on package security
PyPI is a repository for distributing packages, not a service for auditing them. While third-party security researchers and our staff do their best to detect and remove malicious packages, PyPI cannot guarantee the quality, security or suitability of any given package.
To learn more about protecting yourself from malicious actors, visit our package security documentation.














