
Introduction


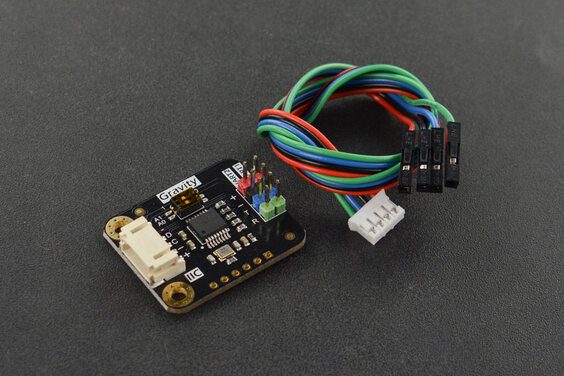
CircuitPython library for DFROBOT Gravity: I2C to Dual UART Module
Dependencies
This driver depends on:
Please ensure all dependencies are available on the CircuitPython filesystem. This is easily achieved by downloading the Adafruit library and driver bundle or individual libraries can be installed using circup.
Installing from PyPI
On supported GNU/Linux systems like the Raspberry Pi, you can install the driver locally from PyPI. To install for current user:
pip3 install CircuitPython_DFRobot_Gravity_DRF0627_I2C_Dual_UartTo install system-wide (this may be required in some cases):
sudo pip3 install CircuitPython_DFRobot_Gravity_DRF0627_I2C_Dual_UartTo install in a virtual environment in your current project:
mkdir project-name && cd project-name
python3 -m venv .env
source .env/bin/activate
pip3 install CircuitPython_DFRobot_Gravity_DRF0627_I2C_Dual_Uart
Installing to a Connected CircuitPython Device with Circup
Make sure that you have circup installed in your Python environment. Install it with the following command if necessary:
pip3 install circupWith circup installed and your CircuitPython device connected use the following command to install:
circup install CircuitPython_DFRobot_Gravity_DRF0627_I2C_Dual_UartOr the following command to update an existing version:
circup updateUsage Example
import time
import board
import CircuitPython_DFRobot_Gravity_DRF0627_I2C_Dual_Uart as DualUart

i2c = board.I2C()


iic_uart1 = DualUart.DFRobot_IIC_Serial(
    i2c,
    sub_uart_channel=DualUart.DFRobot_IIC_Serial.SUBUART_CHANNEL_1,
    IA1=1,
    IA0=1,
)

iic_uart2 = DualUart.DFRobot_IIC_Serial(
    i2c,
    sub_uart_channel=DualUart.DFRobot_IIC_Serial.SUBUART_CHANNEL_2,
    IA1=1,
    IA0=1,
)

try:
    iic_uart1.begin(baud=9600, format=iic_uart1.IIC_Serial_8N1)
    print("Opened: UART 1 ")
except Exception as e:
    iic_uart1 = None
    print("Error: Could not open UART 1 Exception: " + str(e))

try:
    iic_uart2.begin(baud=9600, format=iic_uart2.IIC_Serial_8N1)
    print("Opened: UART 2")
except Exception as e:
    iic_uart2 = None
    print("Error: Could not open UART 2 Exception: " + str(e))

sendID = 1
sendDelayCount = 1

while True:
    time.sleep(.3)
    sendDelayCount -= 1
    if sendDelayCount <= 0:
        sendDelayCount = 10
        iic_uart1.write("From1:" + str(sendID))
        iic_uart2.write("From2:" + str(sendID))

    if iic_uart1 is not None:
        if iic_uart1.available():
            s = ""
            while iic_uart1.available():
                b = iic_uart1.read(1)
                s += chr(b[0])
            print("<1:" + s + " len:" + str(len(s)) + ">")

    if iic_uart2 is not None:
        if iic_uart2.available():
            s = ""
            while iic_uart2.available():
                b = (iic_uart2.read(1))
                s += chr(b[0])
            print("<2:" + s + " len:" + str(len(s)) + ">")
Additional connection information
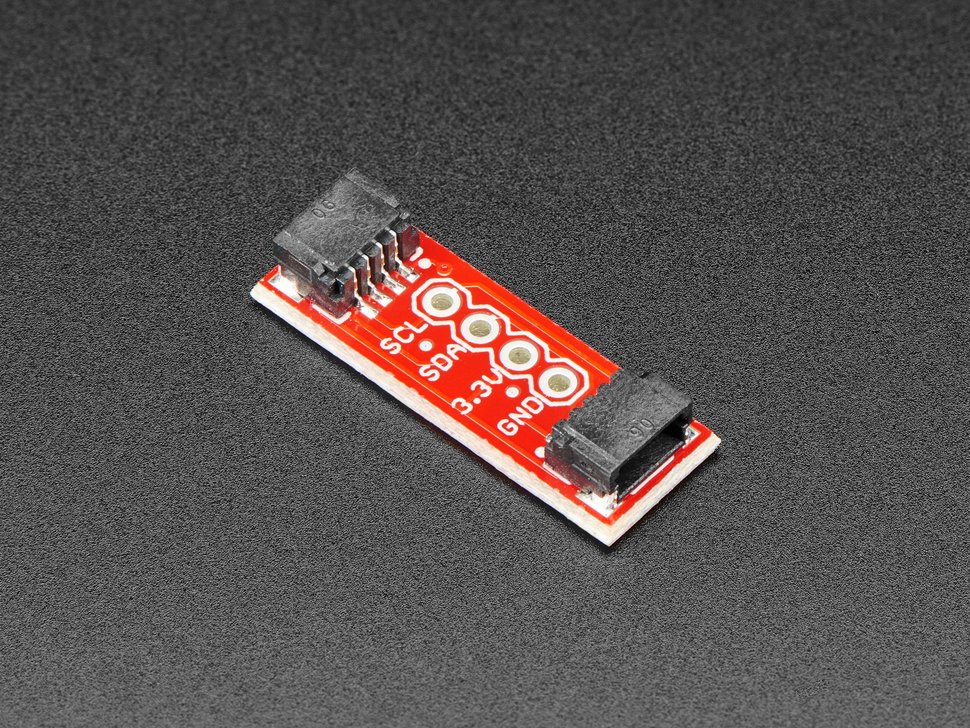
The DRF0627 comes with a cable that allows for connection to the CircuitPython hardware using a SparkFun STEMMA QT / Qwiic Breadboard Breakout Adapter Product ID: 4527 https://www.adafruit.com/product/4527
Connections:
Black wire -> Stemma Ground
Red wire -> Stemma 3.3 V
Green wire -> Stemma SDA
Blue wire -> Stemma SCA
To test the connection the “t” and “R” pins can be connected together. If you tie the “T” and “R” pins between the same UART the data will echo back to you on the same port. If you tie the “T” and “R” pins from UART1 to UART 2 data will be send between the two ports.
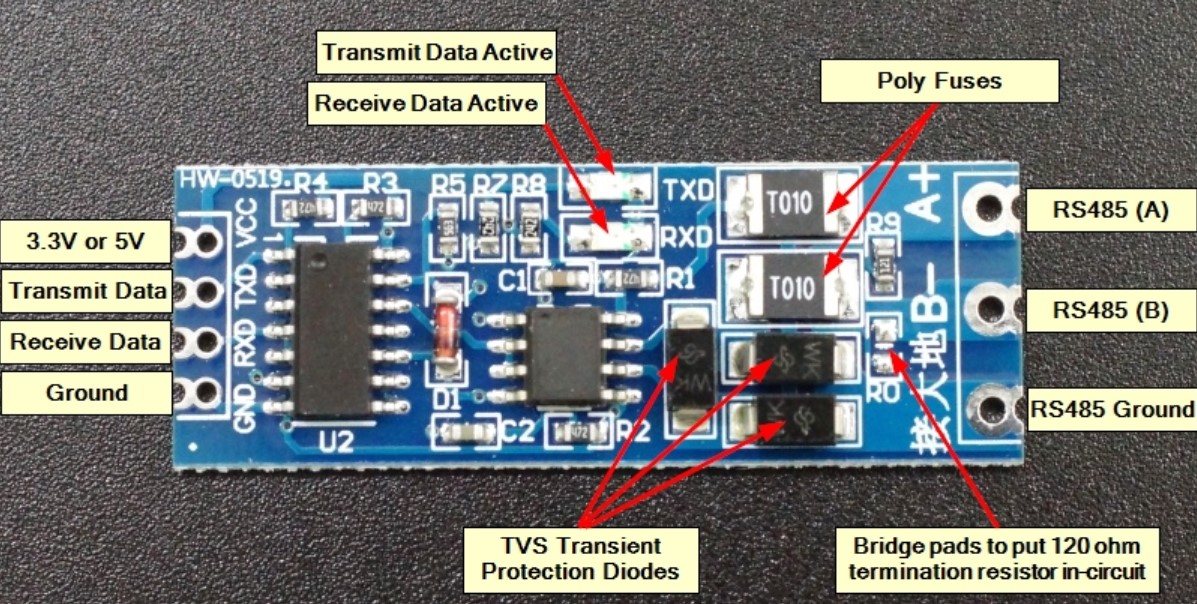
If RS485 is desired you can use a RS485 adapter such as the “SCM TTL to RS-485 Interface Module”
Documentation
API documentation for this library can be found on Read the Docs.
For information on building library documentation, please check out this guide.
Contributing
Contributions are welcome! Please read our Code of Conduct before contributing to help this project stay welcoming.
1 maintainer

Release files for circuitpython-dfrobot-gravity-drf0627-dual-uart 1.0.14
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | |
|---|---|---|---|
| circuitpython_dfrobot_gravity_drf0627_dual_uart-1.0.14.tar.gz | 34.0 kB | Details |
Release files / circuitpython_dfrobot_gravity_drf0627_dual_uart-1.0.14.tar.gz
| Download URL | circuitpython_dfrobot_gravity_drf0627_dual_uart-1.0.14.tar.gz |
|---|---|
| Size | 34.0 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
d40734332fef73b3e657d73dcfd1fc4bf30b77ec40789328cd43933cb2687b68
|
|
BLAKE2b-256 checksum How to use checksums |
14430d660606e21be9262bb33fd84f4d83f76a1e18d928f217a7e5e34f0de163
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/4.0.1 CPython/3.10.6
|














