
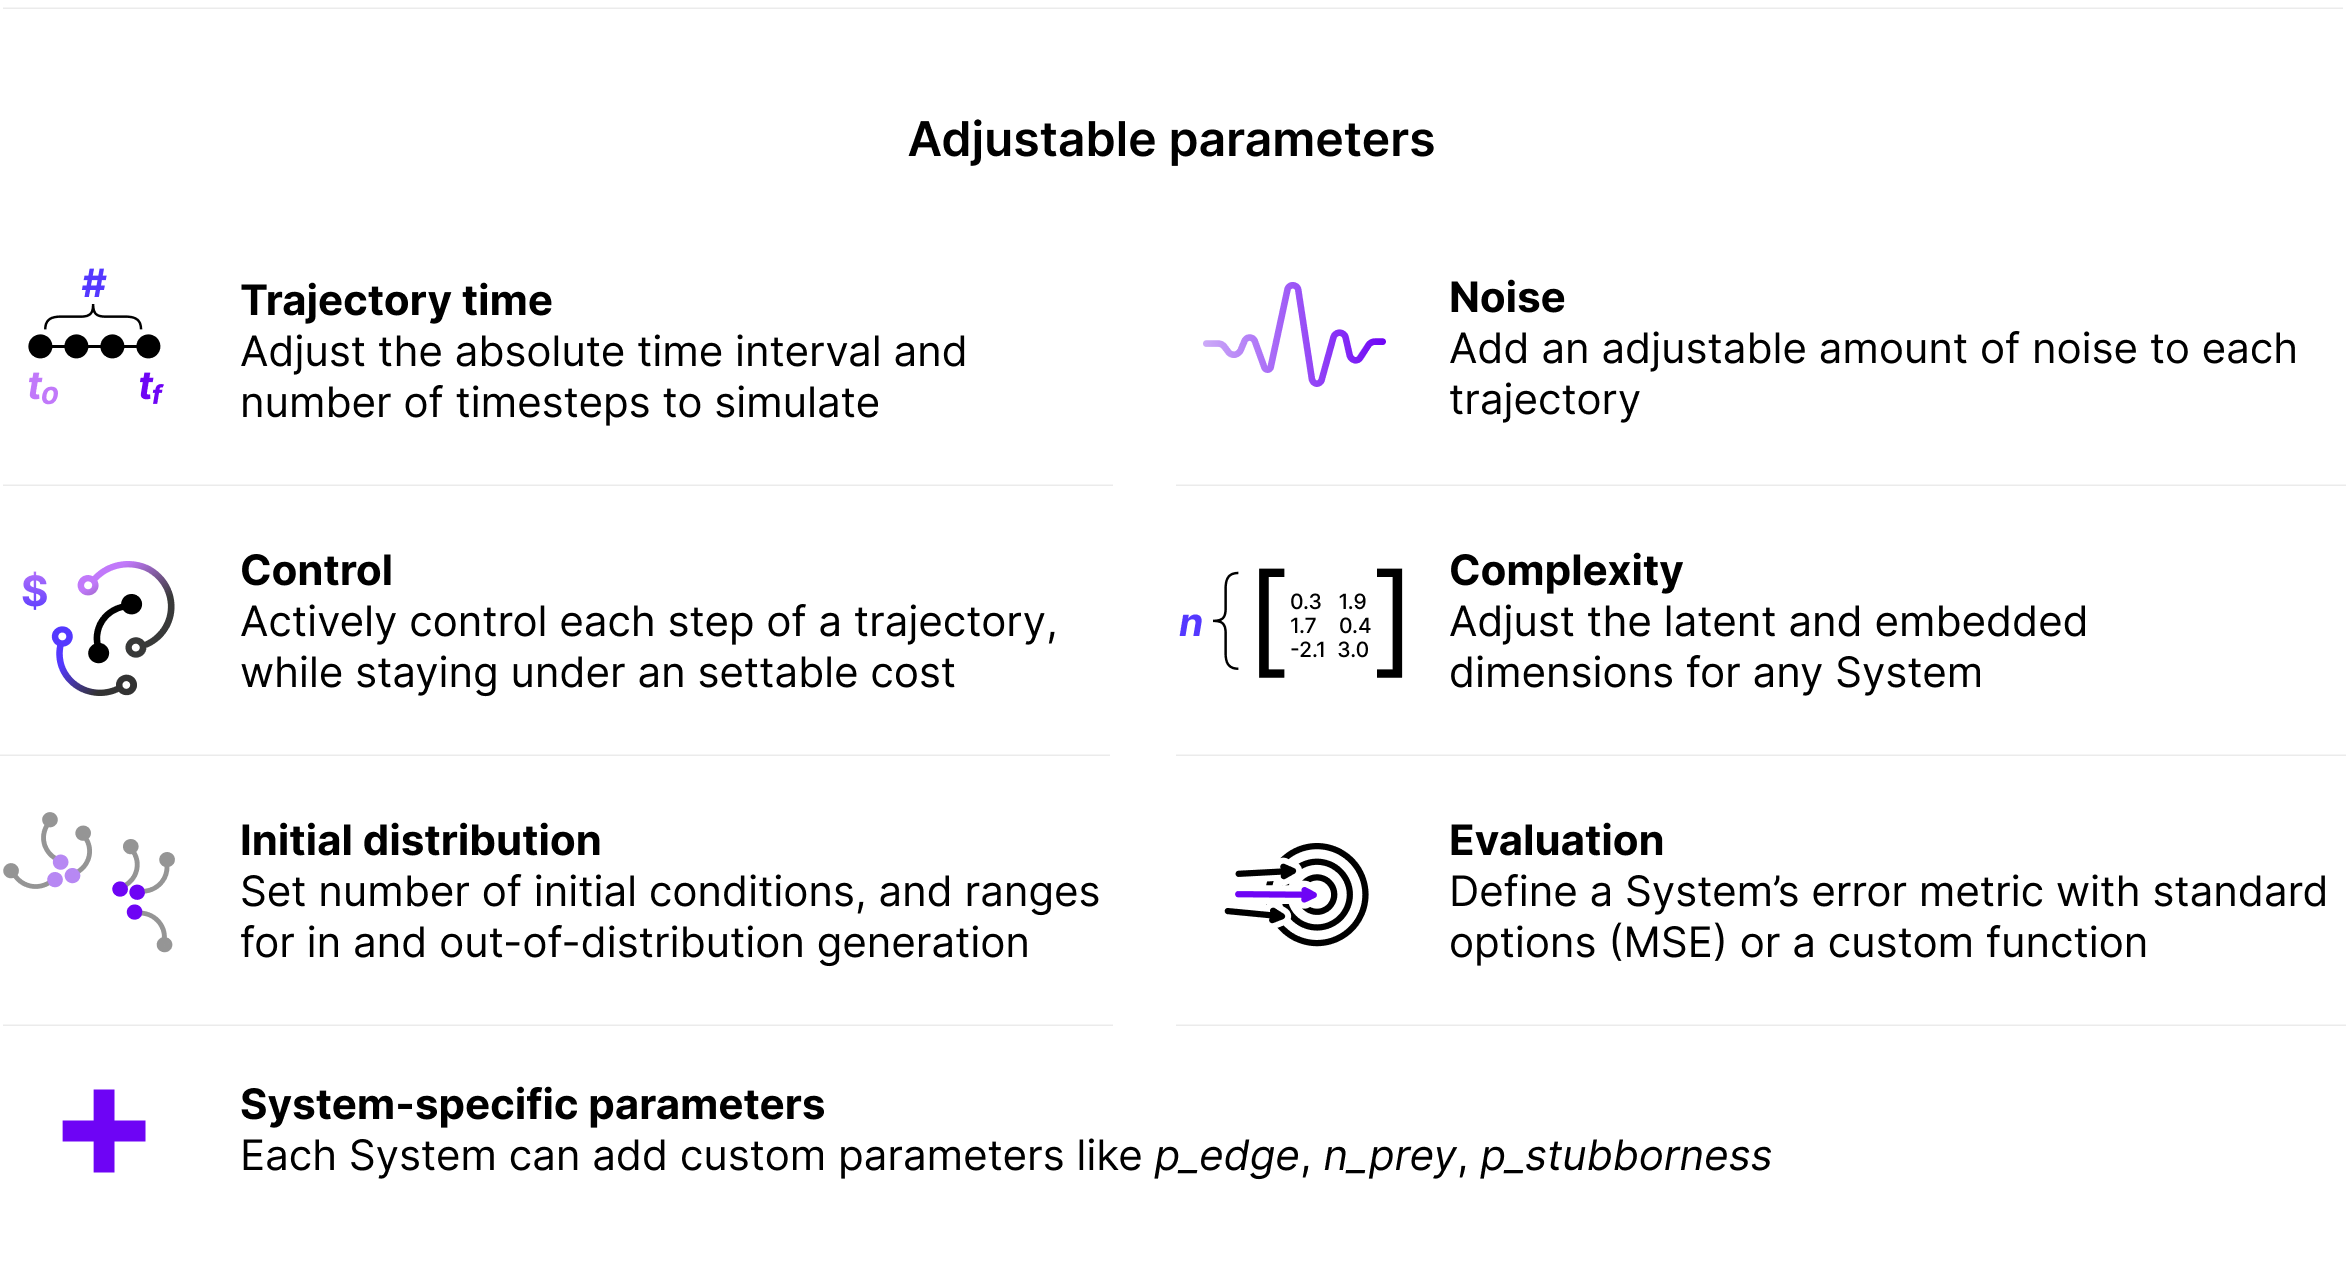
DynaDojo is a Python gym environment for testing how models generalize and efficently use samples in dynamical system idenficiation. Our platform lets you understand how a model performs as various parameters are adjusted, including tuning the complexity of the system (e.g., dimension), increasing the dataset size, changing the number of timesteps per trajectory, active learning (control), adding noise, adjusting the distribution of initial conditions, and more.
You can install DynaDojo with pip:
pip install dynadojo
Introduction
There are three ways to interact with DynaDojo and users can take on multiple "hats" at a time. You can add new dynamical Systems to the platform, create set environments for adjusting parameters in a Challenge, or implement your Model with our API to understand how it performs. Most of the platform is adjustable through various parameters in these clases.
Challenges
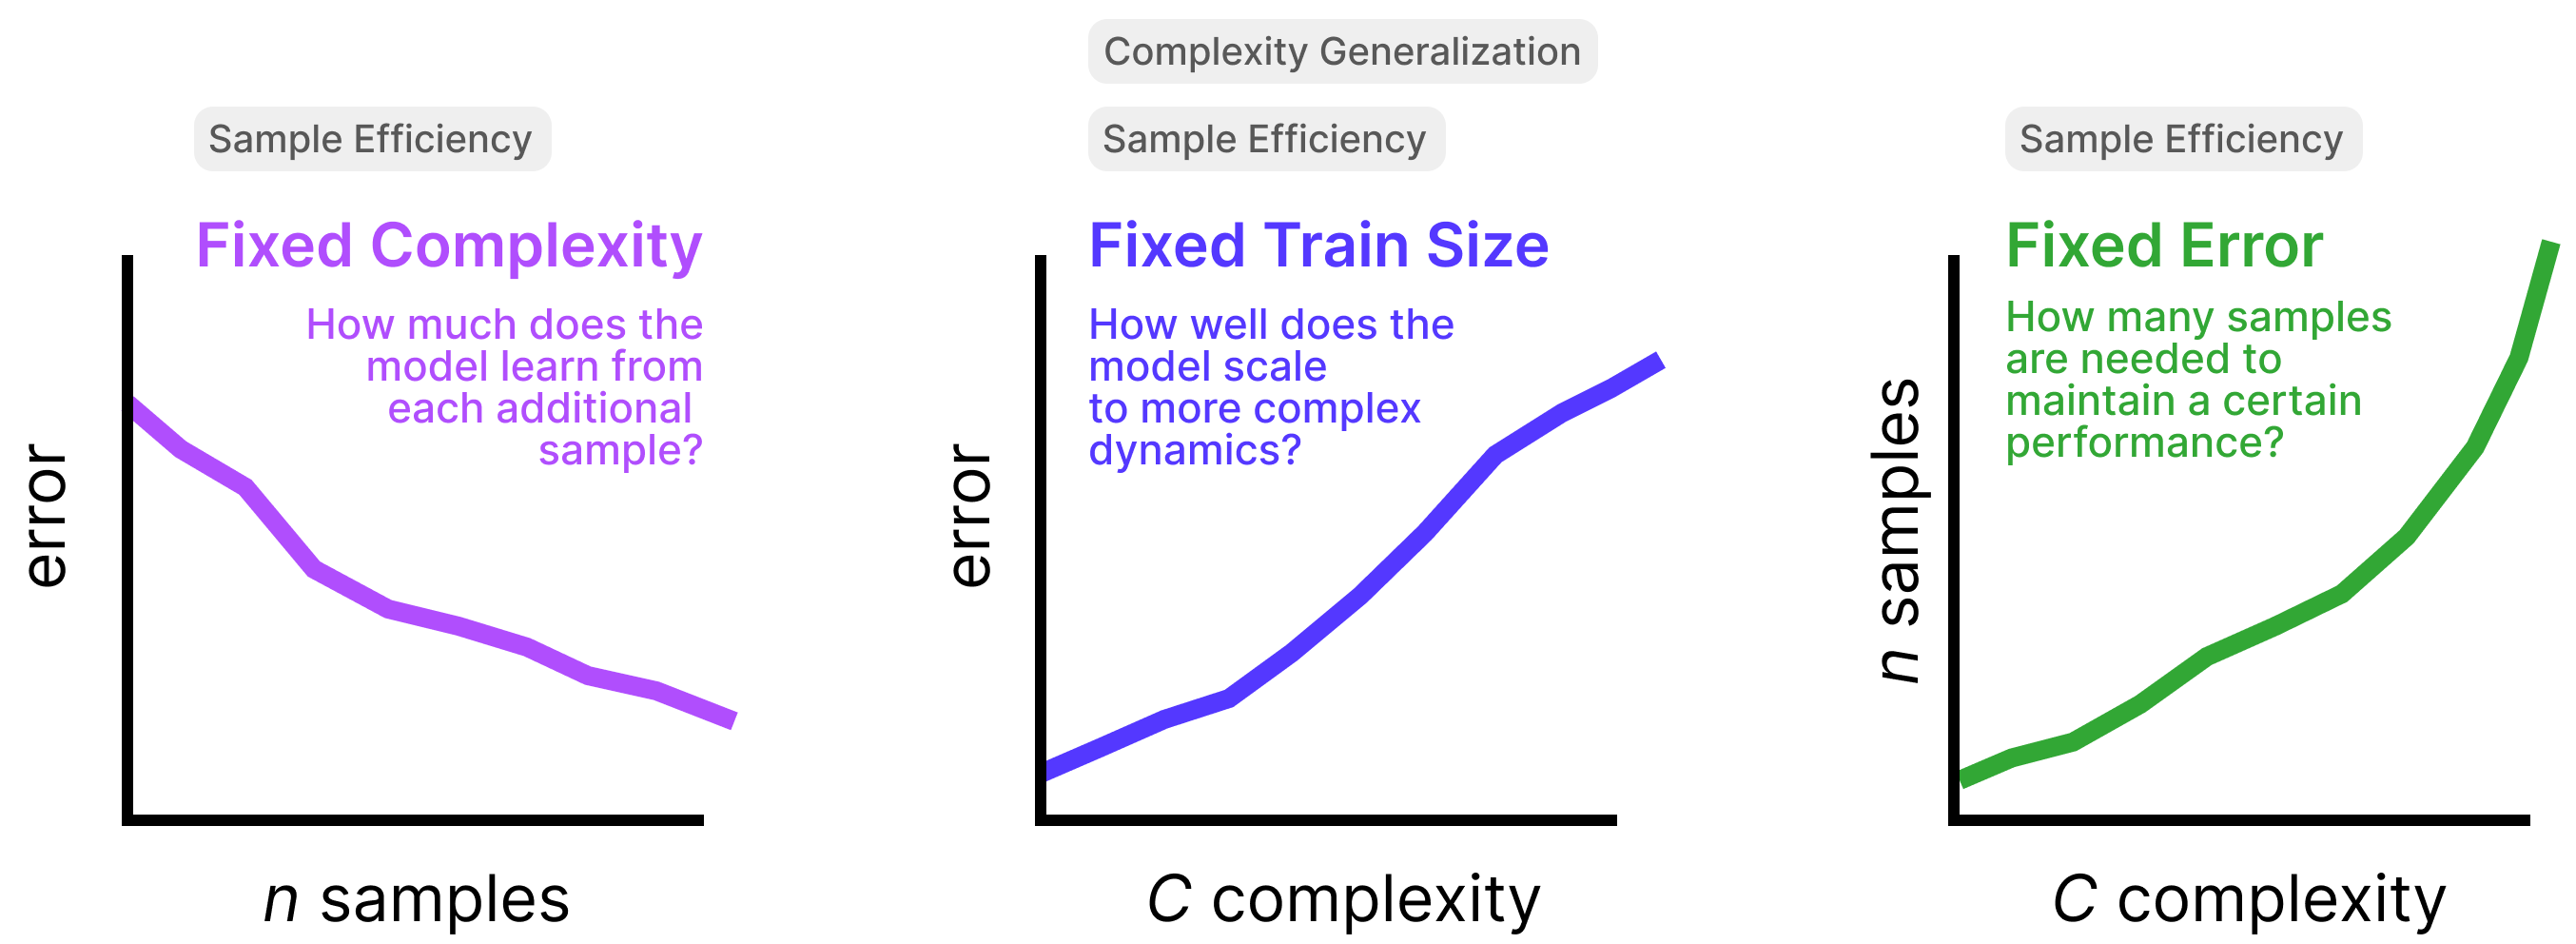
DynaDojo comes with three off-the-shelf challenges: Fixed Error, Fixed Complexity, and Fixed Train Size.
from dynadojo.systems import LDSSystem
from dynadojo.baselines import LinearRegression, DNN
from dynadojo.challenges import FixedComplexity
import pandas as pd


challenge = FixedComplexity(
    N=[10, 100, 1000],  # number of training examples
    l=3,  # latent dimension
    e=3,  # embed dimension
    t=50,  # timesteps
    control_horizons=0,
    max_control_cost_per_dim=0,
    system_cls=LDSSystem,
    reps=10,
    test_examples=50,
    test_timesteps=50,
)
data1 = challenge.evaluate(LinearRegression, id="linear regression")
data2 = challenge.evaluate(DNN, model_kwargs={"activation": "relu"}, fit_kwargs={"epochs": 20}, id="nonlinear network")
data3 = challenge.evaluate(DNN, fit_kwargs={"epochs": 20}, id="linear network")
data = pd.concat((data1, data2, data3))
challenge.plot(data)
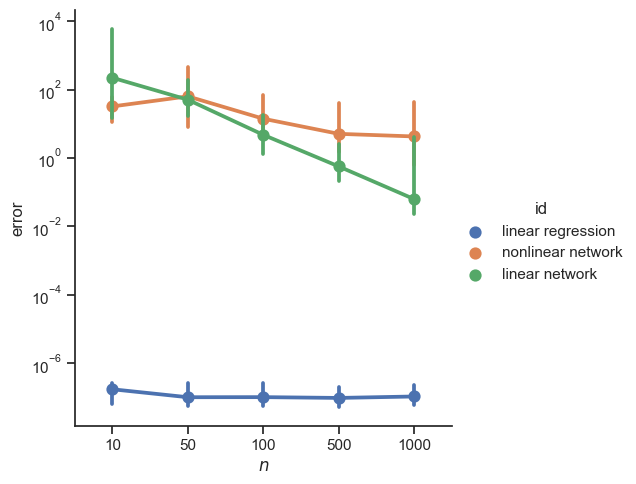
Out (Fixed Complexity, C = latent_dim = 5): Note how for this LDSSystem, a linear network learns more from each added sample (larger decreases in error) than a nonlinear network, and how linear regression immediately saturates at very low error. These dynamics help contextualize model performance and comparision.
Systems

DynaDojo comes with 20 pre-built systems (including ODEs and PDEs) that range from mature mathematic simulations, to bounded confidence opinion dynamics, biology, ecology, and epidemology:
- Cellular Automata
- Threshold Linear Networks
- N-Body Systems
- Linear Dynamical Systems (LDS)
- Generalized Lorenz
- Spiking Neural Network (SNN)
- Kuramoto N-Oscillators
- Generalized Prey-Predator
- Competitive Lotka Volterra
- Deffuant
- Algorithmic Bias with Media Influence
- Hegselmann-Krause (HK)
- Weighted Hegselmann-Krause (WHK)
- Attraction-Repulsion Weighted Hegselmann-Krause (ARWHK)
- SIR: Susceptible/Infected/Removed
- SIS: Susceptible/Infected/Susceptible
- SEIS: Susceptible/Exposed/Infected/Susceptible
- 2D Heat Equation
- Black-Scholes-Barenblatt (BSB)
- Hamilton-Jacobi-Bellman (HJB)
Adding Systems
To add new systems to DynaDojo, you subclass from AbstractSystem and implement the required functions listed below. It is easy to build a System from scratch, or to use existing packages like scipy and NDLIB and wrap them for our API.
import numpy as np

from dynadojo.abstractions import AbstractSystem


class MySystem(AbstractSystem):
    def make_init_conds(self, n: int, in_dist=True) -> np.ndarray:
        pass

    def make_data(self, init_conds: np.ndarray, control: np.ndarray, timesteps: int, noisy=False) -> np.ndarray:
        pass

    def calc_error(self, x, y) -> float:
        pass

    def calc_control_cost(self, control: np.ndarray) -> np.ndarray:
        pass

    def __init__(self, latent_dim, embed_dim):
        super().__init__(latent_dim, embed_dim)
Documentation for each of the abstract methods can be found in dynadojo/abstractions. Use tester.py to verify that your new system accurately integrates with DynaDojo.
Models
DynaDojo comes with six baseline models:
- CNN
- DMD (Schmid, Peter J., "Dynamic mode decomposition of numerical and experimental data")
- DNN
- Lowest Possible Radius (LPR)
- Linear Regression (LR)
- SINDy (Brunton, Steven L., Joshua L. Proctor, and J. Nathan Kutz., "Discovering governing equations from data by sparse identification of nonlinear dynamical systems")
Adding Models
Adding new models is simple with DynaDojo. The developer simply needs to implement two abstract methods fit and predict. A model can also optionally use control with the act method.
import numpy as np

from dynadojo.abstractions import AbstractModel


class MyModel(AbstractModel):
    def __init__(self, embed_dim: int, timesteps: int, max_control_cost: float, **kwargs):
        super().__init__(embed_dim, timesteps, max_control_cost, **kwargs)

    def fit(self, x: np.ndarray, **kwargs) -> None:
        pass

    def predict(self, x0: np.ndarray, timesteps: int, **kwargs) -> np.ndarray:
        pass

    #optional, used when control desired
    def act(self, x: np.ndarray, **kwargs) -> np.ndarray:
        pass
Examples
Example 1: Comparing DNN activations on LDS
Nonlinearity is a hallmark of modern deep learning; however, there are some exceptional tasks where linear models actually outperform nonlinear neural networks. In this example, we explore this phenomena through linear dynamical systems (LDS) and deep neural networks (DNNs).
To start, let's create some LDS data using one of DynaDojo's off-the-shelf LDSSystem.
import dynadojo as dd
import numpy as np

latent_dim = 5
embed_dim = 10
n = 5000
timesteps = 50
system = dd.systems.LDSSystem(latent_dim, embed_dim)
x0 = system.make_init_conds(n)
y0 = system.make_init_conds(30, in_dist=False)
x = system.make_data(x0, control=np.zeros((n, timesteps, embed_dim)), timesteps=timesteps)
y = system.make_data(y0, control=np.zeros((n, timesteps, embed_dim)), timesteps=timesteps)
dd.utils.lds.plot([x, y], target_dim=min(latent_dim, 3), labels=["in", "out"], max_lines=15)
In the image below, observe how the in distribution trajectories (blue) have a different evolution than the out-of-distribution trajectories (orange). A robust model should be able to predict the orange trajectories even if it's only trained on the blue ones.

Next, let's create our nonlinear model using DynaDojo's baseline DNN class.
nonlinear_model = dd.baselines.DNN(embed_dim, timesteps, activation="tanh", max_control_cost=0)
nonlinear_model.fit(x, epochs=10, verbose='auto')
x_pred = nonlinear_model.predict(x[:, 0], 50)
y_pred = nonlinear_model.predict(y[:, 0], 50)
dd.utils.lds.plot([x_pred, y_pred], target_dim=min(3, latent_dim), labels=["in pred", "out pred"], max_lines=15)
x_err = system.calc_error(x, x_pred)
y_err = system.calc_error(y, y_pred)
print(f"{x_err=}")
print(f"{y_err=}")
Out:
x_err=203.1404201824185
y_err=346.67112531011145
As we can see, the model performs pretty badly. With 10 epochs of training, it struggles to predict both the in and out-of-distribution trajectories!

Next, let's try DNN with a linear activation.
linear_model = dd.baselines.DNN(embed_dim, timesteps, activation=None, max_control_cost=0)
linear_model.fit(x, epochs=10, verbose='auto')
x_pred = linear_model.predict(x[:, 0], 50)
y_pred = linear_model.predict(y[:, 0], 50)
dd.utils.lds.plot([x_pred, y_pred], target_dim=min(3, latent_dim), labels=["in pred", "out pred"], max_lines=15)
x_err = system.calc_error(x, x_pred)
y_err = system.calc_error(y, y_pred)
print(f"{x_err=}")
print(f"{y_err=}")
Out:
x_err=21.46598299085367
y_err=243.8198349312669
As we can see, the linear model does much better! This is because linear models learn linear dynamics faster.

Citing
License
This software is made available under the terms of the MIT license. See LICENSE for details.
The external dependencies used by this software are available under a variety of different licenses. Review these external licenses before using the software.
3 maintainers


Metadata
3 maintainers
Release files for dynadojo 0.2.6
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | Provenance | Actions |
|---|---|---|---|---|
| dynadojo-0.2.6.tar.gz | 4.6 MB | Without provenance | Details for dynadojo-0.2.6.tar.gz |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Actions Reset |
|---|---|---|---|---|
| dynadojo-0.2.6-py2.py3-none-any.whl | Python 3, Python 2 | none | any | Details for dynadojo-0.2.6-py2.py3-none-any.whl |
Total release size: 4.7 MB
Release files / dynadojo-0.2.6.tar.gz
| Download URL | dynadojo-0.2.6.tar.gz |
|---|---|
| Size | 4.6 MB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
4c952cffd3258581cb581fb3a0dd669f7d98f4e45ed2bf00cdc394f36805fa80
|
|
BLAKE2b-256 checksum How to use checksums |
13c84135d614c363dcac1757d763db63cecd4ba89ed0735e22c869a00dd0def5
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
python-requests/2.29.0
|
Release files / dynadojo-0.2.6-py2.py3-none-any.whl
| Download URL | dynadojo-0.2.6-py2.py3-none-any.whl |
|---|---|
| Size | 51.3 kB |
| Tags | Python 2 Python 3 |
|
SHA-256 checksum How to use checksums |
3508de0b2b6a7c0ede2ac3f36a1ae5df9b8bf1004d16dc57ef410f7e638432fd
|
|
BLAKE2b-256 checksum How to use checksums |
ea78e77e626061061ca56049871970512921a7ebcd0bd50cd63e86e87514880a
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
python-requests/2.29.0
|
Security for dynadojo 0.2.6
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
No provenance found
None of the files in this release were uploaded with provenance metadata.
A note on package security
PyPI is a repository for distributing packages, not a service for auditing them. While third-party security researchers and our staff do their best to detect and remove malicious packages, PyPI cannot guarantee the quality, security or suitability of any given package.
To learn more about protecting yourself from malicious actors, visit our package security documentation.














