
Probabilistic Mission Design
Resin reasoning · ProMis mission design · CoFi tracking · CoCo control
This repository implements Probabilistic Mission Design (ProMis). ProMis enables users to formalize their knowledge of local rules, such as traffic regulations, to constrain an agent's actions and movements. To achieve this, we employ probabilistic first-order logic, a mathematical framework that combines formal reasoning with probabilistic inference. The rules are written in Resin, a reactive probabilistic logic language whose syntax and semantics are described in its language reference. Using ProMis, scalar fields of the probability of adhering to the agent's constitution are obtained across its state space.
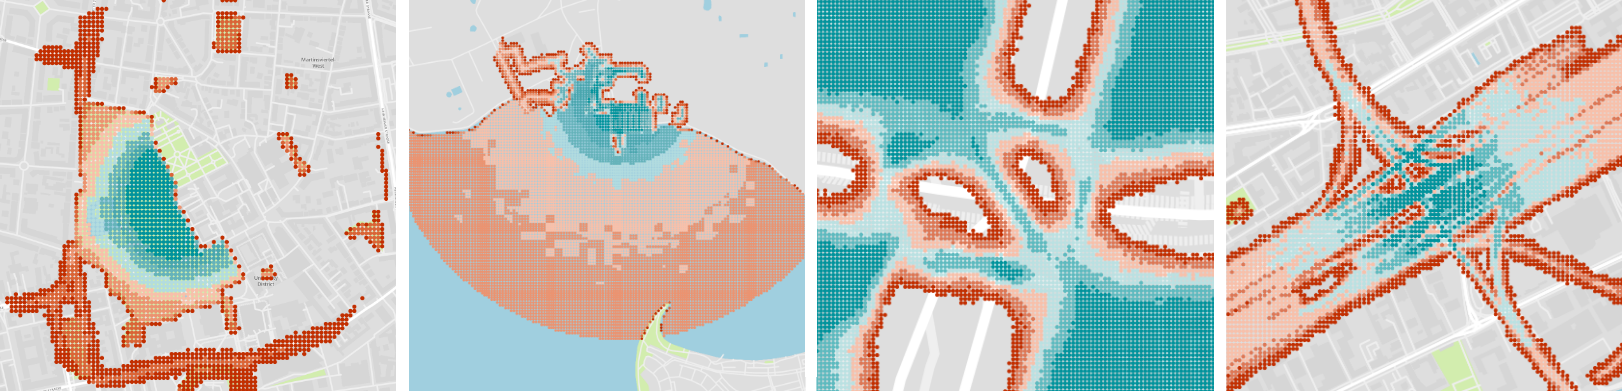
Building on these landscapes, we further provide CoFi, which tracks agents that are expected to follow their constitution, and CoCo, steering agents to comply with it. The following shows ProMis being applied in a diverse set of scenarios, with a high probability of satisfying all flight restrictions being shown in blue, a low probability being shown in red, and unsuitable spaces being transparent.
Installation & Usage
To install ProMis, please follow the instructions here. For an in-depth walkthrough on applying ProMis in your own applications, you can check our usage guide. An interactive version of the usage guide is also available.
Documentation
ProMis' documentation is available online. It can also be built locally with the following commands.
git clone
pip install ".[doc]"

mkdir -p doc/source/notebooks
cp examples/*.ipynb doc/source/notebooks
sphinx-build -b html doc/source _build/html
To view the documentation, open the file ProMis/doc/build/html/index.html using the browser of your choice.
Contributing
This project is set up to be checked and formatted with ruff check and ruff format.
Use pytest to run automated tests.
License
Copyright (c) 2023 Simon Kohaut, Honda Research Institute Europe GmbH, Felix Divo, and contributors. See LICENSE.md for details.
Citation
If you use ProMis, please cite the paper below.
@ARTICLE{11193664,
  author={Kohaut, Simon and Flade, Benedict and Ochs, Daniel and Dhami, Devendra Singh and Eggert, Julian and Kersting, Kristian},
  journal={IEEE Transactions on Intelligent Transportation Systems},
  title={Probabilistic Mission Design for Neuro-Symbolic Unmanned Aircraft Systems},
  year={2025},
  volume={26},
  number={12},
  pages={22751-22760},
  doi={10.1109/TITS.2025.3609835}
}
You may further be interested in consulting the following accompanying works:
- Mission Design for Unmanned Aerial Vehicles using Hybrid Probabilistic Logic Programs. Simon Kohaut, Benedict Flade, Devendra Singh Dhami, Julian Eggert, Kristian Kersting. In Proceedings of the 26th IEEE International Intelligent Transportation Systems Conference (ITSC).
- StaR Maps: Unveiling Uncertainty in Geospatial Relations. Benedict Flade, Simon Kohaut, Devendra Singh Dhami, Kristian Kersting. In Proceedings of the 27th IEEE International Intelligent Transportation Systems Conference (ITSC).
- Hybrid Many-Objective Optimization in Probabilistic Mission Design for Compliant and Effective UAV Routing. Simon Kohaut, Nikolas Hohmann, Sebastian Brulin, Benedict Flade, Julian Eggert, Markus Olhofer, Jürgen Adamy, Devendra Dhami, Kristian Kersting. In the ACM Journal on Autonomous Transportation Systems (JATS).
- Towards Probabilistic Clearance, Explanation and Optimization. Simon Kohaut, Benedict Flade, Devendra Singh Dhami, Julian Eggert, Kristian Kersting. In Proceedings of the 2024 IEEE International Conference on Unmanned Aircraft Systems (ICUAS).
1 maintainer

Metadata
1 maintainer
Release files for promis 4.0.0
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | Provenance | Actions |
|---|---|---|---|---|
| promis-4.0.0.tar.gz | 911.9 kB | With provenance | Details for promis-4.0.0.tar.gz |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Actions Reset |
|---|---|---|---|---|
| promis-4.0.0-py3-none-any.whl | Python 3 | none | any | Details for promis-4.0.0-py3-none-any.whl |
Total release size: 1.9 MB
Release files / promis-4.0.0.tar.gz
| Download URL | promis-4.0.0.tar.gz |
|---|---|
| Size | 911.9 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
1536b241006abdbc3d8ac52df84c1d3f4560d4f07d2abbf26db24c84f7bf53ac
|
|
BLAKE2b-256 checksum How to use checksums |
c401a387bae12578a97f3f0a0cf7cdb6625c285dcf4d098fbf188a2d115261d1
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.16
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.


PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Oct 29, 2026.
Transparency logRelease files / promis-4.0.0-py3-none-any.whl
| Download URL | promis-4.0.0-py3-none-any.whl |
|---|---|
| Size | 947.0 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
a4c4dc7ccced237d3cee5b480e13fec88a467671f075d67764cf06e69d27c75c
|
|
BLAKE2b-256 checksum How to use checksums |
d699aed55038cd02815aa0447e6d3259cfb946223c927058f75ce33080440c3f
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.16
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Oct 29, 2026.
Transparency logSecurity for promis 4.0.0
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
Full provenance
All 2 files in this release have been uploaded with provenance metadata.
Attestation for promis-4.0.0.tar.gz
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Oct 29, 2026.
Transparency logA note on package security
PyPI is a repository for distributing packages, not a service for auditing them. While third-party security researchers and our staff do their best to detect and remove malicious packages, PyPI cannot guarantee the quality, security or suitability of any given package.
To learn more about protecting yourself from malicious actors, visit our package security documentation.














