sr.robot3


Student Robotics API for Python 3
This package uses PEP420-style namespace packaging.
Development
Requirements
This project uses the Poetry dependency and virtualenv manager.
You will also need:
- Python 3.6+
- Make
Setup
- Clone the repository from GitHub to a folder on your local machine
cdto that folder, and tell Poetry to install dependencies and set up a virtualenvpoetry install- You can now enter the virtual environment using
poetry shelland develop using your IDE of choice.
Tests
The full type, test and lint suite can be run using make: make.
You can also run parts of the suite.
- Unit tests:
make test - Unit tests with HTML coverage:
make test-cov - Linting:
make lint - Static type checks:
make type
Adding camera calibrations
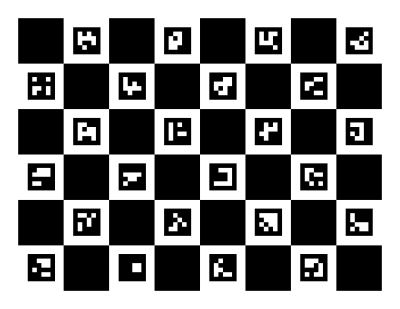
You will need to print off a chAruco marker grid.
opencv_interactive-calibration -t=charuco -sz=GRID_SIZE
Replace GRID_SIZE with the length of one of the larger squares (in mm) from the printed marker grid.
Use -ci=1 for specifying camera index if multiple cameras are connected.
Point the camera at the marker grid. Until DF is at or below 30 then press S to save.
This will output a cameraParameters.xml file. Place this file in sr/robot3/vision/calibrations named by the camera model.
You will need to add a detection strategy for the camera in to sr/robot3/vision/backend.py.
Contributions
This project is released under the MIT Licence. For more information, please see LICENSE.
The CONTRIBUTORS file can be generated by executing CONTRIBUTORS.gen. This generated file contains a list of people who have contributed to sr.robot3.


Release files for sr-robot3 2023.0.0.post1
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | Provenance | Actions |
|---|---|---|---|---|
| sr.robot3-2023.0.0.post1.tar.gz | 15.7 kB | Without provenance | Details for sr.robot3-2023.0.0.post1.tar.gz |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Actions Reset |
|---|---|---|---|---|
| sr.robot3-2023.0.0.post1-py3-none-any.whl | Python 3 | none | any | Details for sr.robot3-2023.0.0.post1-py3-none-any.whl |
Total release size: 36.1 kB
Release files / sr.robot3-2023.0.0.post1.tar.gz
| Download URL | sr.robot3-2023.0.0.post1.tar.gz |
|---|---|
| Size | 15.7 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
5e7384ab3fabbba7193376d5add5c0ec6abe2b04f5cf20189a8f145026247c71
|
|
BLAKE2b-256 checksum How to use checksums |
dd978173af2cda5a8e3c5389083378d3d839c64c53a5f5b0488c512c99a2b5f7
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
poetry/1.1.15 CPython/3.10.6 Darwin/21.6.0
|
Release files / sr.robot3-2023.0.0.post1-py3-none-any.whl
| Download URL | sr.robot3-2023.0.0.post1-py3-none-any.whl |
|---|---|
| Size | 20.4 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
d56b21adc8801537d3df08e7e00b87889a69affe4d39543fcd29d5fd2b509a08
|
|
BLAKE2b-256 checksum How to use checksums |
578a626d87592e8d9ced2f519512a4b1586ca7b153a15696e15555fefbd3e43d
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
poetry/1.1.15 CPython/3.10.6 Darwin/21.6.0
|
Security for sr-robot3 2023.0.0.post1
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
No provenance found
None of the files in this release were uploaded with provenance metadata.
A note on package security
PyPI is a repository for distributing packages, not a service for auditing them. While third-party security researchers and our staff do their best to detect and remove malicious packages, PyPI cannot guarantee the quality, security or suitability of any given package.
To learn more about protecting yourself from malicious actors, visit our package security documentation.