
strix-halo-jax

Run JAX and MuJoCo MJX (robotics simulation, e.g. MuJoCo Playground) on the GPU of an
AMD Ryzen AI MAX ("Strix Halo", Ryzen AI MAX+ 395, Radeon 8060S, gfx1151) from pip wheels —
no system ROCm install — and jaxcheck, a hang-safe check that tells you which wheel set works
on your machine: GPU devices, matmul, scatters, MJX reset and step, each in its own process.
Useful if you searched for "Backend 'rocm' is not in the list of known backends", JAX ROCm gfx1151, MJX on AMD, HSA_STATUS_ERROR_MEMORY_APERTURE_VIOLATION or Strix Halo machine learning.
Demo
jaxcheck on a Ryzen AI MAX+ 395 with the recipe below — every stage passes, including the
MuJoCo MJX ones (evidence):
$ jaxcheck --label "jax-0.11.1 PyPI plugin + rocm[libraries] 7.13.0, no env vars"
jax-0.11.1 PyPI plugin + rocm[libraries] 7.13.0, no env vars devices       ok           3.0s
jax-0.11.1 PyPI plugin + rocm[libraries] 7.13.0, no env vars matmul        ok          15.0s
jax-0.11.1 PyPI plugin + rocm[libraries] 7.13.0, no env vars scatter_set   ok           3.5s
jax-0.11.1 PyPI plugin + rocm[libraries] 7.13.0, no env vars scatter_add   ok           4.0s
jax-0.11.1 PyPI plugin + rocm[libraries] 7.13.0, no env vars scatter_2d    ok           4.0s
jax-0.11.1 PyPI plugin + rocm[libraries] 7.13.0, no env vars scatter_vmap  ok           4.0s
jax-0.11.1 PyPI plugin + rocm[libraries] 7.13.0, no env vars scatter_oob   ok           4.0s
jax-0.11.1 PyPI plugin + rocm[libraries] 7.13.0, no env vars mjx_reset     ok          49.1s
jax-0.11.1 PyPI plugin + rocm[libraries] 7.13.0, no env vars mjx_step      ok         101.6s
A broken set shows up in seconds as fault or fail, instead of a process that hangs for half an
hour. What it is for — a humanoid walking policy trained on this machine with MuJoCo Playground
(humanoid-companion):
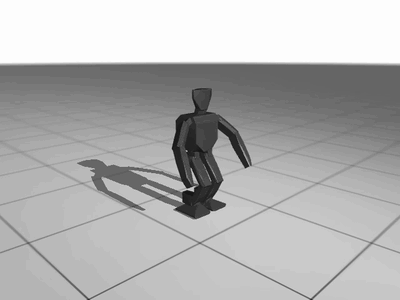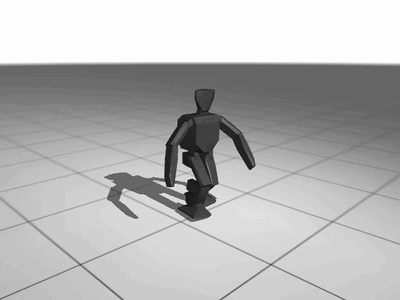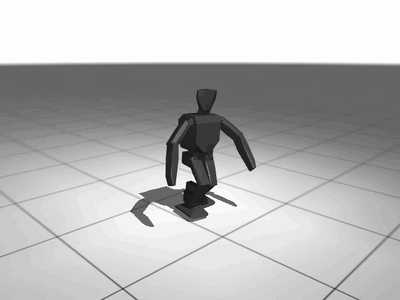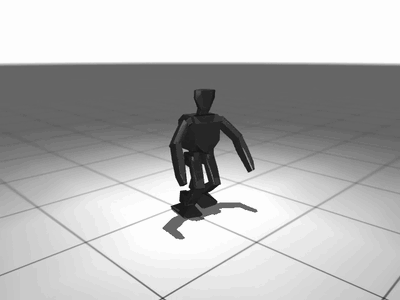
That policy was trained on the CPU (103 M steps in 96 min, 16 JAX CPU devices) while the GPU path was broken; with this recipe the same environment steps at up to 30,787 steps/s on the GPU (table below).
The working recipe (11 September 2026)
Linux x86_64, Python 3.12, uv:
uv venv -p 3.12 && source .venv/bin/activate
uv pip install --index https://repo.amd.com/rocm/whl/gfx1151/ --index-strategy unsafe-best-match \
  "jax==0.11.1" "jaxlib==0.11.1" "jax-rocm7-plugin==0.11.1" "jax-rocm7-pjrt==0.11.1" "rocm[libraries]==7.13.0"
python -c "import jax; print(jax.devices())"        # [RocmDevice(id=0)]
or, locked, from a clone: uv sync --extra gfx1151 --extra mjx. Your user must be in the render group
(/dev/kfd is root:render 0660): sudo usermod -aG render,video $USER, then log in again.
That is all: the 0.11.1 plugin (from PyPI) finds AMD's rocm-sdk library wheels by itself. No
LD_LIBRARY_PATH, no HSA_OVERRIDE_GFX_VERSION.
If the GPU is shared (with a local LLM, say), set XLA_PYTHON_CLIENT_PREALLOCATE=false, or JAX takes
75 % of device memory at start-up.
Compatibility matrix
Each cell from python jaxcheck.py --label … (evidence) on a Ryzen AI MAX+ 395 (64 GiB BIOS carve-out as VRAM),
Ubuntu 24.04, kernel 7.0, no system ROCm. MJX stages: mujoco_playground 0.2.0 Op3Joystick,
impl="jax", 16 environments.
| Wheel set | devices | matmul | scatters | MJX reset | MJX step |
|---|---|---|---|---|---|
JAX 0.11.1: plugin + PJRT 0.11.1 from PyPI, rocm[libraries]==7.13.0 (AMD gfx1151 index), no env vars |
ok | ok | ok | ok | ok |
JAX 0.9.2: TheRock nightly 0.9.2+rocm7.14.0a20260608 + rocm[libraries] of the same date, with rocm-run |
ok | ok | ok | fault, then the process hangs | not reached |
JAX 0.9.1: AMD gfx1151 release index 0.9.1+rocm7.13.0 + rocm[libraries,devel]==7.13.0 |
plugin cannot load: librocm_sysdeps_hwloc.so.5, librocm_sysdeps_pciaccess.so.0 not in any 7.13.0 SDK wheel (TheRock#8163) |
– | – | – | – |
The 0.9.x fault (HSA_STATUS_ERROR_MEMORY_APERTURE_VIOLATION in input_scatter_fusion_5, a large fused
scatter built from MJX kinematics) matches the fused-kernel bug fixed in XLA for JAX ≥ 0.10.0
(rocm-jax#453); no XLA flag avoided it on 0.9.2. Details:
rocm-jax#132.
Please add your row (another kernel, a system ROCm install, a newer index): CONTRIBUTING.md.
MJX throughput on this chip
Raw vmap(env.step) of Op3Joystick, 100 steps after compile, JAX 0.11.1, GPU shared with a resident
52 GB LLM:
| environments | GPU (env steps/s) | one CPU device (env steps/s) |
|---|---|---|
| 1,024 | 7,744 | 4,780 |
| 4,096 | 28,612 | 6,376 |
| 8,192 | 30,787 | 3,605 |
For comparison, Brax PPO training of the same env on the CPU split into 16 JAX devices
(--xla_force_host_platform_device_count=16) ran at 21,600 steps/s including the learning updates — so
on this APU the GPU is a solid but not dramatic gain, and it competes with other GPU users for memory.
First compiles take 40–170 s per batch shape; a persistent compilation cache helps.
jaxcheck: which set works, without hanging
Run it inside the environment you want to test (it checks the JAX that is installed there):
pip install strix-halo-jax     # jaxcheck only (standard library): it tests the JAX already installed
jaxcheck --label "my set"                                   # devices, matmul, scatters, MJX reset/step
jaxcheck --label "my set" --stages matmul scatter_set
XLA_FLAGS=--xla_… jaxcheck --label "with a flag"
or, with nothing installed yet, the tested set and the check in one go (verified with the wheel on the machine above):
uvx --python 3.12 --index https://repo.amd.com/rocm/whl/gfx1151/ --index-strategy unsafe-best-match \
    --from "strix-halo-jax[gfx1151,mjx]" jaxcheck --label "strix-halo-jax 0.1.0 set"
From a clone, python jaxcheck.py … works the same.
Each stage runs in its own process with its output streamed to results/<label>-<stage>.log, and is
recorded as ok, fail (non-zero exit; last error line kept), fault (a GPU fault signature was
printed — the process is killed at once, because after a queue abort ROCm processes can hang instead of
exiting) or timeout. Results go to results/results.jsonl and a table in results/README.md.
The MJX stages need pip install playground.
Traps we hit (so you don't)
| Symptom | Cause | Fix |
|---|---|---|
Backend 'rocm' is not in the list of known backends, rocm_plugin_extension not found |
a 0.9.x plugin cannot find the ROCm libraries (no system ROCm) | use the 0.11.1 plugin from PyPI; for 0.9.x, ./rocm-run sets the paths |
FAILED_PRECONDITION: No visible GPU devices; rocminfo: not member of "render" group |
/dev/kfd permission |
sudo usermod -aG render,video $USER, log in again |
| a benchmark "compiles" for 25 minutes, one thread at 100 % | a GPU fault followed by a hang (0.9.x + MJX), not a compile | upgrade to JAX ≥ 0.10; use jaxcheck.py to see fault in seconds |
rocblas_gemm_ex failed with: rocblas_status_internal_error in code that used to work |
a persistent compilation cache shared between JAX versions ("PjRt-IFRT does not track XLA executable versions") | one cache per jaxlib/plugin build (rocm-run does this) |
Unknown flag in XLA_FLAGS: --xla_gpu_… |
the flag exists in the plugin's strings but jaxlib does not accept it | drop it; jaxcheck.py reports the line |
| out-of-memory next to a local LLM | the BIOS gives the iGPU a fixed carve-out (64 GiB here) shared by everything on the GPU | preallocation off; or set the BIOS UMA frame buffer to its minimum so the GPU uses GTT from the full RAM |
Contributors

Licence and disclaimer
Apache-2.0. Measurements from one machine on one day; your firmware, kernel and wheel versions may differ — the matrix says exactly what was tested. Not affiliated with AMD or Google DeepMind. A developer tool, provided as is; not a medical device and not for clinical use.
1 maintainer

Metadata
1 maintainer
Release files for strix-halo-jax 0.1.1
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | Provenance | Actions |
|---|---|---|---|---|
| strix_halo_jax-0.1.1.tar.gz | 14.4 kB | With provenance | Details for strix_halo_jax-0.1.1.tar.gz |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Actions Reset |
|---|---|---|---|---|
| strix_halo_jax-0.1.1-py3-none-any.whl | Python 3 | none | any | Details for strix_halo_jax-0.1.1-py3-none-any.whl |
Total release size: 27.1 kB
Release files / strix_halo_jax-0.1.1.tar.gz
| Download URL | strix_halo_jax-0.1.1.tar.gz |
|---|---|
| Size | 14.4 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
f5e00facbf817e79b2479053464ba4d14ec8455bf20349f150c83eb9febc0903
|
|
BLAKE2b-256 checksum How to use checksums |
1837788539a7e2941a4147b6502195e3fc0d454855a2ba2d0b599d241d35ead6
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.


PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Sep 12, 2026.
Transparency logRelease files / strix_halo_jax-0.1.1-py3-none-any.whl
| Download URL | strix_halo_jax-0.1.1-py3-none-any.whl |
|---|---|
| Size | 12.7 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
d7cfde3b229469eb31d4fc58c31f5748cbfd5e3ead9699575b17186437a3cdf5
|
|
BLAKE2b-256 checksum How to use checksums |
9c55357a32f3afe8f17e2661888a32a4953fc145a596d7f4be9b7cfcf0b0a406
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Sep 12, 2026.
Transparency logSecurity for strix-halo-jax 0.1.1
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
Full provenance
All 2 files in this release have been uploaded with provenance metadata.
Attestation for strix_halo_jax-0.1.1.tar.gz
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Sep 12, 2026.
Transparency logA note on package security
PyPI is a repository for distributing packages, not a service for auditing them. While third-party security researchers and our staff do their best to detect and remove malicious packages, PyPI cannot guarantee the quality, security or suitability of any given package.
To learn more about protecting yourself from malicious actors, visit our package security documentation.














