
actuator-lint
Check a PX4 control allocation configuration before it flies.
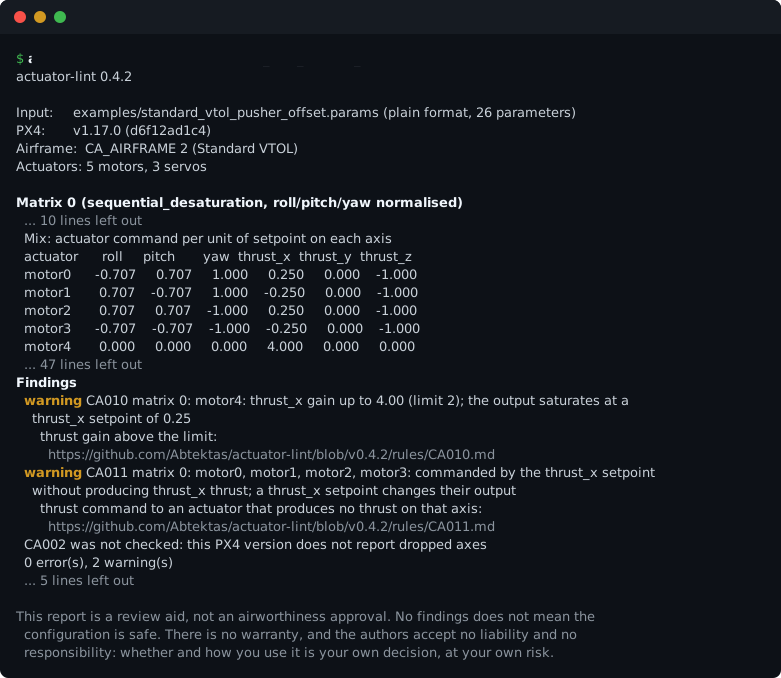
actuator-lint reads the CA_* parameters of a vehicle from a file, runs PX4's
own actuator effectiveness and control allocation code on them, and reports the
resulting matrices and likely configuration mistakes. No vehicle and no
simulator are needed.
Safety and liability
- This software is provided "as is", without warranty of any kind. The
authors and contributors accept no liability and no responsibility for any
use of the tool or of its results. Whether and how you use it is entirely
your own decision, at your own risk. The terms are in the
license, which
actuator-lint licenseprints. - It is a review aid. It does not approve a vehicle as safe or airworthy, and a report without findings does not mean the configuration is safe.
- It does not replace bench tests, motor tests without propellers, or careful step-by-step flight testing.
- This project is not affiliated with or endorsed by the PX4 project or the Dronecode Foundation. PX4 is a trademark of Dronecode Project, Inc. It is used here only to name the software this tool works with.
Install
This package is the Python part. It needs Python 3.11 or newer and has no Python dependencies:
pip install actuator-lint
The tool also needs the engine, a program built from the control allocation code of one PX4 version. Prebuilt engines for Linux (x86_64 and arm64) and macOS (arm64) are files of each release on GitHub; the README has the commands to download, check and install one, and says how to build an engine for another PX4 version. A result is only valid for the PX4 version the engine was built against, which every report names.
Documentation
1 maintainer

Metadata
1 maintainer
Release files for actuator-lint 0.4.2
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | |
|---|---|---|---|
| actuator_lint-0.4.2.tar.gz | 114.0 kB | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| actuator_lint-0.4.2-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 142.1 kB
Release files / actuator_lint-0.4.2.tar.gz
| Download URL | actuator_lint-0.4.2.tar.gz |
|---|---|
| Size | 114.0 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
7b473204ee07d31cc879cc0c9c791dc5bc3674511d7a0181416b8991bc6265f2
|
|
BLAKE2b-256 checksum How to use checksums |
9dbfe2ed6eea842a43736337701286bad217e29468d1cc75b24544e62d35d1a6
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.


PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Oct 16, 2026.
Transparency logRelease files / actuator_lint-0.4.2-py3-none-any.whl
| Download URL | actuator_lint-0.4.2-py3-none-any.whl |
|---|---|
| Size | 28.1 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
a108f4ff36e11eb751462ce878a8d7dcd9c5da7ed9f236154d4fad2cbcc0b5ac
|
|
BLAKE2b-256 checksum How to use checksums |
f076951b1004d4c5c4fe36dc0066ebcc6c805c9edca2def164e2b29dfc845b60
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Oct 16, 2026.
Transparency log












