
AGNES - Flexible Reinforcement Learning Framework with PyTorch
Status: This framework is under active development and bugs may occur.


Results
MuJoCo
(Current results)

You can get the Tensorboard log file by clicking the image above(You will be redirected to the destination GitHub folder). The default config for the MuJoCo environment was used. Plotted by examples/plot.py
Atari
(Old results)

You can get the Tensorboard log file by clicking the image above(You will be redirected to the destination GitHub folder). The default config for the Atari environment was used.
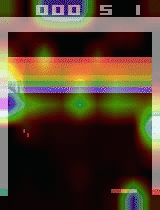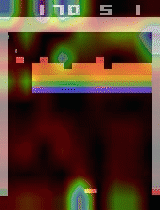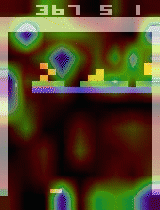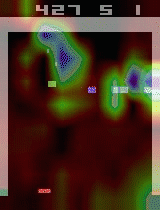
Grad-cam technique was used for sampled action chosen by trained LSTMCNN(previous point).
Runners
Single
One worker and trainer. agnes.make_vec_env can also be used here.
import agnes
import time


if __name__ == '__main__':
    env = agnes.make_env("InvertedDoublePendulum-v2")
    runner = agnes.Single(env, agnes.PPO, agnes.MLP)
    runner.log(agnes.log, agnes.TensorboardLogger(".logs/"), agnes.CsvLogger(".logs/"))
    runner.run()
agnes.log - object of StandardLogger class that outputs parameters to console. agnes.TensorboardLogger - class for writing logs in Tensorboard file. agnes.CsvLogger - class for writing logs in csv file. (required for plotting)
DistributedMPI
Unlike in Single runner, in DistributedMPI runner due to async executing, weights are delayed by one rollout but this has no effect on learning because weights are delayed only by one update as it is in Single runner. So all parameters like probabilities ratio stay the same.
Runs with
mpiexec -n 3 python -m mpi4py script_name.py
or
mpirun -n 3 python -m mpi4py script_name.py
This command will run 2 workers and 1 trainer.
# script_name.py
import agnes


if __name__ == '__main__':
    env = agnes.make_vec_env("BreakoutNoFrameskip-v4")
    runner = agnes.DistributedMPI(env, agnes.PPO, agnes.CNN)
    runner.run()
Algorithms
A2C
Sync version of Advantage Actor Critic is implemented in this framework and can be used simply:
import agnes


if __name__ == '__main__':
    runner = agnes.Single(env, agnes.A2C, agnes.MLP)
    runner.run()
PPO
Proximal Policy Optimization is implemented in this framework and can be used simply:
import agnes


if __name__ == '__main__':
    runner = agnes.Single(env, agnes.PPO, agnes.MLP)
    runner.run()
Neural Network Architectures
Multi Layer Perceptron
Can be used with both continuous and discrete action spaces.
...
runner = agnes.Single(env, agnes.PPO, agnes.MLP)
...
Convolutional Neural Network
Can be used only with discrete action spaces.
...
runner = agnes.Single(env, agnes.PPO, agnes.CNN)
...
Recurrent Neural Network
Can be used with both continuous and discrete action spaces.
...
runner = agnes.Single(env, agnes.PPO, agnes.RNN)
...
Convolutional Recurrent Neural Network
Can be used only with discrete action spaces.
...
runner = agnes.Single(env, agnes.PPO, agnes.RNNCNN)
...
Convolutional Neural Network with last LSTM layer
Can be used only with discrete action spaces.
...
runner = agnes.Single(env, agnes.PPO, agnes.LSTMCNN)
...
Make environment
-
make_vec_env(env, envs_num=ncpu, config=None)**
Parameters:
- env(str or function) is id of gym environment or function, that returns initialized environment
- envs_num(int) is a number of environments to initialize, by default is a number of logical cores on the CPU
- config(dict) is a dictionary with parameters for Monitor and for initializing environment, by default is None(uses default config)
Returns:
- dict of
- "env"(VecEnv object)
- "env_type"(str)
- "env_num"(int) is a number of envs in VecEnv object
- "env_name"(str) is the name of envs in VecEnv object(Id in gym or class name)
The whole tuple should be put in a runner.
-
make_env(env, config=None) is an alias of make_vec_env without envs_num argument that will be setted to 1.
Notice: Some plot functions and environment wrappers were taken from OpenAI Baselines(2017).
1 maintainer

Metadata
1 maintainer
Release files for agnes 0.0.7.4
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | |
|---|---|---|---|
| agnes-0.0.7.4.tar.gz | 41.7 kB | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| agnes-0.0.7.4-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 97.6 kB
Release files / agnes-0.0.7.4.tar.gz
| Download URL | agnes-0.0.7.4.tar.gz |
|---|---|
| Size | 41.7 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
bbbeabd6bef6a05b2d49833031938ad8274846d797b0b65ac2486272ea5d7fb2
|
|
BLAKE2b-256 checksum How to use checksums |
2546797a5733a81f243a2d89b1a9617117b84f0c2344d33a35647ebf17cdf6f5
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/3.1.1 pkginfo/1.5.0.1 requests/2.23.0 setuptools/41.2.0 requests-toolbelt/0.9.1 tqdm/4.46.0 CPython/3.8.3
|
Release files / agnes-0.0.7.4-py3-none-any.whl
| Download URL | agnes-0.0.7.4-py3-none-any.whl |
|---|---|
| Size | 55.9 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
287e11ccce48f5921b33785981699beb30df3d0481eaa83af406a4e01ebc1126
|
|
BLAKE2b-256 checksum How to use checksums |
ecf0be6e55f3dea2cb58feef5e224e0e28b61bf5ab1bac1d5b551e3469a0c5de
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/3.1.1 pkginfo/1.5.0.1 requests/2.23.0 setuptools/41.2.0 requests-toolbelt/0.9.1 tqdm/4.46.0 CPython/3.8.3
|














