
URDF Files for Humanoid Robots of the ARMAR Family
This repository provides (unofficial) URDF files for some of the humanoid robots of the ARMAR family.
Supported Robots
As of now, the following robots are supported:
| robot_name | DOF | Description | |
|---|---|---|---|
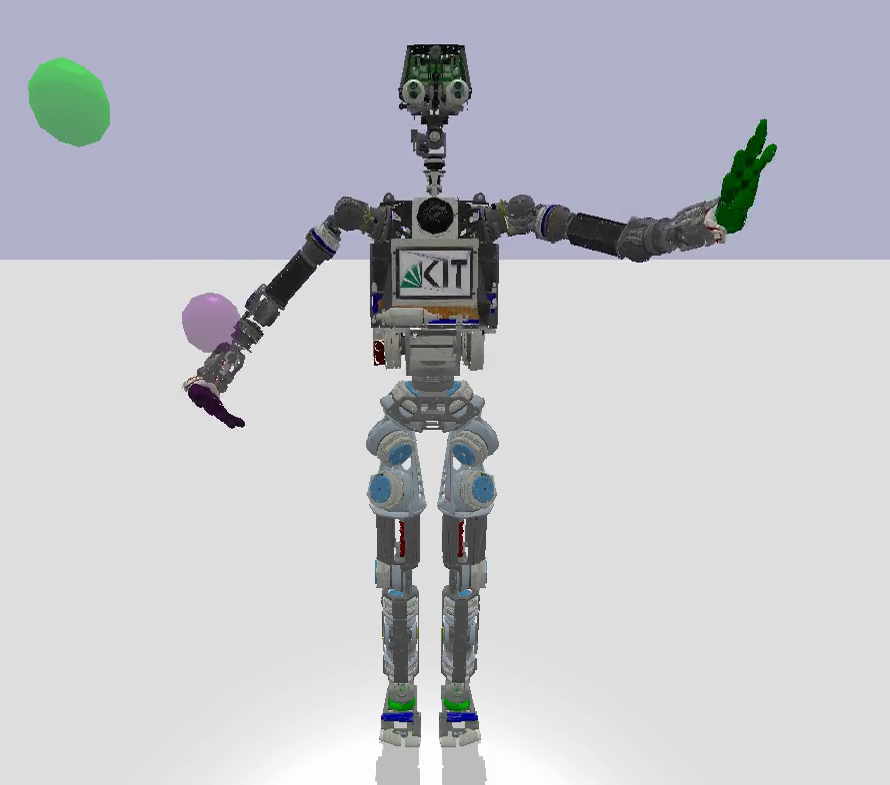 |
armar4 | 52 | The humanoid robot Armar 4 with a fixed head. |
| armar4_fixed_hands | 30 | Like armar4, but with rigid hands. | |
| armar4_fixed_hands_and_legs | 18 | Like armar4, but with rigid hands and fixed legs. | |
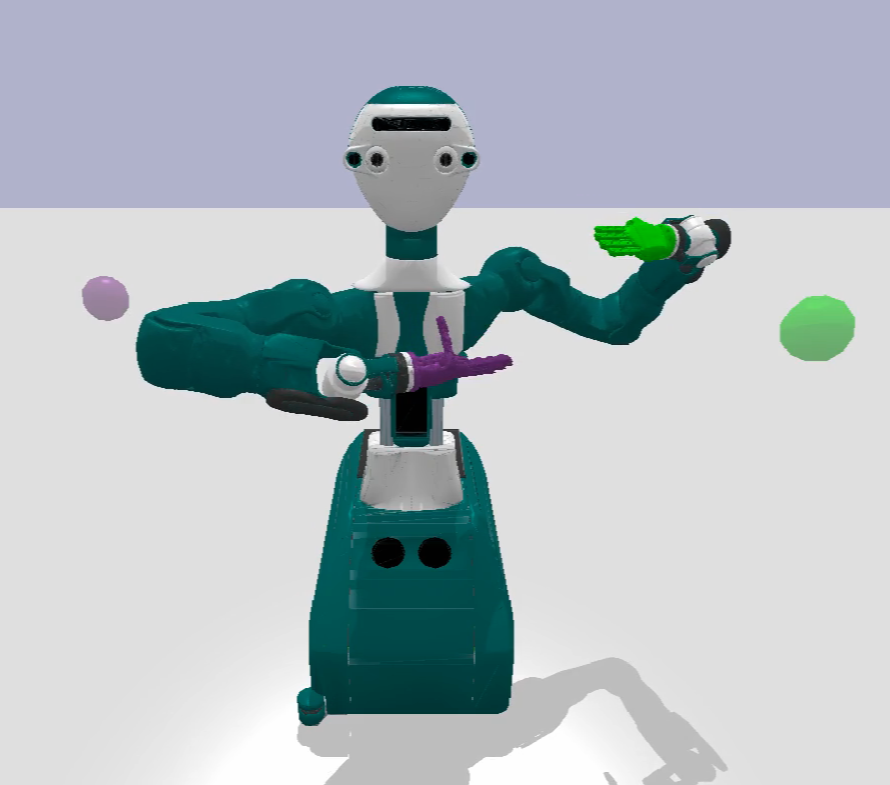 |
armar6 | 17 | The humanoid robot Armar 6 with a fixed head and rigid hands. |
| armar6_front | 17 | Like armar6, but the position of continuous joints is restricted such that the hands are mostly in front of the robot. | |
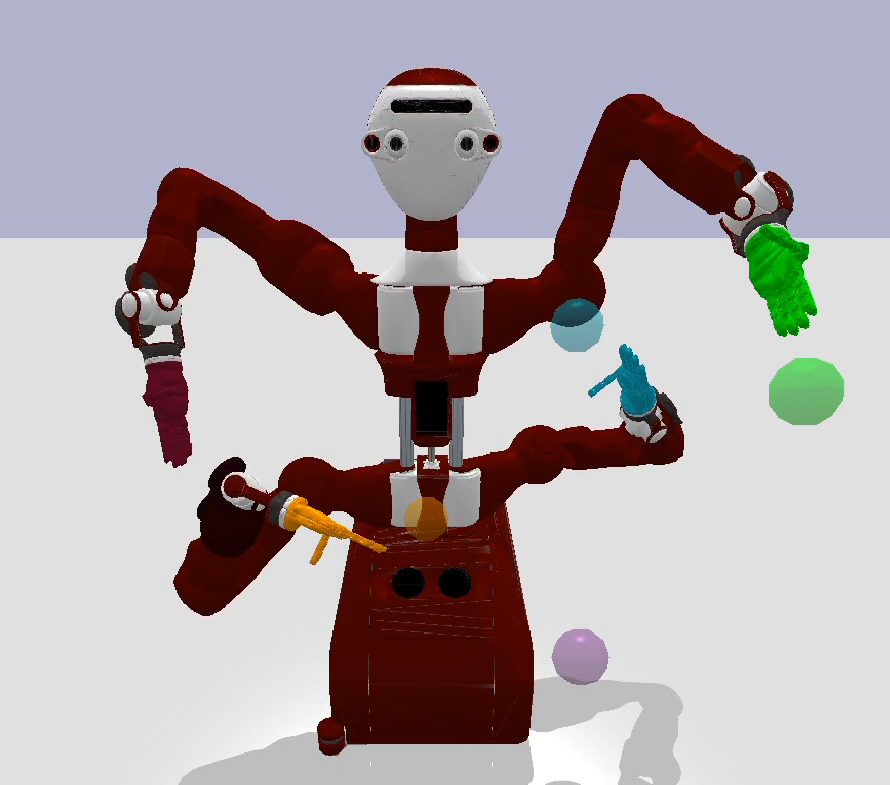 |
armar6_x4 | 33 | A four-armed version of Armar 6 with a fixed head and rigid hands. |
| armar6_x4_front | 33 | Like armar6_x4, but the position of continuous joints is restricted such that the hands are mostly in front of the robot. |
The corresponding URDF files can be found in the description directory. As shown below, it is also possible to access the models directly from python.
Installation
pip install armar
Usage
The following example shows how to receive the absolute path of a URDF file from python:
import armar
armar.get_path_to_urdf_file(robot_name="armar6")
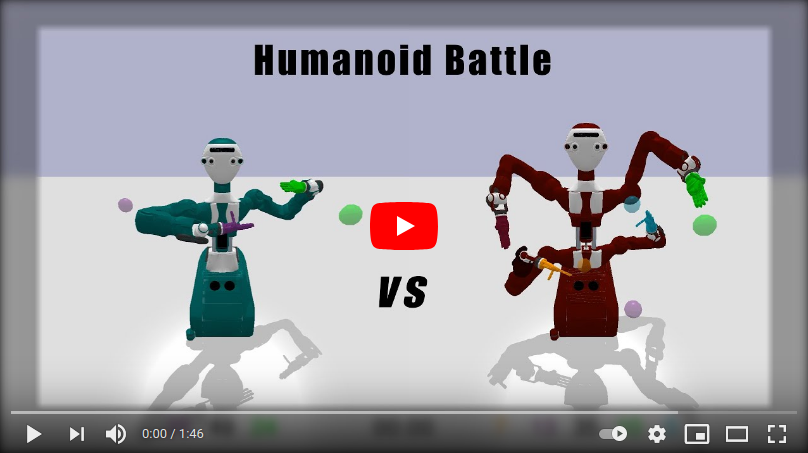
Example: Models controlled by a Neural Network
Acknowledgment and Disclaimer
The robots of the ARMAR family are designed and developed by the Chair of High Performance Humanoid Technologies (H²T) at the Karlsruhe Institute of Technology (KIT). The URDF files provided in this repository are based on models provided by the Chair of High Performance Humanoid Technologies. The four-armed version of Armar 6 is not an official part of the ARMAR family developed at H²T.
License
The files of this repository are licensed under the Creative Commons Attribution-NonCommercial 4.0 International (CC BY-NC 4.0) license.
1 maintainer

Metadata
1 maintainer
Release files for armar 1.1.0
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| armar-1.1.0-py3-none-any.whl | Python 3 | none | any | Details |
Release files / armar-1.1.0-py3-none-any.whl
| Download URL | armar-1.1.0-py3-none-any.whl |
|---|---|
| Size | 57.5 MB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
78ba2c9dfa22dc11e116d76753b265e99428b3bd0aad88de9f7dcf1b5d2f6aea
|
|
BLAKE2b-256 checksum How to use checksums |
36763bff68bc7c90c93105116d639dde95dfcfb6b998261457e7e158df73e6e5
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/3.4.1 importlib_metadata/3.10.0 pkginfo/1.7.0 requests/2.25.1 requests-toolbelt/0.9.1 tqdm/4.59.0 CPython/3.8.8
|














