
asmagic
A Python library for receiving data streams from asMagic iOS App.
Working with asMagic App:
Table of Contents
Features
AR Data Streaming
- 6DOF camera pose (position + orientation)
- RGB camera images
- Depth maps
- Camera intrinsics
- Device velocity
IMU Data Streaming
- Accelerometer (3-axis)
- Gyroscope (3-axis)
- Magnetometer (3-axis)
- Gravity vector
- User acceleration
- Device attitude (quaternion)
Joystick Data Streaming
- Dual joystick positions (left and right)
- 4 button states
- Real-time control data
- 0-1 normalized values
Install
pip install asmagic
Quick Start
AR Data
from asmagic import ARDataSubscriber

# Create subscriber with your iPhone's IP address
sub = ARDataSubscriber("192.168.1.100")

try:
    # Continuous data streaming
    for data in sub:
        # All sensor data in one frame
        print(f"Timestamp: {data.timestamp}")
        print(f"Velocity: {data.velocity}")
        print(f"Local Pose: {data.local_pose}")
        print(f"Global Pose: {data.global_pose}")
        print(f"Camera Intrinsics: {data.camera_intrinsics}")

        # Access image data
        if data.has_color_image:
            # Color: bytes(jpeg format) or array
            color_bytes = data.color_bytes
            color_array = data.color_array  # or shortcut: data.color
            print(f"Color: {len(color_bytes)} bytes, array shape: {color_array.shape}")

        if data.has_depth_image:
            # Depth: Numpy array
            depth = data.depth_array  # or shortcut: data.depth
            print(f"Depth: {depth.shape}")

except KeyboardInterrupt:
    print("\nStopped by user")
finally:
    sub.close()
IMU Data
from asmagic import IMUDataSubscriber

# Create IMU subscriber (port 8002 is fixed)
sub = IMUDataSubscriber("192.168.1.100")

try:
    # Continuous IMU data streaming
    for data in sub:
        print(f"Timestamp: {data.timestamp}")
        print(f"Accelerometer (G): {data.accelerometer}")
        print(f"Gyroscope (rad/s): {data.gyroscope}")
        print(f"Magnetometer (μT): {data.magnetometer}")
        print(f"Gravity (G): {data.gravity}")
        print(f"User Acceleration (G): {data.user_acceleration}")
        print(f"Attitude (quat): {data.attitude}")

except KeyboardInterrupt:
    print("\nStopped by user")
finally:
    sub.close()
Joystick Data
from asmagic import JoystickDataSubscriber

# Create joystick subscriber (port 8020 is default)
sub = JoystickDataSubscriber("192.168.1.100")

try:
    # Continuous joystick data streaming
    while True:
        data = sub.get()
        if data:
            # Joystick positions: 0.0 to 1.0 range
            # X-axis: right is positive, Y-axis: up is positive
            print(f"Left:  ({data.left_x:.3f}, {data.left_y:.3f})")
            print(f"Right: ({data.right_x:.3f}, {data.right_y:.3f})")
            print(f"Buttons: {data.buttons}")

except KeyboardInterrupt:
    print("\nStopped by user")
finally:
    sub.close()
Usage Examples
AR Data Examples
Note: Example 1 and Example 2 achieve the same goal of continuous data reading.
Example 1: Continuous AR Data Reading
from asmagic import ARDataSubscriber

# Connect to iPhone
sub = ARDataSubscriber("192.168.1.100")

try:
    for data in sub:
        # Print all available data
        print(f"\n--- Frame at {data.timestamp} ---")
        print(f"Velocity: {data.velocity}")
        print(f"Local Pose: {data.local_pose}")
        print(f"Global Pose: {data.global_pose}")
        print(f"Camera Intrinsics: {data.camera_intrinsics}")

        if data.has_depth_image:
            depth = data.depth  # or data.depth_array
            print(f"Depth shape: {depth.shape}, min: {depth.min()}, max: {depth.max()}")

except KeyboardInterrupt:
    print("\nStopped")
finally:
    sub.close()
Example 2: Continuous Reading with get()
from asmagic import ARDataSubscriber

sub = ARDataSubscriber("192.168.1.100")

try:
    while True:
        data = sub.get()
        if data:
            print(f"Timestamp: {data.timestamp}")
            print(f"Velocity: {data.velocity}")
            print(f"Local Pose: {data.local_pose}")
            print(f"Global Pose: {data.global_pose}")
            print(f"Camera Intrinsics: {data.camera_intrinsics}")

            # Access images
            if data.has_color_image:
                print(f"Color bytes: {len(data.color_bytes)} bytes")
                print(f"Color array: {data.color_array.shape}")

            if data.has_depth_image:
                print(f"Depth array: {data.depth_array.shape}")

except KeyboardInterrupt:
    print("\nStopped")
finally:
    sub.close()
Example 3: Display Color and Depth Images
from asmagic import ARDataSubscriber
import cv2

# Connect to iPhone
sub = ARDataSubscriber("192.168.1.100")

try:
    for data in sub:
        # Display both images side by side
        data.show_images()

        # Or display individually:
        # data.show_color()  # RGB image
        # data.show_depth()  # Depth map with colormap

        # Press ESC to exit
        if cv2.waitKey(1) == 27:
            break

except KeyboardInterrupt:
    print("\nStopped")
finally:
    sub.close()
    cv2.destroyAllWindows()
Example 4: Process Image Data
from asmagic import ARDataSubscriber
import numpy as np

sub = ARDataSubscriber("192.168.1.100")

try:
    for data in sub:

        # Color image: process as numpy array
        if data.has_color_image:
            color = data.color_array  # RGB numpy array
            print(f"Color shape: {color.shape}")

        # Depth image: always as numpy array
        if data.has_depth_image:
            depth = data.depth_array  # uint16 numpy array
            depth_meters = depth.astype(np.float32) / 10000.0
            print(f"Depth range: {depth_meters.min():.2f}m - {depth_meters.max():.2f}m")

except KeyboardInterrupt:
    pass
finally:
    sub.close()
Example 5: Using Pose Data
from asmagic import ARDataSubscriber
import numpy as np

sub = ARDataSubscriber("192.168.1.100")

try:
    for data in sub:
        # Extract position from pose (first 3 elements)
        position = data.local_pose[:3] # [tx, ty, tz]

        # Extract quaternion from pose (last 4 elements)
        quaternion = data.local_pose[3:]  # [qx, qy, qz, qw]

        print(f"Position (m): x={position[0]:.3f}, y={position[1]:.3f}, z={position[2]:.3f}")
        print(f"Quaternion: {quaternion}")
        print(f"Velocity (m/s): {data.velocity}")   # [vx, vy, vz]

except KeyboardInterrupt:
    pass
finally:
    sub.close()
Example 6: Get Individual AR Data Fields
from asmagic import ARDataSubscriber
import numpy as np

sub = ARDataSubscriber("192.168.1.100")

try:
    while True:
        # Get only specific data fields
        timestamp = sub.get_timestamp()
        print(f"Timestamp: {timestamp}")

except KeyboardInterrupt:
    print("\nStopped")
finally:
    sub.close()
Note: Use
get_*()methods when you need specific data fields. This is more efficient than receiving the full frame.
IMU Data Examples
Note: Example 7 and Example 8 achieve the same goal of continuous data reading.
Example 7: Continuous IMU Data Reading
from asmagic import IMUDataSubscriber

sub = IMUDataSubscriber("192.168.1.100")

try:
    for data in sub:
        print(f"\n--- IMU Frame at {data.timestamp} ---")
        print(f"Accelerometer (G): {data.accelerometer}")
        print(f"Gyroscope (rad/s): {data.gyroscope}")
        print(f"Magnetometer (μT): {data.magnetometer}")
        print(f"Gravity (G): {data.gravity}")
        print(f"User Acceleration (G): {data.user_acceleration}")
        print(f"Attitude (quat): {data.attitude}")

except KeyboardInterrupt:
    print("\nStopped")
finally:
    sub.close()
Example 8: Continuous Reading with get()
from asmagic import IMUDataSubscriber

sub = IMUDataSubscriber("192.168.1.100")

try:
    while True:
        data = sub.get()
        if data:
            print(f"\n--- IMU Frame at {data.timestamp} ---")
            print(f"Accelerometer (G): {data.accelerometer}")
            print(f"Gyroscope (rad/s): {data.gyroscope}")
            print(f"Magnetometer (μT): {data.magnetometer}")
            print(f"Gravity (G): {data.gravity}")
            print(f"User Acceleration (G): {data.user_acceleration}")
            print(f"Attitude (quat): {data.attitude}")

except KeyboardInterrupt:
    print("\nStopped")
finally:
    sub.close()
Example 9: Get Individual IMU Data Fields
from asmagic import IMUDataSubscriber
import numpy as np

sub = IMUDataSubscriber("192.168.1.100")

try:
    while True:
        # Get only specific IMU fields
        accel = sub.get_accelerometer()
        gyro = sub.get_gyroscope()

        if accel is not None and gyro is not None:
            # Calculate magnitudes
            accel_mag = np.linalg.norm(accel)
            gyro_mag = np.linalg.norm(gyro)

            print(f"Accel: {accel}, |a| = {accel_mag:.3f} G")
            print(f"Gyro: {gyro}, |ω| = {gyro_mag:.3f} rad/s")

except KeyboardInterrupt:
    print("\nStopped")
finally:
    sub.close()
Note: Use
get_*()methods when you need specific data fields. This is more efficient than receiving the full frame.
Joystick Data Examples
Example 10: Continuous Joystick Data Reading
from asmagic import JoystickDataSubscriber

sub = JoystickDataSubscriber("192.168.1.100")

try:
    while True:
        data = sub.get()
        if data:
            print(f"\n--- Frame at {data.timestamp:.3f} ---")
            print(f"Left Joystick:  X={data.left_x:.3f}, Y={data.left_y:.3f}")
            print(f"Right Joystick: X={data.right_x:.3f}, Y={data.right_y:.3f}")
            print(f"Buttons: {data.buttons}")

            if data.button1:
                print("  Button 1 pressed!")

except KeyboardInterrupt:
    print("\nStopped")
finally:
    sub.close()
Example 11: Iterator Style
from asmagic import JoystickDataSubscriber

with JoystickDataSubscriber("192.168.1.100") as sub:
    for data in sub:
        print(f"L({data.left_x:.3f}, {data.left_y:.3f}) "
              f"R({data.right_x:.3f}, {data.right_y:.3f})")
Note: Use
get_*()methods when you need specific data fields. This is more efficient than receiving the full frame.
Data Format Reference
AR Data
Coordinate System
Pose Format: $[t_x, t_y, t_z, q_x, q_y, q_z, q_w]$
- Translation (first 3 values): Position in meters
- $t_x, t_y, t_z$: X, Y, Z coordinates
- Rotation (last 4 values): Orientation as quaternion
- $q_x, q_y, q_z$: Imaginary part
- $q_w$: Real part
- Normalized: $q_x^2 + q_y^2 + q_z^2 + q_w^2 = 1$
Coordinate Frame:
- X-axis: Right
- Y-axis: Up
- Z-axis: Forward
Difference between local_pose and global_pose:
local_pose: Position relative to device starting pointglobal_pose: Position in shared world coordinate (when multiple devices collaborate)
Note: When using a single device,
local_poseandglobal_poseare identical
Velocity
Format: $[v_x, v_y, v_z]$
- Calculated as: $\vec{v} = \frac{\Delta \vec{p}}{\Delta t}$
- Unit: meters per second (m/s)
- In the same coordinate frame as pose
Camera Intrinsics
Format: $[f_x, 0, 0, 0, f_y, 0, c_x, c_y, 1]$
Represents 3×3 matrix:
$$ K = \begin{bmatrix} f_x & 0 & c_x \ 0 & f_y & c_y \ 0 & 0 & 1 \end{bmatrix} $$
Where:
- $f_x, f_y$: Focal length in pixels
- $c_x, c_y$: Principal point (optical center) in pixels
Depth Image
- Format: 16-bit unsigned integer (uint16)
- Unit: $10^{-4}$ m (0.1 mm, scaled by 10000 from meters)
- Conversion to meters: $d_{meters} = \frac{d_{raw}}{10000}$
- Range: $0 \leq d_{raw} \leq 65535$ → $0$ to $6.5535$ m
- Access: Use
data.depthordata.depth_arrayto get numpy array
Image Data Format
Color Image: Two formats available
color_bytes: JPEG compressed bytescolor_array: RGB numpy array (640×480×3)color: Shortcut forcolor_array
Depth Image: Numpy array only
depth_array: uint16 numpy array (256×192)depth: Shortcut fordepth_array
IMU Data
For detailed field descriptions, see IMUFrame Properties in API Reference.
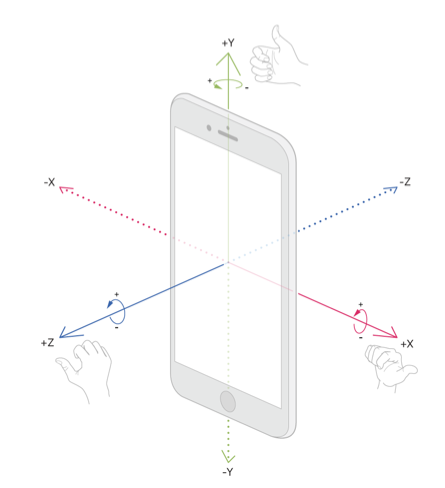
IMU Coordinate System
Coordinate Frame (iPhone device frame):
- X-axis: Right (when holding phone in portrait)
- Y-axis: Up (toward top of device)
- Z-axis: Forward (out of screen)
IMU Data Explained
The IMU data follows Apple's CoreMotion framework conventions. For comprehensive details, refer to Apple's CoreMotion Documentation.
1. Accelerometer
Total acceleration measured by the device's accelerometer hardware.
- Unit: G (gravitational force units, where $1G = 9.81 \text{ m/s}^2$)
2. Gyroscope
Angular velocity around each axis.
- Unit: rad/s (radians per second)
3. Magnetometer
Magnetic field strength detected by the device.
- Unit: μT (microteslas)
4. Gravity Vector
Component of acceleration due to Earth's gravitational pull, isolated from user motion.
- Unit: G (gravitational force units)
- Magnitude: $|\vec{g}| \approx 1.0G$ when stationary
- Usage: Determining device orientation relative to Earth
- Reference: CMDeviceMotion.gravity
5. User Acceleration
Acceleration from user motion, with gravity removed.
- Unit: G (gravitational force units)
- Formula: $\vec{a}{user} = \vec{a}{total} - \vec{g}$
- Reference: CMDeviceMotion.userAcceleration
6. Attitude (Quaternion)
Device orientation in 3D space.
- Format: $[q_x, q_y, q_z, q_w]$ (quaternion)
- Normalized: $q_x^2 + q_y^2 + q_z^2 + q_w^2 = 1$
- Reference: CMAttitude
Joystick Data
Joystick Position Values
The joystick data uses a 0.0 to 1.0 range for both axes:
- Value range: 0.0 to 1.0 (floating point)
- Center position: (0.5, 0.5)
- X-axis:
- 0.0 = Full left
- 0.5 = Center
- 1.0 = Full right
- Right is positive
- Y-axis:
- 0.0 = Full down
- 0.5 = Center
- 1.0 = Full up
- Up is positive
Coordinate System
        Y (1.0) ↑ UP
                |
                |
LEFT (0.0) ←----+----→ (1.0) RIGHT X
                |
                |
         DOWN ↓ (0.0)
Examples:
- Move joystick right: X increases (0.5 → 1.0)
- Move joystick up: Y increases (0.5 → 1.0)
- Move joystick to upper-right corner: (1.0, 1.0)
- Joystick at center: (0.5, 0.5)
Button Data
- Type: List of boolean values
- States:
True(pressed),False(released) - Count: 4 buttons
- Access:
data.buttonsordata.button1,data.button2, etc.
API Reference
ARDataSubscriber
Constructor:
ARDataSubscriber(ip, port=8000, hwm=1, conflate=True, verbose=False)
Parameters:
ip(str): iPhone's IP addressport(int): Port number (default: 8000)hwm(int): High water mark (default: 1, keeps only latest message)conflate(bool): Message conflation (default: True)verbose(bool): Print connection info (default: False)
Usage:
# Create subscriber
sub = ARDataSubscriber("192.168.1.100")

# Continuously receive data
for data in sub:
    print(data.timestamp)
    print(data.velocity)

# Close when done
sub.close()
Main Methods:
| Method | Returns | Description |
|---|---|---|
get() |
ARFrame or None |
Get latest data frame |
get_timestamp() |
float or None |
Get timestamp only |
get_velocity() |
np.ndarray or None |
Get velocity only |
get_local_pose() |
np.ndarray or None |
Get local pose only |
get_global_pose() |
np.ndarray or None |
Get global pose only |
get_camera_intrinsics() |
np.ndarray or None |
Get camera intrinsics only |
get_color_image() |
bytes or None |
Get color image bytes only |
get_depth_image() |
np.ndarray or None |
Get depth array only |
close() |
None |
Close connection |
Note:
- The subscriber is iterable, so you can use
for data in sub:to receive frames continuously. - All
get_*()methods accept an optionaltimeoutparameter (default: 1000ms).
ARFrame
Data object returned by get() or when iterating. For data format details, see AR Data Format Reference above.
Properties:
| Property | Type | Description |
|---|---|---|
timestamp |
float |
Unix timestamp in seconds |
velocity |
np.ndarray |
Velocity $[v_x, v_y, v_z]$ in m/s |
local_pose |
np.ndarray |
Local pose $[t_x, t_y, t_z, q_x, q_y, q_z, q_w]$ |
global_pose |
np.ndarray |
Global pose $[t_x, t_y, t_z, q_x, q_y, q_z, q_w]$ |
camera_intrinsics |
np.ndarray |
Camera intrinsics (3×3 flattened) |
| Color Image | ||
color_bytes |
bytes |
JPEG image bytes (for saving/forwarding) |
color_array |
np.ndarray |
Decoded RGB image array (H×W×3) |
color |
np.ndarray |
Shortcut for color_array |
| Depth Image | ||
depth_array |
np.ndarray |
Depth image array (uint16, H×W) |
depth |
np.ndarray |
Shortcut for depth_array |
depth_width |
int |
Depth image width |
depth_height |
int |
Depth image height |
| Helpers | ||
has_color_image |
bool |
Check if color image exists |
has_depth_image |
bool |
Check if depth image exists |
Methods:
| Method | Returns | Description |
|---|---|---|
show_color(window_name) |
bool |
Display color image with OpenCV |
show_depth(window_name, colormap) |
bool |
Display depth image with colormap |
show_images(show_color, show_depth) |
tuple |
Display both images side by side |
IMUDataSubscriber
Constructor:
IMUDataSubscriber(ip, port=8002, hwm=1, conflate=True, verbose=False)
Parameters:
ip(str): iPhone's IP addressport(int): Port number (default: 8002, fixed for IMU data)hwm(int): High water mark (default: 1, keeps only latest message)conflate(bool): Message conflation (default: True)verbose(bool): Print connection info (default: False)
Usage:
# Create IMU subscriber
sub = IMUDataSubscriber("192.168.1.100")

# Continuously receive IMU data
for data in sub:
    print(data.accelerometer)
    print(data.gyroscope)

# Close when done
sub.close()
Main Methods:
| Method | Returns | Description |
|---|---|---|
get() |
IMUFrame or None |
Get latest IMU data frame |
get_timestamp() |
float or None |
Get timestamp only |
get_accelerometer() |
np.ndarray or None |
Get accelerometer only |
get_gyroscope() |
np.ndarray or None |
Get gyroscope only |
get_magnetometer() |
np.ndarray or None |
Get magnetometer only |
get_gravity() |
np.ndarray or None |
Get gravity vector only |
get_user_acceleration() |
np.ndarray or None |
Get user acceleration only |
get_attitude() |
np.ndarray or None |
Get attitude quaternion only |
close() |
None |
Close connection |
Note:
- The subscriber is iterable, so you can use
for data in sub:to receive frames continuously. - All
get_*()methods accept an optionaltimeoutparameter (default: 1000ms).
IMUFrame
Data object returned by get() or when iterating. For data format details and physical meanings, see IMU Data Format Reference above.
Properties:
| Property | Type | Description |
|---|---|---|
timestamp |
float |
Unix timestamp in seconds |
accelerometer |
np.ndarray |
Accelerometer $[a_x, a_y, a_z]$ in G |
gyroscope |
np.ndarray |
Gyroscope $[\omega_x, \omega_y, \omega_z]$ in rad/s |
magnetometer |
np.ndarray |
Magnetometer $[m_x, m_y, m_z]$ in μT |
gravity |
np.ndarray |
Gravity $[g_x, g_y, g_z]$ in G |
user_acceleration |
np.ndarray |
User acceleration $[u_x, u_y, u_z]$ in G |
attitude |
np.ndarray |
Attitude quaternion $[q_x, q_y, q_z, q_w]$ |
Helper Properties:
| Property | Type | Description |
|---|---|---|
has_accelerometer |
bool |
Check if accelerometer data exists |
has_gyroscope |
bool |
Check if gyroscope data exists |
has_magnetometer |
bool |
Check if magnetometer data exists |
has_gravity |
bool |
Check if gravity data exists |
has_user_acceleration |
bool |
Check if user acceleration exists |
has_attitude |
bool |
Check if attitude data exists |
JoystickDataSubscriber
Constructor:
JoystickDataSubscriber(ip, port=8020, hwm=1, conflate=True, verbose=False)
Parameters:
ip(str): Publisher's IP addressport(int): Port number (default: 8020)hwm(int): High water mark (default: 1, keeps only latest message)conflate(bool): Message conflation (default: True)verbose(bool): Print connection info (default: False)
Usage:
# Create subscriber
sub = JoystickDataSubscriber("192.168.1.100")

# Continuously receive data
for data in sub:
    print(f"Left: ({data.left_x}, {data.left_y})")
    print(f"Buttons: {data.buttons}")

# Close when done
sub.close()
Main Methods:
| Method | Returns | Description |
|---|---|---|
get() |
JoystickFrame or None |
Get latest data frame |
get_timestamp() |
float or None |
Get timestamp only |
get_left_joystick() |
np.ndarray or None |
Get left joystick only |
get_right_joystick() |
np.ndarray or None |
Get right joystick only |
get_buttons() |
List[bool] or None |
Get button states only |
close() |
None |
Close connection |
Note:
- The subscriber is iterable, so you can use
for data in sub:to receive frames continuously. - All
get_*()methods accept an optionaltimeoutparameter (default: 1000ms).
JoystickFrame
Data object returned by get() or when iterating.
Properties:
| Property | Type | Description |
|---|---|---|
timestamp |
float |
Unix timestamp in seconds |
left_joystick |
np.ndarray |
Left joystick position [x, y] (0.0-1.0) |
right_joystick |
np.ndarray |
Right joystick position [x, y] (0.0-1.0) |
buttons |
List[bool] |
Button states [button1, button2, button3, button4] |
left_x |
float |
Left joystick X (0.0-1.0, right is positive) |
left_y |
float |
Left joystick Y (0.0-1.0, up is positive) |
right_x |
float |
Right joystick X (0.0-1.0, right is positive) |
right_y |
float |
Right joystick Y (0.0-1.0, up is positive) |
button1 |
bool |
Button 1 state |
button2 |
bool |
Button 2 state |
button3 |
bool |
Button 3 state |
button4 |
bool |
Button 4 state |
Helper Properties:
| Property | Type | Description |
|---|---|---|
has_left_joystick |
bool |
Check if left joystick data exists |
has_right_joystick |
bool |
Check if right joystick data exists |
has_buttons |
bool |
Check if button data exists |
Requirements
- Python >= 3.8
- numpy >= 1.20.0
- pyzmq >= 22.0.0
- protobuf >= 4.0.0
- opencv-python >= 4.5.0
- Pillow >= 8.0.0
License
MIT License
1 maintainer

Metadata
1 maintainer
Release files for asmagic 0.1.4
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | Provenance | |
|---|---|---|---|---|
| asmagic-0.1.4.tar.gz | 25.8 kB | Without provenance | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| asmagic-0.1.4-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 48.5 kB
Release files / asmagic-0.1.4.tar.gz
| Download URL | asmagic-0.1.4.tar.gz |
|---|---|
| Size | 25.8 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
6ad5436e9920c30aab114579449998efefa24c89c909bb993f5e8e5c3535fbb9
|
|
BLAKE2b-256 checksum How to use checksums |
8a8996e70db64a39aba7b3c31c6ae1a6f20e76fef0a6e6b755e031ee613ba1b8
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/6.1.0 CPython/3.8.18
|
Release files / asmagic-0.1.4-py3-none-any.whl
| Download URL | asmagic-0.1.4-py3-none-any.whl |
|---|---|
| Size | 22.8 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
da4a213216b7d51669a04d56ad5bc091a77e5b5c9c766b51e653f2d81e1c3353
|
|
BLAKE2b-256 checksum How to use checksums |
b8de6cb21c896037ca6498bb933259f89031c81bfe003f7f75a9f5965f120d1d
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/6.1.0 CPython/3.8.18
|
Security for asmagic 0.1.4
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
No provenance found
None of the files in this release were uploaded with provenance metadata.
A note on package security
PyPI is a repository for distributing packages, not a service for auditing them. While third-party security researchers and our staff do their best to detect and remove malicious packages, PyPI cannot guarantee the quality, security or suitability of any given package.














