


A Python package for simulating UAV Navigation in Satellite-Less Environments. The package contains two algorithms the GTRS [1] and WLS [2] whose goal is to estimate and navigate a UAV.
Installation
Install from PyPI:
pip install --upgrade pip
pip install autonav
First Steps
After installing the package one can import the algorithms and necessary dependencies as follows:
import matplotlib.pyplot as plt

from autonav import gtrs, wls
from autonav.file_handlers import readpathfile
from autonav.plots import plot_trajectories
from numpy import array
Afterwards, one can create the necessary values to run the algorithms:
# Area border
b = 200
# Number of anchors
n = 8
# Position of the anchors
a_i = array(
    [
    [0, 0, 0],
    [0, b, 0],
    [b / 2, 0, 0],
    [b / 2, b, 0],
    [0, 0, b / 8],
    [0, b, b / 8],
    [b / 2, 0, b / 8],
    [b / 2, b, b / 8],]
    ).T
# Number of measurement samples
k = 50
# Maximum velocity allowed to the UAV
v_max = b / 100
# Distance threshold
tau = b / 50
# Smoothing factor
gamma = b / 100
# Initial position of the UAV
initial_uav_position = [10, 10, 5]
# File containing the waypoints
destinations = readpathfile("docs/docs/examples/Path.csv")
# Noise seed
noise_seed = 1
# Noise Distribution
noise_distribution = "normal"
# Noise distribution parameters
mean = 0
std = 1
noise_distribution_parameters = [mean, std]
Finally, run the GTRS or WLS algorithm and plot the trajectories:
# Estimate the positions and trajectory using the GTRS algorithm
[estimated_positions, true_trajectory] = gtrs(
    a_i,
    n,
    k,
    destinations,
    initial_uav_position,
    v_max,
    tau,
    gamma,
    noise_seed,
    noise_distribution,
    noise_distribution_parameters,
)
# Plot the trajectory that the UAV followed
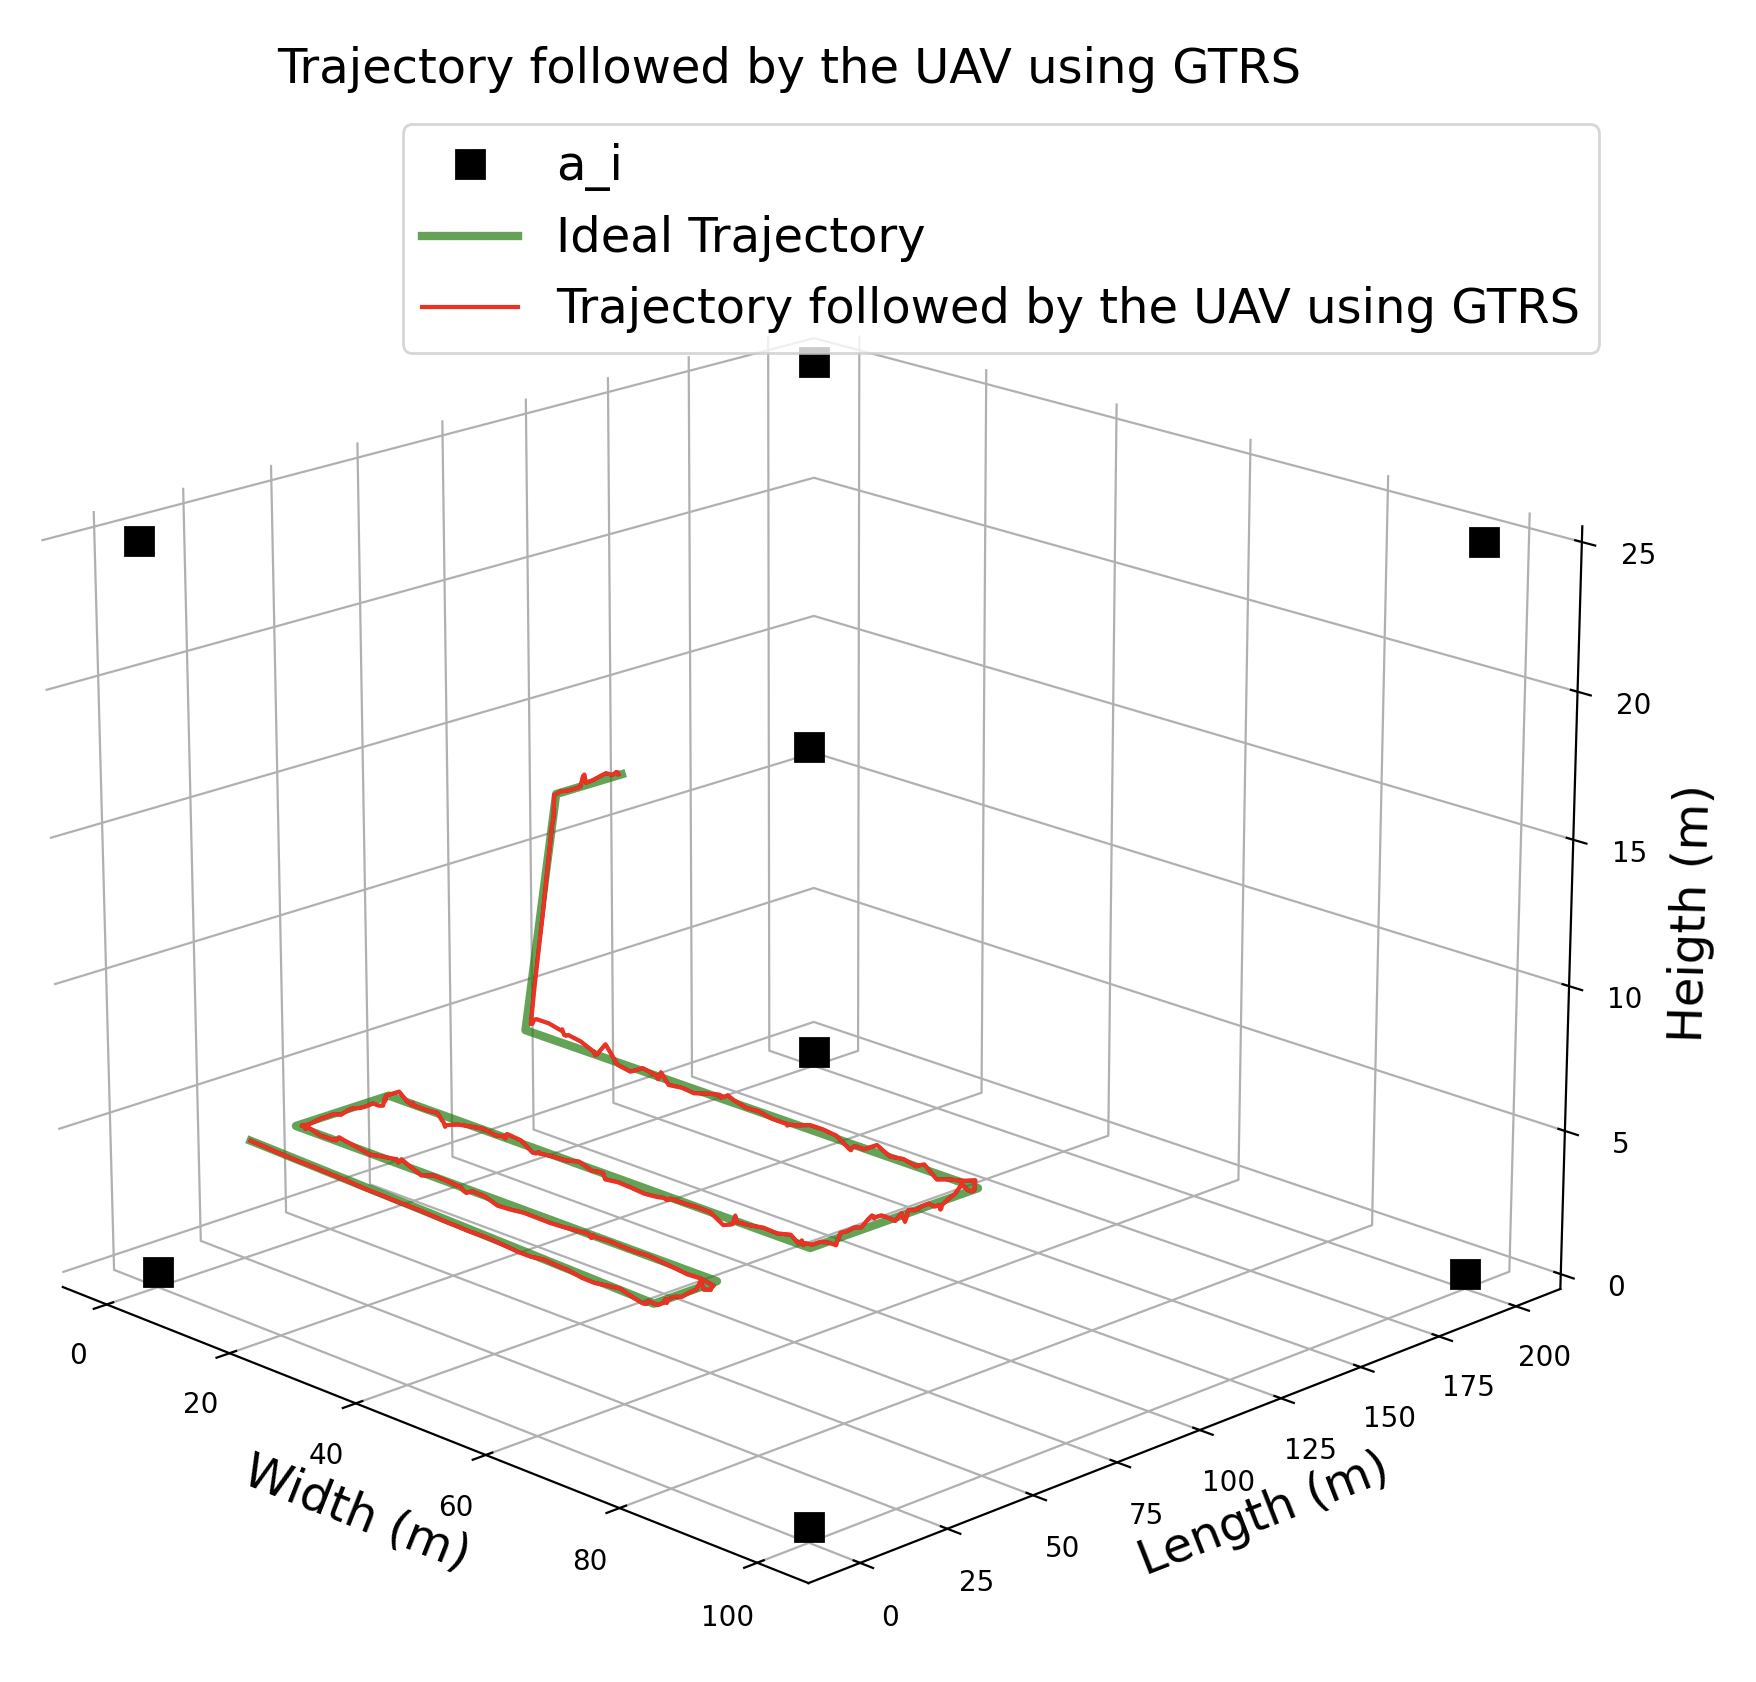
plot_trajectories(destinations, [true_trajectory], a_i, ['GTRS'])
plt.show()
References
[1] J. P. Matos-Carvalho, R. Santos, S. Tomic and M. Beko, "GTRS-Based Algorithm for UAV Navigation in Indoor Environments Employing Range Measurements and Odometry," in IEEE Access, vol. 9, pp. 89120-89132, 2021, doi: 10.1109/ACCESS.2021.3089900. https://ieeexplore.ieee.org/document/9456863
[2] R. Santos, J. P. Matos-Carvalho, S. Tomic and M. Beko, "WLS algorithm for UAV navigation in satellite‐less environments," in IET Wireless Sensor Systems, 2022, 12, (3-4), p. 93-102, DOI: 10.1049/wss2.12041 IET Digital Library, https://ietresearch.onlinelibrary.wiley.com/doi/full/10.1049/wss2.12041
License
1 maintainer

Metadata
1 maintainer
Release files for autonav 1.0.3
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | |
|---|---|---|---|
| autonav-1.0.3.tar.gz | 16.3 kB | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| autonav-1.0.3-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 30.4 kB














