
Candphy




Library from Python3.+ for development, works, researches, and more other works and projects on the more points of physic 📈📊
First time
Installation:
this lib is found on the site of packages for python the pypi and on the site that is a repository for the codes and softwares with licenses from majority business of the word, the github.
Linux
$ pip3 install candphy -U
Windows
C\:> python3 -m pip3 install candphy -U
Examples
Waves
Signal Radio
(need the RTL-SDR driver)
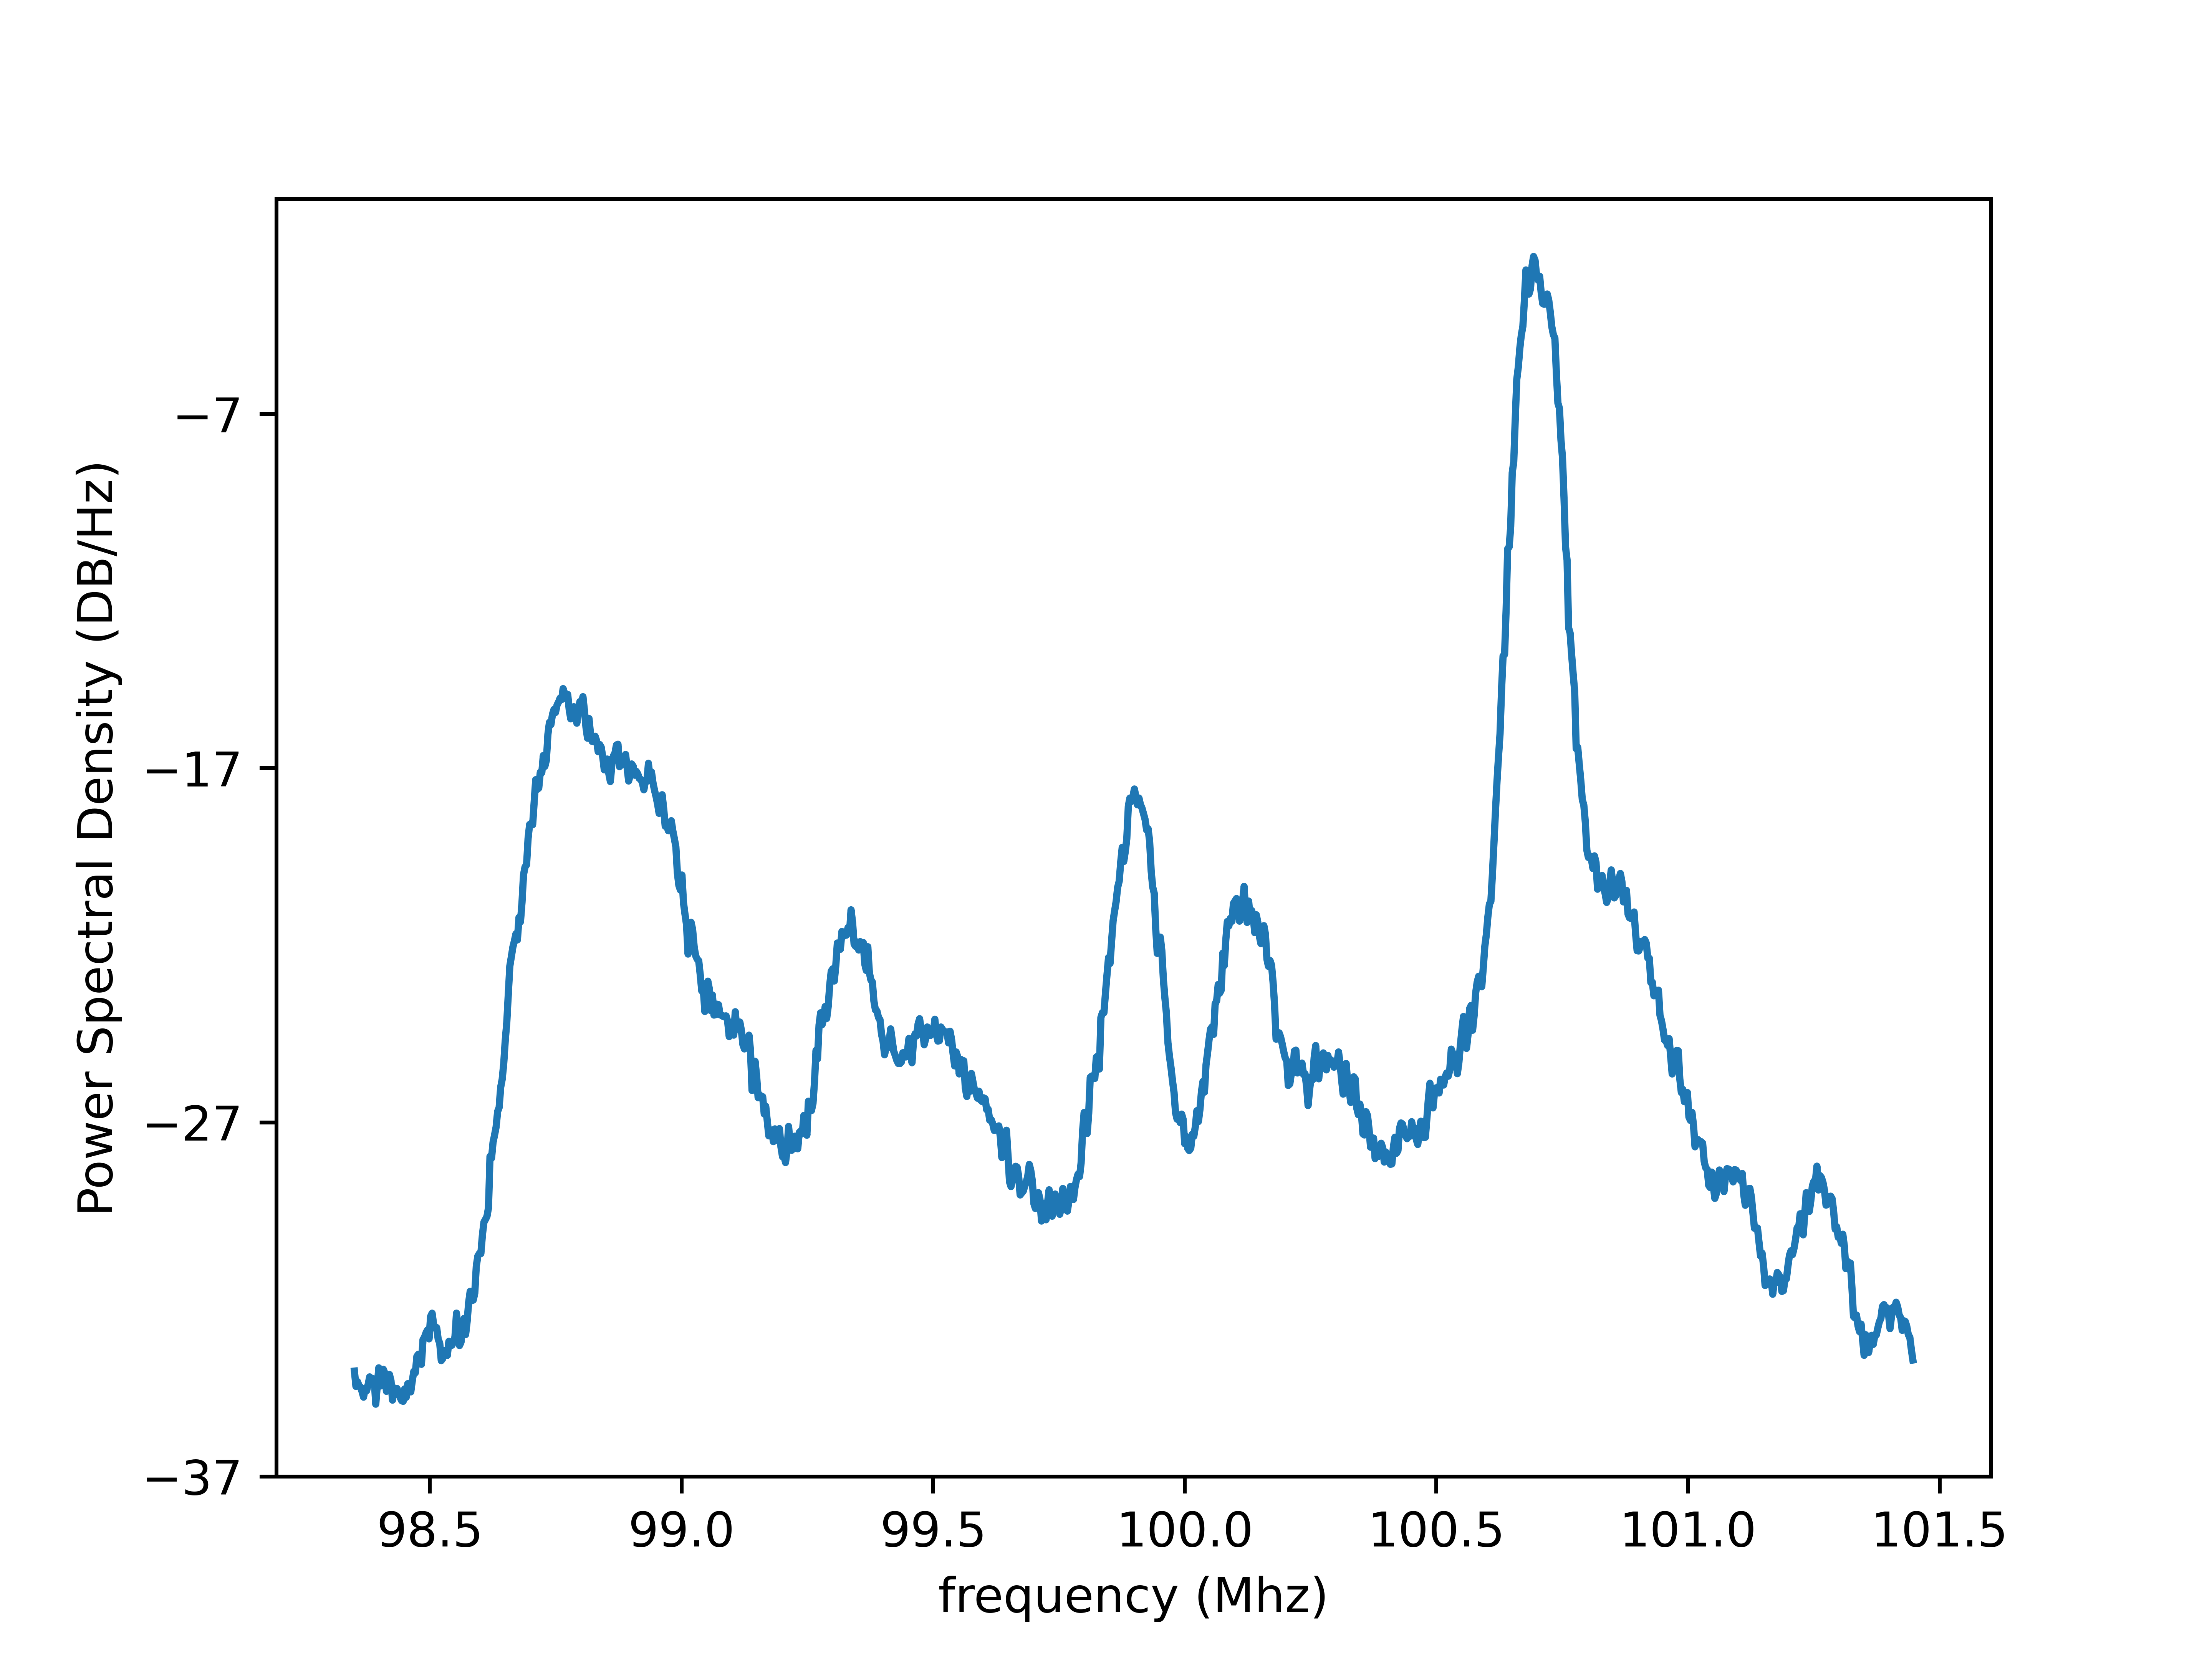
from candphy.waves import get_signal_radio as gr
from candphy.waves import plot_signal as ps
from candphy.logs import show_console

#showing the logs from work lib
show_console(False)

#getting signals samples from
#the around of the frequency 99.9Mhz
#(raio from space get is of 3.1Mhz)
s = gr(99.9)

print('signal radio: \n',s)

#plotting this signal radio
ps(s)
'''
output:
Detached kernel driver
Found Rafael Micro R820T tuner
[R82XX] PLL not locked!
Exact sample rate is: 3100000.092387 Hz
Reattached kernel driver
signal radio:
{'freq_center': 99900000.0, 'freq_rate': 3100000.0, 'bytes': 1024, 'order': 1000000.0, 'size_signal': 262144, 'samples': array([-0.00392157-0.00392157j, -0.00392157-0.00392157j,
       -0.00392157-0.00392157j, ...,  0.1372549 -0.0745098j ,
       -0.10588235+0.15294118j, -0.16078431+0.10588235j]), 'type': 'signal_radio'}
Gravitational Waves
working data
getting the data:
from candphy.waves import gwaves

gw = gwaves.Gwaves_Data()
pd_gw = gw.data_gw
showing the DataFrame:
#printing the DataFrame of Gravitational Waves
print('type:',type(pd_gw))
print(pd_gw)
output:
type: <class 'pandas.core.frame.DataFrame'>

               Name Version           Release           GPS              Mass 1 (M☉)  ...                  Redshift False Alarm Rate (yr-1)          Final Mass (M☉)                     Date                                               Link
0   GW200322_091133      v1  GWTC-3-confident  1.268904e+09       34.0  34  +48  -18  ...   0.6  0.60  +0.84  -0.30              140.0  140       53.0  53  +38  -26  2020-03-22T09:12:10.300  https://www.gw-openscience.org/eventapi/html/G...
1   GW200316_215756      v1  GWTC-3-confident  1.268431e+09  13.1  13.1  +10.2  -2.9  ...  0.22  0.22  +0.08  -0.08       1e-05  ≤  1.0e-05   20.2  20.2  +7.4  -1.9  2020-03-16T21:58:33.100  https://www.gw-openscience.org/eventapi/html/G...
2   GW200311_115853      v1  GWTC-3-confident  1.267963e+09   34.2  34.2  +6.4  -3.8  ...  0.23  0.23  +0.05  -0.07       1e-05  ≤  1.0e-05   59.0  59.0  +4.8  -3.9  2020-03-11T11:59:30.300  https://www.gw-openscience.org/eventapi/html/G...
3   GW200308_173609      v1  GWTC-3-confident  1.267724e+09  36.4  36.4  +11.2  -9.6  ...  0.83  0.83  +0.32  -0.35                2.4  2.4  47.4  47.4  +11.1  -7.7  2020-03-08T17:36:46.700  https://www.gw-openscience.org/eventapi/html/G...
4   GW200306_093714      v1  GWTC-3-confident  1.267523e+09  28.3  28.3  +17.1  -7.7  ...  0.38  0.38  +0.24  -0.18                24.0  24  41.7  41.7  +12.3  -6.9  2020-03-06T09:37:51.100  https://www.gw-openscience.org/eventapi/html/G...
..              ...     ...               ...           ...                      ...  ...                       ...                     ...                      ...                      ...                                                ...
88         GW170608      v3  GWTC-1-confident  1.180922e+09   11.0  11.0  +5.5  -1.7  ...  0.07  0.07  +0.02  -0.02       1e-07  ≤  1.0e-07   17.8  17.8  +3.4  -0.7  2017-06-08T02:01:53.500  https://www.gw-openscience.org/eventapi/html/G...
89         GW170104      v2  GWTC-1-confident  1.167560e+09   30.8  30.8  +7.3  -5.6  ...   0.2  0.20  +0.08  -0.08       1e-07  ≤  1.0e-07   48.9  48.9  +5.1  -4.0  2017-01-04T10:12:35.600  https://www.gw-openscience.org/eventapi/html/G...
90         GW151226      v2  GWTC-1-confident  1.135136e+09   13.7  13.7  +8.8  -3.2  ...  0.09  0.09  +0.04  -0.04       1e-07  ≤  1.0e-07   20.5  20.5  +6.4  -1.5  2015-12-26T03:39:29.600  https://www.gw-openscience.org/eventapi/html/G...
91         GW151012      v3  GWTC-1-confident  1.128679e+09  23.2  23.2  +14.9  -5.5  ...  0.21  0.21  +0.09  -0.09        0.00792  7.9e-03  35.6  35.6  +10.8  -3.8  2015-10-12T09:55:19.400  https://www.gw-openscience.org/eventapi/html/G...
92         GW150914      v3  GWTC-1-confident  1.126259e+09   35.6  35.6  +4.7  -3.1  ...  0.09  0.09  +0.03  -0.03       1e-07  ≤  1.0e-07   63.1  63.1  +3.4  -3.0  2015-09-14T09:51:21.400  https://www.gw-openscience.org/eventapi/html/G...

[93 rows x 17 columns]
the columns in the data:
print('columns:')
print(pd_gw.columns)
output:
columns:
Index(['Name', 'Version', 'Release', 'GPS', 'Mass 1 (M☉)', 'Mass 2 (M☉)',
       'Network SNR', 'Distance (Mpc)', 'χeff', 'Total Mass (M☉)',
       'Chirp Mass (M☉)', 'Detector Frame Chirp Mass (M☉)', 'Redshift',
       'False Alarm Rate (yr-1)', 'Final Mass (M☉)', 'Date', 'Link'],
      dtype='object')
plotting signal
from candphy.waves import gwaves

#instanciamint the data of graviatitonal waves
gw = gwaves.Gwaves_Data()

#getting the name of last gwave from data
gw_name = gw.data_gw['Name'][0]

#getting the gwave of this name
gwave = gw.get_gwave(name_gwave=gw_name)

#ploting the gwave signal
plt_signal = gw.plot_gwave(gwave)

plt_signal.savefig(f'signal_{gw_name}.png',dpi=900)
plt_signal.show()
output:
1 maintainer

Metadata
1 maintainer
Release files for candphy 0.0.2021
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| candphy-0.0.2021-py3-none-any.whl | Python 3 | none | any | Details |
Release files / candphy-0.0.2021-py3-none-any.whl
| Download URL | candphy-0.0.2021-py3-none-any.whl |
|---|---|
| Size | 9.8 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
40a5d66dd8c3cba9c89f4eea03c65e2f39da336f5877d78e1404c3aa99c14349
|
|
BLAKE2b-256 checksum How to use checksums |
14bd544634dffe38991e71f131f5d7d1dbf48bc335748f1dd5f09c45fedae197
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/4.0.2 CPython/3.9.13
|
Security for candphy 0.0.2021
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
No provenance found
None of the files in this release were uploaded with provenance metadata.
A note on package security
PyPI is a repository for distributing packages, not a service for auditing them. While third-party security researchers and our staff do their best to detect and remove malicious packages, PyPI cannot guarantee the quality, security or suitability of any given package.
To learn more about protecting yourself from malicious actors, visit our package security documentation.













