
Contrax
Differentiable control theory primitives for JAX.



Contrax is a JAX-native systems, estimation, and control toolbox.
MATLAB-familiar names at the API surface — ss, lqr, kalman, place —
with jit, vmap, and grad behavior underneath.
Documentation · Getting started · API reference
Install
pip install contrax
Requires Python 3.11+ and JAX 0.9.2+. For GPU support, install JAX separately per the JAX installation guide before installing Contrax.
Upgrading from 0.1.0? Version 0.2.0 changes filter signatures, result fields, solver configuration and MHE indexing. Read the breaking changes and migration notes before updating callers.
Why Contrax
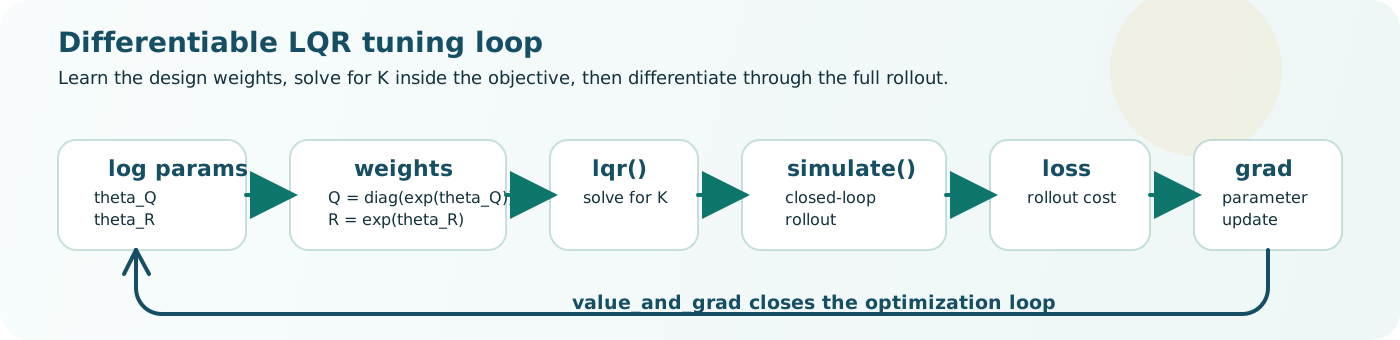
A controller design step can sit inside an ordinary differentiable objective instead of being a separate offline calculation:
import jax
jax.config.update("jax_enable_x64", True)

import jax.numpy as jnp
import contrax as cx

A = jnp.array([[1.0, 0.05], [0.0, 1.0]])
B = jnp.array([[0.0], [0.05]])
SYS = cx.dss(A, B, jnp.eye(2), jnp.zeros((2, 1)), dt=0.05)
X0 = jnp.array([1.0, 0.0])


def closed_loop_cost(log_q_diag, log_r):
    K = cx.lqr(SYS, jnp.diag(jnp.exp(log_q_diag)), jnp.exp(log_r)[None, None]).K
    _, xs, _ = cx.simulate(SYS, X0, lambda t, x: -K @ x, num_steps=80)
    return jnp.sum(xs**2) + 1e-2 * jnp.sum((xs[:-1] @ K.T) ** 2)


cost, (dq, dr) = jax.jit(jax.value_and_grad(closed_loop_cost, argnums=(0, 1)))(
    jnp.zeros(2), jnp.array(0.0)
)
This is the central Contrax idea: control primitives that behave like normal JAX building blocks.
Scope
Systems
ss, dss, c2d, nonlinear_system, phs_system, canonical_J,
schedule_phs, linearize, linearize_ss, phs_to_ss, series, parallel
Simulation
lsim, simulate, rollout, step_response, impulse_response,
initial_response, sample_system, foh_inputs
Continuous LTI lsim accepts an explicit sample grid with ZOH or FOH inputs.
Simulation results report numerical status and step counts; sampled models
retain integration diagnostics through model.step(t, x, u). Native Diffrax
solvers and step-size controllers configure continuous integration.
Control
lqr, lqi, dare, care, place, feedback, state_feedback,
augment_integrator
Estimation
kalman, ekf, ukf, rts, uks
kalman_predict, kalman_update, kalman_step
ekf_predict, ekf_update, ekf_step
kalman_gain, mhe_objective, mhe, mhe_warm_start
Analysis
ctrb, obsv, poles, evalfr, freqresp, dcgain,
ctrb_gramian, obsv_gramian, lyap, dlyap, zeros,
quadratic_rollout_cost
Diagnostics
innovation_diagnostics, likelihood_diagnostics, ukf_diagnostics,
smoother_diagnostics, phs_diagnostics, innovation_rms
Parameterization
positive_exp, positive_softplus, spd_from_cholesky_raw, diagonal_spd,
lower_triangular
Interoperability
contrax.compat.python_control — optional bidirectional conversion with
python-control (uv add control)
Lyapunov solvers return a validated result bundle:
result = cx.dlyap(A, Q, solver=cx.solvers.Lyapunov())
X = result.X  # Check result.successful before using an unfamiliar equation.
lyap and dlyap support implicit forward/reverse differentiation, stable-system
doubling and explicit general dense solves. Automatic dense fallback is bounded
to eight states. See analysis for the equation and failure
contracts.
Solver Status
dare— structured doubling with implicit JVP/VJP, scale-aware residual and stability checks.care— Hamiltonian stable-subspace solve with accepted Newton corrections and implicit JVP/VJP. Closely separated subspaces can limit accuracy.place— design-time KNV0/YT pole placement with achieved-assignment and conditioning checks, solver configuration, and bounded SISO fallback.ekf/ukf/rts/uks— linear and nonlinear filtering and smoothing with JIT, batching and differentiation support.mhe— LBFGS-backed fixed-window MHE. Useful optimization-based estimation primitive; not a full NLP framework.
LTI workflows are the most mature slice. Nonlinear models, PHS support, and fixed-window MHE are real public capabilities, but they should be read with more explicit solver-maturity caution than the core discrete design path.
Development
git clone https://github.com/givani30/Contrax.git
cd Contrax
uv sync --group dev
uv run pre-commit install
uv run pytest tests/ -q
See CONTRIBUTING.md for contribution guidelines.
Acknowledgements
Contrax is built on top of several excellent JAX-ecosystem libraries:
- JAX — the foundation: JIT compilation, autodiff, and vectorization.
- Equinox — pytree-compatible modules used for all result bundles and system types.
- Diffrax — ODE solvers powering
simulate()on continuous-time models. - Optimistix — LBFGS solver backing
mhe(). - Lineax — linear solvers used in the estimation and Riccati paths.
The DARE implicit differentiation approach draws on trajax (Google) and the DiLQR approach (ICML 2025). The UKF sigma-point rules follow Wan & van der Merwe (2000).
1 maintainer

Metadata
1 maintainer
Release files for contrax 0.2.1
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | Provenance | Actions |
|---|---|---|---|---|
| contrax-0.2.1.tar.gz | 128.9 kB | Without provenance | Details for contrax-0.2.1.tar.gz |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Actions Reset |
|---|---|---|---|---|
| contrax-0.2.1-py3-none-any.whl | Python 3 | none | any | Details for contrax-0.2.1-py3-none-any.whl |
Total release size: 232.9 kB
Release files / contrax-0.2.1.tar.gz
| Download URL | contrax-0.2.1.tar.gz |
|---|---|
| Size | 128.9 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
5bb2e0efd1afd6e1b688644fdeb115603d46c9c493370a9f17b688e99bd0a39c
|
|
BLAKE2b-256 checksum How to use checksums |
1b3660f2bcd5e0070d41c8122f0993ba582677b9fc71f125260b69123c3731d1
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
uv/0.13.5 {"installer":{"name":"uv","version":"0.13.5","subcommand":["publish"]},"python":null,"implementation":{"name":null,"version":null},"distro":{"name":"Arch Linux","version":null,"id":null,"libc":null},"system":{"name":null,"release":null},"cpu":null,"openssl_version":null,"setuptools_version":null,"rustc_version":null,"ci":null}
|
Release files / contrax-0.2.1-py3-none-any.whl
| Download URL | contrax-0.2.1-py3-none-any.whl |
|---|---|
| Size | 104.0 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
9323be8a28699b596a43f7acebab37a2b72d5d613eb4352e491c80638075a022
|
|
BLAKE2b-256 checksum How to use checksums |
f27caf7f685bb943b23752da743188ceb68461b174819fd4e51d6ad064de0b34
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
uv/0.13.5 {"installer":{"name":"uv","version":"0.13.5","subcommand":["publish"]},"python":null,"implementation":{"name":null,"version":null},"distro":{"name":"Arch Linux","version":null,"id":null,"libc":null},"system":{"name":null,"release":null},"cpu":null,"openssl_version":null,"setuptools_version":null,"rustc_version":null,"ci":null}
|
Security for contrax 0.2.1
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
No provenance found
None of the files in this release were uploaded with provenance metadata.
A note on package security
PyPI is a repository for distributing packages, not a service for auditing them. While third-party security researchers and our staff do their best to detect and remove malicious packages, PyPI cannot guarantee the quality, security or suitability of any given package.
To learn more about protecting yourself from malicious actors, visit our package security documentation.














