
Creature Lab
Stress-test a real robot, see exactly why it fell, and prove the fix.
On a laptop, in a browser.


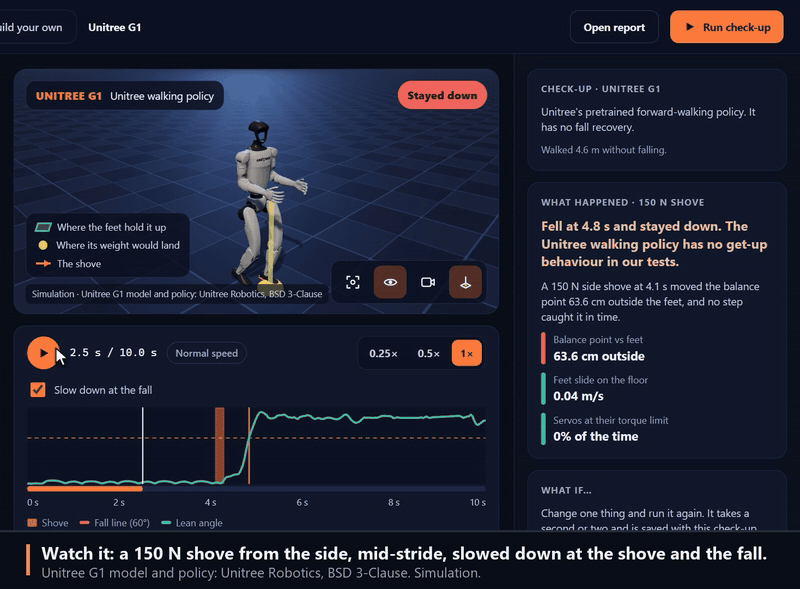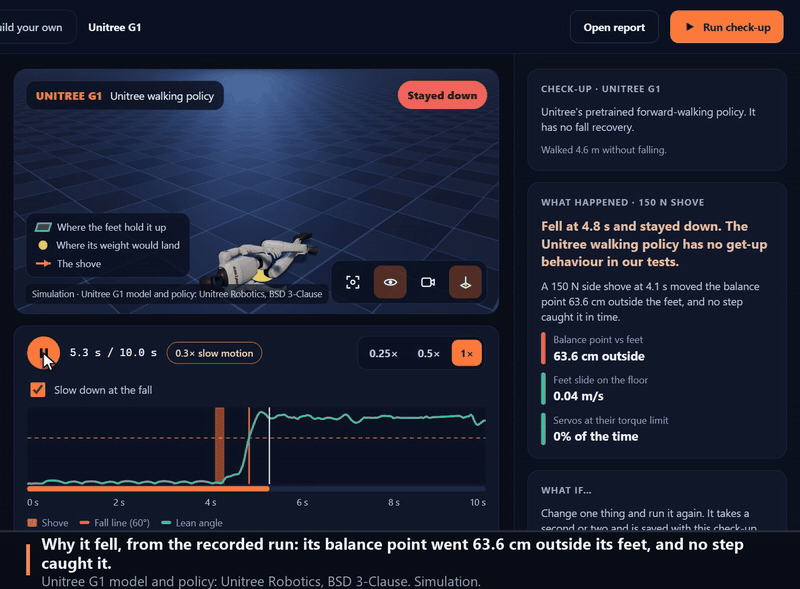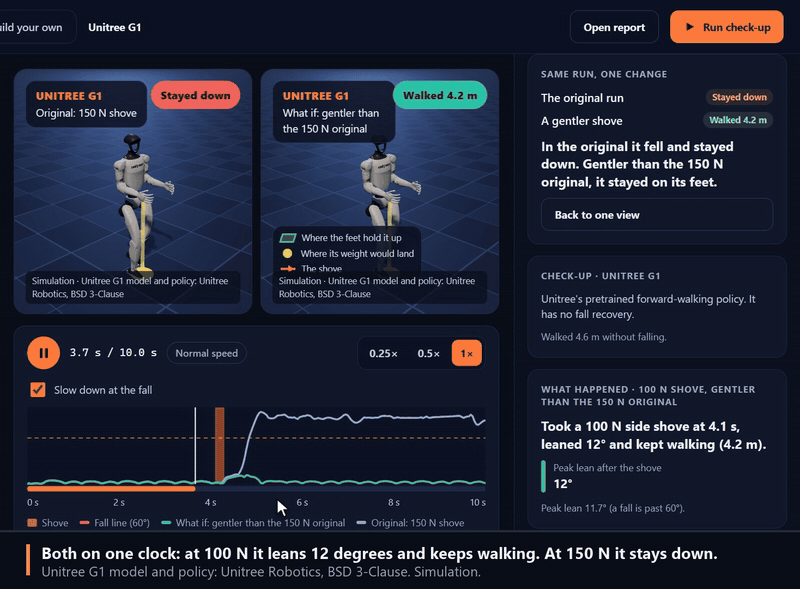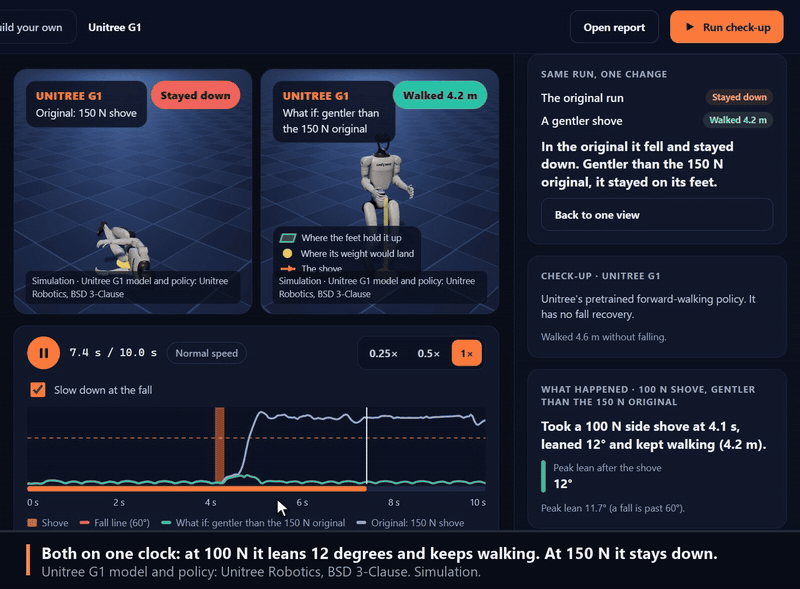
The real app on saved runs: a 150 N shove, why it fell, and one click to try it gentler. Watch the 1-minute tour. Unitree G1 model and policy by Unitree Robotics, BSD 3-Clause. Simulation.
Creature Lab runs published robots with their real trained walking policies. It shoves them at dozens of strengths and moments, walks them over stairs, ramps, rough ground and stepping stones, and tries a failing motor, late commands, slippery floors, loads and weak batteries. Then it explains every fall from the recorded evidence: where the weight went relative to the feet, how fast the feet slid, whether a foot caught a step or missed a stone, and whether the motors ran out of torque. Change one thing, or swap the policy, and see whether the fall is fixed. The physics runs on the CPU (MuJoCo). It is a simulation, not the hardware.
Try it
uvx --from "creature-lab[app]" creature-lab # or: pip install "creature-lab[app]", then creature-lab
Or from a clone, which also gives you the classic editor and the tests:
git clone https://github.com/oney-erge/Creature-Lab.git
cd Creature-Lab
./run.sh            # macOS: ./run.command   Windows: run.bat
Either way it installs prebuilt packages only (no compiler, about 300 MB) and opens the app. Press Download and check up on the Unitree G1 and accept its license. On a laptop, the download and the whole check-up (40 shoves, then uneven ground, weak motors, late commands, slippery floors and loads) took 47 s from an empty cache.
What you can do
- Watch a shove in 3D, slowed down at the shove and the fall. The app draws the floor area that holds the robot up and the point where its weight would land.
- Read why it fell in plain words, with the numbers behind it.
- Walk it over uneven ground: stairs, a ramp, rough ground and stepping stones, sized to the robot. A fall there is explained as a toe caught on a step, a foot down a gap or a slope too steep.
- Ask "what if": shove from the other side, harder or gentler, on a slippery floor, slower, faster or carrying a load. It runs again in about a second and plays beside the original.
- Compare policies on the same test. The 29-joint Unitree G1 has two policies trained for Creature Lab, one with small shoves and one with strong shoves; the Microduck has Pollen's walk-only and walk-and-get-up policies. A robot with more than two lets you pick which to compare.
- Bring your own robot and policy: a MuJoCo model, an ONNX policy and a small
robot.toml(robots validate,robots add; guide) get the same shoves and explanations. - Check for regressions from the command line:
robots comparesays which tests got better or worse between two check-ups (--fail-on-regressionfor CI), androbots cardwrites an SVG robustness card for a README or model card. - Build your own quadruped, hexapod, worm or humanoid with sliders, and run it.
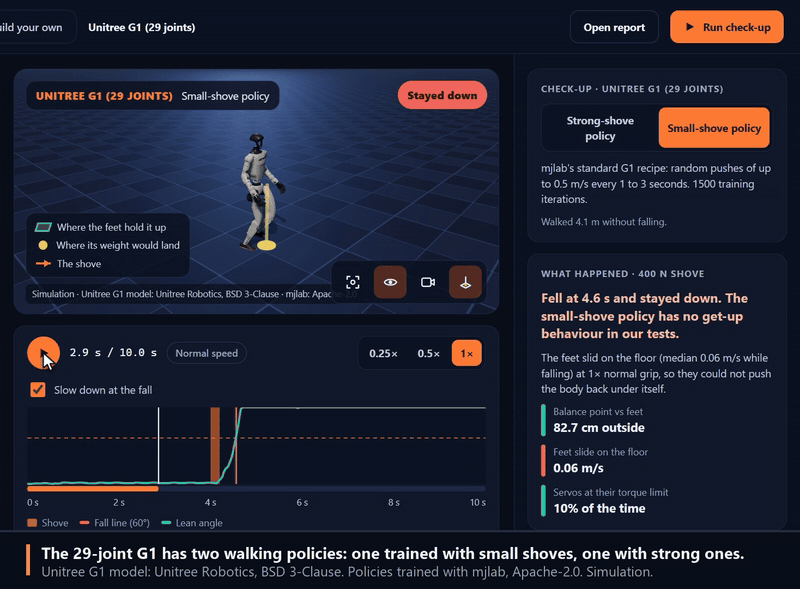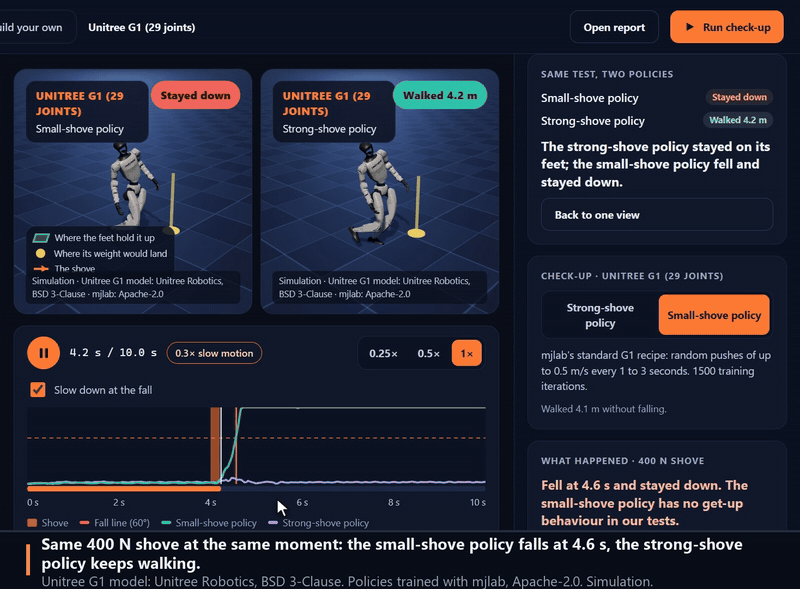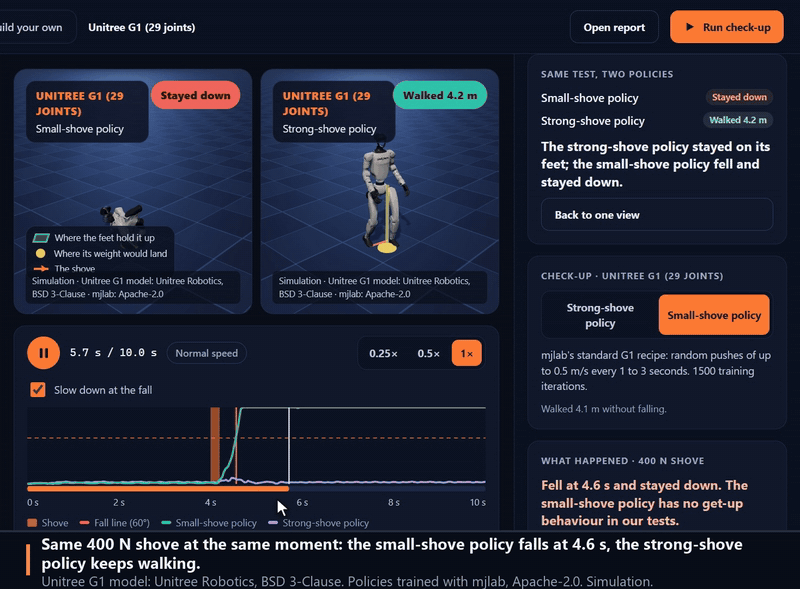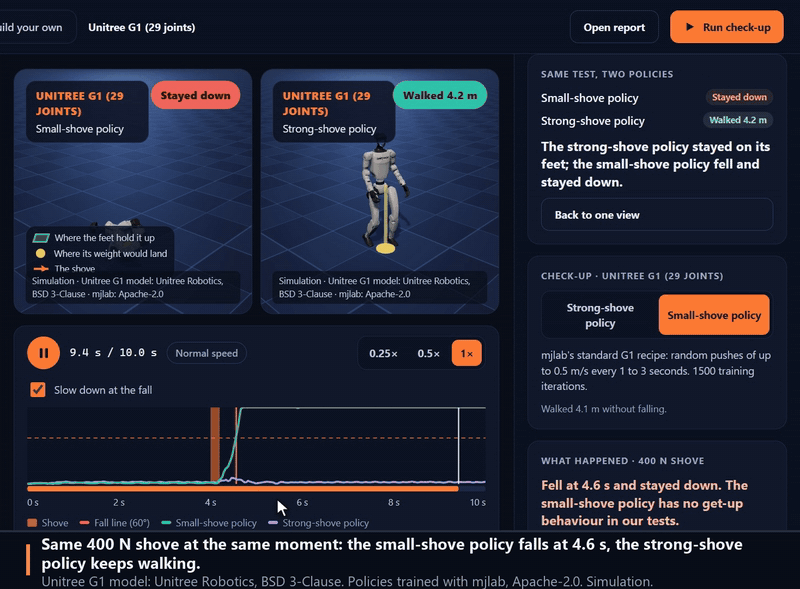
Same 400 N shove, same moment, two policies trained the same way except for how hard they were shoved in training (simulation). Over eight shoves at 400 N the small-shove policy fell 5 times, the strong-shove policy once. Unitree G1 model: Unitree Robotics, BSD 3-Clause.
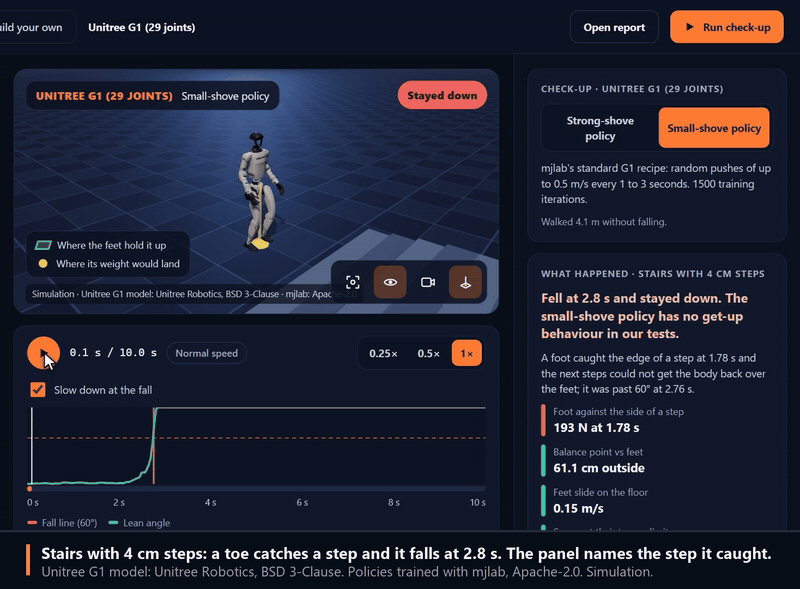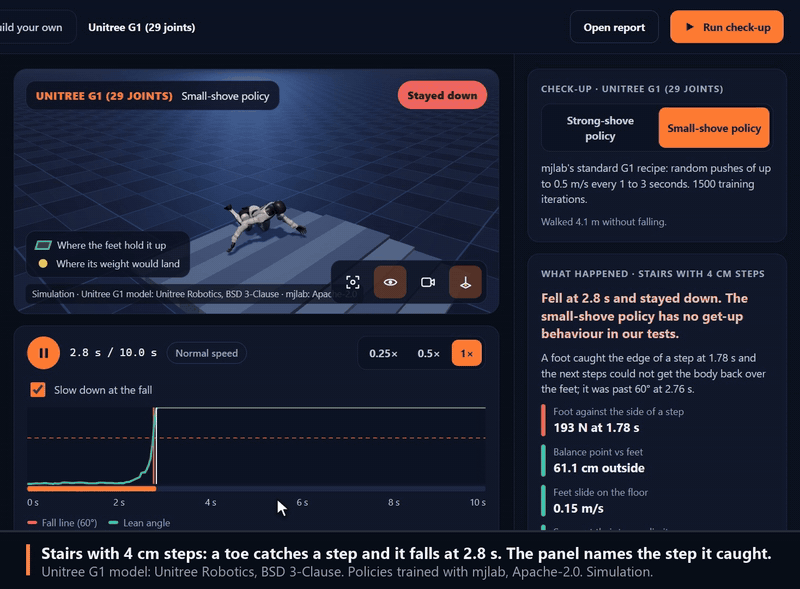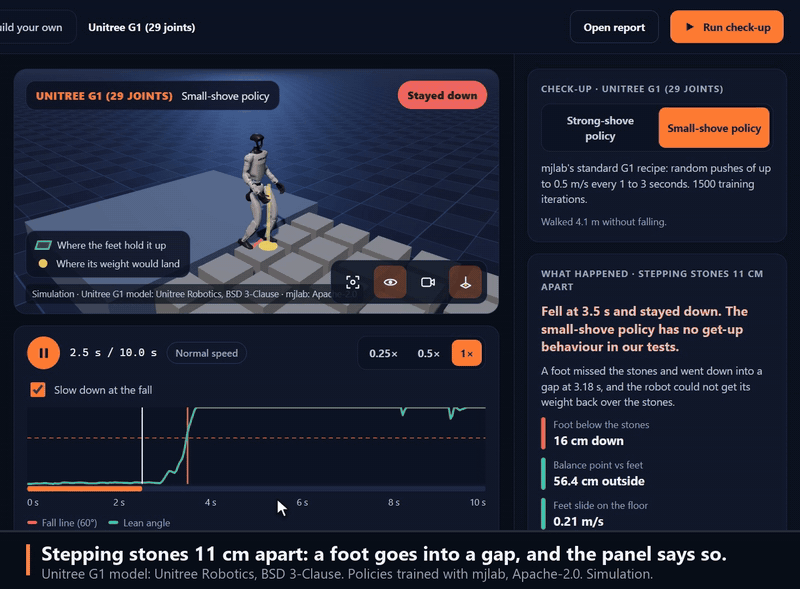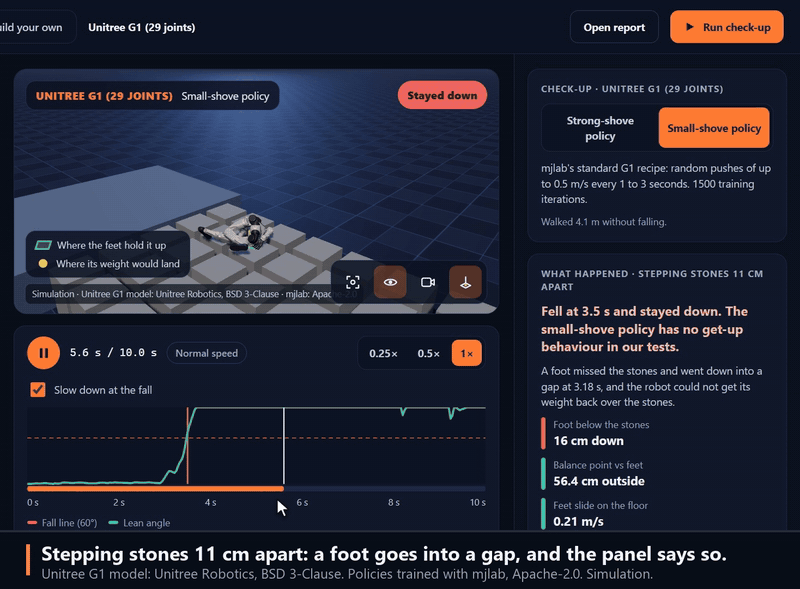
Uneven ground (simulation): stairs with 4 cm steps and stepping stones 11 cm apart. Neither of the G1's policies was trained on anything but a flat floor, and both fall on every stair height the check-up tries. Unitree G1 model: Unitree Robotics, BSD 3-Clause.
From the command line
uv sync --inexact --extra robots
uv run creature-lab robots checkup unitree-g1     # or: microduck
uv run creature-lab robots compare BEFORE_DIR AFTER_DIR --fail-on-regression
A check-up writes an HTML report; add --film for a 1080p film. See
Robot check-up for the tests, how falls are explained, licenses and limits.
Creature Lab started as a workbench for designing modular robots, and that is still here: a zoo of
working and deliberately broken creatures, a part-by-part build editor with URDF import and export,
root-cause diagnosis, and search for better bodies and gaits (creature-lab zoo, build,
autopsy, evolve). PyBullet is optional for these (uv sync --inexact --extra sim); outside
Linux it is built from source and needs a C++ compiler, so the launcher leaves it out and MuJoCo is
used instead.
What it is not
A teaching and prototyping tool, not hardware qualification, a cloud service or large-scale GPU training. Check-ups are deterministic simulations of published models; a robot that passes here can still fall on a real floor.
Documentation
| Guide | Use it for |
|---|---|
| Browser app | Robots, replays, "what if" and check-ups in the app |
| Robot check-up | The tests, how falls are explained, licenses |
| Getting started | A first experiment, and troubleshooting |
| CLI reference | Every command and export |
| Known issues | Current limitations |
| All documentation | Build editor, zoo, failure lab, schemas, contributing |
If the launcher fails, it prints what to do; uv run creature-lab doctor checks the setup. Docker
serves the same app on localhost: ./run.sh docker.
Apache-2.0. Built by Oney Erge.
1 maintainer

Metadata
1 maintainer
Release files for creature-lab 0.4.2
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | Provenance | Actions |
|---|---|---|---|---|
| creature_lab-0.4.2.tar.gz | 8.7 MB | With provenance | Details for creature_lab-0.4.2.tar.gz |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Actions Reset |
|---|---|---|---|---|
| creature_lab-0.4.2-py3-none-any.whl | Python 3 | none | any | Details for creature_lab-0.4.2-py3-none-any.whl |
Total release size: 12.5 MB
Release files / creature_lab-0.4.2.tar.gz
| Download URL | creature_lab-0.4.2.tar.gz |
|---|---|
| Size | 8.7 MB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
5897025ddad2a37248fd5d5f2227d579404a66969a0be9100ed0a0705cdb41b0
|
|
BLAKE2b-256 checksum How to use checksums |
0d4dd8f50d9c3d82964d125d3c45ea106f0510716c73dbaede1ac16c9008b2f1
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.16
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.


PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Nov 12, 2026.
Transparency logRelease files / creature_lab-0.4.2-py3-none-any.whl
| Download URL | creature_lab-0.4.2-py3-none-any.whl |
|---|---|
| Size | 3.8 MB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
3227a8005113d1de79307d79f3a3cd50d3fa1eee189cd3930d67fa05f49f5238
|
|
BLAKE2b-256 checksum How to use checksums |
d2c436c4d5a4dac08b13a7360d795fc48811200b8cca5cc59d580bea5e8224ad
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.16
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Nov 12, 2026.
Transparency logSecurity for creature-lab 0.4.2
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
Full provenance
Both files in this release have been uploaded with provenance metadata.
Attestation for creature_lab-0.4.2.tar.gz
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Nov 12, 2026.
Transparency logA note on package security
PyPI is a repository for distributing packages, not a service for auditing them. While third-party security researchers and our staff do their best to detect and remove malicious packages, PyPI cannot guarantee the quality, security or suitability of any given package.
To learn more about protecting yourself from malicious actors, visit our package security documentation.














