
Dexterous manipulation. Simulated, teleoperated, benchmarked.
All in one framework.
Website · Documentation · Datasets
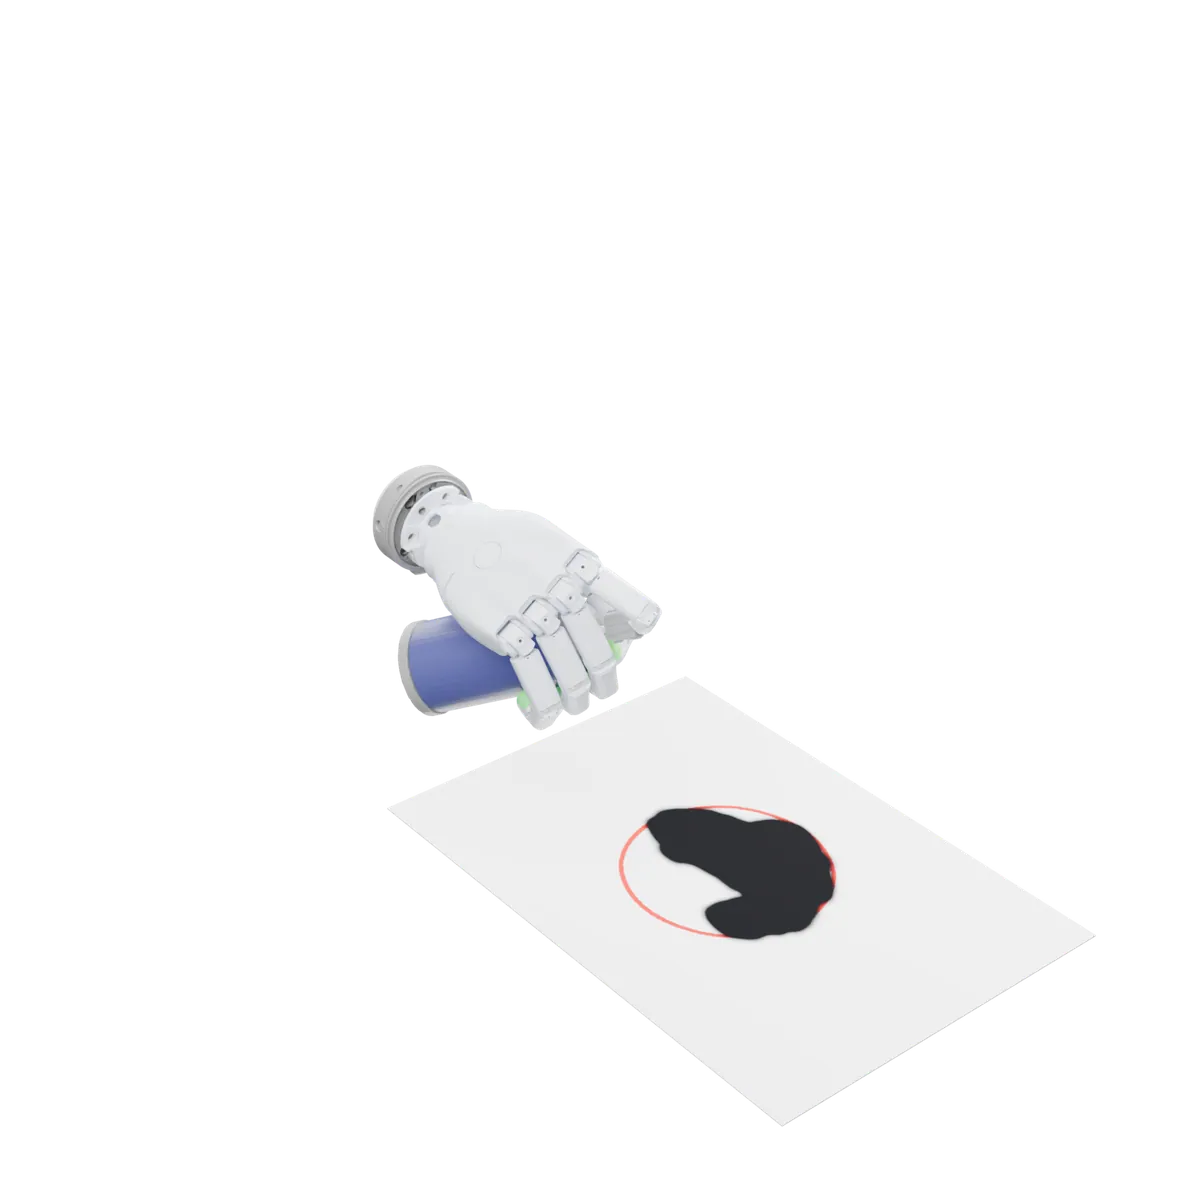
DexSuite brings the robot, the tasks, teleoperation, tactile sensing, the data and the evaluation into one stack, on the Genesis simulator. A task is written once and runs with any arm and any hand, from a parallel-jaw gripper to a 24-joint hand.
Install
pip install dexsuite                # every arm, hand and task
pip install "dexsuite[all]"         # plus SpaceMouse, Vive and Manus teleoperation and the LeRobot dataset tools
Python 3.10 or newer and a CUDA GPU (the CPU works for a quick look). The first environment on a machine compiles the
Genesis kernels, which takes about a minute. On a machine without a display, export PYOPENGL_PLATFORM=egl.
| Tasks | Reach, Lift, Push, Pick & Place, Stack, Rack Mug, Move Pan, Drill to Point, Place Fruits, Make Coffee, Tool Hang and the bimanual set |
| Arms | Franka Panda, Franka FR3, Kinova Gen3, KUKA iiwa 14, Rethink Sawyer, UR5e, UR10e, UFactory Lite 6, Link6, Unitree Z1, and six integrated robots |
| End-effectors | Robotiq 2F-85, UMI gripper, Allegro Hand, BarrettHand, D'Claw, Inspire, Ability, Schunk SVH, LEAP and Shadow hands |
[all] |
SpaceMouse, Vive and Manus teleoperation, LeRobot recording (0.4.4), HDF5 export |
Quickstart
import dexsuite as ds

env = ds.make("lift", manipulator="franka", gripper="allegro")
obs, info = env.reset(seed=0)

for _ in range(300):
    action = env.action_space.sample()       # 6 values move the hand, 16 set the Allegro joints
    obs, reward, terminated, truncated, info = env.step(action)
Every environment is a Gymnasium environment with batched PyTorch tensors: n_envs=64 builds 64 copies in one
simulator. The documentation covers the tasks, the robots, the actions and
observations, teleoperation and the benchmark datasets on Hugging Face.
Citation
@article{dexsuite2026,
  author  = {Anonymous},
  title   = {DexSuite: An All-in-One Framework for Dexterous Manipulation Across Arms, Hands, and Tasks},
  year    = {2026},
}
1 maintainer

Metadata
1 maintainer
Release files for dexsuite 0.1.0
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Actions Reset |
|---|---|---|---|---|
| dexsuite-0.1.0-py3-none-any.whl | Python 3 | none | any | Details for dexsuite-0.1.0-py3-none-any.whl |
Release files / dexsuite-0.1.0-py3-none-any.whl
| Download URL | dexsuite-0.1.0-py3-none-any.whl |
|---|---|
| Size | 88.7 MB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
6c3f39466c81c8e5ce3229c3f8c698a4c2c147074f39ceeed0c4bab9ed40118b
|
|
BLAKE2b-256 checksum How to use checksums |
a0fcacf0e38f96d914f460bc8b136659ce98b700d1797b81c0f2b26f02e42940
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/7.0.0 CPython/3.11.17
|
Security for dexsuite 0.1.0
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
No provenance found
None of the files in this release were uploaded with provenance metadata.
A note on package security
PyPI is a repository for distributing packages, not a service for auditing them. While third-party security researchers and our staff do their best to detect and remove malicious packages, PyPI cannot guarantee the quality, security or suitability of any given package.
To learn more about protecting yourself from malicious actors, visit our package security documentation.














