
e3nn
E(3) is the Euclidean group in dimension 3. That is the group of rotations, translations and mirror.
e3nn is a pytorch library that aims to create E(3) equivariant neural networks.
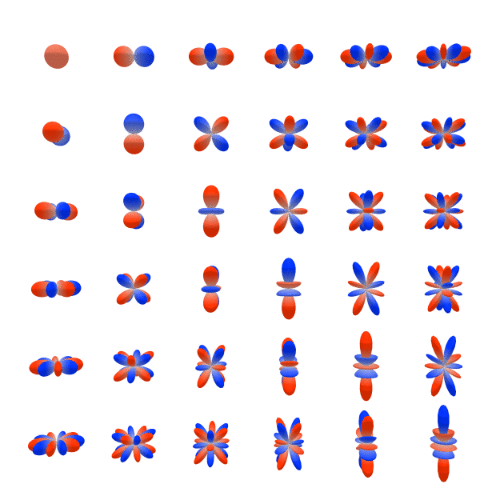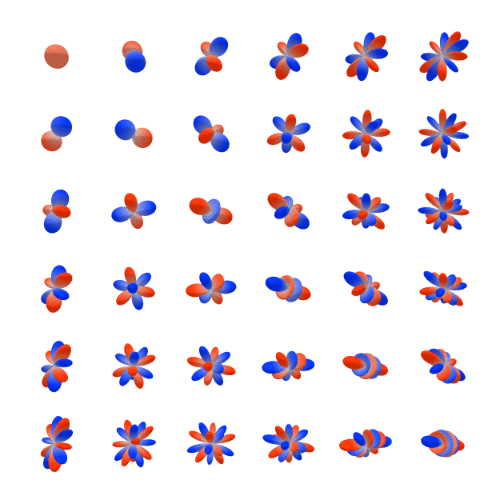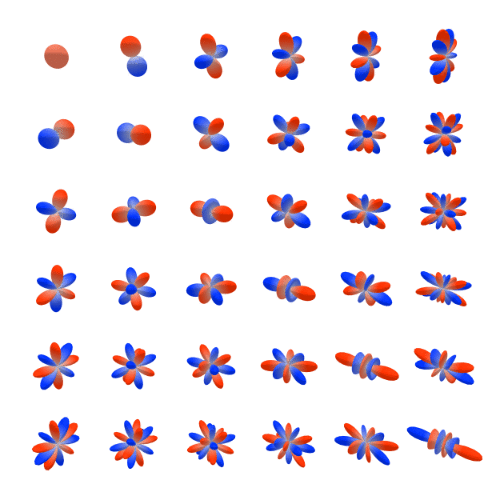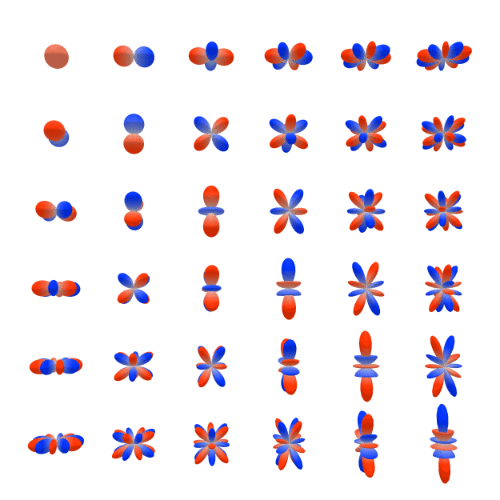
Example
from functools import partial

import torch

from e3nn.non_linearities.rescaled_act import swish
from e3nn.radial import GaussianRadialModel
from e3nn.kernel import Kernel
from e3nn.point.operations import Convolution
from e3nn.non_linearities.norm import Norm
from e3nn import rs

# Define the input and output representations
Rs_in = [(1, 0), (2, 1)]  # Input = One scalar plus two vectors
Rs_out = [(1, 1)]  # Output = One single vector

# Radial model:  R+ -> R^d
RadialModel = partial(GaussianRadialModel, max_radius=3.0, number_of_basis=3, h=100, L=1, act=swish)

# kernel: composed on a radial part that contains the learned parameters
#  and an angular part given by the spherical hamonics and the Clebsch-Gordan coefficients
K = partial(Kernel, RadialModel=RadialModel, normalization='norm')

# Use the kernel to define a convolution operation
C = partial(Convolution, K)

# Create the convolution module
conv = C(Rs_in, Rs_out)

# Module to compute the norm of each irreducible component
norm = Norm(Rs_out, normalization='norm')


n = 5  # number of input points
features = rs.randn(1, n, Rs_in, normalization='norm', requires_grad=True)
in_geometry = torch.randn(1, n, 3)
out_geometry = torch.zeros(1, 1, 3)  # One point at the origin


norm(conv(features, in_geometry, out_geometry)).backward()

print(features)
print(features.grad)
Hierarchy
e3nncontains the librarye3nn/o3.pyO(3) irreducible representationse3nn/rsh.pyreal spherical harmonicse3nn/rs.pygeometrical tensor representationse3nn/imagecontains voxels linear operationse3nn/pointcontains points linear operationse3nn/non_linearitiesnon linearities operations
examplessimple scripts and experiments
Installation
pip install git+https://github.com/e3nn/e3nn
To get the CUDA kernels read the instructions in INSTALL.md.
Citing

@software{e3nn_2020_3723557,
  author       = {Mario Geiger and
                  Tess Smidt and
                  Benjamin K. Miller and
                  Wouter Boomsma and
                  Kostiantyn Lapchevskyi and
                  Maurice Weiler and
                  Michał Tyszkiewicz and
                  Jes Frellsen},
  title        = {github.com/e3nn/e3nn},
  month        = mar,
  year         = 2020,
  publisher    = {Zenodo},
  version      = {v0.3-alpha},
  doi          = {10.5281/zenodo.3723557},
  url          = {https://doi.org/10.5281/zenodo.3723557}
}
2 maintainers


Release files for e3nn 0.0.0
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | |
|---|---|---|---|
| e3nn-0.0.0.tar.gz | 607.5 kB | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| e3nn-0.0.0-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 1.3 MB
Release files / e3nn-0.0.0.tar.gz
| Download URL | e3nn-0.0.0.tar.gz |
|---|---|
| Size | 607.5 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
f86909a2fdeee807024791258de13e7e8a8411fb0d489cc8f5519b3483aaea17
|
|
BLAKE2b-256 checksum How to use checksums |
0d002fce38a34891b8ce5a95905b8cac955bc168e7d7cf4d57a1456a5b29964b
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/3.1.1 pkginfo/1.5.0.1 requests/2.23.0 setuptools/41.2.0 requests-toolbelt/0.9.1 tqdm/4.46.0 CPython/3.8.3
|
Release files / e3nn-0.0.0-py3-none-any.whl
| Download URL | e3nn-0.0.0-py3-none-any.whl |
|---|---|
| Size | 701.7 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
0a84b301f065ad371d608ce71d7ffde8bfdee7df9d3d3a532fa858f03b8d7e93
|
|
BLAKE2b-256 checksum How to use checksums |
ed3441ec81a75d116c5ccd327a8dade0f3fe114b78c6841001fcf030cd1b901f
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/3.1.1 pkginfo/1.5.0.1 requests/2.23.0 setuptools/41.2.0 requests-toolbelt/0.9.1 tqdm/4.46.0 CPython/3.8.3
|














