


Documentation for this package can be found at https://python-graphslam.readthedocs.io/.
This package implements a Graph SLAM solver in Python.
Features
Optimize R^2, R^3, SE(2), and SE(3) datasets
Analytic Jacobians
Supports odometry and landmark edges
Supports custom edge types (see tests/test_custom_edge.py for an example)
Import and export .g2o files
Installation
pip install graphslamExample Usage
SE(3) Dataset
>>> from graphslam.graph import Graph

>>> g = Graph.from_g2o("data/parking-garage.g2o")  # https://lucacarlone.mit.edu/datasets/

>>> g.plot(vertex_markersize=1)

>>> g.calc_chi2()

16720.02100546733

>>> g.optimize()

>>> g.plot(vertex_markersize=1)
Output:
Iteration                chi^2        rel. change
---------                -----        -----------
        0           16720.0210
        1              45.6644          -0.997269
        2               1.2936          -0.971671
        3               1.2387          -0.042457
        4               1.2387          -0.000001
Original |
Optimized |
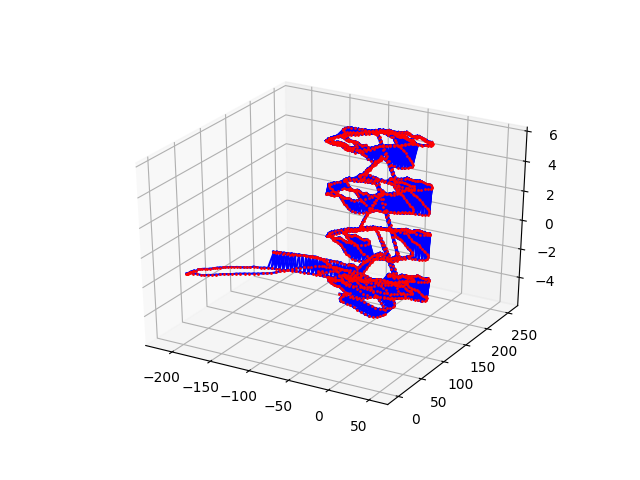
|
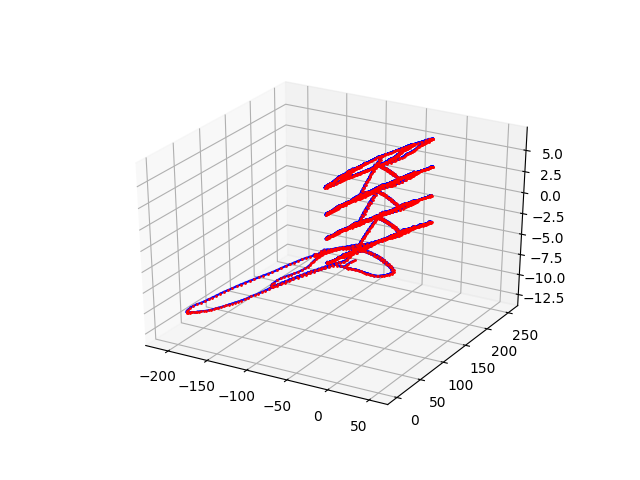
|
SE(2) Dataset
>>> from graphslam.graph import Graph

>>> g = Graph.from_g2o("data/input_INTEL.g2o")  # https://lucacarlone.mit.edu/datasets/

>>> g.plot()

>>> g.calc_chi2()

7191686.382493544

>>> g.optimize()

>>> g.plot()
Output:
Iteration                chi^2        rel. change
---------                -----        -----------
        0         7191686.3825
        1       319950425.6477          43.488929
        2       124950341.8035          -0.609470
        3          338165.0770          -0.997294
        4             734.7343          -0.997827
        5             215.8405          -0.706233
        6             215.8405          -0.000000
Original |
Optimized |
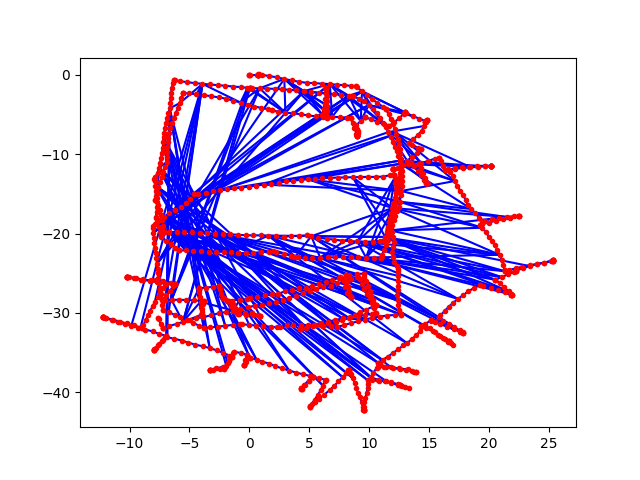
|
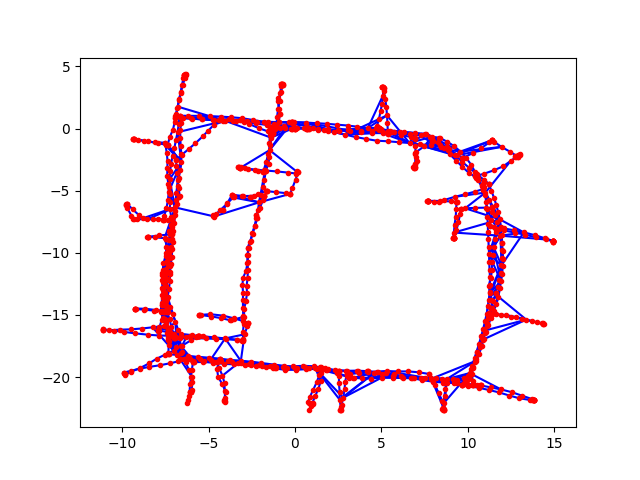
|
References and Acknowledgments
Grisetti, G., Kummerle, R., Stachniss, C. and Burgard, W., 2010. A tutorial on graph-based SLAM. IEEE Intelligent Transportation Systems Magazine, 2(4), pp.31-43.
Blanco, J.L., 2010. A tutorial on SE(3) transformation parameterizations and on-manifold optimization. University of Malaga, Tech. Rep, 3.
Carlone, L., Tron, R., Daniilidis, K. and Dellaert, F., 2015, May. Initialization techniques for 3D SLAM: a survey on rotation estimation and its use in pose graph optimization. In 2015 IEEE international conference on robotics and automation (ICRA) (pp. 4597-4604). IEEE.
Carlone, L. and Censi, A., 2014. From angular manifolds to the integer lattice: Guaranteed orientation estimation with application to pose graph optimization. IEEE Transactions on Robotics, 30(2), pp.475-492.
Thanks to Luca Larlone for allowing inclusion of the Intel and parking garage datasets in this repo.
Live Coding Graph SLAM in Python
If you’re interested, you can watch as I coded this up.
1 maintainer

Release files for graphslam 0.0.17
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | |
|---|---|---|---|
| graphslam-0.0.17.tar.gz | 35.5 kB | Details |
Release files / graphslam-0.0.17.tar.gz
| Download URL | graphslam-0.0.17.tar.gz |
|---|---|
| Size | 35.5 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
482770a1e6aea732bbc5944d83a65e1ed74c458e29fc40b69f33178a3a87b574
|
|
BLAKE2b-256 checksum How to use checksums |
191204ff8145ef171b81fec9042f156e903a14656f290778d0433f14c7842d07
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/4.0.2 CPython/3.11.6
|














