
gym-sailing: A sailing environment for OpenAI Gym / Gymnasium
This is a Gymnasium (OpenAI Gym) environment designed to train reinforcement learning (RL) agents to control a sailboat. The environment simulates the dynamics of a sailboat and allows the agent to learn tacking behavior to reach a target point.
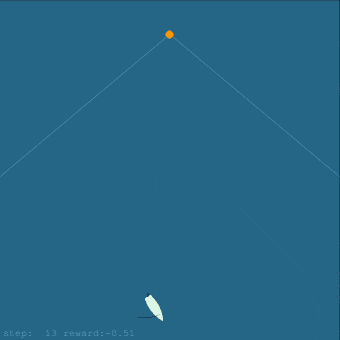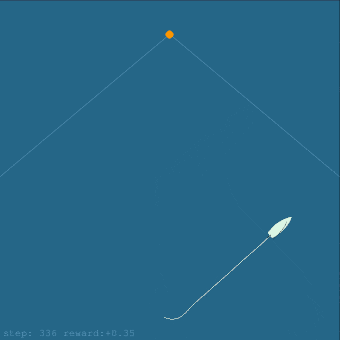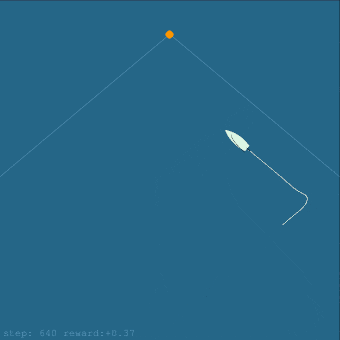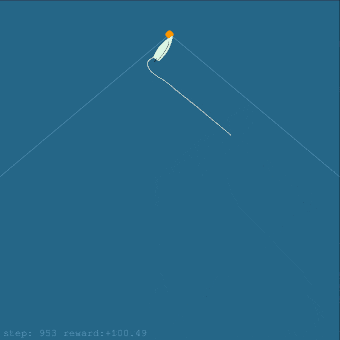
Environments
| Environment | Description |
|---|---|
| Sailboat-v0 | The main environment with a continuous action space. |
| SailboatDiscrete-v0 | A variation of the environment with a discrete action space. |
| Motorboat-v0 | An easy test environment with a motorboat instead of a sailboat. |
Installation
You can install the latest release using pip:
pip install gym-sailing
Alternatively, if you prefer, you can clone the repository and install it locally.
Usage
Basic Usage
Bare minimum code to run the environment:
import gymnasium as gym
import gym_sailing

env = gym.make("Sailboat-v0", render_mode="human")
observation, info = env.reset(seed=42)

for _ in range(1000):
    action = env.action_space.sample()  # this is where you would insert your policy
    observation, reward, terminated, truncated, info = env.step(action)

    if terminated or truncated:
        observation, info = env.reset()

env.close()
Training an RL Agent
To train an RL agent using stable-baselines3:
from stable_baselines3 import PPO
import gymnasium as gym
import gym_sailing

env = gym.make("Sailboat-v0")
model = PPO('MlpPolicy', env, verbose=1)

# Train the agent
model.learn(total_timesteps=1_000_000)

# Test the trained model
observation, info = env.reset()
for _ in range(1000):
    action, _ = model.predict(observation)
    observation, reward, terminated, truncated, info = env.step(action)

env.close()
Environment Details
Observation Space
The observation space includes:
- Boat Speed: The current speed of the boat.
- Boat Heading: The angle of the boat relative to the wind, ranging from -$\pi$ to $\pi$.
- Heading Rate: The rate of change of the boat's heading.
- Course to Target: The angle between the boat's heading and the target, ranging from -$\pi$ to $\pi$.
- Distance to Target: The normalized distance between the boat and the target.
Action Space
The action space consists of:
- Rudder Angle: The angle of the rudder, ranging from -1 to 1 for Sailboat-v0 and Motorboat-v0, and {-1, 0, 1} for SailboatDiscrete-v0.
Reward
The default reward function includes:
- Alive Penalty: A penalty for each time step to encourage the agent to reach the target quickly.
- Target Reward: A reward for reaching the target.
- Course Penalty: A penalty for leaving the course area.
- Progress Reward: A reward for making progress towards the target, using the L8 norm, to encourage the agent to move upwind.
Episode End
- The environment is terminated if the boat reaches the target or leaves the course area.
- The environment is truncated after 3000 steps.
Benchmarks
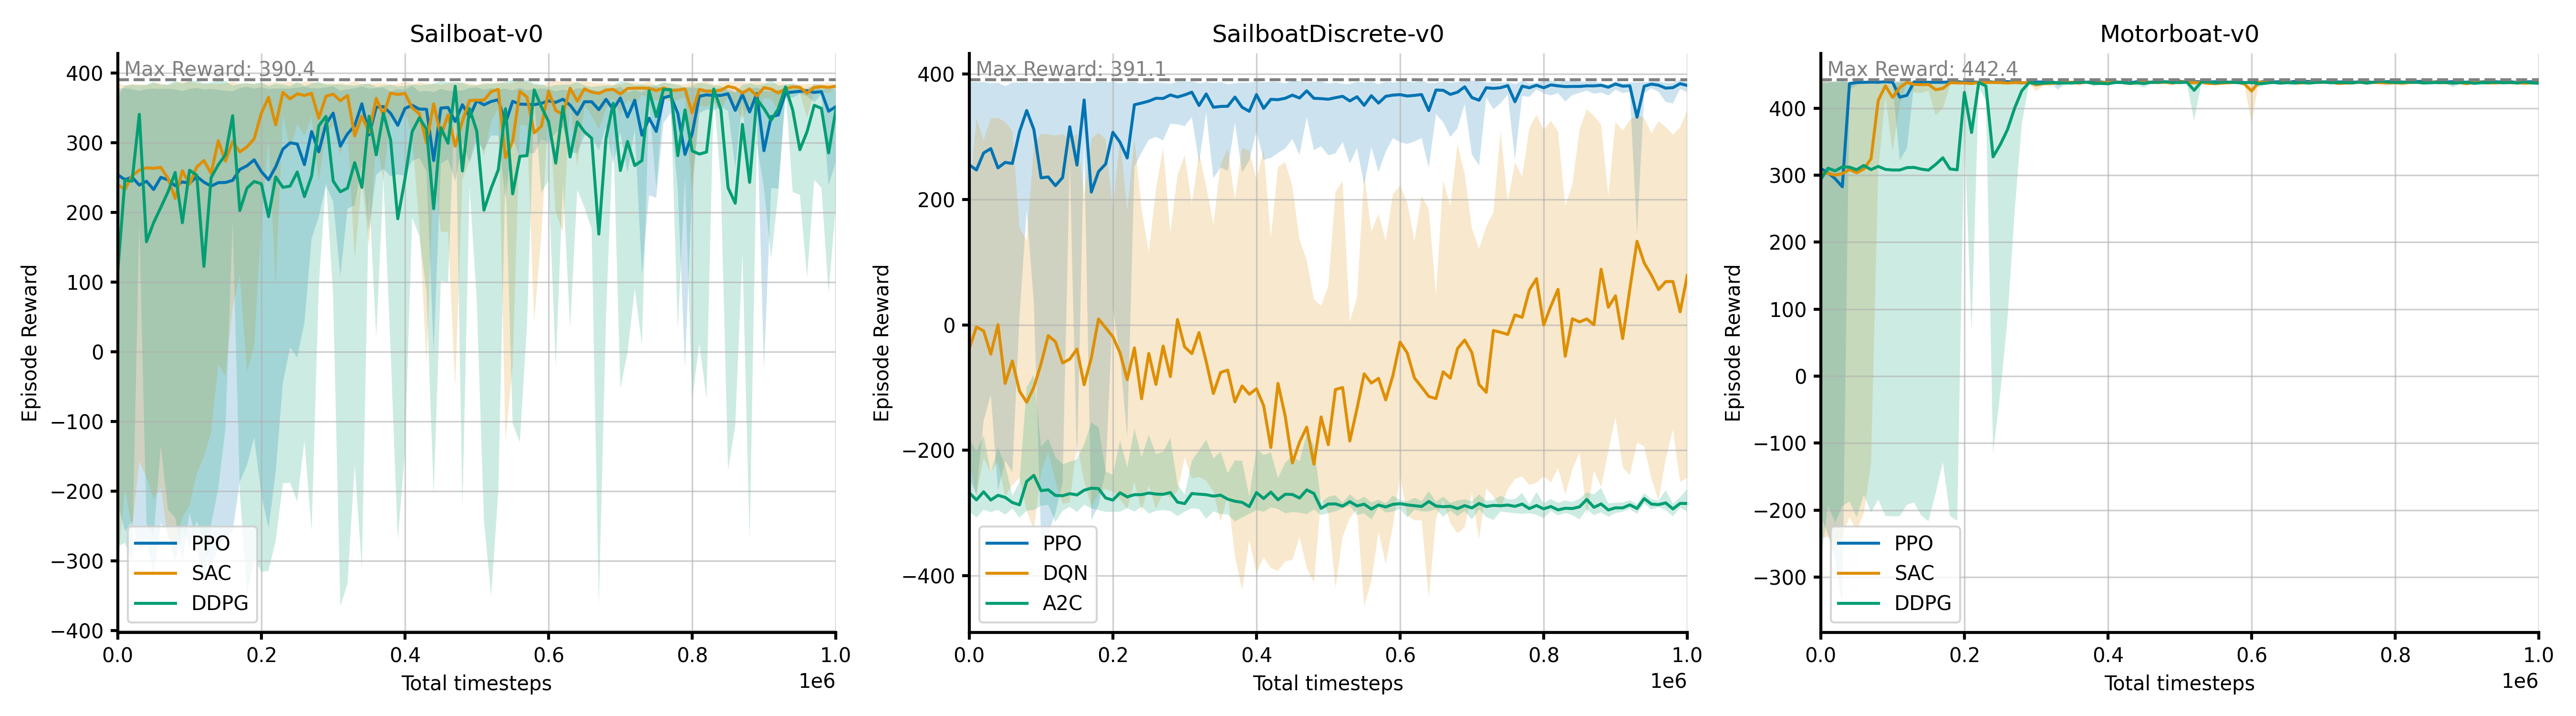
Benchmarks using stable-baselines3 with default hyperparameters. Good policies that tack only once tend to achieve ~390 total reward for the sailboat environment. PPO seems to perform better, but SAC is also a good option, that even converging faster.
Contributing
Contributions are welcome. Please fork the repository and submit a pull request with your changes. For any questions or suggestions, feel free to open an issue.
Future Work
Here are some features I'd like to add in the future:
- Add currents of different intensities and directions.
- Add wind shifts.
- Add wind gusts and lulls.
- Make the polar diagram more accurate, using the data from this paper: R. Binns, F. W. Bethwaite, and N. R. Saunders, “Development of A More Realistic Sailing Simulator,” High Performance Yacht Design Conference. RINA, pp. 243–250, Dec. 04, 2002. doi: 10.3940/rina.ya.2002.29.
Inspiration
This project was inspired by this fork: https://github.com/openai/gym/compare/master...JonAsbury:gym:Sailing-Simulator-Env
License
This project is licensed under the MIT License - see the LICENSE file for details.
1 maintainer

Metadata
1 maintainer
Release files for gym-sailing 0.2.1
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | |
|---|---|---|---|
| gym_sailing-0.2.1.tar.gz | 923.6 kB | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| gym_sailing-0.2.1-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 946.7 kB
Release files / gym_sailing-0.2.1.tar.gz
| Download URL | gym_sailing-0.2.1.tar.gz |
|---|---|
| Size | 923.6 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
67938c3e3df52580351b79fcf82c6131f2b078c6d14d50bfaa63e8ccd58fe568
|
|
BLAKE2b-256 checksum How to use checksums |
c7572527aac22527e0d0823ac9a5c4be22d9a52f5ded5671fb3ef50ba2565c79
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/5.1.1 CPython/3.11.4
|
Release files / gym_sailing-0.2.1-py3-none-any.whl
| Download URL | gym_sailing-0.2.1-py3-none-any.whl |
|---|---|
| Size | 23.1 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
4f49dc4180c54c7fc92837ae6fd5e1e15b32867a0cee3f0a47054891dc5cb397
|
|
BLAKE2b-256 checksum How to use checksums |
deb6b50efc6670694a41580f1bf04416d22f86ae71b4c8e103492659c4e544e9
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/5.1.1 CPython/3.11.4
|













