
HandoverLab

A system-level simulator for studying handover in dense 5G and beyond-5G networks, written in Python.
HandoverLab simulates 3GPP mobility procedures (baseline handover with Event A3, Release-16 conditional handover and DAPS handover, Release-18 L1/L2-triggered mobility) for many users moving through a street grid, an open area or along a highway, with a received-power-level radio model from TR 38.901, an L3-filtered measurement chain, a radio-link failure model, and an outcome label for every handover attempt.
Status: 1.0.2, a patch release of the first stable release 1.0.0 (
python -m pip install handoverlab). The public surface (configuration and result formats with a schema version, the rule interface, metric names, commands and the documented Python names) is frozen and follows the stability policy: within 1.x it only grows, and anything removed is deprecated first.
What 1.0.2 changes
Every link in the README is absolute, so the links also work on the PyPI project page; the README
links the documentation site and gives the Zenodo concept DOI; the package metadata state the
licence as an SPDX expression; the verify --ns3 help, a gate message and several documentation
pages are corrected. Results, fingerprints, job IDs and the public surface are as in 1.0.0.
What 1.0.1 changes
The dashboard image in the README has an absolute URL, so it also shows on the PyPI project page, and the README gives the Zenodo DOI of 1.0.0. Results, fingerprints, job IDs and the public surface are as in 1.0.0.
What 1.0.0 brings
1.0.0 is the first stable release: 1.0.0rc4 with the version and the release metadata set to 1.0.0, and HandoverLab is now installed from PyPI. Results, fingerprints, job IDs and the public surface are as in 1.0.0rc4. The release candidates before it added the following.
What 1.0.0rc4 changes
- Checked 3GPP citations: every clause, table and value cited in the scenario cards and the documentation was checked against the specifications; wrong clause numbers were corrected (for example, the highway lanes, lane width and road length are in TR 37.885 Table A-1, the inter-site distance of 500 m in clause 6.1.3), and the 35 m site offset is marked as an assumption.
- Documentation audit: stale statements, versions and option lists corrected; every example and code snippet checked.
Only text changed: results, fingerprints, job IDs and the public surface are as in 1.0.0rc3.
What 1.0.0rc3 adds
- A highway scenario (
highway-10ghz): a new layout kindhighway(the straight multi-lane road of the TR 37.885 highway case, roadside sites at a configurable spacing and offset) and lane-keeping vehicles at 70-140 km/h (profileshwy,hwy70,hwy140, or your own speed groups). See the how-to a highway. - Site lists from CSV files (
layout.sites_file), for every layout kind.
All of it is additive: existing defaults, results, fingerprints and study job IDs are unchanged.
What 1.0.0rc2 adds
- DAPS handover (Rel-16, rule
daps): the source keeps serving during the execution, and a failed execution falls back to the source instead of a re-establishment. - L1/L2-triggered mobility (Rel-18, rule
ltm): candidate cells configured in advance, cell switch decided on unfiltered L1 reports, a short RACH-less execution. Both come with base classes (DAPSRule,LTMRule) for your own rules and pass the rule contract kit. - A learning-based example rule (
a3_bandit): A3 offsets learned per cell by an epsilon-greedy bandit from the outcome labels. - An upper mid-band scenario (
fr3-urban-15ghz): the default grid at 15 GHz. - How-to guides: DAPS and LTM, a learning-based rule, the upper mid-band.
All of it is additive: existing defaults, results and fingerprints are unchanged.
What 1.0.0rc1 adds
- A frozen public surface: configuration and result files carry
schema: 1; a newer schema is refused with a clear message instead of being misread. The rule interface has a version, metric names are stable (renamed metrics keep their old name as a warning alias), and a deprecation helper warns before anything goes. A test compares the surface with a stored snapshot. See stability and the metric reference. - How-to guides: add a scenario, run on many cores, export event logs, reproduce and check results.
- Quality gates in CI: a lint job (ruff), a minimum test coverage, and a nightly workflow that runs the long verification on Linux and Windows and compares the golden fingerprints of both systems.
- Release plumbing: PyPI publishing with trusted publishing when a version tag is pushed, Zenodo metadata for an archived DOI, and the release steps in RELEASING.
What stage 4 adds
- Dashboard (
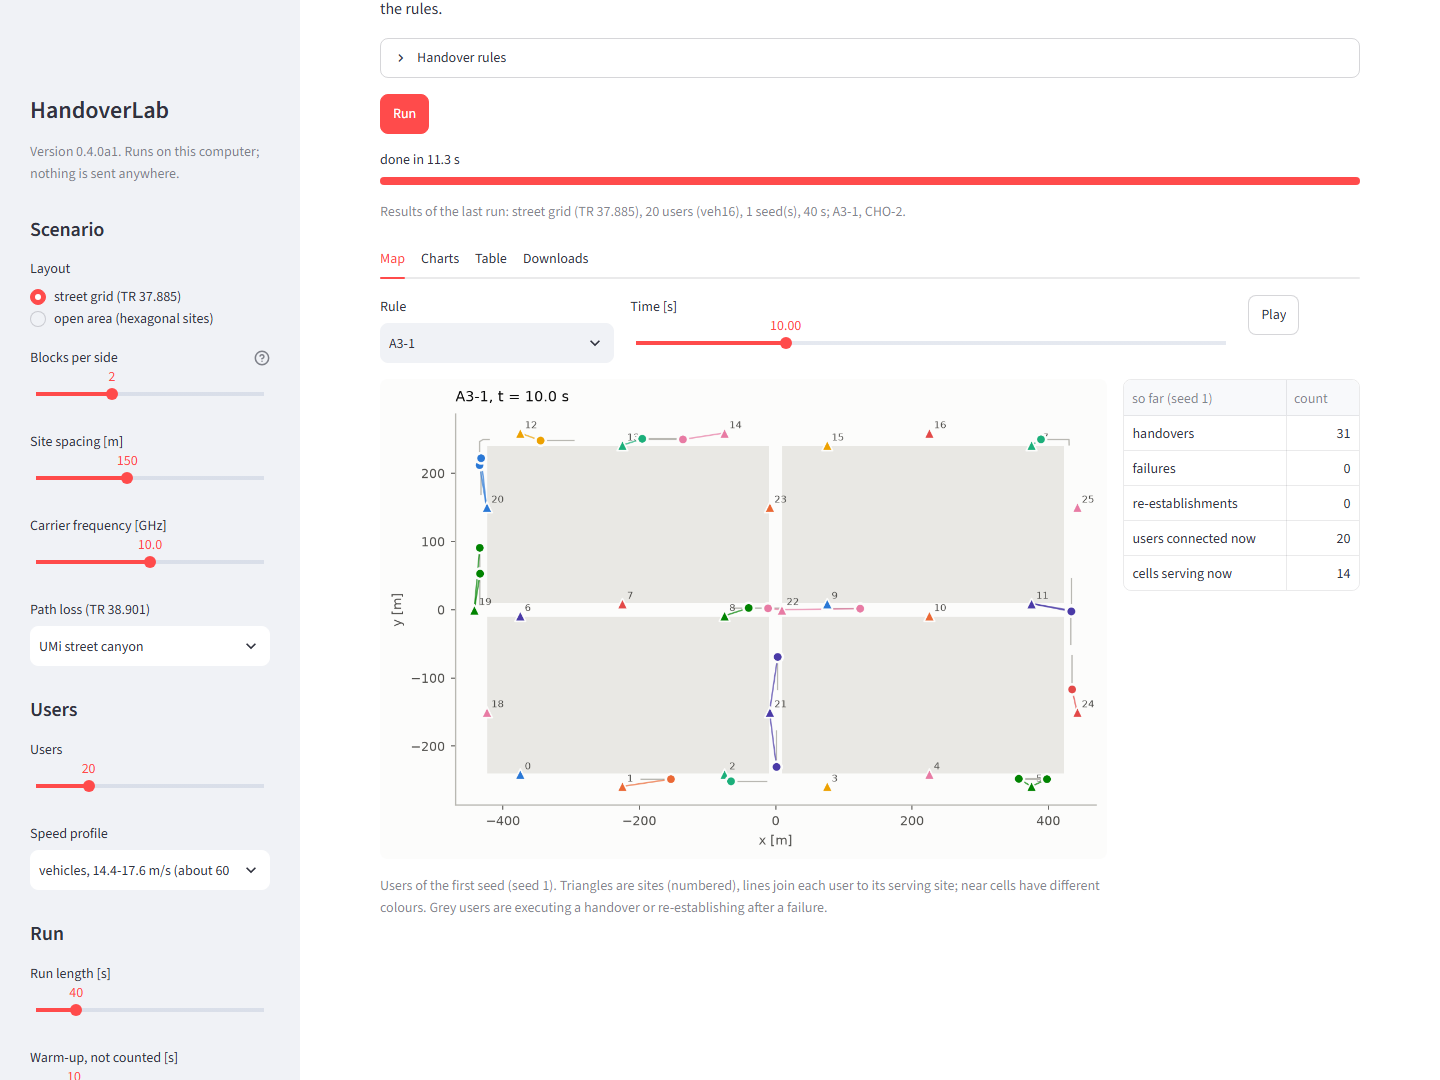
pip install "handoverlab[gui]", thenhandoverlab gui): a local page in the browser to pick a street grid or open area, speed profile, frequency, users and up to four rules with their parameters; a run button with progress; a map of the users moving on the layout, coloured by serving cell (time slider and play); charts of handovers, failures and rate; and downloads of the results (CSV, JSON, event logs), the figures and an experiment file thathandoverlab runrepeats exactly. It runs on your computer only; the core package does not depend on it. See the dashboard guide. - Tutorials and reference: your first run,
writing your own rule,
a fair tuning study,
reading the report; an API reference generated from the
docstrings and a command-line reference (
mkdocs build,pip install "handoverlab[docs]"), and a workflow that builds the site and can publish it on GitHub Pages. - Event-log levels
off,summaryandfull:fulladds a trace of the procedure (reports, preparations, configurations, executions, attachments, failures) from which the serving cell of every user follows at any time. The level never changes a result. handoverlab status STUDY: finished, failed and remaining jobs per stage, rule runs still to simulate and the time left, estimated from the study's own finished jobs.- Gate policy
extend: a grid whose selected value sits on its edge is widened with the same spacing and every method is tuned again with the same budget, up to a cap; each extension is a dated amendment in the study directory and the report. - Failure-model calibration against ns-3 / 5G-LENA, from stored ns-3 outputs only: 96 % of the ns-3 failures are late handover commands. A Qout filter window of about 0.12 s (instead of 0.2 s) fits the mean failure rate of the 24 reference settings (0.35-0.41 against 0.43 per UE-minute, rank correlation 0.97) but fails every held-back set (three times too many failures in the second ns-3 data set, different responses to the preparation delay and the number of users). So no calibrated preset is offered, the default is unchanged, and failure rates stay relative quantities; see docs/calibration.md.
What stage 3 adds
handoverlab study study.yaml: one file describes conditions, tuning and test seeds, the rules with their tuning grids and the comparisons; one command runs everything.- Tuning on an equal budget: every rule evaluates the same number of settings (a random round, then refinement around the best) on seeds that never appear in a test. Selection rule: lowest unnecessary-handover rate within a failure budget set by a reference rule, with fixed tie-breaks.
- Gates that fail loudly or warn before any test run: a selected setting on the edge of its grid, a failure budget that constrains nothing, unequal budgets, tuning seeds reused as test seeds, a flat optimum, a budget no setting meets.
- Paired statistics (
handoverlab.stats): paired differences, t and bootstrap intervals, exact or approximate Wilcoxon signed-rank tests, Holm correction. - Storage and runs: one atomic record per job, Parquet tables (CSV without pyarrow),
content-hashed job IDs, resumption (finished jobs are skipped, stored rule runs reused), worker
processes with
--workers(default: leave four cores free). handoverlab report DIR: Markdown and HTML with tables and figures.- Faster engines: the engines of all rules of a world share one step loop; with many rules per world (as in tuning) about half the engine time, with bit-identical results.
See the user guide, docs/performance.md and the validation section of docs/verification.md.
What stage 2 adds
handoverlab verify: path loss and LOS probability against hand-computed TR 38.901 values, radio statistics (shadowing standard deviation and correlation, LOS share, time variation, L1 error), invariants and conservation of counts, determinism, equivalences (CHO with immediate execution = A3), golden event-log fingerprints; a pass/fail report and a JSON copy.- Debug mode (
debug=True,run --debug,HANDOVERLAB_DEBUG=1): invariant checks at every step and a read-only observation for rules; results unchanged. - Event-log fingerprints: the SHA-256 of every run's event log is stored with its metrics;
verify --resultsrecomputes stored runs and compares them. - Event logs as tables: Parquet (with
pyarrow) or CSV, typed columns, read back withread_events. - Contract test kit for rule plug-ins:
handoverlab.testing.check_rule. - Scenario cards for four built-in scenarios (
smoke,urban-grid-10ghz,open-area-10ghz,ns3-urban-3.5ghz), usable by name in configuration files. - Wider regression against the bh6 prototype: ten cases, 36 runs, identical metrics and event logs.
- Reference comparison with ns-3 / 5G-LENA over 24 A3 settings: handover and unnecessary-handover rates within the limits (median ratios 0.95 and 1.04, rank correlation 0.99); failure rates differ (0.13 against 0.43 per UE-minute), as documented in the validation section.
- Faster world build: about a third less time for the radio map, with bit-identical results.
See docs/verification.md and docs/performance.md.
What stage 1 contains
- Scenarios: the TR 37.885 urban street grid (configurable number of blocks, default 3 x 3, the minimum area of TR 37.885 Table A-1; 433 m x 250 m pitch, 20 m streets) with sites on the pavement, and an open area of the same size with a hexagonal site grid; explicit site lists.
- Channel: TR 38.901 UMi street canyon and UMa path loss (LOS/NLOS); line of sight from the building geometry plus the spatially consistent LOS state; spatially correlated shadowing shared by all users ("place-tied blockage"), optionally partly moved to a process along each user's path; a time-varying component; L1 measurement error; beam gain and load-coupled interference.
- Mobility: street-following users with turn probabilities, random waypoints in the open area, pedestrian and vehicular speed profiles or your own speed groups.
- Measurements: L1 samples, the TS 38.331 L3 filter, Event A3 with time-to-trigger, periodic reporting for conditional handover.
- Handover procedures: baseline handover (report, preparation, command, execution) and Rel-16 conditional handover (preparation of up to 8 candidates, per-candidate execution offset and time-to-trigger, release, recovery into a prepared cell), behind a small rule interface.
- Failure model: Qout/Qin with windows, N310/N311/T310, lost commands and configurations, execution failures, re-establishment (TR 36.839 / TR 36.842 values by default).
- Metrics: outcome of every attempt (useful, unnecessary, too early, wrong cell, too late, censored), failures by cause, ping-pong, preparation overhead, interruption, delivered rate.
- Reproducibility: one world per seed shared by all compared rules (paired comparison); the engine draws no random numbers.
Install
HandoverLab needs Python 3.9 or later. NumPy, SciPy and PyYAML are installed with it; matplotlib
(reports, extra report), pyarrow (Parquet tables, extra parquet), Streamlit (the dashboard,
extra gui) and MkDocs (the documentation site, extra docs) are optional.
From PyPI:
python -m pip install handoverlab                  # the core package
python -m pip install "handoverlab[report,gui]"    # with reports and the dashboard
handoverlab verify --only pathloss fingerprints    # optional: a quick check of the installation
From source (for development, the tests and the examples):
git clone https://github.com/mjs19971997/handoverlab.git
cd handoverlab
python -m pip install -e ".[test,report]"    # add gui for the dashboard: ".[test,report,gui]"
python -m pytest            # optional: run the tests (a few minutes)
handoverlab verify          # optional: verification report (about two minutes)
Quick start
Write an example configuration and run it:
handoverlab init config.yaml
handoverlab run config.yaml -o results/metrics.csv
run writes one row per seed and rule with all metrics and the fingerprint of the event log, to
CSV or (with a .json output name) to JSON together with the resolved scenario and the package
versions. handoverlab rules lists the available rules and handoverlab scenarios the built-in
scenarios (scenario: smoke in a configuration uses one). Configurations can be YAML, TOML or JSON;
see examples/.
A whole study, with tuning, gates, paired tests and a report (a few minutes):
handoverlab study examples/study_smoke.yaml --workers 2 --report
The report lands in results/study-smoke/report/ (report.html, report.md, figures);
re-running the command skips everything that is already done, and handoverlab status results/study-smoke shows what is left and how long it will take.
Or explore in the browser:
python -m pip install "handoverlab[gui]"
handoverlab gui                      # http://localhost:8501, on your computer only
Example
import handoverlab as hl

scenario = hl.Scenario.from_dict({
    "layout": {"kind": "street_grid", "blocks": [3, 3], "site_spacing_m": 150.0},
    "mobility": {"users": 20, "profile": "veh16"},
    "run": {"duration_s": 60.0, "warmup_s": 10.0},
})
rules = [
    {"rule": "a3", "name": "A3", "off_db": 3.0, "ttt_s": 0.16},
    {"rule": "cho", "name": "CHO", "o_prep_db": -2.0, "o_exec_db": 3.0, "ttt_exec_s": 0.08},
]
for r in hl.simulate(scenario, rules, seeds=[1]):      # both rules run on the same world
    print(r.rule, r.metrics["handovers_pm"], r.metrics["unnecessary_pm"], r.metrics["failures_pm"])
The full script is examples/compare_a3_cho.py. Writing your own handover rule takes a few lines; see the user guide.
Documentation
The documentation site is at https://mjs19971997.github.io/handoverlab/. It is a MkDocs site (python -m pip install -e ".[docs]", then mkdocs serve);
the pages are plain Markdown in docs/ and readable on GitHub as well.
- Tutorials: your first run, writing your own rule, a fair tuning study, reading the report.
- User guide: concepts, scenarios, configuration keys, command line, Python API, rule plug-ins and their contract checks, event logs and their levels, verification, metrics, studies (tuning, gates, storage, workers, status, reports), paired statistics, limitations.
- How-to guides: dashboard, add a scenario, run on many cores, export event logs, reproduce and check results, DAPS and LTM, a learning-based rule, the upper mid-band, a highway.
- Reference: command line, metric names and the API (generated from the docstrings, in the site); stability policy.
- Scenario cards: the built-in scenarios with the source of every parameter.
- Verification, failure-model calibration and performance.
- Changelog, contribution guide and releasing.
Roadmap
- Stage 1 (0.1.0a1): core simulator, configuration, rule interface, command line, tests.
- Stage 2 (0.2.0a1): verification in depth (invariant checks, golden event-log fingerprints, radio
statistics, rule contract test kit, wider bh6 regression, ns-3 reference case), event logs as
tables, the
verifycommand, scenario cards, a faster world build. - Stage 3 (0.3.0a1): studies: equal-budget tuning with automatic gates, the selection rule, paired
statistics, job records and Parquet tables, resumable studies with reused runs, worker
processes,
studyandreportcommands, batched engines. - Stage 4 (0.4.0a1): browser dashboard (extra
gui), tutorials, API and command-line reference with a documentation site, event-log levels,statuswith the time left, the grid-edge policyextend, failure-model calibration against ns-3 / 5G-LENA. - Stage 5 (1.0.0rc1): the public interfaces frozen and documented with a schema version (configuration, results, rule interface, metric names) and a stability policy; how-to guides; a lint job and a coverage threshold in CI; a nightly comparison of fingerprints between Linux and Windows; release plumbing for PyPI and Zenodo.
- Stage 6 (1.0.0rc2): DAPS handover, L1/L2-triggered mobility, a learning-based example rule and an upper mid-band scenario, all additive.
- Stage 7 (1.0.0rc3): a highway layout with lane-keeping vehicular mobility and its scenario card, site lists from CSV files, all additive.
- Stage 8 (1.0.0rc4): the 3GPP citations and the documentation checked and corrected; no change of results.
- 1.0.0: the first stable release, published on PyPI.
- 1.0.1: the dashboard image shows on the PyPI project page; no change of results.
- 1.0.2 (this release): README links work on PyPI, the documentation site is linked, text corrections; no change of results.
- Later (planned, not done): conditional LTM, optional compiled kernels for the step loop, a TR 38.901 calibration scenario.
Citation
If you use HandoverLab, please cite it as described in CITATION.cff (GitHub shows it under Cite this repository). The releases are archived on Zenodo: doi:10.5281/zenodo.23409131 cites all versions (it resolves to the latest); version 1.0.0 is doi:10.5281/zenodo.23409132 and version 1.0.1 doi:10.5281/zenodo.23409402.
Licence
MIT. See LICENSE.
Authors
Mostafa Jalili Sanjarani and Yasser Elmi Sola
1 maintainer

Metadata
1 maintainer
Release files for handoverlab 1.2.0
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | Provenance | |
|---|---|---|---|---|
| handoverlab-1.2.0.tar.gz | 613.4 kB | With provenance | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| handoverlab-1.2.0-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 793.5 kB
Release files / handoverlab-1.2.0.tar.gz
| Download URL | handoverlab-1.2.0.tar.gz |
|---|---|
| Size | 613.4 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
38e860eb28577f5c378be9e554eff38973c7a2f8a30a99c708cda6fb7986efc7
|
|
BLAKE2b-256 checksum How to use checksums |
00c746e98aa37765099a6a9b5821124d490d41a127270dbac6161d6f7b2ae602
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.


PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Oct 18, 2026.
Transparency logRelease files / handoverlab-1.2.0-py3-none-any.whl
| Download URL | handoverlab-1.2.0-py3-none-any.whl |
|---|---|
| Size | 180.1 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
d3dfe1160c11a27aa251ec501deb9fe37c12a9ced9442996bff754139cc8ea13
|
|
BLAKE2b-256 checksum How to use checksums |
1926f04a36bfde9af82ec3853485ba3a6ca63125f46ec2498920b47c8bedabf1
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Oct 18, 2026.
Transparency logSecurity for handoverlab 1.2.0
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
Full provenance
All 2 files in this release have been uploaded with provenance metadata.
Attestation for handoverlab-1.2.0.tar.gz
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Oct 18, 2026.
Transparency logA note on package security
PyPI is a repository for distributing packages, not a service for auditing them. While third-party security researchers and our staff do their best to detect and remove malicious packages, PyPI cannot guarantee the quality, security or suitability of any given package.














