
HBB2OBB: Horizontal to Oriented Bounding Box Conversion and Evaluation Tool


HBB2OBB converts horizontal (axis-aligned) bounding boxes (HBBs) into oriented (rotated) bounding boxes (OBBs) by using your existing HBB annotations as prompts for segmentation models from the SAM (Segment Anything Model) family. It targets object detection tasks where objects appear at arbitrary orientations, such as aerial imagery, satellite data, or traffic monitoring, producing OBBs that tightly encapsulate non-upright objects. Beyond conversion, it ships evaluation, hyperparameter optimization, and annotation format-conversion tools, with both a command-line interface and a Python API.
Why HBB2OBB
- 🎯 Accurate OBBs from HBBs: prompts SAM-family segmentation models with your existing horizontal boxes to fit tight oriented boxes around non-upright objects, with no re-annotation required.
- 🚗 No HBBs? Detect them:
hbb2obb-detectruns an Ultralytics detector over your images and writes the horizontal boxes the conversion consumes, confidence column included (details). - 🧩 Model ensemble: combines masks from multiple SAM variants through majority voting for more robust, accurate results (see Usage).
- 🛡️ Spatially constrained & safe: region-specific masking and contour refinement keep segmentation inside the object, and a fallback keeps the original HBB when no valid mask is found.
- 🔎 Confidence-scored output: every OBB gets a quality score in
[0, 1]that flags silent fallbacks and low-confidence conversions, so you know which boxes to trust; your detector's own confidence can be carried through instead of, or on top of, that score (see Confidence scores). - 📐 Flexible scaling: positive or negative scale factors (optionally different for the short and long sides) recover cropped object parts or tighten overly conservative annotations.
- 📊 Evaluate & optimize: built-in IoU evaluation against ground truth plus
hbb2obb-optimize, a hyperparameter search over SAM inference resolution × scale factors × opening kernel, driven by a config file so a whole benchmark is one reproducible command (details). - 🔄 Six annotation formats: read and write YOLO, DOTA, Pascal VOC, COCO and LabelMe, for horizontal and oriented boxes alike, with a check that proves every format encodes the same boxes (details).
- 🔍 Interactive viewer:
hbb2obb-viewpans and zooms over your annotations, in any format, coloring boxes by confidence and overlaying predictions against ground truth (details). - ⚙️ CLI + Python API:
hbb2obb,hbb2obb-detect,hbb2obb-eval,hbb2obb-convert,hbb2obb-viewandhbb2obb-optimizecommands plus an importable API, with transparent visualizations of every step.
📋 Full Feature Overview
- HBB to OBB conversion: converts YOLO-format horizontal bounding boxes to oriented bounding boxes.
- HBB detection: produce the horizontal boxes in the first place with any Ultralytics detector, local, from the Ultralytics catalogue, or from Hugging Face (details).
- Segmentation-based: uses state-of-the-art SAM models for accurate object boundary detection.
- Multiple model support: SAM, SAM2, SAM2.1, SAM3, Mobile SAM, and FastSAM families (details).
- Model ensemble: combine multiple models via majority voting for enhanced accuracy.
- Confidence scoring: a per-OBB quality score flags fallbacks and low-confidence conversions for triage, optionally combined with the detector confidence from the input, written as an extra column or to a side-car directory that leaves the label files standard (details).
- Polygon output: optionally save the segmentation contour behind each OBB, row-aligned with the OBB file, as a tighter object outline for downstream masking (details).
- Evaluation tools: assess OBB accuracy against ground truth using IoU metrics.
- Hyperparameter optimization: search SAM inference resolutions, HBB scale factors and opening kernels for the best settings on your data, one sweep at a time or a whole benchmark from a config file.
- Provenance records:
--save_provenancewrites the command, the versions, a digest of the source that ran and the SHA-256 of every checkpoint, so a released annotation set can be regenerated rather than trusted. - Visualization tools: render HBBs, segmentation masks, derived contours, and resulting OBBs.
- Interactive viewer: pan and zoom over annotated frames, toggle each layer, and compare two annotation sets side by side.
- Format conversion utilities: convert between YOLO, DOTA, Pascal VOC, COCO and LabelMe annotations, in either direction, for both box kinds.
🚀 Planned Enhancements
- Improved morphological operations: more advanced operations for better mask refinement.
- Support for other segmentation models: extend compatibility beyond the SAM/FastSAM families.
🔗 Related Projects
HBB2OBB integrates with and complements several specialized tools:
-
Geo-trax 🚀: georeferenced vehicle trajectory extraction pipeline for high-altitude drone imagery, built on YOLO detection and multi-object tracking. Its vehicle detector supplies the HBB inputs for vehicle use cases (car, bus, truck, motorcycle), and
hbb2obb-detectruns it by default (details). -
Stabilo ⚖️: Python library for video and trajectory stabilization using robust homography transformations. Supports various feature detectors, RANSAC algorithms, and user-defined masks.
-
Stabilo-Optimize 🎯: benchmarking and hyperparameter optimization framework for Stabilo. Evaluates stabilization performance through ground truth-free assessment using random perturbations.
Install
Create and activate a Python virtual environment (Python 3.9–3.13), then install from PyPI:
python3.11 -m venv .venv
source .venv/bin/activate  # On Windows: .venv\Scripts\activate
pip install hbb2obb
Also works with uv (uv pip install hbb2obb) and conda.
[!NOTE] SAM model weights are downloaded automatically by Ultralytics on first use into a
models/directory relative to your current working directory: run commands from a consistent location so weights are reused. Detector weights forhbb2obb-detectland there too. The one exception is SAM 3, which must be downloaded manually (see below).
Every command checks PyPI once a day, in the background, for a newer HBB2OBB release and prints a one-line notice if one exists. The check never blocks, never fails a run, and is silent when offline. Set HBB2OBB_DISABLE_UPDATE_CHECK=1 to turn it off.
Alternatives: conda or uv
conda create -n hbb2obb python=3.11 -y
conda activate hbb2obb
uv (fastest; then uv pip install hbb2obb):
uv venv --python 3.11
source .venv/bin/activate  # On Windows: .venv\Scripts\activate
Install from source (development / editable)
git clone https://github.com/rfonod/hbb2obb.git
cd hbb2obb && pip install -e '.[dev]'
The -e flag makes your local changes take effect without reinstalling; the [dev] extra adds pytest and ruff. For a plain install, use pip install . instead.
SAM 3 model weights (manual download required)
Unlike other SAM models, SAM 3 weights (sam3.pt) are not auto-downloaded by Ultralytics. To use SAM 3:
- Request access on the SAM 3 model page on Hugging Face.
- Once approved, download
sam3.pt. - Place
sam3.ptin themodels/directory (relative to where you run the conversion).
See the Ultralytics SAM 3 documentation for more.
Quick Start
A small sample dataset ships in data/. From the repository root:
# The sample already ships with detected HBBs, so start here. To redo that step yourself:
#   hbb2obb-detect data/images --overwrite

# Convert the sample HBBs to OBBs (default single model) and save visualizations
hbb2obb data/images --save_img

# Higher accuracy with a model ensemble
hbb2obb data/images --sam_models sam_b sam_l sam2_b sam2.1_b

# Evaluate the converted OBBs against ground truth
hbb2obb-eval data/labels_obb_gt data/labels_obb -mp data/classes.yaml

# Look at the result: pan, zoom, step through frames, q to quit
hbb2obb-view data/images --compare data/labels_obb_gt
Converted OBB annotations are written to data/labels_obb/. Every command takes --help.
Usage
Converting HBB to OBB
# Default single model (sam_b), HBBs read from <img_source>/../labels_hbb
hbb2obb /path/to/images --hbb_dir /path/to/hbb/annotations

# Model ensemble (majority voting across models)
hbb2obb /path/to/images --sam_models sam_b sam_l sam2_b sam2.1_b

# Scale HBBs: expand to recover cropped parts, or shrink conservative boxes
hbb2obb /path/to/images --scale_factors 0.1      # expand uniformly
hbb2obb /path/to/images --scale_factors -0.02    # shrink uniformly
hbb2obb /path/to/images --scale_factors 0.1 0.05 # short side / long side

# Save visualization images of the conversion
hbb2obb /path/to/images --save_img

# Also save the segmentation polygon of each object, a tighter outline than its OBB
hbb2obb /path/to/images --save_polygon --polygon_dir /path/to/save/polygons
Evaluating OBB Predictions
hbb2obb-eval /path/to/ground_truth /path/to/predictions
More CLI arguments
Run hbb2obb --help / hbb2obb-eval --help for the full list. Key conversion arguments:
--hbb_dir/-hd: directory of HBB annotations in YOLO TXT format (default:<img_source>/../labels_hbb).--obb_dir/-od: directory to save OBB annotations (default:<img_source>/../labels_obb).--sam_models/-sm: SAM model(s) to use (e.g.sam_b,sam_l,sam2_b,sam2.1_b,sam3,mobile_sam,FastSAM-s).--imgsz: SAM inference resolution (default: 1280).--scale_factors/-sf: factor(s) to scale HBBs (single value, or two values for short/long sides).--opening_kernel_percentage/-okp: morphological opening kernel size as a percentage of the mask's smaller dimension.--save_confidence: append a per-OBB confidence score as a 10th column in the output TXT files.--confidence_dir/-cd: write those scores to their own directory instead, one score per line, row-aligned with the labels. Use it when the label files have to stay strictly standard, since Ultralytics and other YOLO OBB readers reject a 10th column. Give it bare forimg_source/../labels_confidence.--save_img,--viz_dir,--show_confidence, and--hide_hbb/--hide_obb/--hide_masks/--hide_segments/--hide_class_labels: visualization controls.--device: inference device for the SAM model(s), e.g.cpu,0,cuda:0,mps(default: Ultralytics picks).--model_kwargs/-k: extra Ultralytics inference kwargs askey1=value1,key2=value2.
Key evaluation arguments:
--excluded_classes/-e: class IDs to exclude from evaluation.--iou_threshold/-t: IoU threshold for a match (default: 0.1).--class_agnostic/-ca: ignore class-label matching (useful for re-classified GT).--exclude_edge_cases/-exc,--edge_tolerance/-et,--img_width/-iw,--img_height/-ih: edge-case handling.--map_path/-mp: path to a label map YAML mapping class IDs to names.
Python API
Converting HBB to OBB: hbb2obb() processes a single image and returns the OBB annotations as a NumPy array:
from pathlib import Path
from hbb2obb.converter import hbb2obb, save_obb_annotations, save_polygon_annotations

img_path = Path("/path/to/images/img1.jpg")

# Single SAM model
obb_annotations = hbb2obb(
    img_path=img_path,
    hbb_dir="/path/to/hbb/annotations",
    sam_models="sam_b",
    imgsz=1280,
    scale_factors=0.05,
    opening_kernel_percentage=0.15,
    save_img=True,
    viz_dir="/path/to/save/visualizations",
)

# Model ensemble with per-side scale factors
obb_annotations = hbb2obb(
    img_path=img_path,
    hbb_dir="/path/to/hbb/annotations",
    sam_models=["sam_b", "sam_l", "sam2_b", "sam2.1_b"],
    scale_factors=[0.1, 0.05],  # short side / long side
)

# Writes <obb_dir>/img1.txt, deriving the filename from img_path
save_obb_annotations(obb_annotations, "/path/to/save/obb/annotations", img_path)

# Also return per-OBB confidence scores, and write them as a 10th column
obb_annotations, confidences = hbb2obb(img_path=img_path, sam_models="sam_b", return_confidence=True)
save_obb_annotations(obb_annotations, "/path/to/save/obb/annotations", img_path, confidences=confidences)

# Also return the segmentation contours, and write them as polygon annotations
obb_annotations, contours = hbb2obb(img_path=img_path, sam_models="sam_b", return_contours=True)
save_polygon_annotations(contours, obb_annotations, "/path/to/save/polygons", img_path)
Evaluating OBB predictions:
from pathlib import Path
from hbb2obb.evaluator import evaluate_obb, print_results

results = evaluate_obb(
    gt_dir=Path("/path/to/ground_truth_annotations"),
    pred_dir=Path("/path/to/predictions"),
    iou_threshold=0.1,
    class_agnostic=True,  # optional: match regardless of class label
    exclude_edge_cases=True,  # optional: drop boxes at the image edge
    img_width=3840,
    img_height=2160,
)

print_results(results, "/path/to/label_map.yaml")
End-to-end workflow, from someone else's annotation format
Starting from HBB annotations and OBB ground truth in whatever format you were given:
# 1. Bring both into YOLO TXT, whatever they arrived as (--from is detected if omitted)
hbb2obb-convert project/voc_hbb --to yolo -o project/labels_hbb -mp project/label_map.yaml
hbb2obb-convert project/gt.json --from coco --to yolo -o project/labels_obb_gt -mp project/label_map.yaml

# 2. Optimize hyperparameters to find the best settings (add -ok to also sweep the opening kernel)
hbb2obb-optimize project/images project/labels_obb_gt -sm sam_b sam_l sam2_b -n multi_sam

# 3. Inspect the best parameters, then convert with them
cat project/benchmark_results/multi_sam/summary.txt
hbb2obb project/images --hbb_dir project/labels_hbb --obb_dir project/labels_obb \
  --sam_models sam_b sam_l --imgsz 1280 --scale_factors 0.05 \
  --opening_kernel_percentage 0.15 --save_confidence --save_provenance

# 4. Evaluate against ground truth, then look at where it went wrong
hbb2obb-eval project/labels_obb_gt project/labels_obb -mp project/label_map.yaml
hbb2obb-view project/images --compare project/labels_obb_gt --show_confidence

# 5. Ship the result in every format your consumers want
hbb2obb-convert project/labels_obb --to dota coco voc -o project/release -mp project/label_map.yaml
Detecting HBBs
No HBBs yet? hbb2obb-detect runs an Ultralytics detector over your images and writes exactly the YOLO TXT the conversion reads, with the detector confidence in the 6th column:
# geo-trax is the default detector, tuned for vehicles in high-altitude drone imagery (weights downloaded on first use)
hbb2obb-detect /path/to/images

# Any other Hugging Face model: all three parts, '<user>/<repo>/<file>.pt' (no "huggingface.co/" prefix)
hbb2obb-detect /path/to/images --model rfonod/geo-trax/geotrax_hbb_yolov8s_1920_v1.pt

# Then convert, carrying the detector confidence into the OBBs alongside the conversion score
hbb2obb /path/to/images --save_confidence --confidence_source combined
More about --model, class maps, and merging with hand-drawn boxes
--model takes a registered detector (geotrax today, the default), any Ultralytics model name or .pt path, or a Hugging Face reference written as <user>/<repo>/<file>.pt. All three parts are required, even when the repo holds only one file. Weights land in models/ beside the SAM checkpoints. A registered detector brings the settings it was validated at: geotrax runs at --imgsz 1920 over its four reliable classes, while anything else starts from the Ultralytics defaults. --class_map renumbers a detector's classes to yours: --class_map '2=0,5=1,7=2,3=3' turns COCO's car, bus, truck and motorcycle into 0,1,2,3 and drops every other class.
Detected boxes are a starting point, not ground truth. If you have hand-drawn boxes already and only want the confidence a detector would give them, --merge_with keeps your geometry untouched and only attaches the score of the detection covering each box:
hbb2obb-detect /path/to/images --merge_with /path/to/labels_hbb --extras_dir /tmp/extras --overwrite
Your boxes stay exactly as they are, in their own order; a box no detection covers keeps 1.0. Detections that back no box of yours are counted and, with --extras_dir, written as their own set to review (hbb2obb-view /path/to/images --hbb_dir /tmp/extras); the merge never adds them for you. --overwrite is required before anything writes into a directory that already holds labels.
Inspecting Annotations
hbb2obb-view opens your annotations over the images they belong to, in a window that pans and zooms:
# Defaults: images in <dir>, boxes from ../labels_obb and ../labels_hbb
hbb2obb-view data/images

# Color the OBBs by confidence and print the score, to find the boxes worth checking
hbb2obb-view data/images --show_confidence

# Overlay ground truth in blue over the converted boxes in green
hbb2obb-view data/images --compare data/labels_obb_gt

# Read a different format, or write annotated images instead of opening a window
hbb2obb-view data/images --obb_format dota
hbb2obb-view data/images -o /path/to/annotated
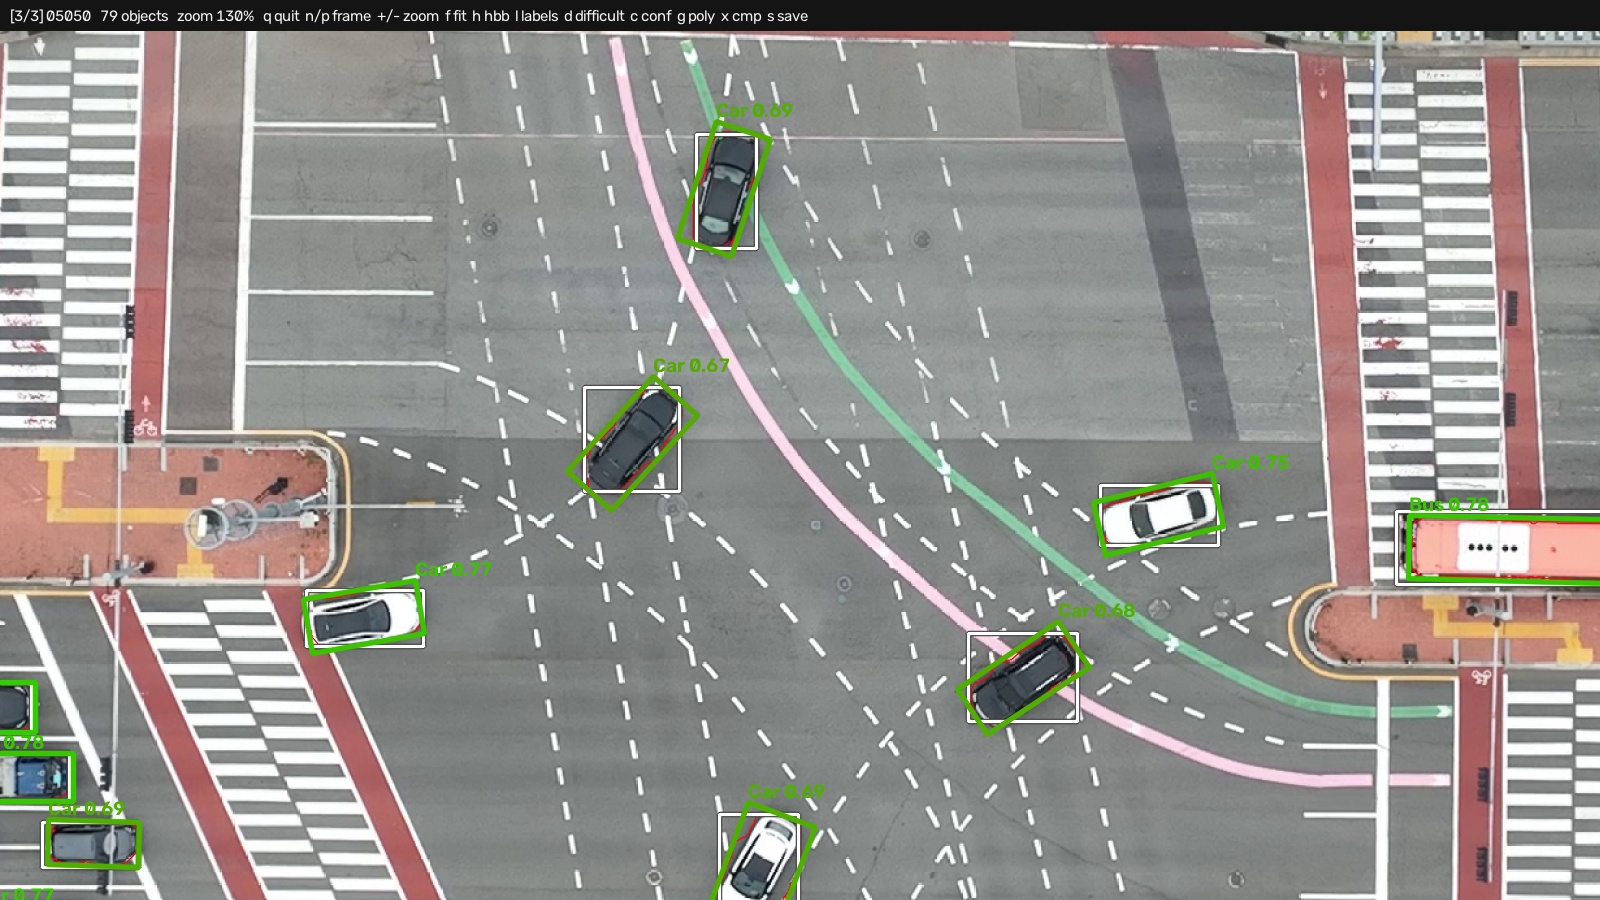
Color legend and keyboard shortcuts
Green is the OBB, white its source HBB, red the segmentation polygon it was fitted to, orange a box flagged difficult; with --show_confidence the OBB is tinted green→red by score, the same gradient --save_img uses. The last two need the conversion to have been run with --save_polygon and --save_confidence, as the sample data in data/ was (see data/README.md for the commands behind every file there). Labels with no confidence column still color by score when the scores sit in a side-car directory: the viewer reads labels_confidence/ beside them, or wherever --confidence_dir points.
| Key | Key | ||
|---|---|---|---|
q / Esc |
quit | h |
show or hide the HBBs |
n / p, arrows |
next / previous frame | l |
show or hide the class labels |
wheel, + / - |
zoom, about the cursor | d |
show or hide boxes flagged difficult |
f / 0 |
fit the frame | c |
color by confidence, and print it |
1 |
zoom to 100% | g |
show or hide the segmentation polygons |
s |
save the current view | x |
cycle the comparison overlay |
Drag with the left mouse button to pan. --crops writes a contact sheet of the individual objects instead.
Converting Between Formats
hbb2obb-convert moves annotations between the six formats below, in either direction, for horizontal and oriented boxes alike:
| Format | HBB | OBB | Shape |
|---|---|---|---|
yolo |
✅ | ✅ | one .txt per frame, with an optional trailing confidence column |
dota |
✅ | one file per frame, x1 y1 … x4 y4 name difficult, integer px |
|
voc |
✅ | one Pascal VOC .xml per frame, integer px |
|
coco |
✅ | ✅ | one .json for the whole set; the quad goes in segmentation, a confidence in score |
labelme |
✅ | ✅ | one LabelMe .json per frame |
# Write several formats in one pass; --from is detected from the files if omitted
hbb2obb-convert /path/to/labels_obb --to dota coco voc -o /path/to/release -mp label_map.yaml

# The reverse, into the YOLO TXT the tool consumes
hbb2obb-convert /path/to/instances.json --from coco --to yolo -o /path/to/labels_hbb --normalize

# Check that every format present under a directory encodes the same boxes
hbb2obb-convert /path/to/dataset --verify -mp label_map.yaml
Format details and edge cases
--verify compares the formats by exact equality after rounding, not by a tolerance: every format is one rounding of a single canonical source, so any disagreement is a real one.
Only DOTA and Pascal VOC can express a per-box difficult flag, so writing either one from YOLO or COCO resets it; --difficult_from dota carries the flags across. --difficult_from confidence instead derives the flag from the conversion score, flagging everything below --difficult_below (fallback boxes score 0.0, so they are always flagged); the scores come from a trailing column on the source labels, or from --confidence_dir when the labels are standard ones with the scores in a side-car. The scores themselves stay out of the output. Only YOLO and COCO can carry a confidence, so DOTA and Pascal VOC drop it. Image dimensions come from --images, or from --img_width / --img_height, and are needed to denormalize relative YOLO coordinates. LabelMe stores class names rather than ids, so pass -mp when round-tripping through it to pin the ids.
A COCO file is named coco_annotations_<kind>.json unless --coco_name says otherwise, which is also how --verify pairs one with its directory: labels_<name>/ goes with coco_annotations_<name>.json beside it. Where a directory holds the canonical YOLO files next to derived ones, --from is detected as yolo.
Tuning Hyperparameters
hbb2obb-optimize grid-searches inference resolution x scale factor x opening kernel for a set of SAM models, scoring each point by average IoU against ground-truth OBBs:
hbb2obb-optimize /path/to/images /path/to/ground_truth -sm sam_b sam_l sam2_b sam2.1_b -n multi_sam
Grid size, outputs, and sweeping the opening kernel
The grid is the full product of --imgsz x --scale_factors x --opening_kernels, and each grid point is a complete SAM pass over the whole image set, so the cost multiplies quickly: the defaults (3 image sizes, 12 scale factors, 1 opening kernel) already amount to 36 passes, and sweeping three kernels instead of one triples that to 108. --opening_kernels / -ok defaults to the single value 0.15, so omitting it leaves the two-axis sweep and its grid size unchanged.
# Add the opening kernel as a third axis (2 x 3 x 3 = 18 grid points)
hbb2obb-optimize /path/to/images /path/to/ground_truth -iz 960 1280 -sf 0.03 0.05 0.07 -ok 0.0 0.15 0.3
A run writes run_config.yaml, results.yaml, summary.txt and plot.png into <output_folder>/<name>, and summary.md, comparison.png and PROVENANCE.txt into the output folder itself. The plot gives each series a hue by image size and, when more than one opening kernel was swept, a lightness of that hue and a marker shape by kernel, so no two of the swept combinations share a colour. Marker area is the execution time.
--device (e.g. cpu, 0, cuda:0, mps) applies to every run and overrides any device set in the config.
Comparing Several Sweeps
A YAML lists the runs, and one command produces all of them:
hbb2obb-optimize -c benchmark.yaml             # all runs in benchmark.yaml
hbb2obb-optimize -c benchmark.yaml --resume    # continue one that was interrupted
Config file, dry runs, and refreshing plots
# benchmark.yaml
img_source: data/images
gt_dir: data/labels_obb_gt
output_folder: data/benchmark_results

defaults:
  imgsz: [640, 960, 1280]
  scale_factors: [0.03, 0.04, 0.05, 0.06, 0.07]

runs:
  - sam_models: [sam_b]
  - sam_models: [sam_l]
  - sam_models: [sam_l, sam_b, sam2_b, sam2.1_b]
hbb2obb-optimize -c benchmark.yaml --dry_run   # the runs, the grid size, the total cost
hbb2obb-optimize -c benchmark.yaml --refresh   # only redraw the plots and the summary
Each run takes the defaults and overrides whatever it names; a run with no name takes one from its models, so [sam_l, sam_b] writes into sam_l-sam_b. Every sweep writes summary.md and PROVENANCE.txt, and a config-driven benchmark also leaves a copy of the configuration in the output folder, so the results re-run on their own from wherever they end up. --resume skips runs that already hold a complete grid, and PROVENANCE.txt then names the runs this invocation measured and the ones it kept. --refresh redraws the plots and the summary from the results on disk and rewrites no provenance.
data/benchmark.yaml is a working example: it is the file behind data/benchmark_results/.
Recording Provenance
--save_provenance records what a run actually did, so a release can be regenerated rather than taken on trust. The file lands one level above the label directory: --obb_dir train/labels leaves train/PROVENANCE.txt. hbb2obb-detect writes PROVENANCE_hbb.txt there instead, and hbb2obb-optimize writes PROVENANCE.txt inside its output folder.
hbb2obb /path/to/images --sam_models sam_l sam_b sam2_b sam2.1_b --save_confidence --save_provenance
What gets recorded
# Works the same for detection
hbb2obb-detect /path/to/images --save_provenance
The record holds the exact command, the settings the run used, the versions of ultralytics, torch, OpenCV, NumPy, Shapely and matplotlib, and the SHA-256 of every checkpoint used. A benchmark also hashes the label sets its numbers were measured against.
The code is pinned three ways: the release version, the commit with git describe when there is a checkout, and a SHA-256 over the package source. The record states whether that commit can be checked out to get the code that ran, judging by the package directory alone. Use the commit to find the change; use the digest to prove you have the same code.
Data Format
HBB annotations (input): YOLO TXT, one file per image; coordinates relative (0–1) or absolute px:
class_id x_center y_center width height
An optional 6th column holds the detector confidence and can be carried into the output (see Confidence scores):
class_id x_center y_center width height confidence
Blank lines are skipped, and an empty label file (a frame with no objects) is valid input and produces an empty output file.
You bring your own HBB annotations. If you don't have any, hbb2obb-detect produces them with an Ultralytics detector and writes this exact format, confidence column included (see Detecting HBBs).
OBB annotations (output): YOLO TXT, one file per image; four corners in absolute px:
class_id x1 y1 x2 y2 x3 y3 x4 y4
With --save_confidence, a 10th column holds the per-OBB confidence score:
class_id x1 y1 x2 y2 x3 y3 x4 y4 confidence
hbb2obb-eval ignores the trailing confidence column, so evaluation works on either variant.
Polygon annotations (optional output): with --save_polygon, the segmentation contour each OBB was fitted to is written to a parallel directory (labels_polygon by default), one file per image; a variable number of corners in absolute px:
class_id x1 y1 x2 y2 ... xN yN
With --save_confidence, a trailing column holds the same per-object score written to the OBB file:
class_id x1 y1 x2 y2 ... xN yN confidence
The polygon is a tighter outline of the object than its OBB, useful as a mask for downstream work. It is row-aligned with the OBB file: line i of both files describes the same object. Objects that fell back to the HBB are written as a four-point rectangle identical to their OBB line, never skipped. --polygon_epsilon simplifies the polygons, the value being a fraction of the contour perimeter (0.01 typically drops about 90% of the vertices); the default 0 writes the raw contour.
Label map (optional): YAML mapping class IDs to names:
0: Car
1: Bus
2: Truck
How It Works
HBB2OBB fits each OBB by prompting SAM with your HBBs, refining the resulting mask, and wrapping it in a minimum-area rotated box.
Conversion pipeline
- Load HBB annotations from YOLO TXT.
- Scale bounding boxes: positive factors expand HBBs (recover cropped parts), negative factors shrink them (tighten conservative boxes); short and long sides can be scaled differently.
- Segmentation: run SAM model(s) with the HBBs as prompts.
- Mask aggregation: with an ensemble, combine masks by majority voting; clip to the scaled HBB region; apply morphological opening.
- Contour extraction: extract the largest refined mask contour per object (optionally saved with
--save_polygon). - OBB computation: fit a minimum-area oriented bounding box.
- Fallback: if no valid mask is found inside an HBB, keep the original HBB as the OBB (confidence
0.0). - Confidence: score each OBB in
[0, 1](see Confidence Scores). - Visualization (optional): overlay HBBs, masks, contours, and OBBs (colored by confidence).
Key characteristics:
- Label preservation: OBBs inherit the class label of their source HBB (no re-classification).
- Corrective effects: the transformation can recover cropped parts (positive scaling) and produce tighter boxes through precise segmentation.
Confidence Scores
Each OBB carries a heuristic quality score in [0, 1] that helps triage a converted dataset: high scores are trustworthy SAM fits, low scores warrant a look, and 0.0 marks a fallback where the original HBB was kept. It is a heuristic, not a calibrated probability. The detail crop below shows the score that --show_confidence prints next to each converted box.
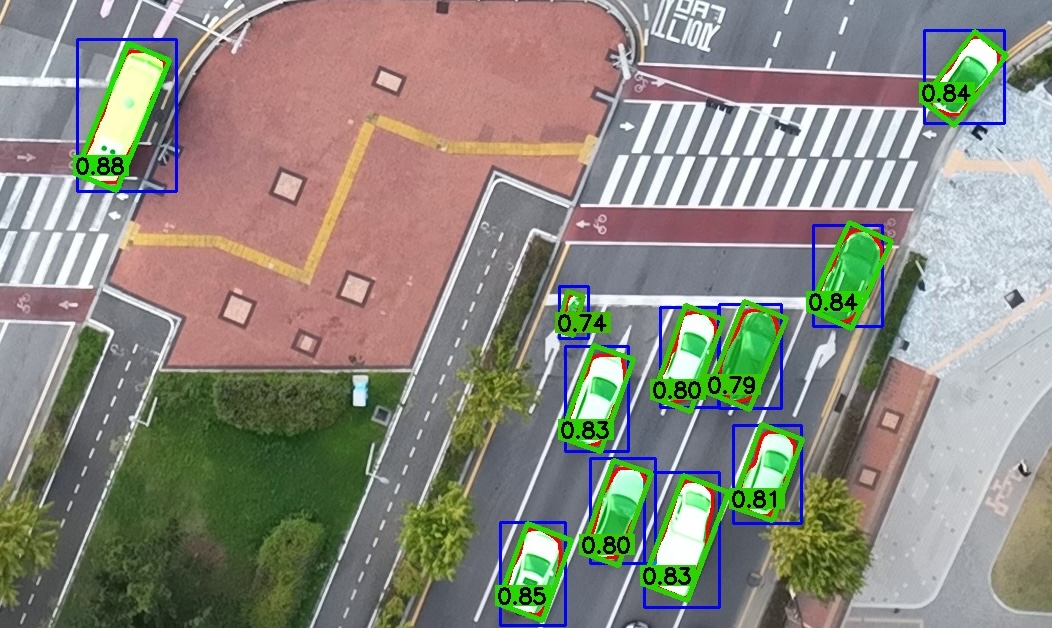
The score is the product of two factors:
- Rectangularity: the fitted contour area divided by the area of its minimum-area rotated rectangle, i.e. how tightly the OBB wraps the segmented shape (
1.0for a perfectly rectangular object). - Ensemble consensus: the fraction of the per-model mask union that survived the majority vote, i.e. how strongly the SAM models agree. This is
1.0for a single model and equals the mask IoU for two models.
Enable it with --save_confidence (writes a 10th column to each output file). In the visualization, OBBs are always tinted on a green→red gradient by score, and --show_confidence prints the numeric value next to each box. When using the Python API, pass return_confidence=True to hbb2obb() to get the scores back alongside the OBBs.
Choosing which score is reported. If your HBB files carry a detector confidence in a 6th column, --confidence_source (or the confidence_source argument of hbb2obb()) selects what the reported score means:
| Value | Reported score |
|---|---|
conversion (default) |
the heuristic conversion quality described above |
detector |
the detector confidence read from the HBB input |
combined |
the product of the two |
conversion says how well the OBB fits the segmented shape, detector how sure the detector was that there is an object at all. Boxes whose input line carried no confidence column fall back to the conversion score, so no output is left without one.
hbb2obb-detect writes that 6th column, for boxes it found itself or, with --merge_with, for boxes you drew by hand (see Detecting HBBs). The sample HBBs in data/ are detector output and carry it; the OBBs in data/labels_obb/ are scored combined.
Best Practices
- For optimal results, combine multiple SAM models of comparable strength, e.g.
--sam_models sam_b sam_l sam2_b sam2.1_b. Adding a weaker model is not free: under majority voting, two weak members can outvote a strong one. - Experiment with scale factors and inference resolutions based on your dataset.
- Run
hbb2obb-optimizeto find the best settings for your data, and--save_provenanceto record the ones you settled on. - Use class-agnostic evaluation when comparing against manually annotated ground truth with different class labels.
- Visualize the conversion to understand how the model interprets your HBBs.
Limitations
- Results depend on the quality of the input HBBs and the SAM models used; poor annotations or weak segmentation lead to inaccurate OBBs.
- Highly occluded or complex objects, where the HBB gives insufficient context, may not convert well.
Citation
If you use HBB2OBB in your research or software, please cite the archived release:
@software{fonod2026hbb2obb,
  author  = {Fonod, Robert},
  title   = {HBB2OBB: Horizontal to Oriented Bounding Box Conversion and Evaluation Tool},
  year    = {2026},
  license = {MIT},
  doi     = {10.5281/zenodo.15151143},
  url     = {https://github.com/rfonod/hbb2obb}
}
Each GitHub release is automatically archived to Zenodo via the Zenodo–GitHub integration; see CITATION.cff for the latest version and DOI.
Contributing
Contributions are welcome! If you encounter issues or have suggestions, please open a GitHub Issue or submit a pull request.
License
This project is distributed under the MIT License. See the LICENSE file for details.
1 maintainer

Metadata
1 maintainer
Release files for hbb2obb 1.6.0
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | |
|---|---|---|---|
| hbb2obb-1.6.0.tar.gz | 145.4 kB | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| hbb2obb-1.6.0-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 238.2 kB
Release files / hbb2obb-1.6.0.tar.gz
| Download URL | hbb2obb-1.6.0.tar.gz |
|---|---|
| Size | 145.4 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
9cec2b0ca8fd329d7ccdf54a0e52947a73deff90ce294ccb266d318e9f01c33e
|
|
BLAKE2b-256 checksum How to use checksums |
a0cbe075931e61041f81fa9f100f32b97aefa65a87d10eda2fe852354d80b3c1
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.


PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Sep 2, 2026.
Transparency logRelease files / hbb2obb-1.6.0-py3-none-any.whl
| Download URL | hbb2obb-1.6.0-py3-none-any.whl |
|---|---|
| Size | 92.8 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
e5582b12f2e6b783284e4fc528dde9aaa011ff4e8d9b076a1d41b6b22c2e623b
|
|
BLAKE2b-256 checksum How to use checksums |
be0f9f1d3c6edd31e0fa3ec0c4c6a05bd1f2c91c5a55392ae1fd40442f289110
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Sep 2, 2026.
Transparency log













