
Recurrent Inertial Graph-based Estimator (RING)

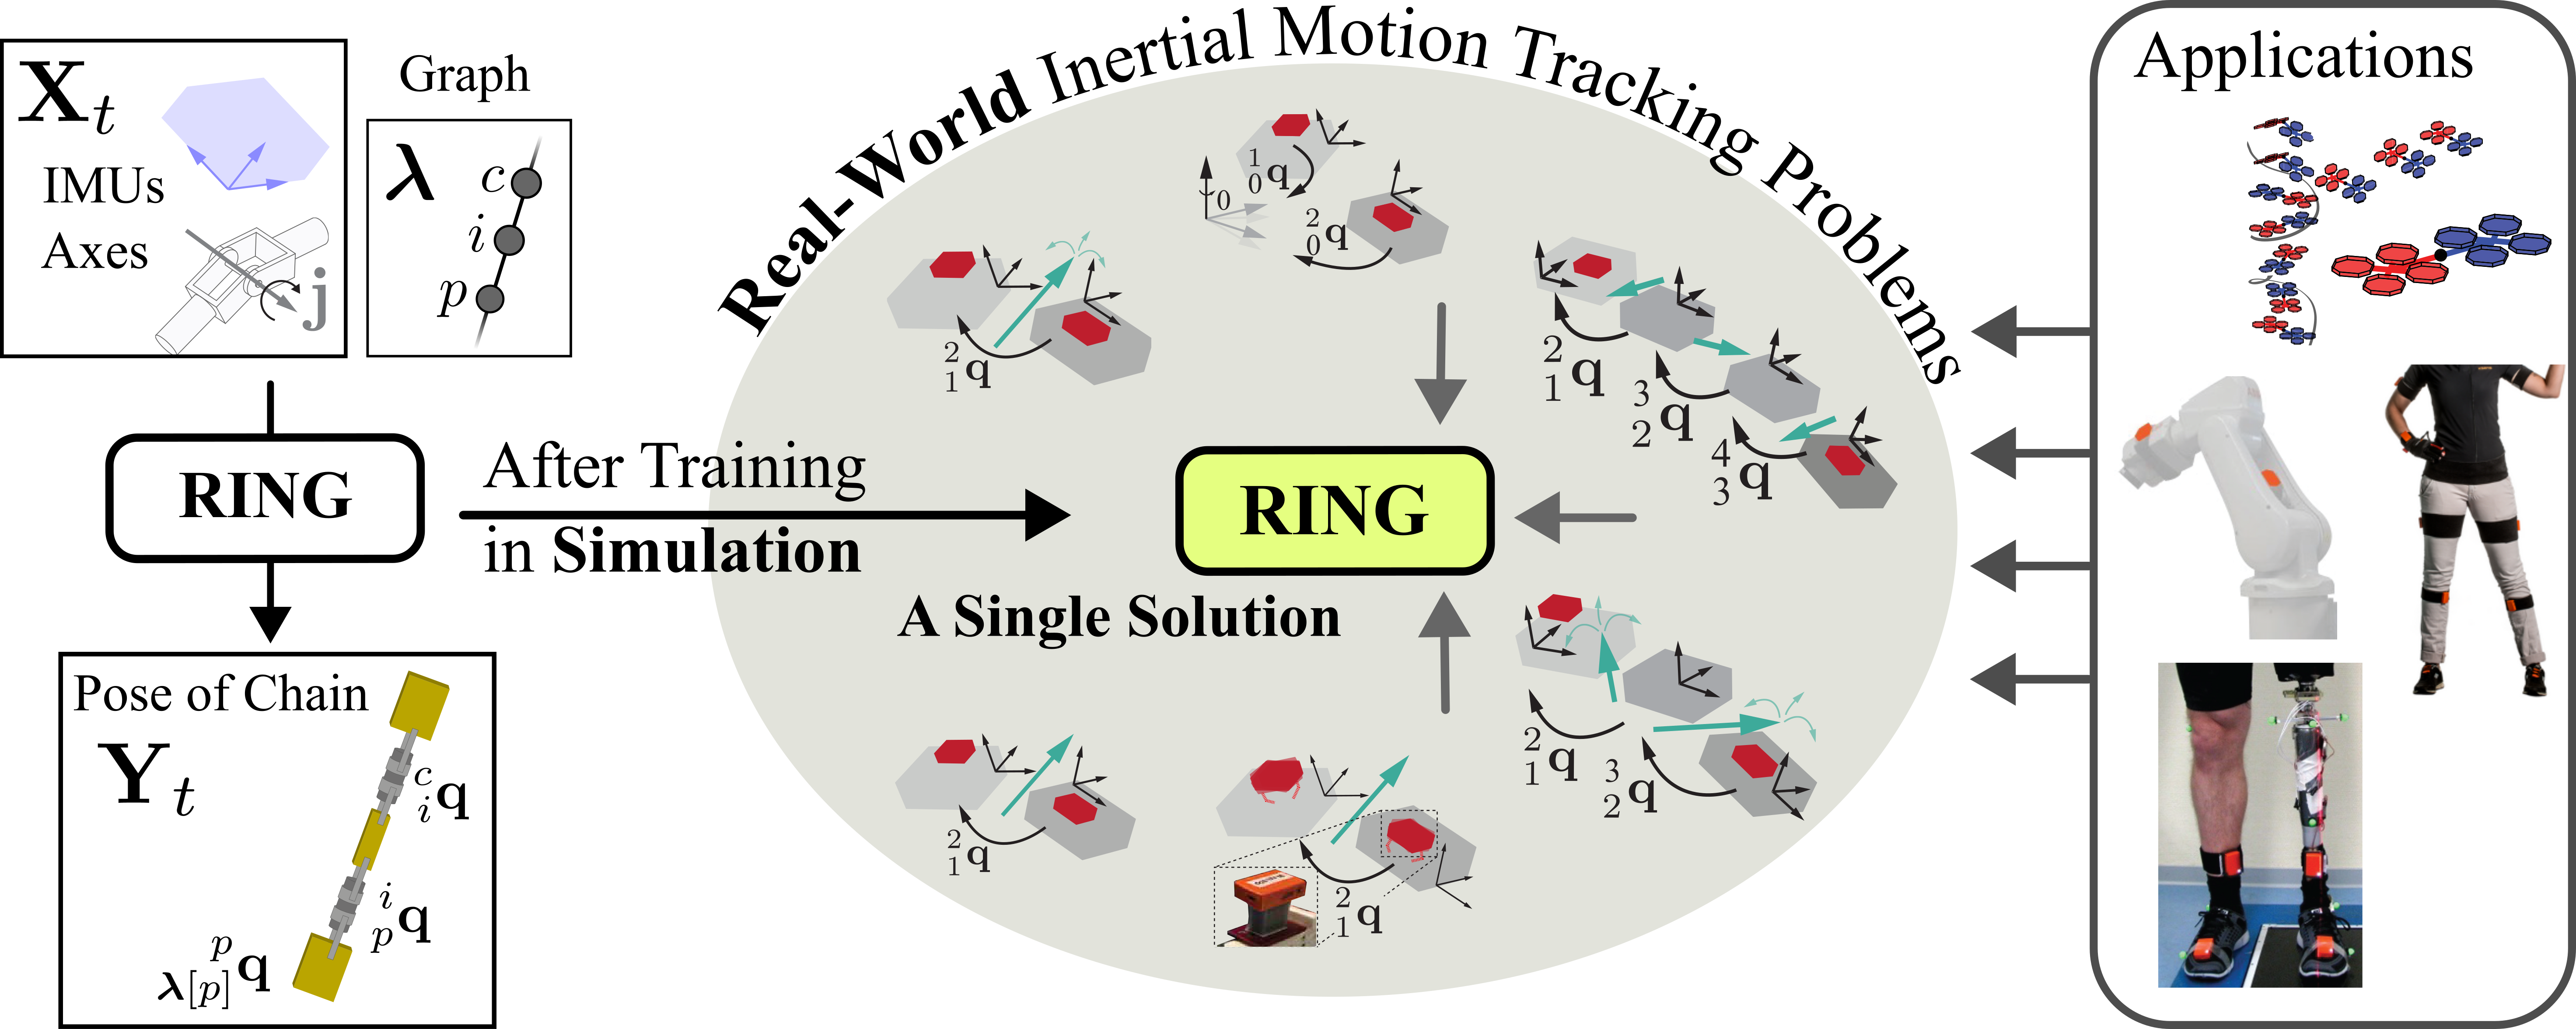
RING provides a pluripotent, problem-unspecific plug-and-play IMT solution that, in contrast to conventional IMT solutions, eliminates the need for expert knowledge to identify, select, and parameterize the appropriate method. RING's pluripotency is enabled by a novel online-capable neural network architecture that uses a decentralized network of message-passing, parameter-sharing recurrent neural networks, which map local IMU measurements and nearest-neighbour messages to local orientations. This architecture enables RING to address a broad range of IMT problems that vary greatly in aspects such as the number of attached sensors, or the number of segments in the kinematic chain, and even generalize to previously unsolved IMT problems, including the challenging combination of magnetometer-free and sparse sensing with unknown sensor-to-segment parameters. Remarkably, RING is trained solely on simulated data, yet evaluated on experimental data, which indicates its exceptional ability to zero-shot generalize from simulation to experiment, while outperforming several state-of-the-art problem-specific solutions. For example, RING can, for the first time, accurately track a four-segment kinematic chain (which requires estimating four orientations) using only two magnetometer-free inertial measurement units.
ℹ️ Tip:
Check out my new plug-and-play interface for inertial motion tracking (RING included) here.
Installation
Supports Python=3.10/3.11/3.12 (tested).
Install with pip using
pip install imt-ring
Typically, this will install jax as cpu-only version. For GPU install instructions for jax see https://github.com/jax-ml/jax?tab=readme-ov-file#instructions.
Documentation
Available here.
Quickstart Example
import ring
import numpy as np

T  : int       = 30         # sequence length     [s]
Ts : float     = 0.01       # sampling interval   [s]
B  : int       = 1          # batch size
lam: list[int] = [-1, 0, 1] # parent array
N  : int       = len(lam)   # number of bodies
T_i: int       = int(T/Ts)  # number of timesteps

X              = np.zeros((B, T_i, N, 9))
# where X is structured as follows:
# X[..., :3]   = acc
# X[..., 3:6]  = gyr
# X[..., 6:9]  = jointaxis

# let's assume we have an IMU on each outer segment of the
# three-segment kinematic chain
X[..., 0, :3]  = acc_segment1
X[..., 2, :3]  = acc_segment3
X[..., 0, 3:6] = gyr_segment1
X[..., 2, 3:6] = gyr_segment3

ringnet = ring.RING(lam, Ts)
yhat, _ = ringnet.apply(X)
# yhat: unit quaternions, shape = (B, T_i, N, 4)
Known fixes
Offscreen rendering with Mujoco
mujoco.FatalError: an OpenGL platform library has not been loaded into this process, this most likely means that a valid OpenGL context has not been created before mjr_makeContext was called
Solution:
import os
os.environ["MUJOCO_GL"] = "egl"
Windows-related: ImportError: DLL load failed while importing ...
ImportError: DLL load failed while importing _multiarray_umath: Das angegebene Modul wurde nicht gefunden.
Solution:
pip uninstall -y jax jaxlibconda install -c conda-forge jax
Publications
The main publication is:
The following publications also utilize this software library, and refer to it as the Random Chain Motion Generator (RCMG) (more specifically the function ring.RCMG):
- RNN-based Observability Analysis for Magnetometer-Free Sparse Inertial Motion Tracking
- Plug-and-Play Sparse Inertial Motion Tracking With Sim-to-Real Transfer
- RNN-based State and Parameter Estimation for Sparse Magnetometer-free Inertial Motion Tracking
Other useful ressources
Particularly useful is the following publication from Roy Featherstone
Contact
Simon Bachhuber (simon.bachhuber@fau.de)
How to bump verion in this python package
- commit and push your code changes. Make sure to also update the version in
pyproject.toml - create the tag and push the tag
1 maintainer

Metadata
1 maintainer
Release files for imt-ring 1.7.1
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | |
|---|---|---|---|
| imt_ring-1.7.1.tar.gz | 17.5 MB | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| imt_ring-1.7.1-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 35.0 MB
Release files / imt_ring-1.7.1.tar.gz
| Download URL | imt_ring-1.7.1.tar.gz |
|---|---|
| Size | 17.5 MB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
b3512cd97f734ffd43551a1d569b7ec2207e0556fa12ef52c1b35ac55ba06e0e
|
|
BLAKE2b-256 checksum How to use checksums |
d536d0de2b9c9094796452ff1d51d0393fdb18a195c6dceeb39d645b864032e7
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/6.1.0 CPython/3.12.9
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.


PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Apr 24, 2025.
Transparency logRelease files / imt_ring-1.7.1-py3-none-any.whl
| Download URL | imt_ring-1.7.1-py3-none-any.whl |
|---|---|
| Size | 17.5 MB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
3961890a45160d17353de758afe1cf4ce5b7a42df50f83c5330b4beada18dfbf
|
|
BLAKE2b-256 checksum How to use checksums |
b54032dfd048eb98856099c06db76ee4c872f7bcd75a0d396b47d024bb338844
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/6.1.0 CPython/3.12.9
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Apr 24, 2025.
Transparency log













