
robotics systems using natural language queries. 🗣️🤖


[!IMPORTANT] 📚 New to ROSA? Check out our Wiki for documentation, guides and FAQs!
ROSA is your AI-powered assistant for ROS1 and ROS2 systems. Built on the Langchain framework, ROSA helps you interact with robots using natural language, making robotics development more accessible and efficient.
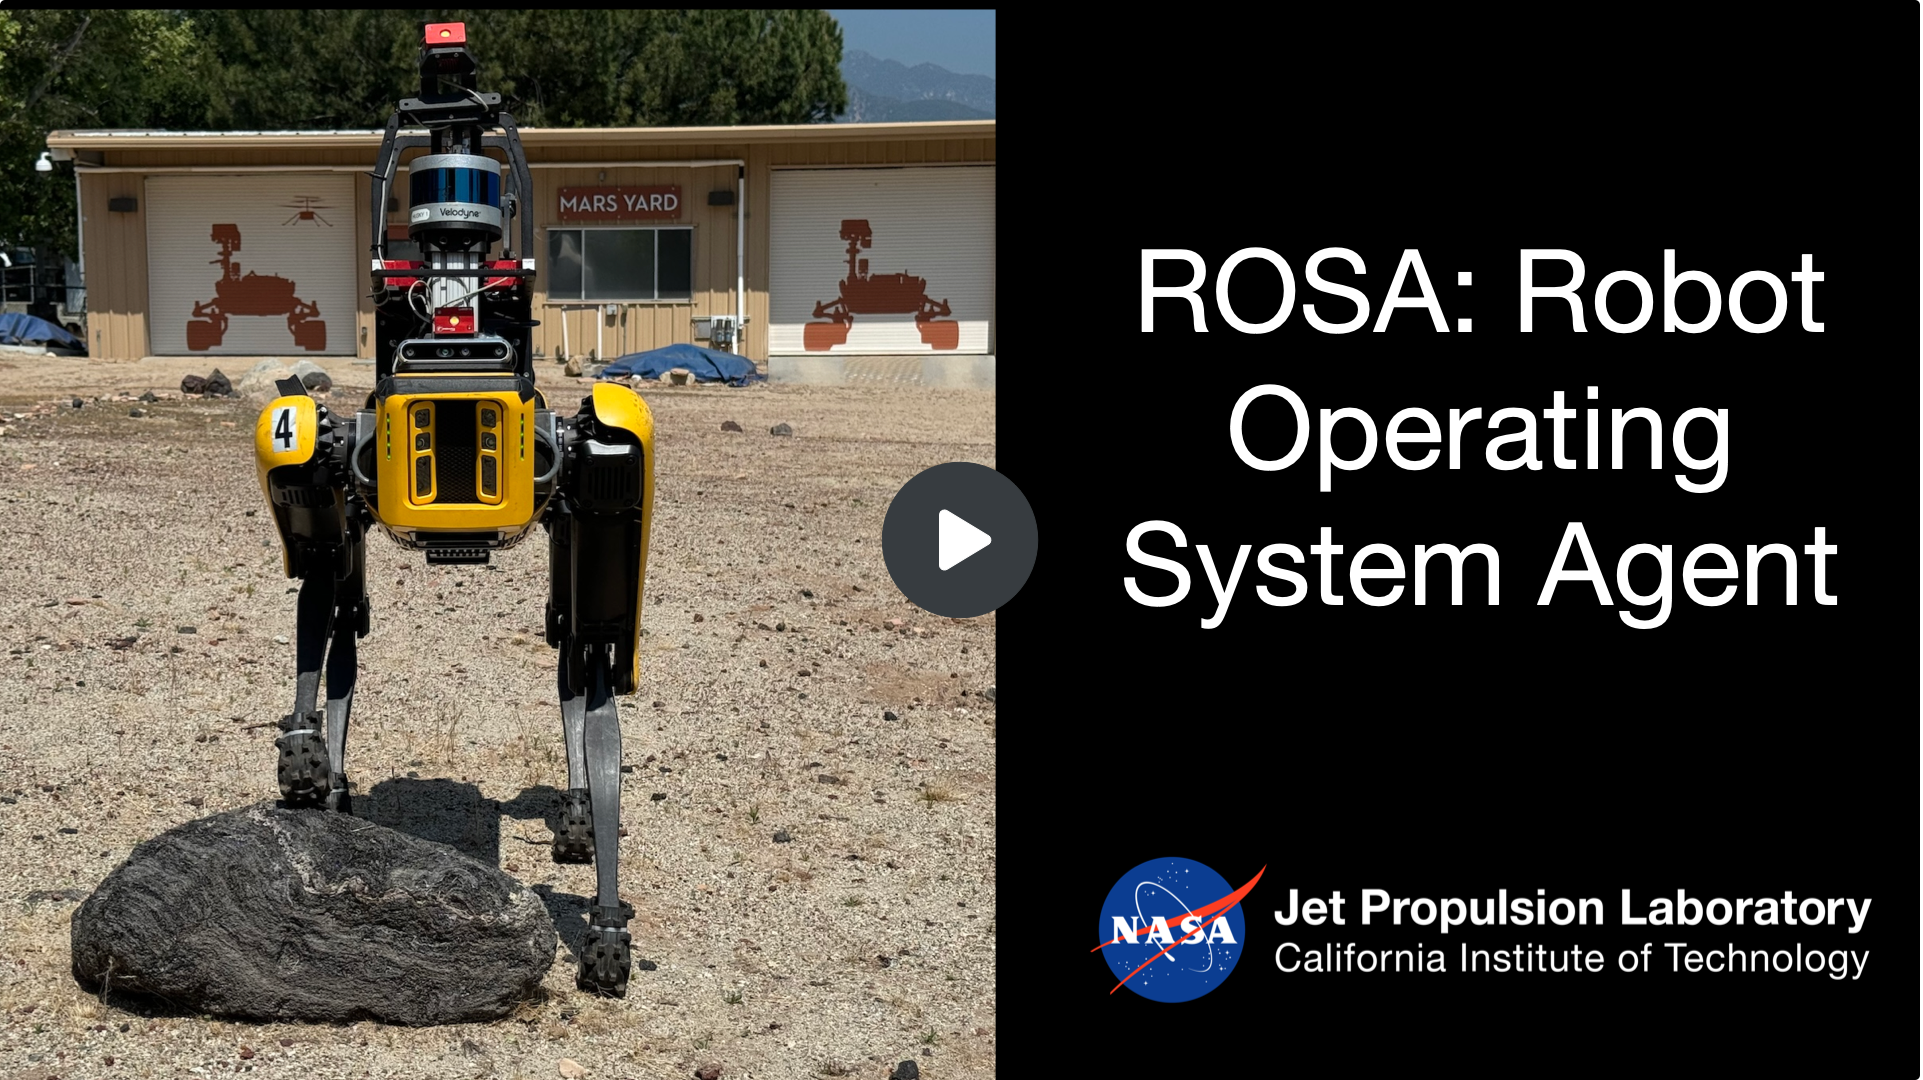
ROSA Demo: NeBula-Spot in JPL's Mars Yard (click for YouTube)
🚀 Quick Start
Requirements
- Python 3.9+
- ROS Noetic or higher
Installation
pip3 install jpl-rosa
Usage Examples
from rosa import ROSA

llm = get_your_llm_here()
agent = ROSA(ros_version=1, llm=llm)
agent.invoke("Show me a list of topics that have publishers but no subscribers")
For detailed information on configuring the LLM, please refer to our Model Configuration Wiki page.
Adapting ROSA for Your Robot 🔧
ROSA is designed to be easily adaptable to different robots and environments. You can create custom agents by either inheriting from the ROSA class or creating a new instance with custom parameters.
For detailed information on creating custom agents, adding tools, and customizing prompts, please refer to our Custom Agents Wiki page.
TurtleSim Demo 🐢
We have included a demo that uses ROSA to control the TurtleSim robot in simulation. To run the demo, you will need to have Docker installed on your machine. 🐳
The following video shows ROSA reasoning about how to draw a 5-point star, then executing the necessary commands to do so.
https://github.com/user-attachments/assets/77b97014-6d2e-4123-8d0b-ea0916d93a4e
For detailed instructions on setting up and running the TurtleSim demo, please refer to our TurtleSim Demo Guide in the Wiki.
IsaacSim Extension (Coming Soon)
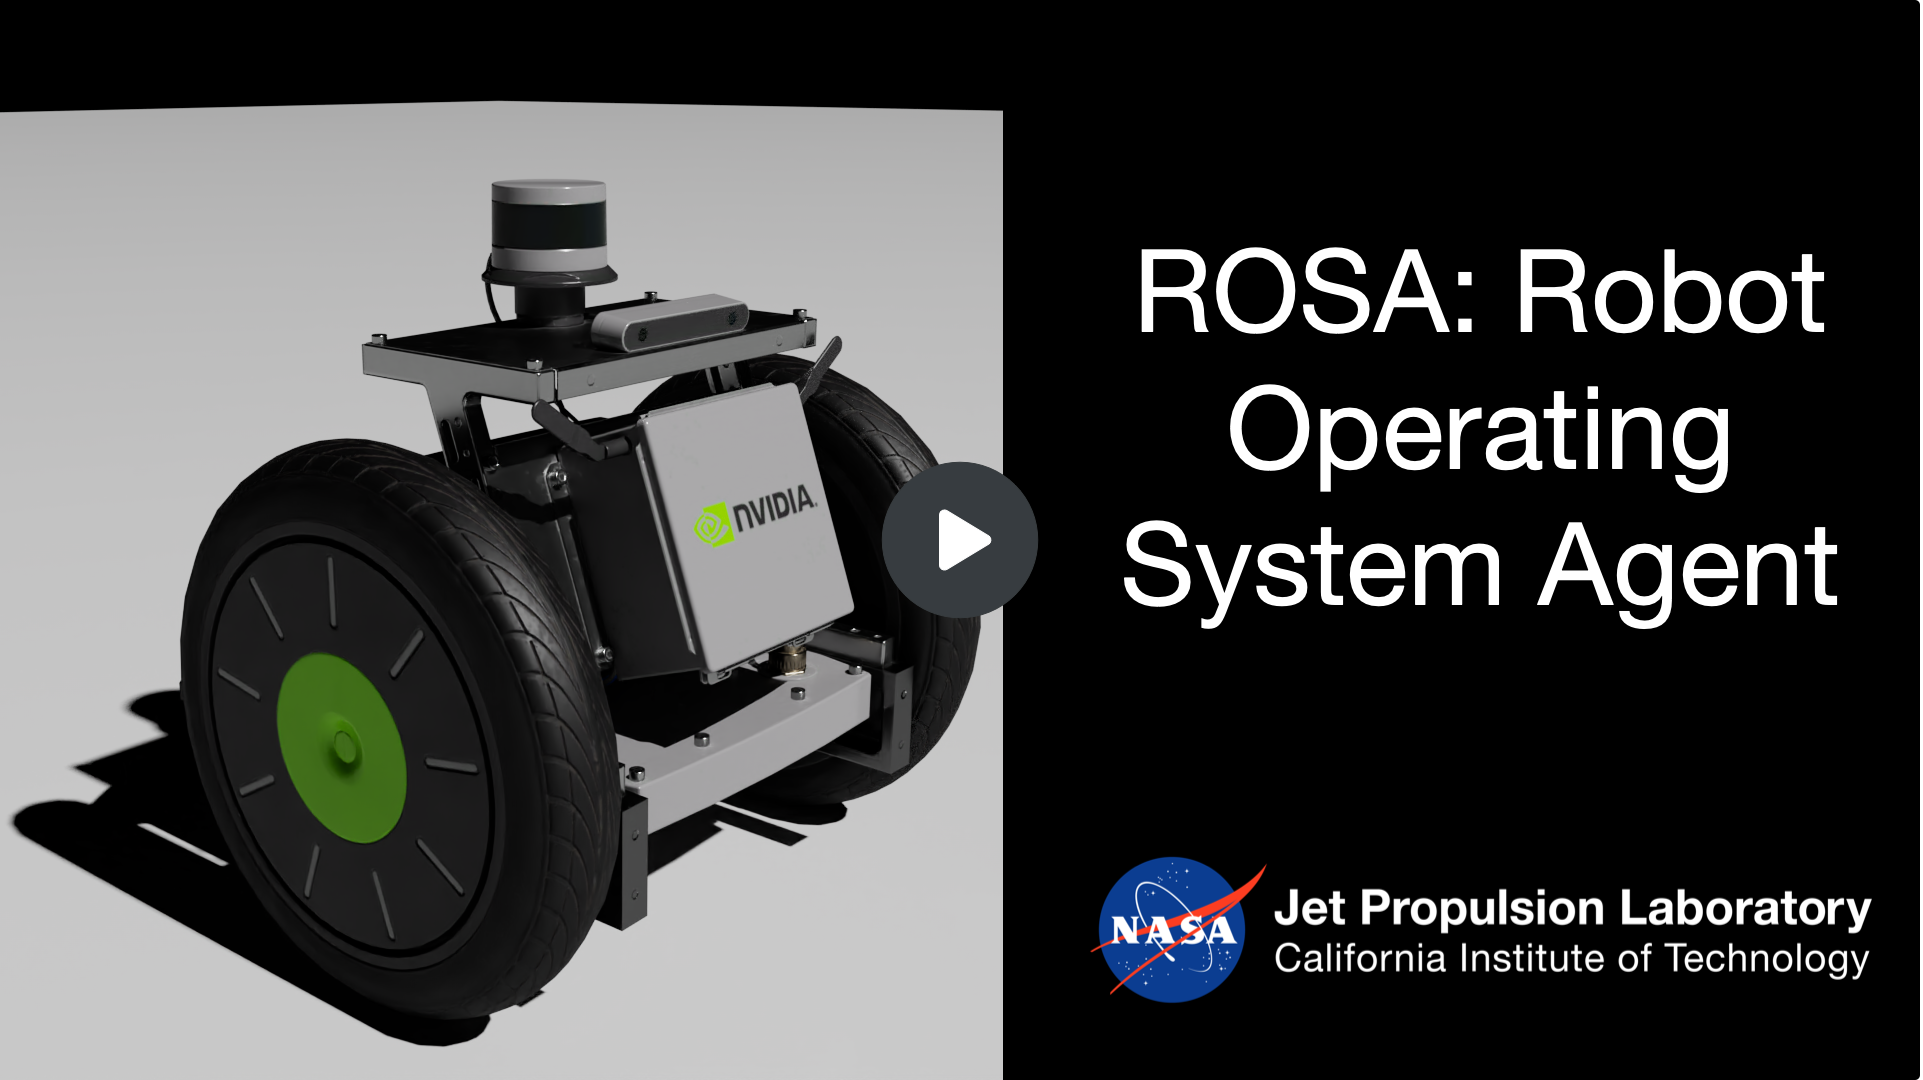
ROSA is coming to Nvidia IsaacSim! While you can already use ROSA with robots running in IsaacSim (using the ROS/ROS2 bridge), we are adding direct integration in the form of an IsaacSim extension. This will allow you not only to control your robots in IsaacSim, but control IsaacSim itself. Check out the video below to learn mroe.
ROSA Demo: Nvidia IsaacSim Extension (click for YouTube)
📘 Learn More
Changelog
See our CHANGELOG.md for a history of our changes.
Contributing
Interested in contributing to our project? Please see our: CONTRIBUTING.md
For guidance on how to interact with our team, please see our code of conduct located at: CODE_OF_CONDUCT.md
For guidance on our governance approach, including decision-making process and our various roles, please see our governance model at: GOVERNANCE.md
License
See our: LICENSE
Support
Key points of contact are:
Copyright (c) 2024. Jet Propulsion Laboratory. All rights reserved.
1 maintainer

Metadata
1 maintainer
Release files for jpl-rosa 1.0.10
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | |
|---|---|---|---|
| jpl_rosa-1.0.10.tar.gz | 48.4 kB | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| jpl_rosa-1.0.10-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 104.0 kB
Release files / jpl_rosa-1.0.10.tar.gz
| Download URL | jpl_rosa-1.0.10.tar.gz |
|---|---|
| Size | 48.4 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
027917167f5df5616b42060bf79f0a2f8ea795a03d89c96b240c65128ade77dd
|
|
BLAKE2b-256 checksum How to use checksums |
5af3b055e9ff1a58f1842f9cb2f1b9fdcb0192b901c3347651f9ae0b69497a18
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/6.2.0 CPython/3.14.3
|
Release files / jpl_rosa-1.0.10-py3-none-any.whl
| Download URL | jpl_rosa-1.0.10-py3-none-any.whl |
|---|---|
| Size | 55.6 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
2afd7309d28dcebf8801dc9099a7d11492ec9d22262348f4730d47795644616e
|
|
BLAKE2b-256 checksum How to use checksums |
d67b59b4f0b6b2736e6051ad8fd83d62683f1e381d55eeb0b54a08ec43c725b0
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/6.2.0 CPython/3.14.3
|














