
ROS Support for jupyter notebooks
While the Jupyter ecosystem has been widely adopted by the Data Science and Machine Learning community, the robotics community has not jumped on the band wagon yet! Most tools around ROS, the Robot Operating System, are built using Python and QT.
However, using QT separates the user away from the code. We've built a set of ROS tools for jupyter notebook, trying to promote a rich, interactive experience for Robotics developers utilizing the power of the jupyter notebook.
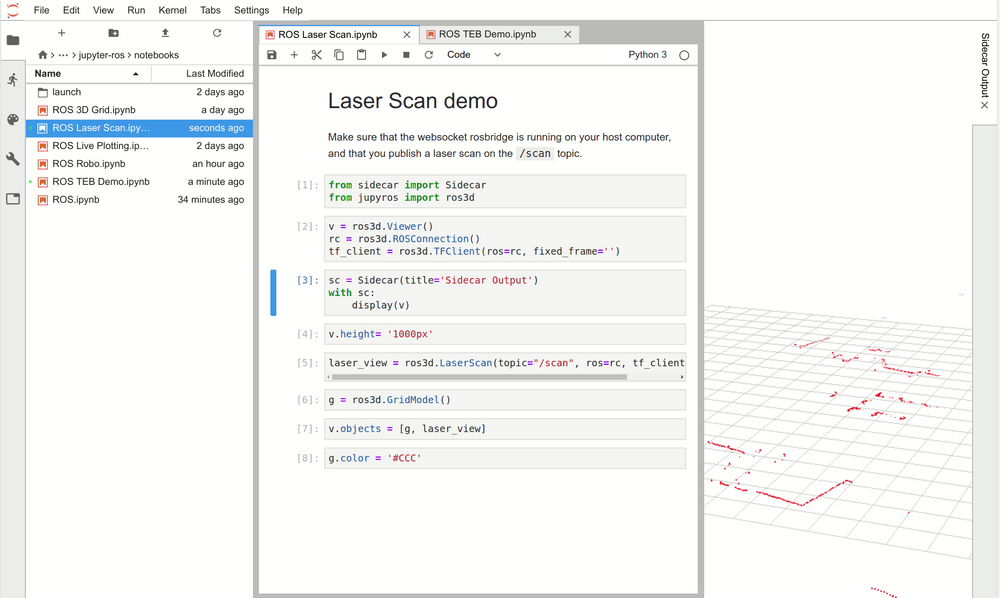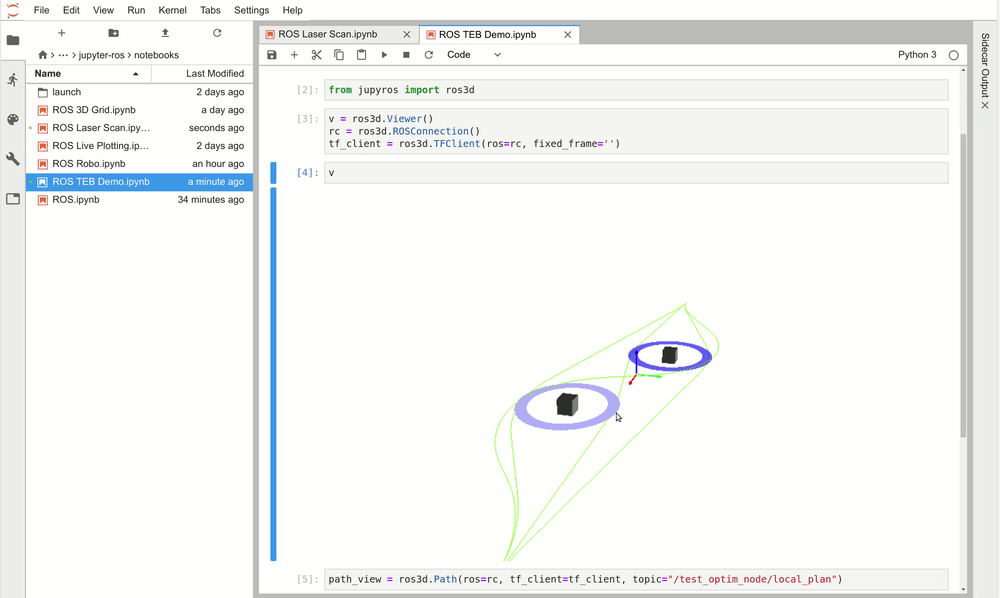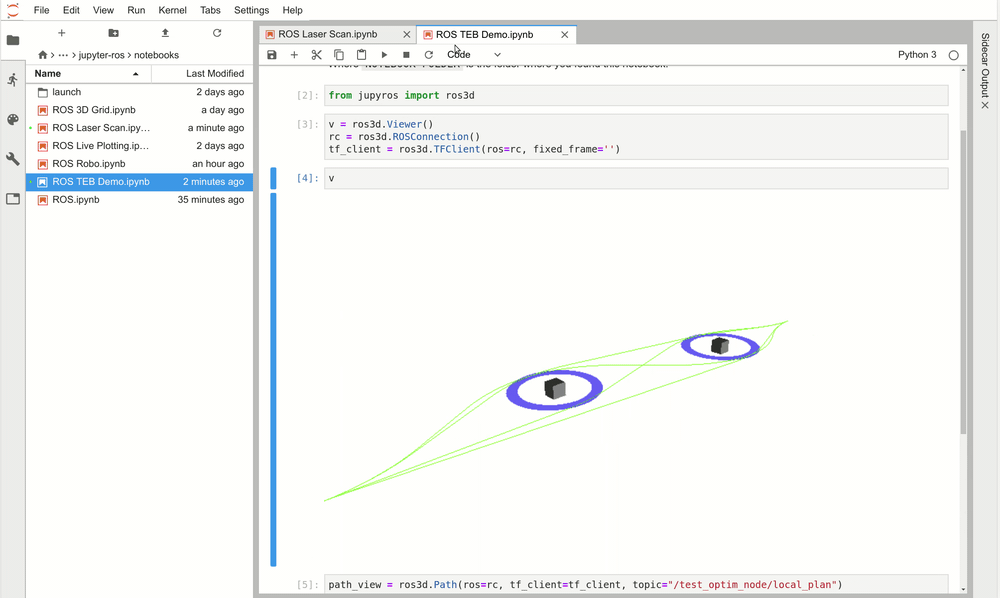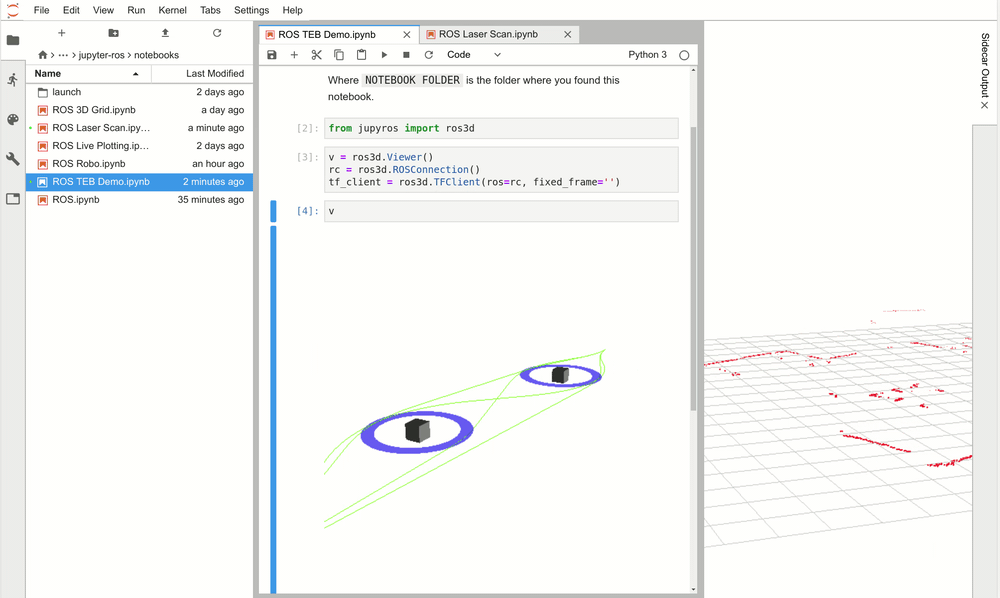
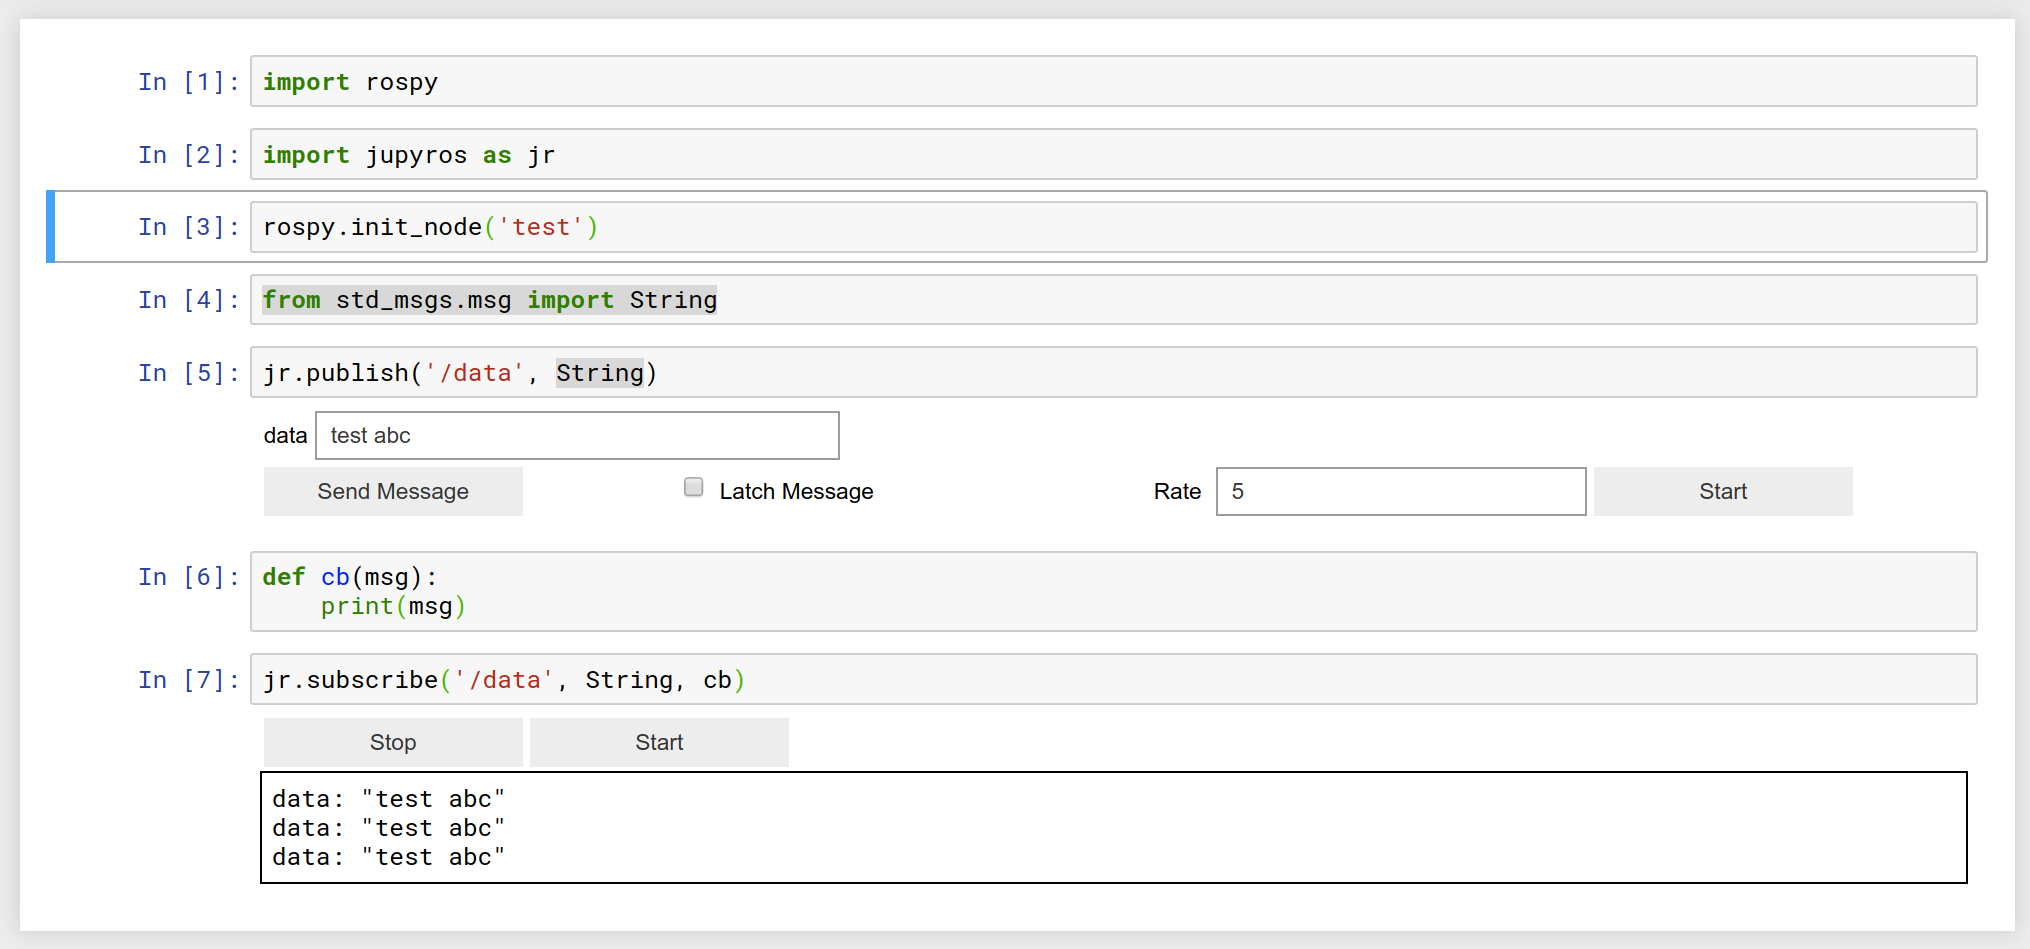
With jupyter-ros, it's possible to easily create widgets for custom message types to send messages.
If you find this package useful, don't hesitate to contribute! You can also always reach out to w.vollprecht@gmail.com or on twitter: https://twitter.com/wuoulf, or join us on Gitter
Installation and Dependencies
You need a ROS environment with rospy. We recommend using Robostack (follow their installation instructions) which allows you to install ROS in a conda environment.
Also required are numpy and bqplot for the live-plotting,
ipywidgets for the interactive widgets, and ipycanvas for the Turtlesim animations.
conda install jupyter bqplot pyyaml ipywidgets ipycanvas
pyyaml is necessary for rospy.
To install use conda or mamba:
conda install jupyter-ros -c robostack
Development installation
You can create a dev environment with:
conda create -n jupyros -c conda-forge python nodejs=14 jupyterlab=3 jupyter bqplot pyyaml ipywidgets ipycanvas
For a development installation (requires npm),
git clone https://github.com/RoboStack/jupyter-ros.git
cd jupyter-ros
pip install -e .
jupyter nbextension install --py --symlink --sys-prefix jupyros
jupyter nbextension enable --py --sys-prefix jupyros
To update the defaults.js javascript you need to run python jupyros/ros3d.py.
Troubleshooting
You might see a warning like "The rospy package is not found in your $PYTHONPATH. Subscribe and publish are not going to work. Do you need to activate your ROS environment?"
This is harmless during installation, but if you see this warning in a notebook, you should check that your ROS environment is activated. You can also set the path from inside the notebook using
import sys
sys.path.append('/opt/ros/melodic/lib/python2.7/dist-packages/')

# The next line should now work!
import jupyros
If you got the following error when you run a cell failed to display Jupyter Widget of type VBox,
you can solve it by running the following command jupyter nbextension enable --py --sys-prefix widgetsnbextension
License
We use a shared copyright model that enables all contributors to maintain the copyright on their contributions.
This software is licensed under the BSD-3-Clause license. See the LICENSE file for details.


Release files for jupyros 0.7.0
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | Provenance | Actions |
|---|---|---|---|---|
| jupyros-0.7.0.tar.gz | 30.8 MB | Without provenance | Details for jupyros-0.7.0.tar.gz |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Actions Reset |
|---|---|---|---|---|
| jupyros-0.7.0-py3-none-any.whl | Python 3 | none | any | Details for jupyros-0.7.0-py3-none-any.whl |
Total release size: 32.0 MB
Release files / jupyros-0.7.0.tar.gz
| Download URL | jupyros-0.7.0.tar.gz |
|---|---|
| Size | 30.8 MB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
e21cb6cd7535076cb2bf93f9b1aef002a313a11922e0f39dab954512663a2877
|
|
BLAKE2b-256 checksum How to use checksums |
9b3b3d6935e89efee10b49bd5638a156473ca4b27d9e74c7bddf4efcfb0235f0
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/4.0.2 CPython/3.12.0
|
Release files / jupyros-0.7.0-py3-none-any.whl
| Download URL | jupyros-0.7.0-py3-none-any.whl |
|---|---|
| Size | 1.2 MB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
0f55edbde842f5ec0b440c0b8b7bc1b962ad5017a1338bf6c88fa93b9a9774fd
|
|
BLAKE2b-256 checksum How to use checksums |
31e867232deeea10105fd760d04179fad26b064e6d9081c6a58d4cebafc8cbf1
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/4.0.2 CPython/3.12.0
|
Security for jupyros 0.7.0
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
No provenance found
None of the files in this release were uploaded with provenance metadata.
A note on package security
PyPI is a repository for distributing packages, not a service for auditing them. While third-party security researchers and our staff do their best to detect and remove malicious packages, PyPI cannot guarantee the quality, security or suitability of any given package.
To learn more about protecting yourself from malicious actors, visit our package security documentation.














