
JVRC humanoid robot model
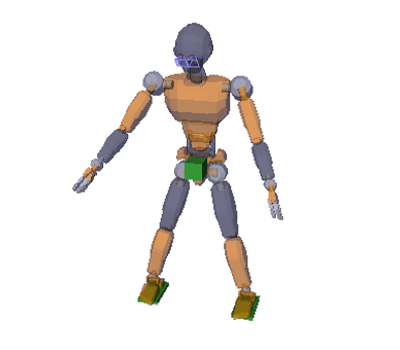

This package contains the robot description for the JVRC-1 model, a virtual humanoid robot released for education and research.
Python module
This module helps retrieve the JVRC-1 model from a Python program. Import it by:
import jvrc_description
It then provides the following paths:
-
jvrc_description.path -
Path to the
jvrc_descriptionfolder itself. -
jvrc_description.meshes_path -
Path to the
meshesfolder. -
jvrc_description.urdf_path -
Path to the
jvrc1.urdfURDF file of the model.
1 maintainer

Metadata
1 maintainer
Release files for jvrc_description 1.1.1
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | |
|---|---|---|---|
| jvrc_description-1.1.1.tar.gz | 666.0 kB | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| jvrc_description-1.1.1-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 1.4 MB
Release files / jvrc_description-1.1.1.tar.gz
| Download URL | jvrc_description-1.1.1.tar.gz |
|---|---|
| Size | 666.0 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
1fc12384f91515876e3bb9e73ef7e4530676d1798b8ffb0e46107e5b9886aa49
|
|
BLAKE2b-256 checksum How to use checksums |
5d0f9ca8392c42cdcc38e9ded2ce65b6fc3d0b5646fe61a5f021d26015f232b2
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
python-requests/2.22.0
|
Release files / jvrc_description-1.1.1-py3-none-any.whl
| Download URL | jvrc_description-1.1.1-py3-none-any.whl |
|---|---|
| Size | 723.2 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
68f8bc88cdb9a221bc60ba2ec26a77560100cead738e8e2ce8e4599764526c5c
|
|
BLAKE2b-256 checksum How to use checksums |
d20edb52cce5e26d175b13eacdbe87e111dee5228fd2eeea7ebdf40912087de9
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
python-requests/2.22.0
|














