
LSM6DS3 Python Library


Generated from the Pimoroni Python Boilerplate.
The LSM6DS3TR-C is an always-on 3D accelerometer and 3D gyroscope that includes additional built-in functions such as:
- Pedometer
- Tap and double tap recognition
- Significant motion and tilt detection
- Free-fall detection
Installing
We'd recommend using this library with Raspberry Pi OS Bookworm or later. It requires Python ≥3.7.
Full install (recommended):
We've created an easy installation script that will install all pre-requisites and get you up and running with minimal efforts. To run it, fire up Terminal which you'll find in Menu -> Accessories -> Terminal on your Raspberry Pi desktop, as illustrated below:
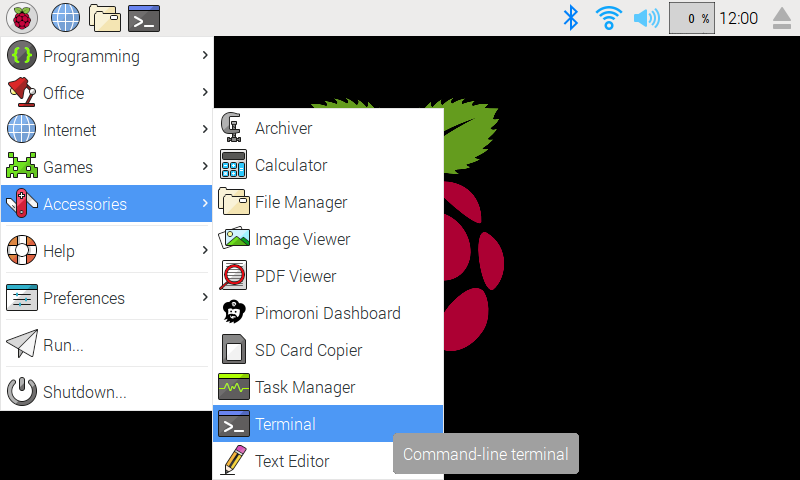
In the new terminal window type the commands exactly as it appears below (check for typos) and follow the on-screen instructions:
git clone https://github.com/pimoroni/lsm6ds3-python
cd lsm6ds3-python
./install.sh
Note Libraries will be installed in the "pimoroni" virtual environment, you will need to activate it to run examples:
source ~/.virtualenvs/pimoroni/bin/activate
Development:
If you want to contribute, or like living on the edge of your seat by having the latest code, you can install the development version like so:
git clone https://github.com/pimoroni/lsm6ds3-python
cd lsm6ds3-python
./install.sh --unstable
Install stable library from PyPi and configure manually
- Set up a virtual environment:
python3 -m venv --system-site-packages $HOME/.virtualenvs/pimoroni - Switch to the virtual environment:
source ~/.virtualenvs/pimoroni/bin/activate - Install the library:
pip install lsm6ds3
In some cases you may need to us sudo or install pip with: sudo apt install python3-pip.
This will not make any configuration changes, so you may also need to enable:
- i2c:
sudo raspi-config nonint do_i2c 0
You can optionally run sudo raspi-config or the graphical Raspberry Pi Configuration UI to enable interfaces.
Changelog
0.0.2
- Updated to library name from
LSM6DS3tolsm6ds3to match our other libraries.
0.0.1
- Initial Release
1 maintainer

Release files for lsm6ds3 0.0.2
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | |
|---|---|---|---|
| lsm6ds3-0.0.2.tar.gz | 11.5 kB | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| lsm6ds3-0.0.2-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 19.2 kB
Release files / lsm6ds3-0.0.2.tar.gz
| Download URL | lsm6ds3-0.0.2.tar.gz |
|---|---|
| Size | 11.5 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
bb13d8d7301e629ff9f9e86f0a39eb5179a1c160aa6c3b4e4a3dab92dac424dd
|
|
BLAKE2b-256 checksum How to use checksums |
51ae0161250a2693734cd740c695dbab79b6c561931cfbdf89cf670f0cda178d
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/5.1.1 CPython/3.12.3
|
Release files / lsm6ds3-0.0.2-py3-none-any.whl
| Download URL | lsm6ds3-0.0.2-py3-none-any.whl |
|---|---|
| Size | 7.7 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
60b5c68ad8c1edd1f44681a9b1f6ec4d9aac6d4ff6f931c5b4d67831e526e857
|
|
BLAKE2b-256 checksum How to use checksums |
b46c336d7bec75c8c4a1f4b5c19ee14efd612cf712381a776df6df64893b4369
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/5.1.1 CPython/3.12.3
|














