
mcap-to-mp4
A tool for converting ROS 2 image topics recorded in rosbag2 MCAP files into MP4 videos
English
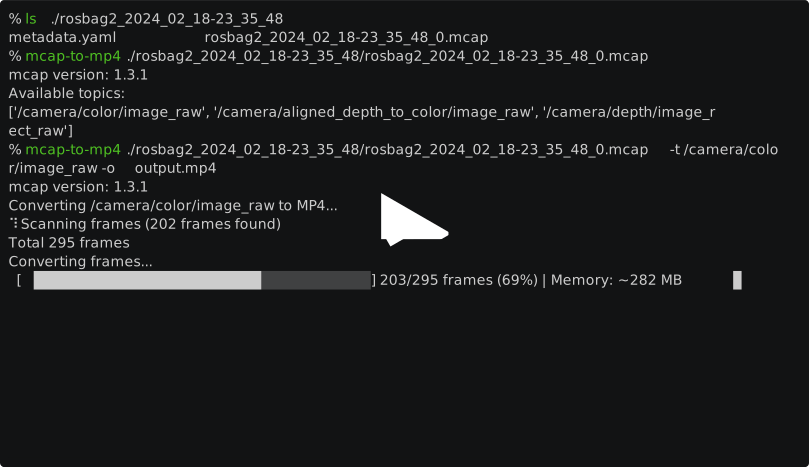
This tool provides a simple way to convert ROS 2 image topics recorded in rosbag2 MCAP files into standard MP4 video files.
It is especially useful for visualizing and sharing regularly published image streams, such as camera feeds.
By default, the tool assumes that input messages are recorded at a roughly fixed rate, and generates an MP4 using the average frame interval of the input messages (CFR: Constant Frame Rate).
When needed, --timestamp-timing enables sensor_msgs/Image.header.stamp-based timing (VFR: Variable Frame Rate).
As a result, the generated videos are well suited for experiment reviews, demos, and presentations.
日本語
このツールは、rosbag2 の MCAP ファイルに記録された ROS 2 の画像トピックを、標準的な MP4 動画ファイルに変換します。
カメラ映像のように、一定周期で発行される画像ストリームの可視化や共有に特に便利です。
デフォルトでは入力メッセージがおおむね一定周期で記録されていることを前提とし、生成される MP4 は入力メッセージ間の平均フレーム間隔(CFR: Constant Frame Rate / 固定フレームレート)を用いて出力します。
--timestamp-timing を指定すると sensor_msgs/Image.header.stamp を使った可変フレームレート(VFR: Variable Frame Rate / 可変フレームレート)で出力します。
そのため、実験の振り返りやデモ、プレゼンテーションに適しています。
Supported Message Types
| Message type | Description | Required dependencies |
|---|---|---|
sensor_msgs/msg/Image |
Uncompressed image (rgb8, bgr8, etc.) | pillow, numpy, imageio, ffmpeg |
sensor_msgs/msg/CompressedImage |
JPEG/PNG compressed image | pillow, numpy, imageio, ffmpeg |
foxglove_msgs/msg/CompressedVideo |
H.264/H.265 codec-compressed video | PyAV (av), FFmpeg libraries, imageio, ffmpeg |
sensor_msgs/msg/Image and sensor_msgs/msg/CompressedImage are supported out of the box.
foxglove_msgs/msg/CompressedVideo requires PyAV and FFmpeg development libraries for decoding codec-compressed frames (e.g., H.264 NAL units).
PyAV is included as a dependency and installed automatically via pip install or uv sync.
If codec initialization fails, make sure your FFmpeg installation supports the required codec (e.g., libavcodec-extra on Ubuntu/Debian).
Requirements
Note: This tool does NOT require a ROS 2 runtime environment. You only need Python and the following dependencies:
- Python3
- mcap
- mcap-ros2-support
- pillow
- numpy
- imageio
- av (PyAV)
- ffmpeg
QuickStart
pip
# Install
pip install mcap-to-mp4
# Run
mcap-to-mp4 $path_to_the_mcap_file -t $topic_name -o $outputfilename
uv
# Install
uv tool install mcap-to-mp4
# Run
mcap-to-mp4 $path_to_the_mcap_file -t $topic_name -o $outputfilename
Docker
# Build
git clone https://github.com/Tiryoh/mcap-to-mp4.git
docker build -t tiryoh/mcap-to-mp4 .
# Run
docker run --rm -it -v "${PWD}:/works" tiryoh/mcap-to-mp4 $path_to_the_mcap_file -t $topic_name -o $outputfilename
Usage
pip
Install the package from PyPI
pip install mcap-to-mp4
Install the package from source (optional)
# optional
git clone https://github.com/Tiryoh/mcap-to-mp4.git
cd mcap-to-mp4
pip install -e .
mcap-to-mp4 --help
uv
Install the package from PyPI
uv tool install mcap-to-mp4
Install the package from source (optional)
# optional
git clone https://github.com/Tiryoh/mcap-to-mp4.git
cd mcap-to-mp4
uv sync --group dev
# Run with uv run
uv run mcap-to-mp4 --help
Download sample mcap rosbag2 file
wget "https://drive.usercontent.google.com/download?id=1TxKxq-SN_9ryiFxH6kQG07Gy90_bpnWW&confirm=xxx" -O "realsense_rosbag2.zip"
unzip realsense_rosbag2.zip
Run
# With pip or uv tool install:
mcap-to-mp4 ./rosbag2_2024_02_18-23_35_48/rosbag2_2024_02_18-23_35_48_0.mcap -t /camera/color/image_raw -o output.mp4

# With uv sync (source install):
uv run mcap-to-mp4 ./rosbag2_2024_02_18-23_35_48/rosbag2_2024_02_18-23_35_48_0.mcap -t /camera/color/image_raw -o output.mp4

# Optional: use header.stamp based VFR timing
mcap-to-mp4 ./rosbag2_2024_02_18-23_35_48/rosbag2_2024_02_18-23_35_48_0.mcap -t /camera/color/image_raw -o output_vfr.mp4 --timestamp-timing
Docker
Install the package
git clone https://github.com/Tiryoh/mcap-to-mp4.git
docker build -t tiryoh/mcap-to-mp4 .
Download sample mcap rosbag2 file
wget "https://drive.usercontent.google.com/download?id=1TxKxq-SN_9ryiFxH6kQG07Gy90_bpnWW&confirm=xxx" -O "realsense_rosbag2.zip"
unzip realsense_rosbag2.zip
Run
docker run --rm -it -v "${PWD}:/works" tiryoh/mcap-to-mp4 ./rosbag2_2024_02_18-23_35_48/rosbag2_2024_02_18-23_35_48_0.mcap -t /camera/color/image_raw -o output.mp4

# Optional: use header.stamp based VFR timing
docker run --rm -it -v "${PWD}:/works" tiryoh/mcap-to-mp4 ./rosbag2_2024_02_18-23_35_48/rosbag2_2024_02_18-23_35_48_0.mcap -t /camera/color/image_raw -o output_vfr.mp4 --timestamp-timing
Notes
--timestamp-timingoption: This option saves each frame as a PNG file to a temporary directory before encoding with ffmpeg, which takes significantly longer than the default CFR mode. For example, a 6868-frame rosbag took about 4 minutes in CFR mode vs. about 11 minutes in VFR mode (measured on M3 MacBook Air).- Memory check: During conversion, the tool estimates memory usage and displays it.
- Linux (including WSL): Estimated memory usage is displayed. If available system memory is low, a warning is shown and you will be prompted to continue or abort.
- macOS: Estimated memory usage is displayed. Available memory check is not supported.
- Windows (non-WSL): Memory check is not supported.
License
Copyright 2024-2026 Daisuke Sato
This repository is licensed under the MIT license, see LICENSE.
Unless attributed otherwise, everything in this repository is under the MIT license.
Related Projects
1 maintainer

Metadata
1 maintainer
Release files for mcap-to-mp4 0.6.0
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | Provenance | |
|---|---|---|---|---|
| mcap_to_mp4-0.6.0.tar.gz | 88.6 kB | Without provenance | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| mcap_to_mp4-0.6.0-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 99.7 kB
Release files / mcap_to_mp4-0.6.0.tar.gz
| Download URL | mcap_to_mp4-0.6.0.tar.gz |
|---|---|
| Size | 88.6 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
afc42b8aeb6a045e2708f27aabcf1b074e0cce6d8f4a7b2fed1fc47c9963bc01
|
|
BLAKE2b-256 checksum How to use checksums |
6a026b37ed913c1a45d47698356764f7484ab3e6306c7607086aaf4f6a2a7709
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/6.1.0 CPython/3.13.7
|
Release files / mcap_to_mp4-0.6.0-py3-none-any.whl
| Download URL | mcap_to_mp4-0.6.0-py3-none-any.whl |
|---|---|
| Size | 11.1 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
5fad4cadf475825b8d1b2a17095459e596ee85862f866d1ab93f985457f1dea0
|
|
BLAKE2b-256 checksum How to use checksums |
680f159e5fa9bb3aef38abed59d5cdc2ae4b9ecedff35a28bf0d75c311288851
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/6.1.0 CPython/3.13.7
|
Security for mcap-to-mp4 0.6.0
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
No provenance found
None of the files in this release were uploaded with provenance metadata.
A note on package security
PyPI is a repository for distributing packages, not a service for auditing them. While third-party security researchers and our staff do their best to detect and remove malicious packages, PyPI cannot guarantee the quality, security or suitability of any given package.














