
model_predictive_control


Python implementation of MPC solver
Install it from PyPI
pip install model_predictive_control
Usage
import numpy as np

from model_predictive_control.cost.trajectory2d_steering_penalty import (
    Traj2DSteeringPenalty,
)
from model_predictive_control.models.bicycle import (
    BicycleModel,
    BicycleModelParams,
)
from model_predictive_control.mpc import MPC

# Initialize the Bicycle Model
params = BicycleModelParams(
    time_step=time_step,
    steering_ratio=13.27,
    wheel_base=2.83972,
    speed_kp=1.0,
    speed_ki=0.1,
    speed_kd=0.05,
    throttle_min=-1.0,
    throttle_max=1.0,
    throttle_gain=5.0,  # Max throttle corresponds to 5m/s^2
)
bicycle_model = BicycleModel(params)

# Define the cost function
cost = Traj2DSteeringPenalty(model=bicycle_model)

# Initialize MPC Controller
horizon = 20
state_dim = 4  # (x, y, theta, velocity)
controls_dim = 2  # (steering_angle, velocity)

mpc = MPC(
    model=bicycle_model,
    cost=cost,
    horizon=horizon,
    state_dim=state_dim,
    controls_dim=controls_dim,
)

# Define initial state (x, y, theta, velocity)
start_state = [0.0, 0.0, 0.0, 1.0]

# Define desired trajectory: moving in a straight line
desired_state_sequence = [[i * 1.0, i * 0.5, 0.0, 1.0] for i in range(horizon)]

# Initial control sequence: assuming zero steering and constant speed
initial_control_sequence = [[0.0, 1.0] for _ in range(horizon)]

# Define control bounds: steering_angle between -0.5 and 0.5 radians,
# velocity between 0.0 and 2.0 m/s
bounds = [[(-np.deg2rad(400), np.deg2rad(400)), (-1.0, 1.0)] for _ in range(horizon)]

# Optimize control inputs using MPC
optimized_control_sequence = mpc.step(
    start_state_tuple=start_state,
    desired_state_sequence=desired_state_sequence,
    initial_control_sequence=initial_control_sequence,
    bounds=bounds,
    max_iters=50,
)
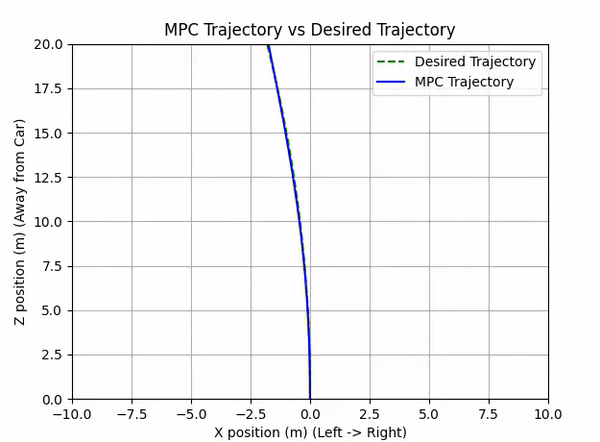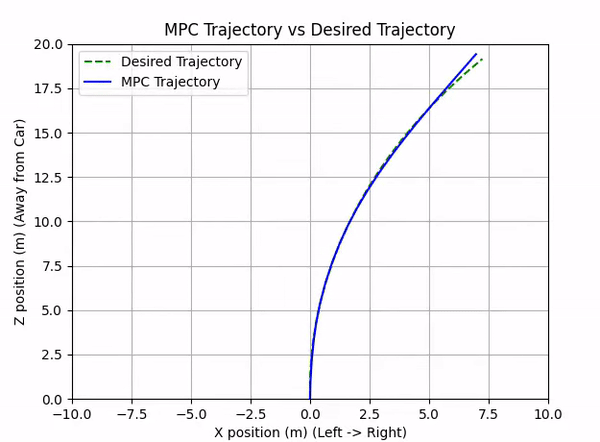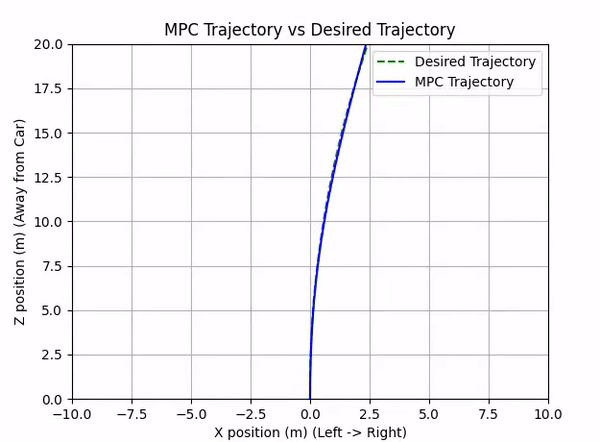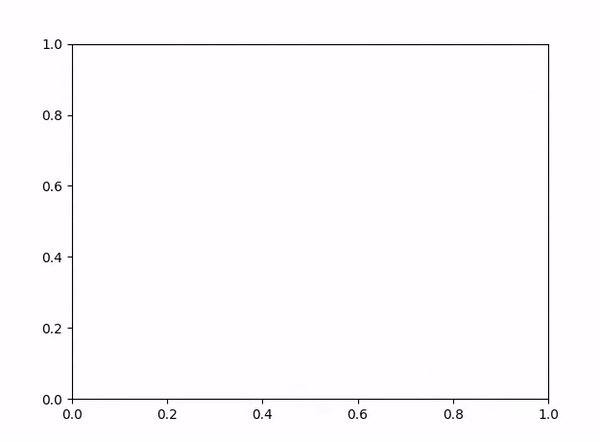
Run the demo with the following
$ python -m model_predictive_control
#or
$ model_predictive_control
Cite
This work was a part of the D³Nav paper. Cite our work if you find it useful
@article{NG2024D3Nav,
  title={D³Nav: Data-Driven Driving Agents for Autonomous Vehicles in Unstructured Traffic},
  author={Aditya NG and Gowri Srinivas},
  journal={The 35th British Machine Vision Conference (BMVC)},
  year={2024},
  url={https://bmvc2024.org/}
}
Development
Read the CONTRIBUTING.md file.
TODO
- Bicycle Model
- Drone Model
- MPC
- Visualizer Demo
- MPC Auto-Optimizer: Takes a set of expected vehicle trajectories and the search space of hyperparamters and returns the list of optimal hyperparameters
- MPC Compiler: Takes the MPC model with a set of expected vehicle trajectories and produces numpy array a mapping from trajectory to control signals. This can be used with a cosine similarity logic to decide on control logic in real time.
1 maintainer

Metadata
1 maintainer
Release files for model-predictive-control 0.4.0
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | Provenance | Actions |
|---|---|---|---|---|
| model_predictive_control-0.4.0.tar.gz | 18.9 kB | Without provenance | Details for model_predictive_control-0.4.0.tar.gz |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Actions Reset |
|---|---|---|---|---|
| model_predictive_control-0.4.0-py3-none-any.whl | Python 3 | none | any | Details for model_predictive_control-0.4.0-py3-none-any.whl |
Total release size: 37.7 kB
Release files / model_predictive_control-0.4.0.tar.gz
| Download URL | model_predictive_control-0.4.0.tar.gz |
|---|---|
| Size | 18.9 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
5d812faf790f7df54c4308914f30d4757809d6de0a131712fc817942508a8236
|
|
BLAKE2b-256 checksum How to use checksums |
2dd7bc2ff7874919a90b709a09d4e15d6edbab6582878d8c8517e79dda37efc5
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/5.1.1 CPython/3.12.5
|
Release files / model_predictive_control-0.4.0-py3-none-any.whl
| Download URL | model_predictive_control-0.4.0-py3-none-any.whl |
|---|---|
| Size | 18.8 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
e4b5514684a2ea2a1270e7617b0f2cfa12aa63b3041ede965110c6bd968259b0
|
|
BLAKE2b-256 checksum How to use checksums |
caf50057d3708f50299551bff0e211100e3ebf3448f4f9d766cf0c70b196d26f
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/5.1.1 CPython/3.12.5
|
Security for model-predictive-control 0.4.0
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
No provenance found
None of the files in this release were uploaded with provenance metadata.
A note on package security
PyPI is a repository for distributing packages, not a service for auditing them. While third-party security researchers and our staff do their best to detect and remove malicious packages, PyPI cannot guarantee the quality, security or suitability of any given package.
To learn more about protecting yourself from malicious actors, visit our package security documentation.














