
msfc-ccd


A Python library for characterizing and using the CCD cameras developed by Marshall Space Flight Center.
The sounding rocket team at MSFC builds CCD cameras for solar instruments flown on sounding rockets. This library reads the FITS files those cameras produce, and models the camera and sensor well enough to turn a raw readout into a calibrated image.
Every array in this package is a named_arrays array, so the axes carry names such as detector_x rather than integer positions, and an image loaded from disk broadcasts against the other arrays in the stack without reshaping.
More information is available in the documentation.
Installation
msfc-ccd is available on PyPI and can be installed using pip:
pip install msfc-ccd
Features
fits.open(), which loads one FITS file, or a sequence of them, into a single object.SensorData, an image or a sequence of images as read from the sensor, along with the operations that calibrate it:.taps,.active,.unbiased, and.electrons.TapData, the same image split into the four quadrants read out by the four taps of the sensor.ImageHeader, the FITS metadata for each image, including the exposure time, the sensor and FPGA temperatures, and the timestamps.CameraandTeledyneCCD230, models of the camera and its sensor, carrying the parameters needed to calibrate an image: gain, dark current, readout noise, charge transfer efficiency, and the exposure timing.noise,dark,gainandcte, which measure the readout noise, dark current, gain and charge transfer efficiency of each tap from darks, flats and Fe 55 exposures.samples, a handful of real FITS files gathered from the cameras, used by the examples below.
Key concepts
An image pairs pixel values with the header that describes them.
SensorData stores the pixel values in .outputs, in data numbers (astropy.units.DN), on axes named by .axis_x and .axis_y, and the FITS metadata in .inputs as an ImageHeader.
Loading many files at once adds another named axis to both, so a sequence of images is the same type as a single image.
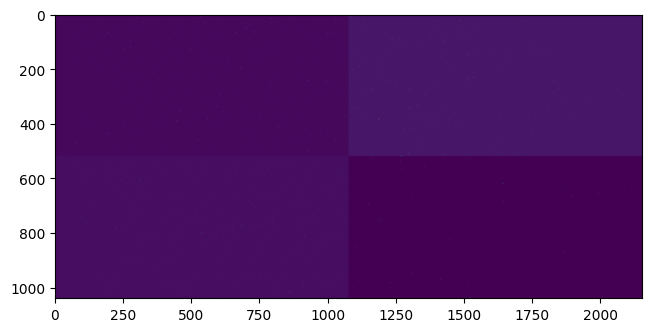
The sensor is read out through four taps.
Each quadrant of the CCD has its own amplifier, so a raw frame is really four images side by side, each with its own bias and gain.
.taps splits a frame into a TapData with tap_x and tap_y axes, and .from_taps() reassembles one, flipping each quadrant back into the orientation of the sensor.
Blank and overscan columns measure the bias.
Each tap reads out 50 blank columns before the light-sensitive pixels and 2 overscan columns after them.
Those columns see no light, so their mean is an estimate of the bias for that tap.
.active trims them away, .unbiased subtracts the bias they measure, and the two compose: image.taps.unbiased.active.
Converting to electrons needs a gain.
.electrons multiplies by Camera.gain, which is usually different for each tap and has to be measured.
A Camera constructed without one, which is what fits.open() uses by default, has no gain to apply, and raises a ValueError naming the missing parameter rather than guessing.
Measure it with msfc_ccd.gain.fe55() or msfc_ccd.gain.photon_transfer(), and supply the result with msfc_ccd.Camera(gain=...) before converting.
Examples
Load and display a single FITS file.
import matplotlib.pyplot as plt
import named_arrays as na
import msfc_ccd

# Load the sample image
image = msfc_ccd.fits.open(msfc_ccd.samples.path_fe55_esis1)

# Display the sample image
fig, ax = plt.subplots(
    constrained_layout=True,
)
im = na.plt.imshow(
    image.outputs.value,
    axis_x=image.axis_x,
    axis_y=image.axis_y,
    ax=ax,
);
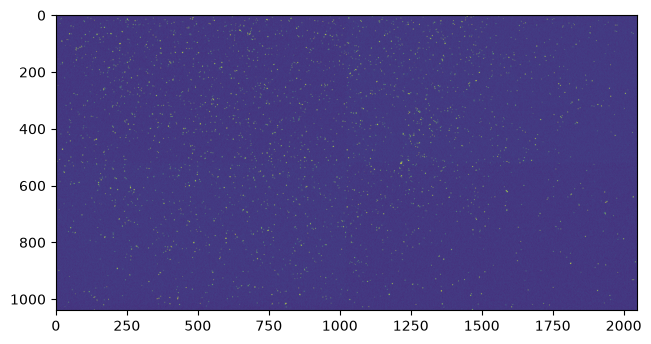
Measure the bias of each tap, and remove it.
# Split the frame into the four tap images
taps = image.taps

# Each tap has its own amplifier, and so its own bias
taps.bias().outputs
ScalarArray(
    ndarray=[[3571.56153846, 3807.21634615],
             [3652.99519231, 3446.92692308]] DN,
    axes=('tap_y', 'tap_x'),
)
# Subtract the bias and trim the blank and overscan columns
corrected = image.from_taps(taps.unbiased.active)

# Display the corrected image
fig, ax = plt.subplots(
    constrained_layout=True,
)
im = na.plt.imshow(
    corrected.outputs.value,
    axis_x=corrected.axis_x,
    axis_y=corrected.axis_y,
    ax=ax,
    vmin=-20,
    vmax=100,
);
Inspect the header of an image.
header = image.inputs

print(f"serial number:  {header.serial_number.ndarray}")
print(f"exposure:       {header.timedelta.ndarray}")
print(f"start:          {header.time_start.ndarray}")
print(f"FPGA temp:      {header.temperature_fpga.ndarray}")
serial number:  6
exposure:       1.999999975 s
start:          2017-07-06T16:36:48.449
FPGA temp:      38.881396484375045 deg_C
Inspect the sensor model that the calibration steps rely on.
import astropy.units as u

sensor = image.camera.sensor

print(f"sensor:          {sensor.manufacturer} {sensor.family}")
print(f"active pixels:   {sensor.num_pixel_x} x {sensor.num_pixel_y}")
print(f"blank/overscan:  {sensor.num_blank} / {sensor.num_overscan}")
print(f"readout noise:   {sensor.readout_noise}")
print(f"charge transfer: {sensor.cte}")
print(f"dark current:    {sensor.dark_current(263 * u.K):0.3f} at 263 K")
sensor:          Teledyne/e2v CCD230-42
active pixels:   2048 x 2064
blank/overscan:  50 / 2
readout noise:   4.0 electron
charge transfer: 99.9995 %
dark current:    1.039 electron / s at 263 K
Citation
If you use msfc-ccd in your research, please cite it.
The citation metadata is kept in CITATION.cff,
which the "Cite this repository" button on GitHub can export as BibTeX or APA.
Every release of msfc-ccd is archived on Zenodo with its own DOI.
The concept DOI, 10.5281/zenodo.23090943,
always resolves to the latest version,
and the Zenodo page lists the DOI of every version.
Please include the version of msfc-ccd that you used,
which is given by importlib.metadata.version("msfc-ccd").
The BibTeX entry below uses the concept DOI.
To cite a specific version instead,
replace doi with the DOI of that version.
@software{msfc-ccd,
  author = {Smart, Roy T. and Parker, Jacob D.},
  title = {msfc-ccd},
  version = {X.Y.Z},
  doi = {10.5281/zenodo.23090943},
  url = {https://github.com/sun-data/msfc-ccd},
}
Development
Install the package in editable mode along with its test dependencies, and run the test suite using pytest:
pip install -e .[test]
pytest
The sample FITS files are stored with git LFS, so git lfs install is needed before the tests and the documentation examples will work.
This project is formatted using black and linted using ruff, both of which are checked by continuous integration:
black .
ruff check .
The notebooks in the documentation must be committed without their outputs, which continuous integration checks using nbstripout. Strip a notebook before committing it:
pip install nbstripout
nbstripout docs/reports/*.ipynb
or install nbstripout as a git filter, which strips the notebooks automatically as they are staged:
nbstripout --install
To build the documentation locally:
pip install -e .[doc]
sphinx-build docs docs/_build/html
1 maintainer

Metadata
1 maintainer
Release files for msfc-ccd 1.1.1
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | |
|---|---|---|---|
| msfc_ccd-1.1.1.tar.gz | 25.5 MB | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| msfc_ccd-1.1.1-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 51.1 MB
Release files / msfc_ccd-1.1.1.tar.gz
| Download URL | msfc_ccd-1.1.1.tar.gz |
|---|---|
| Size | 25.5 MB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
7f94158ccb908a1b595dddda0b16f0b56ce710c1244febcb38602fab49a8586f
|
|
BLAKE2b-256 checksum How to use checksums |
05fe721018db8ebbf1b65ddc985b3e96a4cdb0828ec40b7e239e3543d4c36a77
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.


PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Oct 8, 2026.
Transparency logRelease files / msfc_ccd-1.1.1-py3-none-any.whl
| Download URL | msfc_ccd-1.1.1-py3-none-any.whl |
|---|---|
| Size | 25.5 MB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
1c8f42df11faf9f5030c3578eefa3292558f497706e4418632a239f5385c244e
|
|
BLAKE2b-256 checksum How to use checksums |
07570e54ddfcd851a623040c3c6dc73238b04423709d79e93cbe15945802cefc
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Oct 8, 2026.
Transparency log













