
mujoco_warp_pbr
A batched, physically based renderer for MuJoCo Warp, written in NVIDIA Warp. It renders thousands of MuJoCo Warp worlds per launch with a single specialised megakernel, using MuJoCo's own material, texture and light fields.
- Real-time tier (default): primary ray, ray-traced (soft) shadows, Filament's BRDF with multiscatter energy compensation, split-sum image-based lighting from HDR environment maps, normal / ORM / emissive / opacity maps with ray-cone mip selection, specular anti-aliasing, in-kernel supersampling, MuJoCo reflectance (mirror ray) and alpha blending. Deterministic and noise-free.
- Path-traced tier: unidirectional path tracing with next-event estimation and multiple
importance sampling (lights, environment, BSDF). Same BRDF, converges to Mitsuba 3. Optional
edge-avoiding à-trous denoiser (
denoise=True) guided by first-hit albedo, normal and depth. - Every material, light and environment parameter can vary per world (domain randomisation) without recompiling. Depth and segmentation match MuJoCo Warp's renderer.
Install
pip install mujoco-warp-pbr          # Python >= 3.12; pulls mujoco, mujoco-warp and warp-lang
pip install newton-pbr               # optional: the Newton camera sensor
pip install "mujoco-warp-pbr[typing]"  # optional: shape-aware type stubs for Pyrefly
Usage
import mujoco
import mujoco_warp as mjw
import warp as wp

import mujoco_warp_pbr as mjpbr

mjm = mujoco.MjModel.from_xml_path("scene.xml")
mjd = mujoco.MjData(mjm)
m = mjw.put_model(mjm)
d = mjw.put_data(mjm, mjd, nworld=1024)

rc = mjpbr.create_render_context(
  mjm,
  nworld=1024,
  cam_res=(128, 128),
  render_rgb=True,
  render_depth=True,
  envmap="studio.hdr",  # optional equirectangular HDR environment
)

mjw.step(m, d)
mjw.refit_bvh(m, d, rc.base)  # after the geometry moved
mjpbr.render(m, d, rc)

rgb = wp.zeros((1024, 128, 128), dtype=wp.vec3)
mjpbr.get_rgb(rc, 0, rgb)  # camera 0, display RGB in [0, 1]
Per-world variation: replace any batched array of the context or model with one whose leading
dimension is nworld, e.g. rc.geom_roughness = wp.array(r, dtype=float) with r of shape
(nworld, ngeom), rc.env_id to select one of several environment maps per world, or
m.geom_rgba (MuJoCo Warp's convention: arrays are indexed with worldid % shape[0]).
On GPUs with RT cores, traversal="optix" traces the real-time tier's rays with OptiX instead of
Warp's software BVHs: 3–7× faster on mesh scenes, at most 1.3× on primitive-only scenes (and
slower with a mirror floor); traversal="auto" picks OptiX only when meshes are rendered. It needs
PyOptiX
(otk-pyoptix, built against the OptiX version of the
driver) and the OptiX SDK headers (OPTIX_INCLUDE_DIR), and falls back to the software path with
a warning otherwise; see results/rt_backend.md for what it supports.
Materials and lights
Only native MuJoCo fields are used, so existing MJCF works unchanged:
| MuJoCo | Renderer |
|---|---|
rgba, texture layer rgb / rgba |
base colour (linear) and alpha |
metallic, roughness (-1 = unset) |
metallic, perceptual roughness; unset: metallic 0, roughness 1 − shininess (or unset_material=UnsetMaterial.HEURISTIC, or default_material=) |
specular |
dielectric reflectance, F0 = 0.16 · specular² (0.5 → 0.04) |
layers orm, occlusion, roughness, metallic |
ambient occlusion, roughness and metallic maps (factor × texel) |
layer normal |
tangent-space normal map (glTF convention) |
emission, layer emissive |
emitted radiance (display-relative: 1 = full brightness) |
layer opacity |
alpha |
reflectance |
mirror reflection blended by reflectance |
light intensity (lux / candela), range, bulbradius, diffuse |
physical lights (light_model=LightModel.PHYSICAL, default); intensity 0 uses a calibrated fallback |
light attenuation, cutoff, exponent, ambient, specular |
MuJoCo's GL semantics (light_model=LightModel.MUJOCO) |
| skybox texture | environment lighting and background when no envmap is given |
tools/gltf_to_mjcf.py converts glTF 2.0 assets (metallic-roughness core) to MJCF with these
fields.
Supported geometry: planes, spheres, capsules, ellipsoids, cylinders, boxes, meshes, height fields and SDFs with full PBR; flex is shaded without normal maps and Gaussian splats keep MuJoCo Warp's unlit compositing (a warning is printed for both).
Newton
newton-pbr/ is a small package depending on this one and on
Newton. Its newton_pbr.SensorPbrCamera mirrors
newton.sensors.SensorCamera.update, so any Newton scene renders with this renderer, batched over
all worlds:
camera = newton_pbr.SensorPbrCamera(model, width=128, height=128, fovy=60.0, envmap="studio.hdr")
camera.update(state, camera_transforms, color_image=color, depth_image=depth)
Performance
Camera-frames per second, 4096 worlds at 64², one camera per world, HDR environment and shadows
for this renderer (RTX PRO 6000 Blackwell; from benchmarks/suite.py, full tables for three GPUs
and all renderers in results/suite/suite-v2):
| scene | real-time | real-time (OptiX) | Newton SensorCamera |
Newton RTX (tiled) | MuJoCo Warp |
|---|---|---|---|---|---|
| DamagedHelmet | 312k | 1.61M | 168k | 71k | 112k |
| ABeautifulGame (1.5M triangles) | 246k | 1.33M | 134k | 65k | 147k |
| ANYmal C | 180k | 926k | 176k | 73k | 82k |
| Franka showroom (authored lights) | 226k | 795k | 285k | 72k | 78k |
| material grid (spheres) | 1.87M | 2.39M | 1.95M | 73k | 2.54M |
| primitives | 1.22M | 1.05M | 1.88M | 73k | 2.08M |
- Newton's
SensorCameraand MuJoCo Warp shade with albedo and simple lights (Newton's MJCF import also drops the scenes' lights and textures); this renderer runs full PBR with image-based lighting. - On primitive-only scenes it runs at 0.6–0.7× MuJoCo Warp's speed, where PBR shading outweighs traversal.
- Across GPUs (geometric mean over the suite's scenes, 4096 × 64², real-time tier without OptiX): RTX PRO 6000 418k, H200 167k, A100 115k frames/s.
- Single-camera renderers for reference (frames/s, 256², DamagedHelmet): MuJoCo's OpenGL
renderer 4.4k, Newton's
ViewerRTX91, Mitsuba 3 at 16 spp 218, this renderer's path-traced tier at 16 spp 82 (5.0k real-time; measured before the path tier appliedmax_registers, which made it about 2× faster). Batched through one tiled render product (the "Newton RTX (tiled)" column, static scenes only,research/web/ovrtx_batching.md), Omniverse RTX runs at about 70k frames/s whatever the scene. - Throughput saturates from about 1–4 M pixels per launch (e.g. 256 worlds at 64²).
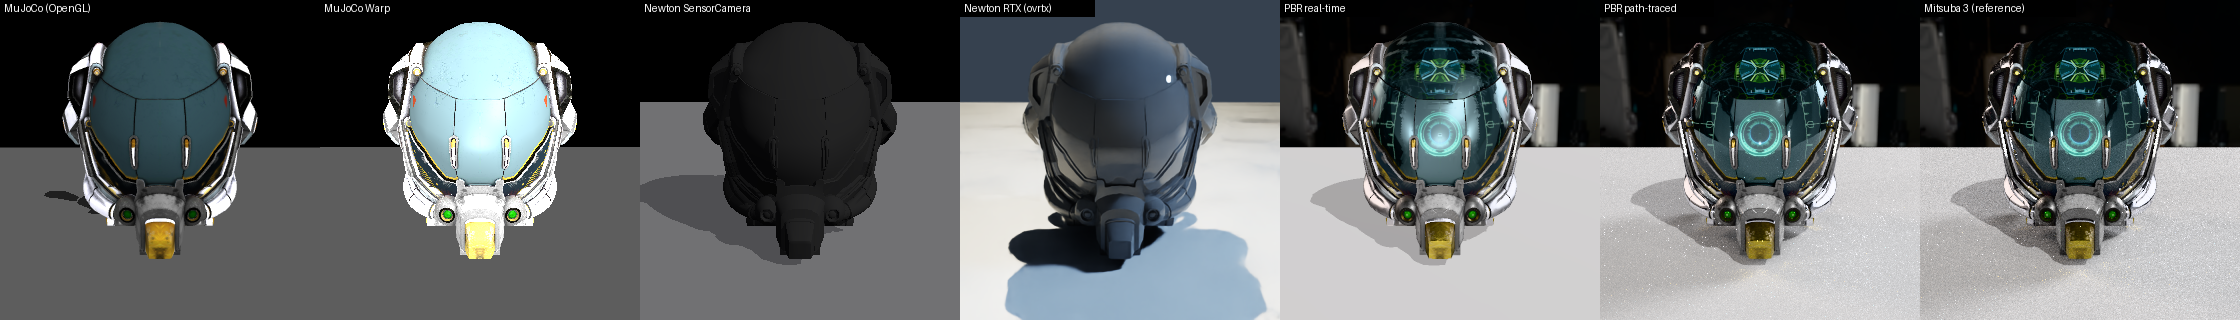
Left to right: MuJoCo OpenGL, MuJoCo Warp, Newton SensorCamera, Newton ViewerRTX, this
renderer's real-time tier, its path-traced tier (256 spp) and Mitsuba 3 (256 spp).
See results/scaling.md and the milestone logs in results/history/
(m5_baseline.md, m7_autoresearch.md) for more tables, results/history/m6_pathtrace.md for the
path-traced tier and results/rt_backend.md for the OptiX backend.
Tuning knobs: max_registers (96 by default, tuned on Hopper; 0 leaves it to the compiler; both
tiers apply it), render_order (RenderOrder.TILED default; RenderOrder.WORLD is up to 2.7×
faster when all worlds render nearly the same image, e.g. fixed cameras), block_dim,
samples_per_pixel, shadow_samples, and disabling unused features (use_shadows,
use_textures, specular_aa, enable_reflections). The host side of a render() call takes
about 61 µs (was 136 µs).
Settings are compiled into the kernel only where reading them at runtime measured slower (DamagedHelmet and the material grid, 4096 worlds at 64², RTX PRO 6000):
| compiled-in setting | why | measured runtime cost |
|---|---|---|
samples_per_pixel |
sample loop | 4–20% |
translucency (max_layers) |
layer loop | 2–10% |
| reflections, textures, environment map, light model, denoise | code paths | 2–6% |
light count, render_order |
unrolled loop / pixel mapping | 1–4% |
tier, geom types, traversal, fast math, max_registers |
structural | – |
Changing one of these recompiles the kernel at the next render (about 2–7 s on GPU, 2 s on CPU); every other setting (tone mapper, shadows and shadow samples, headlight, clip planes, HDR output, environment background, specular AA, vertex normals, spot lights, …) is read at runtime.
Running on CPU
No GPU is needed: the renderer runs unchanged on Warp's CPU device, with images within 1/255 of the GPU's for the real-time tier.
with wp.ScopedDevice("cpu"):
  m = mjw.put_model(mjm)
  d = mjw.put_data(mjm, mjd, nworld=16)
  rc = mjpbr.create_render_context(mjm, nworld=16, cam_res=(64, 64), render_rgb=True)
  mjpbr.render(m, d, rc)
Warp runs a CPU launch on a single core, so throughput does not grow with nworld. To use every
core, give each core its own worker, with its own Data and render context: Python threads
(Warp's launch releases the GIL) or pinned processes. benchmarks/cpu_bench.py measures this,
plus MuJoCo's OpenGL renderer on a software rasteriser and Mitsuba 3's LLVM backend:
python benchmarks/cpu_bench.py --scene damaged_helmet --res 64 --nworld 32 --workers 1 8 32 [--mode process]
python benchmarks/cpu_bench.py --parity --scene damaged_helmet --res 64   # CPU vs GPU images
DamagedHelmet at 64² renders at about 125–150 frames/s per core, scaling to 2.5k frames/s on a
16-core / 32-thread EPYC and 34k on a GH200 node (4× 72-core Grace). One GH200 GPU is 6–47×
faster than one 72-core Grace. A render context with an HDR environment takes about 2 s to
create on the CPU device (the map's prefilter runs in row bands on up to 16 threads; it took
about 32–35 s on one core). Full tables, the scaling curve and the baselines
are in results/cpu.md.
Benchmarks and validation
python tools/fetch_assets.py            # Khronos glTF, Menagerie robots, Poly Haven HDRIs
python benchmarks/bench.py --scene damaged_helmet --nworld 4096 --res 64
python benchmarks/bench.py --scene damaged_helmet --nworld 4096 --res 64 --gpus 0 1 2 3   # multi-GPU scaling
python benchmarks/sweep.py --preset score --out results/score.jsonl   # also: scaling, tune
python benchmarks/validate.py --res 256 --spp 1024   # FLIP / PSNR against Mitsuba 3
python benchmarks/denoise_eval.py --scene grid_env --samples 4 16   # FLIP of the denoiser
python benchmarks/gallery.py --scene franka_showroom --frames 48      # side-by-side orbit video
Assets are cached in $MJPBR_ASSET_DIR (default ~/.cache/mujoco_warp_pbr); --set envmap=hdri/<file>.hdr and the other scripts resolve relative environment maps against it. The
reference renderers (Mitsuba 3, Newton) and image metrics install with the bench extra.
benchmarks/cpu_bench.py is the CPU counterpart of bench.py (see Running on CPU).
benchmarks/suite.py compares every renderer:
- this renderer: real-time tier, path-traced tier, and through
newton_pbr; - MuJoCo Warp, MuJoCo's OpenGL renderer and Mitsuba 3;
- Newton's
SensorCameraandViewerRTX(NVIDIA Omniverse RTX, on RTX GPUs).
It runs them on showcase, robotics and light-rig scenes, for a single scene and for batches, and
writes a markdown report with orbit videos. tools/hf/run_suite.py runs it on several
Hugging Face Jobs GPUs, with a private
bucket carrying code, assets and results:
uv run tools/hf/run_suite.py --bucket USER/BUCKET --flavors rtx-pro-6000 h200 a100-large --sync-assets --wait
Development
uv sync --all-extras
uv run pytest
uv run pytest -m "not slow"   # skips the high-sample path-traced references
uv run ruff check . && uv run ruff format --check .   # or: pre-commit install
uv run pyrefly check
Type checking. Pyrefly is the type checker. The dev extra
pulls in Pyrefly and the typing extra (pip install mujoco-warp-pbr[typing]): shape-aware stubs for Warp
(pyrefly-warp-stubs) and NumPy (pyrefly-numpy-stubs), and mujoco-stubs. Host code annotates array shapes
with named dimensions, e.g. wp.array[wp.vec3, [NWorld, H, W]] or np.ndarray[[H, W, 3], np.dtype[np.float32]],
so image sizes, batch and channel counts are checked across calls; kernel signatures stay plain Warp
(wp.array2d[float]). The annotations are type-checking-only (from __future__ import annotations), so a plain
install needs neither Pyrefly nor the stubs. uv sync --extra dev is enough for pyrefly check: the
benchmark-only packages (bench extra, OptiX, ovrtx, huggingface_hub) are listed in ignore-missing-imports, so
their imports are untyped when absent and checked when installed.
Design notes and literature: research/.
1 maintainer

Metadata
1 maintainer
Release files for mujoco-warp-pbr 0.1.0
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | Provenance | |
|---|---|---|---|---|
| mujoco_warp_pbr-0.1.0.tar.gz | 127.1 kB | With provenance | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| mujoco_warp_pbr-0.1.0-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 249.9 kB
Release files / mujoco_warp_pbr-0.1.0.tar.gz
| Download URL | mujoco_warp_pbr-0.1.0.tar.gz |
|---|---|
| Size | 127.1 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
af4ddc6b758cb26685ee1f31ff6dd7a98fc8c3464748068f962d3958b727b345
|
|
BLAKE2b-256 checksum How to use checksums |
299fae4c3db181e393d7ca470499d82b39f8f9159d9135c35970aa14d4e9c2d0
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.16
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.


PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Oct 23, 2026.
Transparency logRelease files / mujoco_warp_pbr-0.1.0-py3-none-any.whl
| Download URL | mujoco_warp_pbr-0.1.0-py3-none-any.whl |
|---|---|
| Size | 122.8 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
3b80448f016d796e555f084c06e7ea801f20fb3f4b7370f1167f68505e6307c2
|
|
BLAKE2b-256 checksum How to use checksums |
72a4e9f1b47daa5c964685732f82c9b4d989e859e4bd203a592736444f4397a6
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.16
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Oct 23, 2026.
Transparency logSecurity for mujoco-warp-pbr 0.1.0
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
Full provenance
All 2 files in this release have been uploaded with provenance metadata.
Attestation for mujoco_warp_pbr-0.1.0.tar.gz
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Oct 23, 2026.
Transparency logA note on package security
PyPI is a repository for distributing packages, not a service for auditing them. While third-party security researchers and our staff do their best to detect and remove malicious packages, PyPI cannot guarantee the quality, security or suitability of any given package.
To learn more about protecting yourself from malicious actors, visit our package security documentation.














