
navstack-gym
Simulation environment of task with autonomous mobile robot using Navigation Stack.
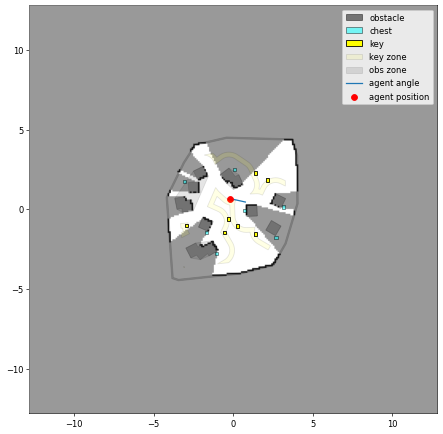
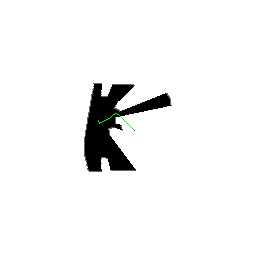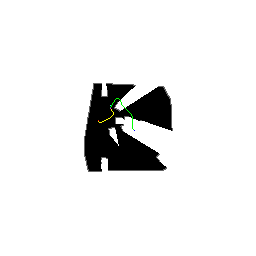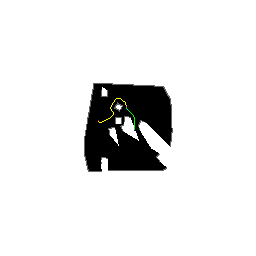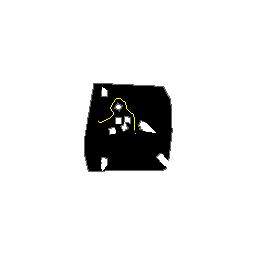
In this environment, the agent do action of instructing relative navigation goal pose and observe a subjective occupancy map.
Implemented Task
TreasureChestRoom :
Agent aim to open chests in unknown rooms with keys and discover as much treasure as possible.
The rooms in which agent spawned are randomly generated such as the following structure.
Yellow cube is key, and cyan cube is treasure chest. Each object will be generated based on different set of placing rules.

Installation
pip install navstack-gym
Usage
I'll add the note later.
example:
import gym
import navstack_gym

env = gym.make('VisibleTreasureHunt-v0')
obs = env.reset(is_generate_pose=True, is_generate_room=True, obstacle_count=10)

imgs = []
imgs.append(env.render('rgb_array'))

for i in range(10):
    action = env.action_space.sample()
    obs, reward, done, info = env.step(action)
    imgs.append(env.render('rgb_array'))
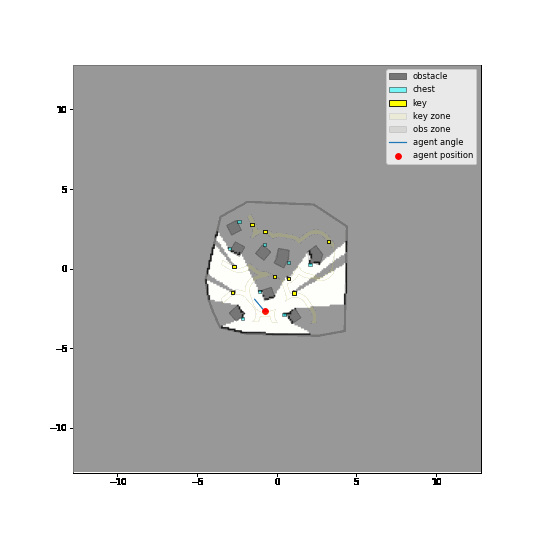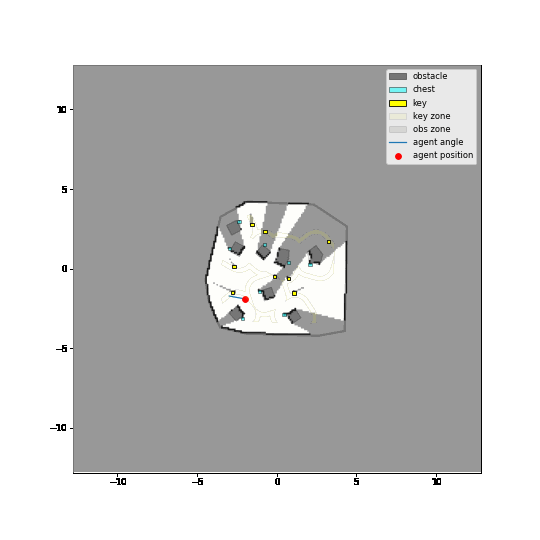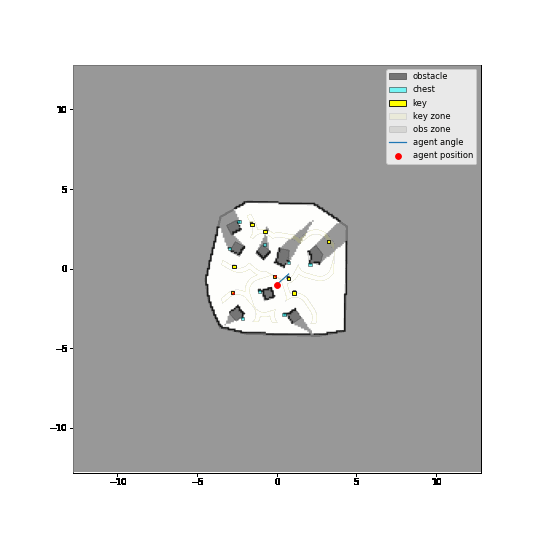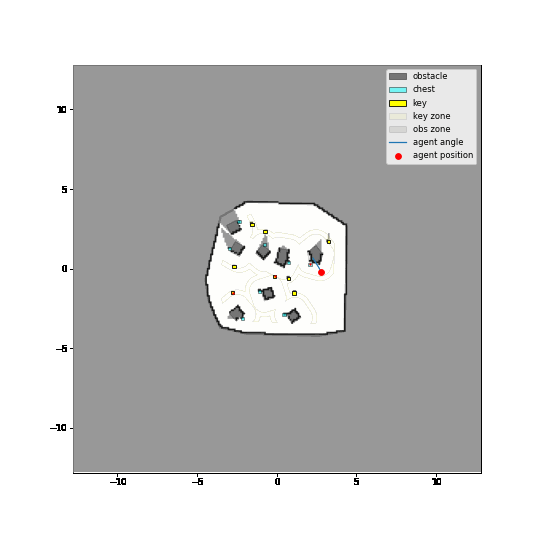
1 maintainer

Metadata
1 maintainer
Release files for navstack-gym 0.1.16
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | |
|---|---|---|---|
| navstack-gym-0.1.16.tar.gz | 7.9 kB | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| navstack_gym-0.1.16-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 16.3 kB














