
ndx-jabs Extension for NWB
NWB extension for storing JABS (JAX Animal Behavior System) algorithm internals, such as instance segmentation contours
General-purpose JABS outputs belong in tool-agnostic extensions: pose estimates in ndx-pose and behavior predictions in an ethogram extension. This extension holds the pieces that are internal to the JABS algorithms, so JABS users can keep them in their NWB files without adding them to the core schema.
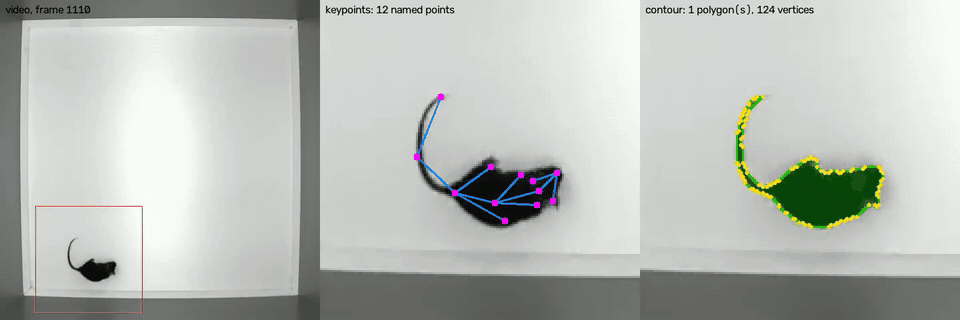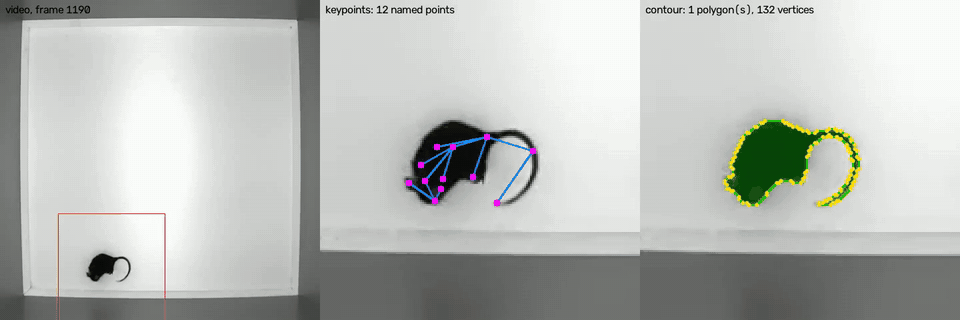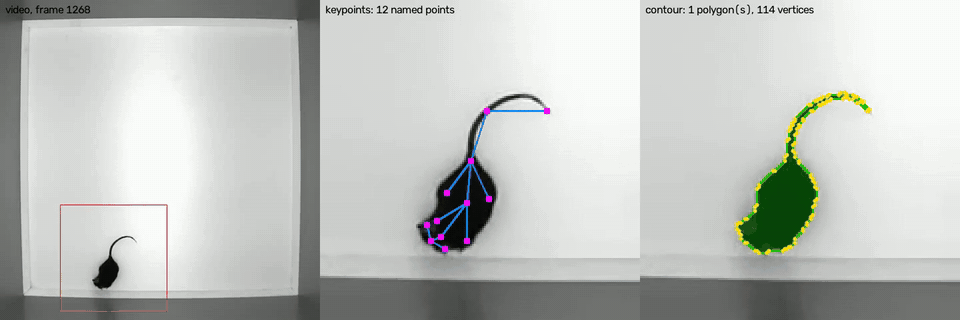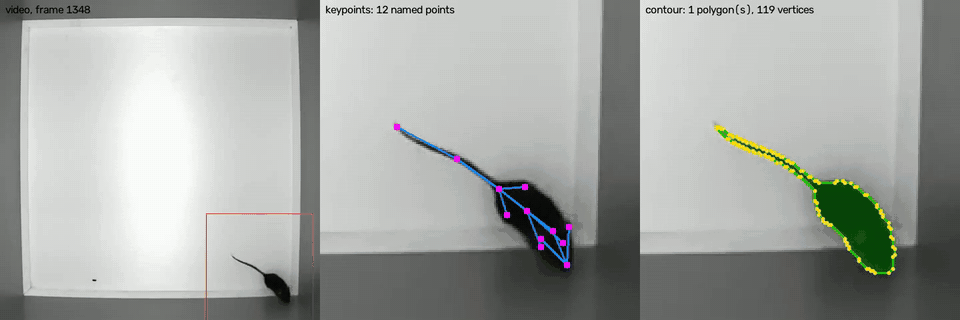
Left: video frame with the region around one mouse boxed. Middle: JABS pose keypoints (12 named points) for that mouse.
Right: the segmentation contour JABS produces for the same mouse, stored by ContourSeries.
Installation
pip install ndx-jabs
Neurodata types
ContourSeries
Extends TimeSeries. Per-frame instance segmentation contours for one animal, stored as JABS produces them.
| Field | Type | Shape | Description |
|---|---|---|---|
data |
numeric (JABS writes int16) |
(num_frames, num_contours, num_vertices, 2) |
Vertex (x, y) positions. Only the first vertex_count vertices of each slot are real; the rest is padding with no meaning |
vertex_count |
uint32 |
(num_frames, num_contours) |
Number of valid vertices in each contour slot; 0 means the slot is empty on that frame |
is_external |
bool |
(num_frames, num_contours) |
True for an external (outer) boundary, False for an internal boundary (a hole) |
contour_group (optional) |
uint32 |
(num_frames, num_contours) |
Groups contours into connected components within a frame, so each hole stays with the part that contains it |
reference_frame |
text | scalar | What (0, 0) is and which way each axis increases |
A segmentation can have several disjoint blobs and holes, so each frame holds up to num_contours closed polygons.
Contour and vertex capacities are per-file maxima chosen by the producer. vertex_count is authoritative, so a
consumer never needs to look for a padding value. unit defaults to pixels. Name each series after the instance it
describes, and store it alongside the PoseEstimation for that instance.
Usage
import datetime

import numpy as np
from pynwb import NWBHDF5IO, NWBFile

from ndx_jabs import ContourSeries

nwbfile = NWBFile(
    session_description="JABS contours",
    identifier="example",
    session_start_time=datetime.datetime(2026, 1, 1, tzinfo=datetime.timezone.utc),
)

num_frames, num_contours, num_vertices = 3600, 4, 319
contours = ContourSeries(
    name="contours_mouse0",
    description="JABS segmentation contours for mouse0",
    data=np.full((num_frames, num_contours, num_vertices, 2), -1, dtype=np.int16),
    vertex_count=np.zeros((num_frames, num_contours), dtype=np.uint32),
    is_external=np.zeros((num_frames, num_contours), dtype=bool),
    reference_frame="(0, 0) is the top left corner of the video frame, x increases rightward and y downward",
    rate=30.0,
)
nwbfile.add_acquisition(contours)

with NWBHDF5IO("contours.nwb", "w") as io:
    io.write(nwbfile)
The extension spec is cached in files that use it, so readers without ndx-jabs installed can still open them.
Development
This project uses uv.
uv sync                                            # install the package and dev tools into .venv
uv run python src/spec/create_extension_spec.py    # regenerate spec/ after editing the spec
uv run pytest                                      # run the tests
uv sync --group test --resolution lowest-direct    # test against the minimum supported dependency versions
uv build                                           # build the wheel and source distribution
Releasing
-
Update
versioninpyproject.tomland insrc/spec/create_extension_spec.py, then runuv run python src/spec/create_extension_spec.pyto regeneratespec/. -
Update
CHANGELOG.md, commit, and merge tomain. -
Tag the commit and push the tag:
git tag 0.1.0
git push origin 0.1.0
The Publish workflow checks that the tag, pyproject.toml and spec versions match, runs the tests, publishes to
PyPI using trusted publishing, and creates a GitHub release.
This extension was created using ndx-template.
1 maintainer

Metadata
1 maintainer
Release files for ndx-jabs 0.1.0
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | |
|---|---|---|---|
| ndx_jabs-0.1.0.tar.gz | 6.8 MB | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| ndx_jabs-0.1.0-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 6.8 MB
Release files / ndx_jabs-0.1.0.tar.gz
| Download URL | ndx_jabs-0.1.0.tar.gz |
|---|---|
| Size | 6.8 MB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
b957b904061e0c5061075164662a71fa938bc9d8a89a1f582597fd7dff8ced8d
|
|
BLAKE2b-256 checksum How to use checksums |
e434edfe9b6667bf78618bf836a56a80e11ca39489d594dbf670ba89c3d37047
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
uv/0.12.22 {"installer":{"name":"uv","version":"0.12.22","subcommand":["publish"]},"python":null,"implementation":{"name":null,"version":null},"distro":{"name":"Ubuntu","version":"24.04","id":"noble","libc":null},"system":{"name":null,"release":null},"cpu":null,"openssl_version":null,"setuptools_version":null,"rustc_version":null,"ci":true}
|
Release files / ndx_jabs-0.1.0-py3-none-any.whl
| Download URL | ndx_jabs-0.1.0-py3-none-any.whl |
|---|---|
| Size | 7.5 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
ebd62e1549d9bd28fc740dc0f01afc6693a652068fbf5b7f7673db9914438ed3
|
|
BLAKE2b-256 checksum How to use checksums |
6bbee28e57dab6394cca7d2b263677593dd7ed9f89e1b87dd99cd84ada5938fd
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
uv/0.12.22 {"installer":{"name":"uv","version":"0.12.22","subcommand":["publish"]},"python":null,"implementation":{"name":null,"version":null},"distro":{"name":"Ubuntu","version":"24.04","id":"noble","libc":null},"system":{"name":null,"release":null},"cpu":null,"openssl_version":null,"setuptools_version":null,"rustc_version":null,"ci":true}
|














