
Python Bundle Adjustment
- Load the data.
from pyba.CameraNetwork import CameraNetwork
import pickle
import glob
import numpy as np

image_path = './data/test/camera_{cam_id}_img_00000{img_id}.jpg'
pr_path = './data/test/df3d_2/pose_result*.pkl'

d = pickle.load(open(glob.glob(pr_path)[0], 'rb'))
camNet = CameraNetwork(points2d=d['points2d'], calib=d, image_path=image_path)
points2d is a numpy array with shape T x J x 2. All units are in pixels. calib is a nested dictionary where keys are camera id's, indexed starting from 0 up to n_cameras-1. values are another sets of dictionaries with keys "R", "tvec", "intr", "distort"
calib = {0: {'R': array([[ 0.90885957,  0.006461  , -0.41705219],
         [ 0.01010426,  0.99924554,  0.03750006],
         [ 0.41697983, -0.0382963 ,  0.90810859]]),
  'tvec': array([1.65191596e+00, 2.22582670e-02, 1.18353733e+02]),
  'intr': array([[1.60410e+04, 0.00000e+00, 2.40000e+02],
         [0.00000e+00, 1.59717e+04, 4.80000e+02],
         [0.00000e+00, 0.00000e+00, 1.00000e+00]]),
  'distort': array([0., 0., 0., 0., 0.])},
 1: {'R': array([[ 0.59137248,  0.02689833, -0.80594979],
         [-0.00894927,  0.9996009 ,  0.02679478],
         [ 0.80634887, -0.00863303,  0.59137718]]),
  'tvec': array([ 1.02706542e+00, -9.25820468e-02,  1.18251732e+02]),
  'intr': array([[1.60410e+04, 0.00000e+00, 2.40000e+02],
         [0.00000e+00, 1.59717e+04, 4.80000e+02],
         [0.00000e+00, 0.00000e+00, 1.00000e+00]]),
  'distort': array([0., 0., 0., 0., 0.])},
}
- Visualize the 2d pose.
import matplotlib.pyplot as plt
img = camNet.plot_2d(0, points='points2d')
plt.figure(figsize=(20,20))
plt.imshow(img, cmap='gray')
plt.axis('off')

- Do the bundle adjustment.
from pyba.pyba import bundle_adjust
bundle_adjust(camNet)
   Iteration     Total nfev        Cost      Cost reduction    Step norm     Optimality
       0              1         7.1659e+05                                    7.27e+05
       1              2         2.9376e+05      4.23e+05       1.08e+01       3.12e+05
       2              4         2.6084e+05      3.29e+04       2.39e+00       1.85e+05
       3              5         2.4676e+05      1.41e+04       3.04e+00       2.20e+04
       4              7         2.4604e+05      7.20e+02       1.32e+00       1.75e+04
       5              8         2.4579e+05      2.53e+02       2.67e+00       2.86e+04
       6              9         2.4487e+05      9.20e+02       2.53e+00       2.18e+04
       7             10         2.4472e+05      1.43e+02       2.48e+00       2.02e+04
       8             11         2.4441e+05      3.18e+02       6.71e-01       1.77e+03
       9             12         2.4440e+05      9.43e+00       6.78e-01       2.13e+03
`ftol` termination condition is satisfied.
Function evaluations 12, initial cost 7.1659e+05, final cost 2.4440e+05, first-order optimality 2.13e+03.
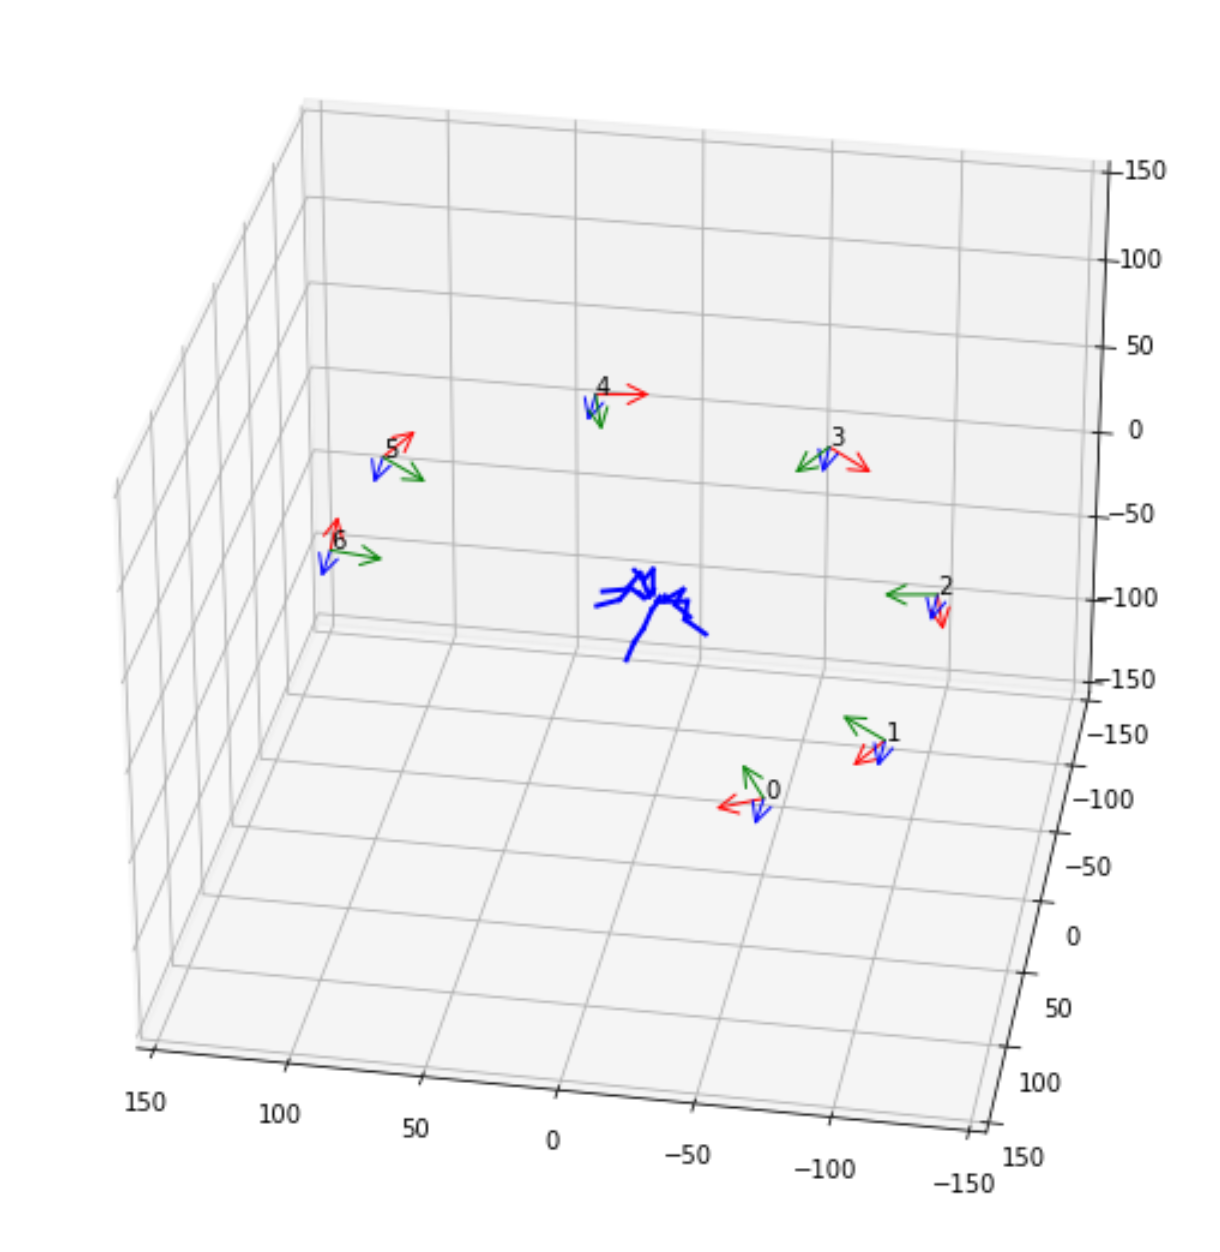
- Visualize the resulting camera rig.
fig = plt.figure(figsize=(10,10))
ax3d = fig.add_subplot(111, projection='3d')

camNet.draw(ax3d, size=20)
camNet.plot_3d(ax3d, img_id=0, size=10)
1 maintainer

Metadata
1 maintainer
Release files for nely-pyba 0.13.1
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | Provenance | |
|---|---|---|---|---|
| nely-pyba-0.13.1.tar.gz | 8.6 kB | Without provenance | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| nely_pyba-0.13.1-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 18.8 kB
Release files / nely-pyba-0.13.1.tar.gz
| Download URL | nely-pyba-0.13.1.tar.gz |
|---|---|
| Size | 8.6 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
fb3e3a79f5fec099d5150c091df91ebe2a4a70af9b3331006c8880a6a4848a02
|
|
BLAKE2b-256 checksum How to use checksums |
858bec7632c9e24d321552f50346609f1f142d96a7aa9d5c433207b6190e289b
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/5.1.1 CPython/3.10.12
|
Release files / nely_pyba-0.13.1-py3-none-any.whl
| Download URL | nely_pyba-0.13.1-py3-none-any.whl |
|---|---|
| Size | 10.2 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
acd4dc361a2f85a6b34eff46f14eb47823387a4129c446dd41221d182d9a8183
|
|
BLAKE2b-256 checksum How to use checksums |
e52e14a4a04d1eb3fc4f1963281144272acfa003f4737bf7f694ce98376957ec
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/5.1.1 CPython/3.10.12
|
Security for nely-pyba 0.13.1
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
No provenance found
None of the files in this release were uploaded with provenance metadata.
A note on package security
PyPI is a repository for distributing packages, not a service for auditing them. While third-party security researchers and our staff do their best to detect and remove malicious packages, PyPI cannot guarantee the quality, security or suitability of any given package.
To learn more about protecting yourself from malicious actors, visit our package security documentation.














