
NML Hand Exoskeleton
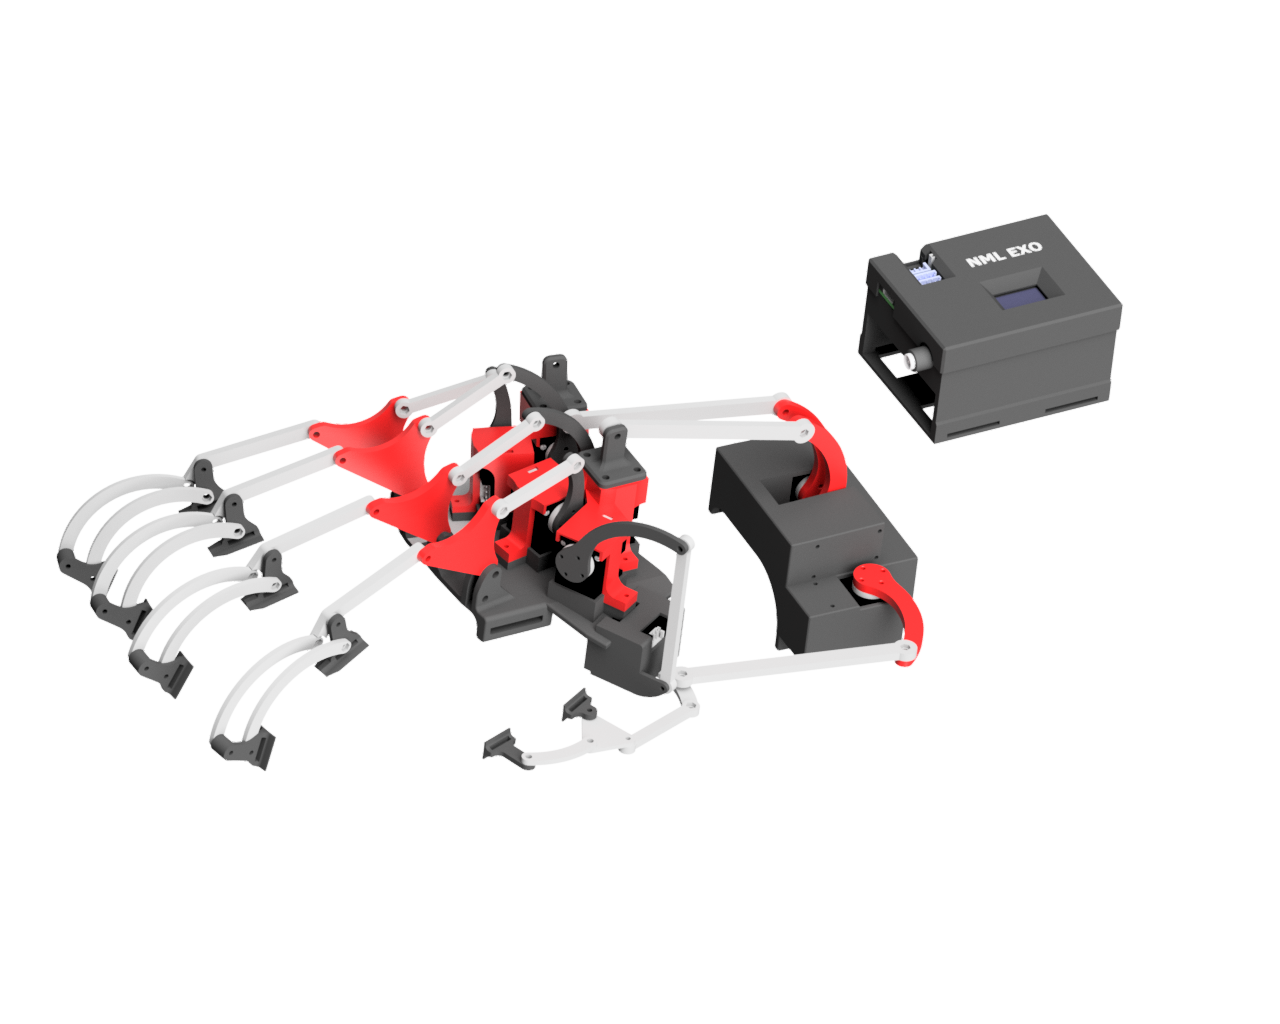


nml_hand_exo is the Python SDK, operator software, and OpenRB-150 firmware for
the NML Hand Exoskeleton. It supports explicit Dynamixel control, participant
calibration, Lab Streaming Layer (LSL) integration, event-marked task sessions,
and continuous EMG intent decoding.
This is research software for supervised laboratory use. It is not a medical device. Verify calibration, current limits, joint limits, and the emergency-stop workflow before placing the device on a participant.
Quick links
- Documentation
- Examples
- Serial protocol
- Dual-exoskeleton architecture
- EMG intent architecture
- Issue tracker
Features
- USB serial, dual-CDC USB, Bluetooth serial, and TCP communication transports.
- Single-side and dual-side operation with explicit integer Dynamixel IDs.
- PyQt operator GUI for connection, calibration, telemetry, direct control, and guarded EMG teleoperation.
- Participant task-cue application with optional LSL event markers.
- Legacy centroid and current LDA-based continuous intent decoders.
- XDF session import, decoder validation, playback utilities, and analysis tools.
- OpenRB-150 firmware with joint-limit, current-limit, and direct-command safety handling.
- Hardware-independent fakes and unit tests for host-side development.
Installation
Python 3.10 through 3.12 is supported. Python 3.11 is used for hardware development and is the recommended version on Windows.
From PyPI after a release:
py -3.11 -m venv .venv
.\.venv\Scripts\Activate.ps1
python -m pip install --upgrade pip
python -m pip install nml-hand-exo
From a source checkout:
git clone https://github.com/Neuro-Mechatronics-Interfaces/NML_Hand_Exo.git
cd NML_Hand_Exo
py -3.11 -m venv .venv
.\.venv\Scripts\Activate.ps1
python -m pip install --upgrade pip
python -m pip install -e .
The Python package does not require a sibling repository, private drive, or lab-local package.
Optional dependencies
Extras keep research integrations separate from the supported runtime:
# Plotting and tabular analysis tools
python -m pip install -e ".[analysis]"

# MindRove, joystick, and WebSocket integrations
python -m pip install -e ".[integrations]"

# Legacy PyTorch model helpers
python -m pip install -e ".[ml]"

# Tests and packaging tools
python -m pip install -e ".[dev]"
LabRecorder is optional external software. It is useful for creating XDF files that combine EMG and task markers, but it is not needed to import the package, run the exoskeleton GUI, or use the Python API.
Getting started
Connect to one OpenRB command port at 1 Mbps and inspect the firmware-reported motor map:
from nml_hand_exo import HandExo, SerialComm

exo = HandExo(SerialComm(port="COM12", baudrate=1_000_000))
try:
    exo.connect()
    info = exo.info()
    print(info)
    print(exo.get_motor_angle("all"))
finally:
    exo.close()
Use integer IDs reported by info() for calibration and motion commands. Bare
motor names are ambiguous in dual firmware. Never command motion outside the
active calibration profile's joint limits.
CLI usage
Installation provides two commands:
handexo --help
handexo --version
handexo gui
handexo emg-intent
handexo emg-centroid

nml-task-cue --help
nml-task-cue
handexo gui is the main operator application. handexo emg-intent is the
maintained discovery, validation, visualization, and continuous-decoding
workflow. handexo emg-centroid remains available for backward compatibility
and comparison with older recordings.
Examples
Examples are grouped by purpose under examples/. Run
them from the repository root so package imports and relative resources resolve
consistently:
python examples/01_basic/example_serial_exo.py --help
python examples/01_basic/example_serial_exo.py --port COM12
python examples/calibration/calibrate_exo.py --help
python examples/08_udp/udp_gesture_receiver.py --help
python tools/import_xdf_intent_session.py --help
Hardware examples do not move motors during --help. Read the safety notes in
their local README before running a motion command.
Package structure
src/nml_hand_exo/
├── applications/   PyQt operator, task-cue, and decoder applications
├── calibration/    calibration profile and ROM helpers
├── control/        compatibility EMG trigger controllers
├── decoding/       features, sessions, LDA models, and stabilization
├── interface/      serial/TCP/LSL transports and HandExo API
├── ml/             optional legacy PyTorch model helpers
├── plotting/       PyQtGraph visualizers
├── processing/     signal processing and orientation helpers
└── testing/        hardware-independent OpenRB test doubles

src/cpp/nml_hand_exo/   OpenRB-150 firmware
src/pico_server/        optional CircuitPython TCP bridge
examples/               runnable hardware and integration examples
tools/                  offline analysis and session-conversion utilities
docs/                   architecture, protocol, and Sphinx documentation
Documentation
Protocol and architecture documents live directly in docs/. Build
the Sphinx reference locally with:
python -m pip install -e ".[docs]"
python -m sphinx -W --keep-going docs/source docs/build/html
Development and testing
python -m pip install -e ".[analysis,dev]"
python -m pytest -q
python -m compileall -q src examples tools tests
python tools/check_protocol_contract.py
git diff --check
Hardware is not required for the unit suite. Tests that exercise a live serial device are documented separately and must be run with the appropriate firmware, calibration profile, and physical safety setup.
Release workflow
Releases use the version declared in pyproject.toml and
nml_hand_exo.__version__. A release commit must be tagged with the matching
vX.Y.Z tag before upload.
python -m build
python -m twine check dist/*
TestPyPI and PyPI uploads are intentionally manual. See
docs/releasing.md for the complete verification and
upload commands. Never store an API token in this repository.
Contributing
Open an issue before making a protocol or firmware contract change. Keep host and firmware command names synchronized, prefer Python-side compatibility fixes, and include regression tests for parser or safety behavior. Pull requests should pass the complete test, compile, documentation, and packaging checks above.
License
NML Hand Exoskeleton is distributed under the MIT License.
1 maintainer

Metadata
1 maintainer
Release files for nml-hand-exo 0.2.17.1
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | |
|---|---|---|---|
| nml_hand_exo-0.2.17.1.tar.gz | 245.9 kB | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| nml_hand_exo-0.2.17.1-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 500.1 kB
Release files / nml_hand_exo-0.2.17.1.tar.gz
| Download URL | nml_hand_exo-0.2.17.1.tar.gz |
|---|---|
| Size | 245.9 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
6c58129ac1e51ebb74177ffa9dc7654c55bce058e149cc4f74d7bd522f74ae8e
|
|
BLAKE2b-256 checksum How to use checksums |
86b49681486d14631f8334737fd0092ee4772ce2f45d5ddfbeb95a8f2d1fb635
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/7.0.0 CPython/3.11.4
|
Release files / nml_hand_exo-0.2.17.1-py3-none-any.whl
| Download URL | nml_hand_exo-0.2.17.1-py3-none-any.whl |
|---|---|
| Size | 254.2 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
6f0a4db07077a871ad41e9a2cebc31777a25028678197f51980b02a916a1108c
|
|
BLAKE2b-256 checksum How to use checksums |
108151e16420d832a1210b22da31c3ffe44000c6e1896f1c64b318c0f15724a4
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/7.0.0 CPython/3.11.4
|













