
Development beyond the paper
This repository continues development beyond the paper. The paper-release branch preserves the previous main snapshot (v1.1.1).
v1.2.2 fixes inference device handling, validates supported input patch sizes, and improves training validation image galleries. See the 1.2.2 release notes.
v1.2.0 added DPM-Solver++ sampling, two-stage training, and PyTorch spectral back-projection. Inference now defaults to 3-step DPM-Solver++ with back-projection. See the release notes and migration example.
Latent Diffusion Super-Resolution - Sentinel 2 (LDSR-S2)
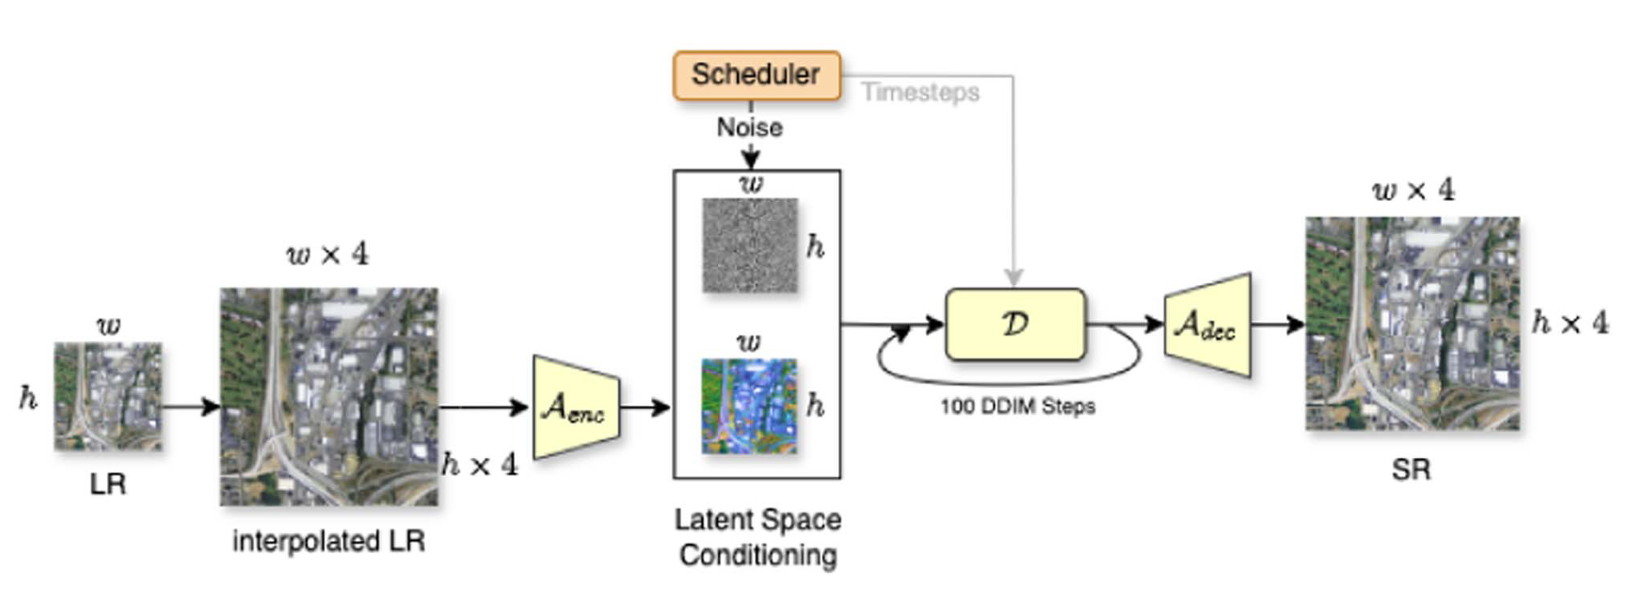
Description: This repository contains the code of the paper Trustworthy Super-Resolution of Multispectral Sentinel-2 Imagery with Latent Diffusion. This package contains the latent-diffusion model and weights to super-resolute the RGB-NIR bands of Sentinel-2. It can be embedded in the "opensr-utils" package in order to create a data pipeline for SR products.
🧪 Status: LDSR-S2 has exited the experimental phase as of v1.0.0
📌 For super-resolving 20m bands, check out SEN2SR, or use it alongside LDSR-S2 in the third notebook linked in the SEN2SR README.
Table of Contents
- 🚀 1. Interactive Notebooks - Google Colab
- 🛠️ 2. Install and Usage - Local
- 🖼️ 3. Super-Resolution Examples
- 🗺️ 4. Inference on S2 Tiles: Data Pipeline
- 📝 5. Notes
1. 🚀 Interactive Notebooks - Google Colab
Run LDSR-S2 directly in Google Colab within seconds! These notebooks let you fetch Sentinel-2 imagery, apply super-resolution, and save results — with or without going through the code. The no-code version even implements a user interface to select and process data.
| Notebook Name | Description | Link |
|---|---|---|
| LDSR-S2 No-Code | 🔘 No coding required — choose a point on a map and download SR results as GeoTIFFs |  |
| LDSR-S2 Walkthrough | 🧪 Code-level walkthrough with uncertainty estimation and advanced plotting | |
| LDSR-S2 & SEN2SR | 🔄 Use LDSR-S2 alongside SEN2SR to compare results on 10m + 20m bands | |
| LDSR-S2 Sampling | 📊 Compare sampler speed and RGB/NIR quality; export diagnostics and measurements | |
2. 🛠️ Install and Usage - Local
pip install opensr-model
Minimal Example
# Get Config
from io import StringIO
import requests
from omegaconf import OmegaConf
config_url = "https://raw.githubusercontent.com/ESAOpenSR/opensr-model/refs/heads/main/opensr_model/configs/config_10m.yaml"
response = requests.get(config_url)
config = OmegaConf.load(StringIO(response.text))

# Get Model
import torch
device = "cuda" if torch.cuda.is_available() else "cpu" # set device
import opensr_model # import package
model = opensr_model.SRLatentDiffusion(config, device=device) # create model
model.load_pretrained(config.ckpt_version) # load checkpoint
sr = model(torch.rand(1,4,128,128)) # DPM-Solver++ (3 steps) + back-projection
Inference defaults to DPM-Solver++ 2M with 3 steps and PyTorch back-projection. Diffusers is included in the standard package dependencies:
pip install -e .
torch.manual_seed(42)
sr = model(image)  # DPM-Solver++ (3 steps) + back-projection
sr_more_steps = model(image, sampling_steps=5)
sr_legacy = model(image, sampler="ddim", sampling_steps=100, spectral_correction="histogram")
Set denoiser_settings.sampler in the model YAML to choose a default sampler.
With sampling_steps: null, DPM-Solver++ uses 3 steps and DDIM uses 100.
Call arguments override config values; apply runtime settings after
load_pretrained, which may restore checkpoint settings. The 3-step setting
prioritizes speed; output quality can vary by scene.
Spectral correction can be selected independently of the sampler:
sr = model(image)  # back-projection is the default
sr_explicit = model(image, sampler="dpm_solver++", spectral_correction="back_projection")
sr_hist = model(image, spectral_correction="histogram")
sr_raw = model(image, spectral_correction="none")
Back-projection runs in PyTorch on decoded reflectances and adjusts the output so
that blur/downsampling reproduces the LR measurement. Its default operator is
4×4 block averaging; optional per-band Gaussian blur and stopping settings are
available through back_projection={...} or the model YAML. Configs without
spectral_correction also use back-projection. The new path keeps
nodata at zero and does not clamp corrected values. The legacy
histogram_matching=False still disables correction unless an explicit
spectral_correction is supplied.
See the inference changelog for settings and compatibility, and the training guide for training instructions.
Sampler performance with v1
Run the sampling diagnostics notebook to measure the speed/quality tradeoff on your own hardware.

SEN2NEON scene 2023_NOGP_6__1_3, central 640 m detail. Both outputs use the
canonical v1 checkpoint, the same seed, back-projection and a shared display
stretch. DPM-Solver++ produces this result in three denoiser evaluations,
very fine detail can differ from DDIM-100.

The step sweep uses 64 SEN2NAIP v2 pairs × 3 matched seeds, with v1 weights and histogram matching for both samplers. At three steps, DPM-Solver++ averages 6.39× the speed of DDIM-100 (0.607 versus 3.875 seconds per image) in this 128²→512² RTX 3090 benchmark. Speedup is the mean of matched runtime ratios; timing includes the full forward pass but excludes I/O and metrics.
Higher RGB SSIM means closer agreement with the HR reference, it does not establish better perceptual detail. This is an exploratory evaluation subset, not a guaranteed unseen test set. Measured values.
2.1 🧱 Weights and Checkpoints
V1 (opensr-ldsrs2_v1_0_0.ckpt) remains the canonical checkpoint and the default for model loading. V2 is an optional research preview; it has not established better or equal quality overall.
The model should load automatically with the model.load_pretrained command. Alternatively, the checkpoints can be found on HuggingFace.
2.2 🖥️ HPC and Slurm Launcher
For cluster workflows, this repository now also ships an installable HPC launcher built around cubo, opensr-model, opensr-utils, and Slurm.
Install the optional extras:
pip install -e .[hpc]
This exposes the opensr-hpc CLI:
opensr-hpc validate-config --config deployment/configs/runtime.default.yaml

opensr-hpc submit patch \
  --config deployment/configs/runtime.default.yaml \
  --lat 52.5200 \
  --lon 13.4050 \
  --start-date 2025-07-01 \
  --end-date 2025-07-03 \
  --dry-run

opensr-hpc submit aoi \
  --config deployment/configs/runtime.default.yaml \
  --aoi-path /data/berlin_aoi \
  --start-date 2025-07-01 \
  --end-date 2025-07-03 \
  --dry-run
See deployment/README.md for the full run layout, config schema, AOI settings, and Slurm entrypoint details.
2.3 Development, tests, and coverage
Use Python 3.12 or newer and install the training dependencies to run the full test suite. From the repository root:
python3 -m venv .venv
source .venv/bin/activate
python -m pip install -e '.[train,dev]'
python -m pre_commit install
python -m pre_commit run --all-files
On Windows, activate the environment with .venv\Scripts\Activate.ps1 in
PowerShell. Keep the environment active when committing and pushing: both checks use its
Python and installed dependencies. Hook installation is required once per clone.
Every commit checks Black formatting on staged Python files and runs the full
pytest suite with line and branch coverage, including the distributed tests.
Every push runs the same checks for the files included in the push. Formatting
or test failures block the commit or push. Fix formatting with python -m black .,
stage the changes, and commit again. To update an existing hook installation:
python -m pre_commit install
GitHub Actions runs these checks when a GitHub release is published, and PyPI publishing waits for them to pass. The GitHub release itself is already published when these checks start. Ordinary pushes and pull requests do not run CI checks. You can also run the Code quality and tests workflow manually from the Actions tab. CI saves the coverage reports as a downloadable artifact.
Useful manual commands:
python -m black .                       # Format Python files
python -m black --check .               # Check formatting without editing
python -m pytest                       # Full suite and coverage reports
python -m pytest tests/diffusion --no-cov  # Focused tests without coverage
Coverage includes opensr_model, including modules the tests do not import.
The external HPC tooling in deployment/ is outside the coverage scope.
The terminal shows missing lines; open htmlcov/index.html for
the browsable report or use coverage.xml with coverage tools. Reports are
Git-ignored. Coverage is reported without an initial minimum percentage; set
fail_under in [tool.coverage.report] in pyproject.toml to enforce a target.
Tests use small CPU models and limit PyTorch threads to keep push checks
practical. The CUDA comparison and released-checkpoint test skip when their
resources are unavailable. Git-ignored tests/diagnostics and campaign experiments are
excluded from the shared suite. The test extra includes pytest and coverage
tools; the dev extra also includes the pinned Black formatter and pre-commit.
3. 🖼️ Super-Resolution Examples
3.1 🛰️ Example SR Image

3.2 🔎 Demo File and Uncertainty Calculation
Run the demo.py file to see how the package works. It super-resolves an example tensor and saves the corresponding uncertainty map.


4. 🗺️ Inference on S2 Tiles: Data Pipeline
This repository itself exposes the raw model for tensor‑level inference. By default it performs 128→512 super‑resolution on 4‑channel tensors (B×4×128×128 → B×4×512×512). It does not handle geospatial IO, tiling, or metadata.
Input tensors are automatically moved to the model weights' device before inference; outputs remain on that device.
Each LR spatial dimension must be 100–128 pixels, inclusive. Inputs below 128 in either dimension are reflect-padded to 128×128 with a printed message; padding is removed from the final SR output, giving 4× the original dimensions. A dimension below 100 or above 128 raises ValueError. The error points to opensr-utils for tiling larger scenes into 128×128 LR windows, overlap blending, and stitching (see below).
For real‑world workflows on Sentinel‑2 data, please use opensr-utils:
- Run inference over 4‑band GeoTIFFs (e.g., RGB‑NIR) or full Sentinel‑2
.SAFEfolders (including.SAFE.zip). - Handles tiling, overlap blending, stitching, and preserves CRS/transform.
- Works with every model (including this one), define LR‑space
window_size=128,factor=4, overlap, and border trimming. - Writes georeferenced outputs (e.g., GeoTIFF/COG), plus basic logs/metadata.
Minimal example (pseudocode; see opensr-utils for details):
import opensr_utils
sr_job = opensr_utils.large_file_processing(
    root="/path/to/S2_tile.SAFE",  # also supports GeoTIFFs and .SAFE.zip
    model=model,                   # your SRLatentDiffusion instance
    window_size=(128, 128),        # LR patch size → 512px SR at factor=4
    factor=4,                      # 10m → 2.5m
    overlap=12,                    # LR‑space overlap to reduce seams
    eliminate_border_px=2,         # trim LR‑space border per tile
    device=device,                 # "cuda"/"cpu"
    gpus=0,                        # single GPU id or list for multi‑GPU
)
Use the notebooks and demo.py for quick starts; for full‑tile processing and proper georeferencing, prefer opensr-utils.
5. 📝 Notes
5.1 🎓 Training
The autoencoder and conditional diffusion model can be trained independently with PyTorch Lightning using paired TACO data. Runs save checkpoints for both training resume and inference.
See the training guide and the packaged configurations in
opensr_model/configs/training_configs.
5.2 📚 Citation
If you use this model in your work, please cite
@ARTICLE{ldsrs2,
  author={Donike, Simon and Aybar, Cesar and Gómez-Chova, Luis and Kalaitzis, Freddie},
  journal={IEEE Journal of Selected Topics in Applied Earth Observations and Remote Sensing},
  title={Trustworthy Super-Resolution of Multispectral Sentinel-2 Imagery With Latent Diffusion},
  year={2025},
  volume={18},
  number={},
  pages={6940-6952},
  doi={10.1109/JSTARS.2025.3542220}}
5.3 📈 Status
This repository has left the experimental stage with the publication of v1.0.0.

2 maintainers


Metadata
2 maintainers
Release files for opensr-model 1.2.2
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | Provenance | Actions |
|---|---|---|---|---|
| opensr_model-1.2.2.tar.gz | 8.4 MB | Without provenance | Details for opensr_model-1.2.2.tar.gz |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Actions Reset |
|---|---|---|---|---|
| opensr_model-1.2.2-py3-none-any.whl | Python 3 | none | any | Details for opensr_model-1.2.2-py3-none-any.whl |
Total release size: 8.6 MB
Release files / opensr_model-1.2.2.tar.gz
| Download URL | opensr_model-1.2.2.tar.gz |
|---|---|
| Size | 8.4 MB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
9fca1a7c65135473150b0b7f4cc99148f0e479aa384e8bcab56d53ae8544f5f7
|
|
BLAKE2b-256 checksum How to use checksums |
6484731d6614a2860c9f6386a896bab838de296da3321dad11bc0bdc4c7aa915
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/7.0.0 CPython/3.12.15
|
Release files / opensr_model-1.2.2-py3-none-any.whl
| Download URL | opensr_model-1.2.2-py3-none-any.whl |
|---|---|
| Size | 222.8 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
bed4a88ca56e4eaa13344a95d55f7f3375a322ceb9f6eb6436e97874e72c8b8e
|
|
BLAKE2b-256 checksum How to use checksums |
0f5d8b8c703fe54cb57e1b7488ffbe1c3948e6779dcfee60c57ff594e9d02a30
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/7.0.0 CPython/3.12.15
|
Security for opensr-model 1.2.2
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
No provenance found
None of the files in this release were uploaded with provenance metadata.
A note on package security
PyPI is a repository for distributing packages, not a service for auditing them. While third-party security researchers and our staff do their best to detect and remove malicious packages, PyPI cannot guarantee the quality, security or suitability of any given package.
To learn more about protecting yourself from malicious actors, visit our package security documentation.














