
PixyzRL: A Reinforcement Learning Framework with Probabilistic Generative Models


Documentation | Examples | GitHub
What is PixyzRL?
PixyzRL is a reinforcement learning (RL) framework based on probabilistic generative models and Bayesian theory. Built on top of the Pixyz library, it provides a modular and flexible design to enable uncertainty-aware decision-making and improve sample efficiency. PixyzRL supports:
- Probabilistic Policy Optimization (e.g., PPO, A2C)
- On-policy and Off-policy Learning
- Memory Management for RL (Replay Buffer, Rollout Buffer)
- Integration with Gymnasium environments
- Logging and Model Training Utilities
Installation
Requirements
- Python 3.10+
- PyTorch 2.5.1+
- Gymnasium (for environment interaction)
Install PixyzRL
Using pip
pip install torch torchvision torchaudio pixyz gymnasium[box2d] torchrl
Install from Source
git clone https://github.com/ItoMasaki/PixyzRL.git
cd PixyzRL
pip install -e .
Quick Start
1. Set Up Environment
from pixyzrl.environments import Env

env = Env("CartPole-v1")
state_dim = env.observation_space.shape[0]
action_dim = env.action_space.n
2. Define Actor and Critic Networks
import torch
from pixyz.distributions import Categorical, Deterministic
from torch import nn

class Actor(Categorical):
    def __init__(self):
        super().__init__(var=["a"], cond_var=["o"], name="p")
        self.net = nn.Sequential(
            nn.Linear(state_dim, 64),
            nn.ReLU(),
            nn.Linear(64, 64),
            nn.ReLU(),
            nn.Linear(64, action_dim),
            nn.Softmax(dim=-1)
        )

    def forward(self, o: torch.Tensor):
        return {"probs": self.net(o)}

class Critic(Deterministic):
    def __init__(self):
        super().__init__(var=["v"], cond_var=["o"], name="f")
        self.net = nn.Sequential(
            nn.Linear(state_dim, 64),
            nn.ReLU(),
            nn.Linear(64, 64),
            nn.ReLU(),
            nn.Linear(64, 1)
        )

    def forward(self, o: torch.Tensor):
        return {"v": self.net(o)}

actor = Actor()
critic = Critic()
2.1 Display distributions as latex
>>> pixyzrl.utils.print_latex(actor)
p(a|o)

>>> pixyzrl.utils.print_latex(critic)
f(v|o)
3. Prepare PPO and Buffer
from pixyzrl.models import PPO
from pixyzrl.memory import RolloutBuffer
from pixyzrl.trainer import OnPolicyTrainer

agent = PPO(actor, critic, entropy_coef=0.0, mse_coef=1.0)

buffer = RolloutBuffer(
    2048,
    {
        "obs": {"shape": (4,), "map": "o"},
        "value": {"shape": (1,), "map": "v"},
        "action": {"shape": (2,), "map": "a"},
        "reward": {"shape": (1,)},
        "done": {"shape": (1,)},
        "returns": {"shape": (1,), "map": "r"},
        "advantages": {"shape": (1,), "map": "A"},
    },
    "cpu",
    1,
)
3.1 Display model as latex
>>> print_latex(agent)
mean \left(1.0 MSE(f(v|o), r) - min \left(A clip(\frac{p(a|o)}{old(a|o)}, 0.8, 1.2), A \frac{p(a|o)}{old(a|o)}\right) \right)
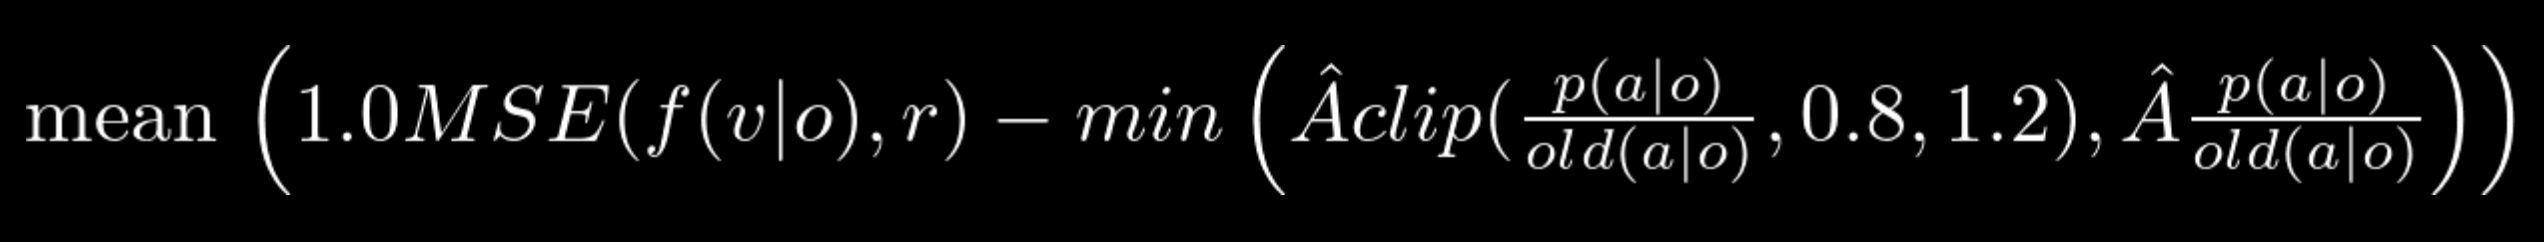
4. Training with Trainer
trainer = OnPolicyTrainer(env, buffer, agent, "cpu")
trainer.train(1000)
Directory Structure
PixyzRL
├── docs
│   └── pixyz
│       └── README.pixyz.md
├── examples  # Example scripts
├── pixyzrl
│   ├── environments  # Environment wrappers
│   ├── models
│   │   ├── on_policy  # On-policy models (e.g., PPO, A2C)
│   │   └── off_policy  # Off-policy models (e.g., DQN)
│   ├── memory  # Experience replay & rollout buffer
│   ├── trainer  # Training utilities
│   ├── losses  # Loss function definitions
│   ├── logger  # Logging utilities
│   └── utils.py
└── pyproject.toml
Future Work
- Implement Deep Q-Network (DQN)
- Implement Dreamer (model-based RL)
- Integrate with ChatGPT for automatic architecture generation
- Integrate with Genesis
License
PixyzRL is released under the MIT License.
Community & Support
For questions and discussions, please visit:
1 maintainer

Metadata
1 maintainer
Release files for pixyzrl 0.3.0
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | |
|---|---|---|---|
| pixyzrl-0.3.0.tar.gz | 25.0 kB | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| pixyzrl-0.3.0-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 53.3 kB
Release files / pixyzrl-0.3.0.tar.gz
| Download URL | pixyzrl-0.3.0.tar.gz |
|---|---|
| Size | 25.0 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
ba76d583000ff9ea46104eb1ce9128cee68a318aa7a06342a851b6650665edf3
|
|
BLAKE2b-256 checksum How to use checksums |
61bbcf37dd27b428d9b0cd02cdcc62dcc2f076a42c7da4b4255862304459848c
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/6.1.0 CPython/3.12.2
|
Release files / pixyzrl-0.3.0-py3-none-any.whl
| Download URL | pixyzrl-0.3.0-py3-none-any.whl |
|---|---|
| Size | 28.3 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
872354b4b82e726a34b60af3f977600290df329f22082acf020933d197eb8011
|
|
BLAKE2b-256 checksum How to use checksums |
023247d3b6e275e3652077ab34132c0123dab996c2f70e82e43d4a1ba621417d
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/6.1.0 CPython/3.12.2
|














