
pyvista-manifold
A PyVista accessor for Manifold, a fast and reliable boolean / CSG library for triangle meshes.
Every frame is a real
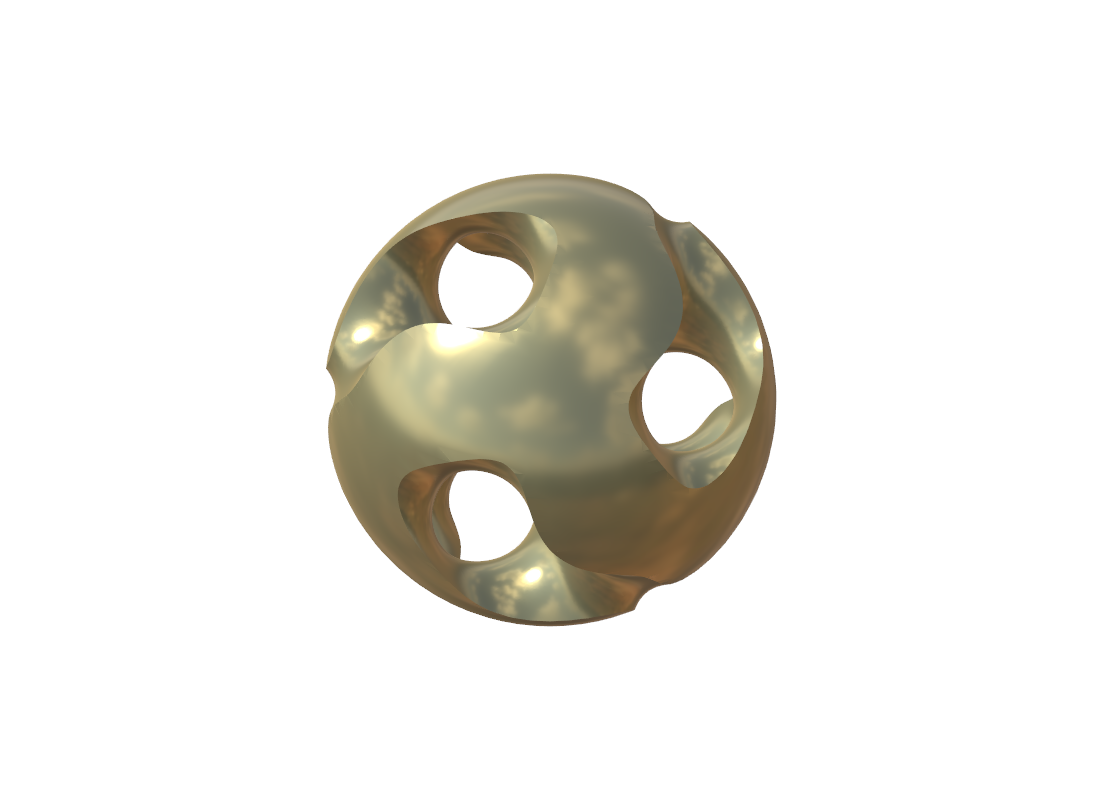
tpms.manifold.intersection(sphere)against a gyroid iso-surface — the wireframe is the live cutter, the gold is the result. Three function calls build the whole thing:level_setfor the gyroid field,pv.Spherefor the cutter,mesh.manifold.intersectionto combine them.
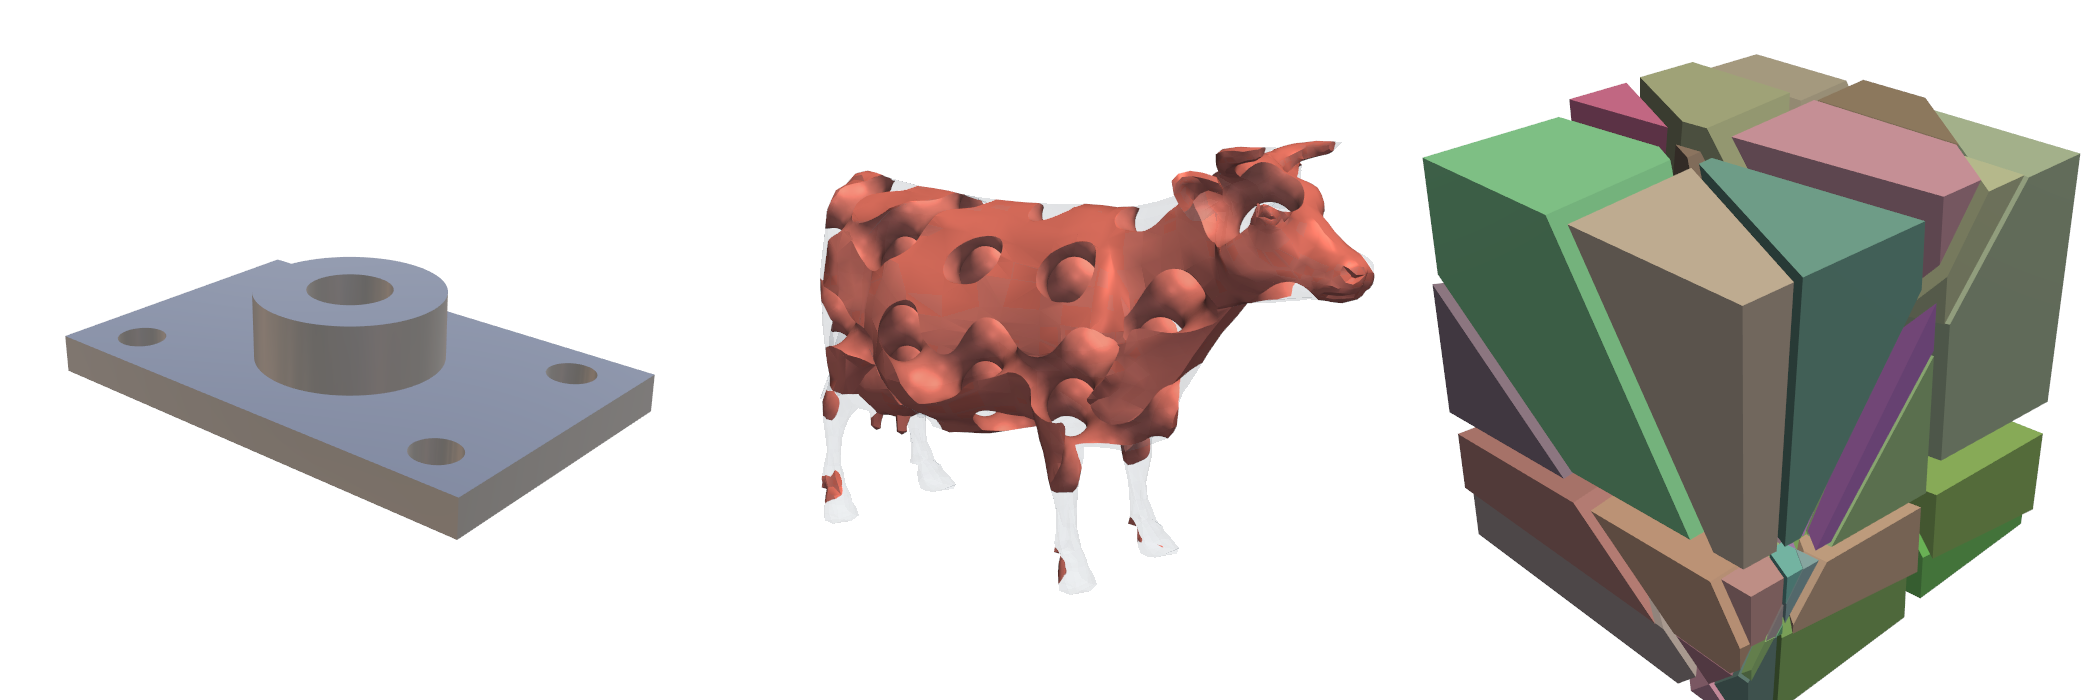
From left: a machined aluminum bracket built by chaining
unionanddifference; a real mesh intersected with a gyroid TPMS lattice; a cube fractured by repeated plane cuts. The gold sphere lives in the animation above.
Once the package is installed, every pv.PolyData exposes a .manifold accessor. There is nothing to import.
import pyvista as pv

cube = pv.Cube()
sphere = pv.Sphere(radius=0.7, center=(0.4, 0.4, 0.4))
cube.manifold.difference(sphere).plot()
Why
PyVista's built-in boolean filters wrap VTK's vtkBooleanOperationPolyDataFilter, which produces non-manifold or self-intersecting output on non-trivial inputs. Manifold solves the same problem with exact arithmetic and topology tracking. This package is the smallest reasonable bridge between the two: a single .manifold accessor that converts on demand, caches the default Manifold conversion on the dataset accessor, and always returns a fresh pv.PolyData.
Install
pip install pyvista-manifold
Requires Python 3.10+ and PyVista 0.48+. The accessor registers itself via PyVista's plugin entry-point system; you don't import the package to use it.
Quick start
import pyvista as pv

# Boolean ops chain through PyVista's filter pipeline
cube = pv.Cube(x_length=2.0, y_length=2.0, z_length=2.0)
sphere = pv.Sphere(radius=0.9)
diff = cube.manifold.difference(sphere)
print(diff.manifold.volume, diff.manifold.is_valid)

# Drill three orthogonal cylinders out of a cube in one call
holes = [pv.Cylinder(radius=0.4, height=3, direction=d) for d in [(1, 0, 0), (0, 1, 0), (0, 0, 1)]]
from pyvista_manifold import OpType

drilled = cube.manifold.batch_boolean(holes, op=OpType.Subtract)

# Intersect with an iso-surface from a callable scalar field
import math
from pyvista_manifold import level_set


def gyroid(x, y, z):
    return -(
        math.sin(2 * x) * math.cos(2 * y)
        + math.sin(2 * y) * math.cos(2 * z)
        + math.sin(2 * z) * math.cos(2 * x)
    )


iso = level_set(gyroid, bounds=(-2, -2, -2, 2, 2, 2), edge_length=0.1)
infilled = pv.Sphere(radius=1.5).manifold.intersection(iso)

# Anything you build chains naturally with PyVista filters
finished = drilled.clean().smooth(n_iter=20).compute_normals()
A worked walkthrough lives in examples/showcase.ipynb: mechanical CSG, TPMS infill of a real mesh, topographic slicing, Voronoi-style fracture, Minkowski filleting.
Gallery
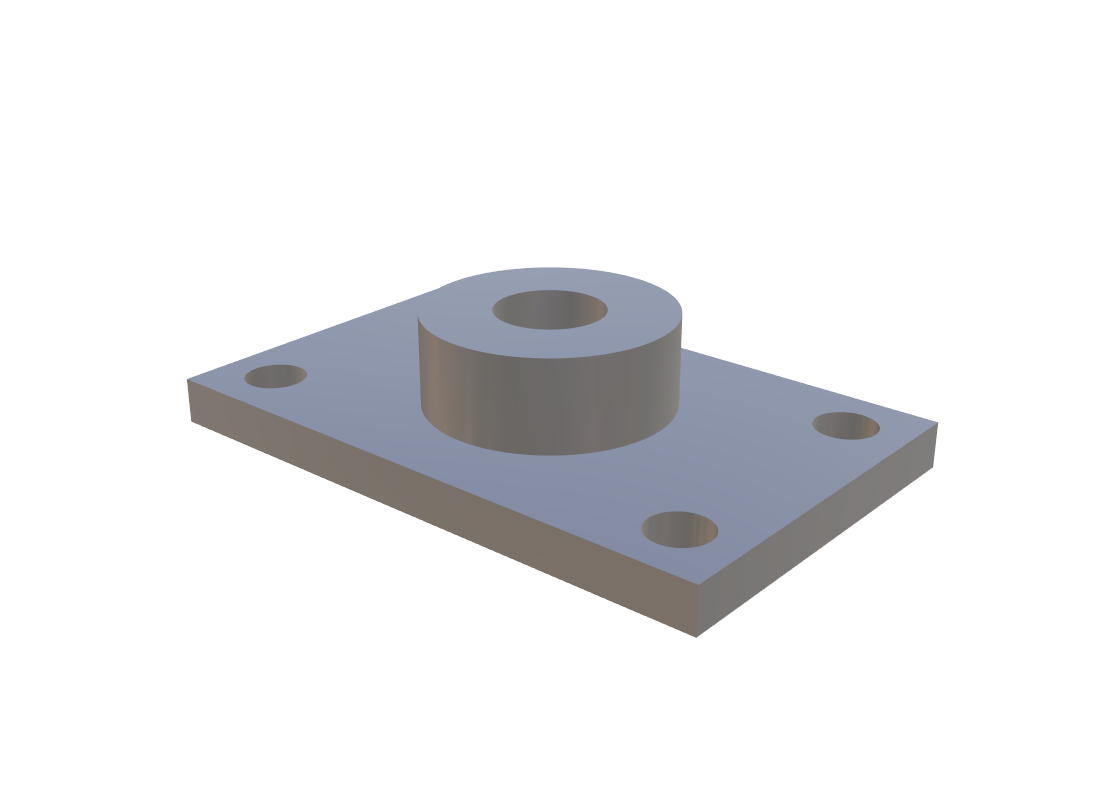
Mechanical CSG. Stack union and difference to build a real-looking part. |
 |
| TPMS lattice infill. Intersect a closed mesh with a gyroid field, the standard 3D-printer infill, computed in two lines. | 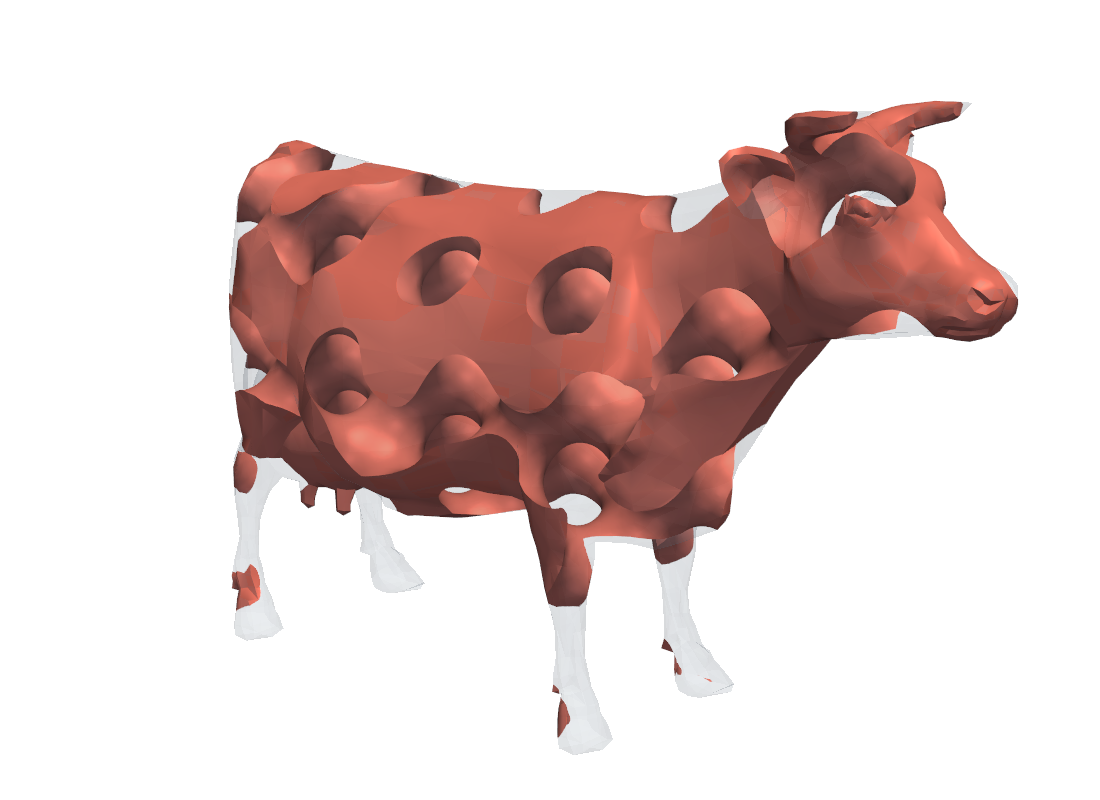 |
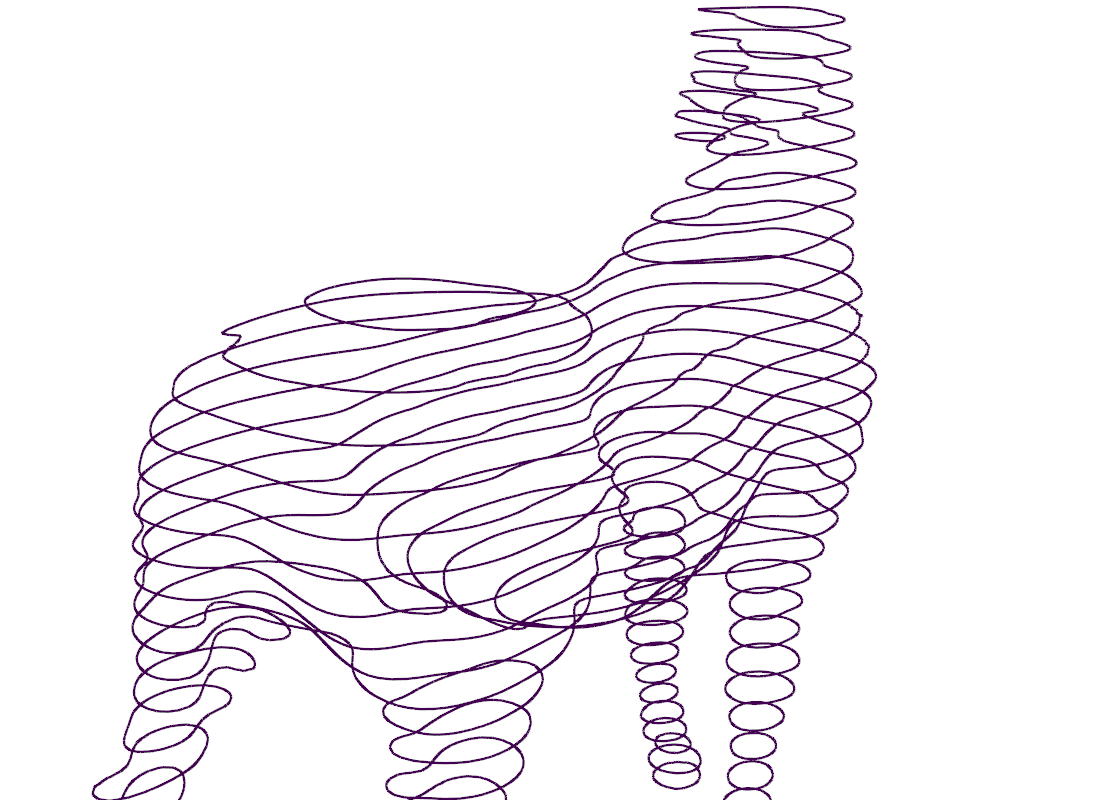
Topographic slicing. slice_z at many heights stacks into a contour map of the silhouette. |
 |
Iso-surface from a callable. level_set extracts a TPMS surface from a Python function, no marching-cubes plumbing. |
 |
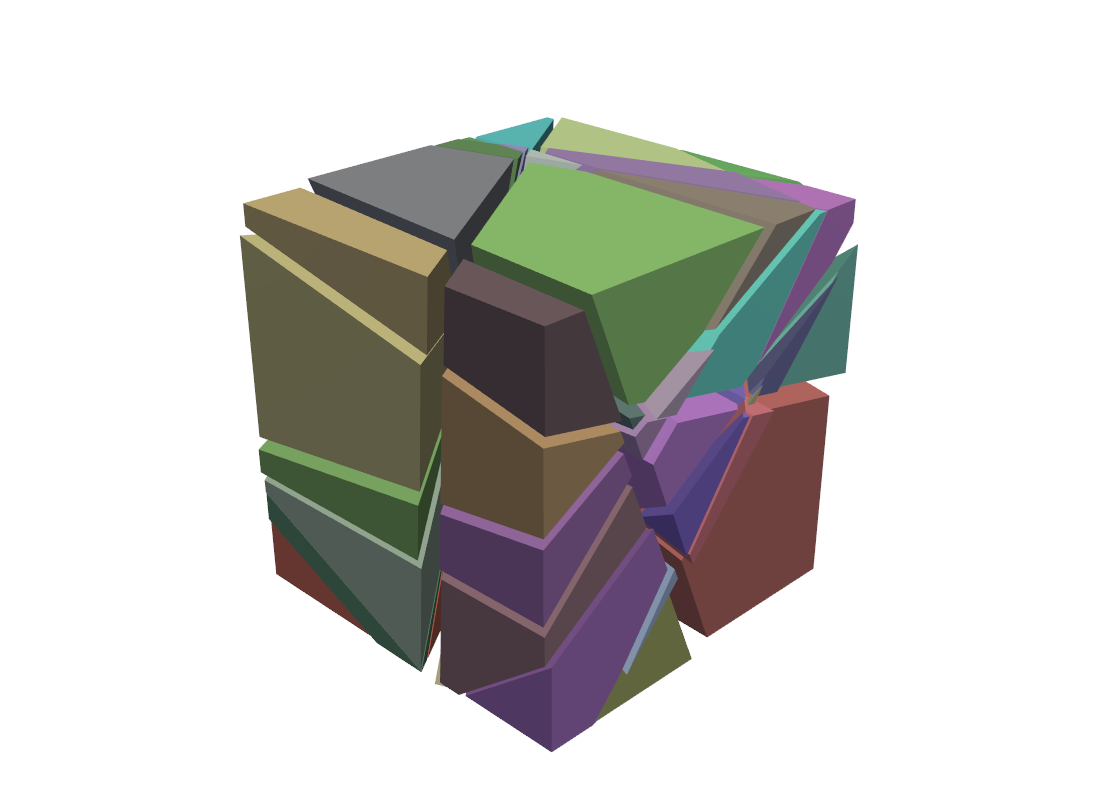
Voronoi-style fracture. Repeated split_by_plane calls turn a cube into a stack of polyhedral cells. |
 |
The accessor
mesh.manifold is a per-instance accessor that converts the PolyData into a manifold3d.Manifold on demand, caches the default clean=True conversion until the dataset is modified, runs the operation, and converts the result back. The input is left untouched.
mesh.manifold                      # accessor instance, cached on the dataset
mesh.manifold.to_manifold()        # raw manifold3d.Manifold (drop down when needed)
mesh.manifold.<operation>(...)     # any method below; always returns pv.PolyData
The conversion runs pyvista.PolyData.clean() and triangulates the input by default, so PyVista primitives like pv.Cube and pv.Cylinder (which ship with seam-duplicated vertices) work directly. Pass clean=False to mesh.manifold.to_manifold() if you need to preserve every input vertex.
If your mesh isn't a closed, outward-facing manifold solid, the conversion still returns a Manifold, but every accessor method that returns geometry raises a ValueError naming the cause, as does min_gap, which also requires valid solids. The other queries never raise: check mesh.manifold.is_valid (returns True when Manifold's status is NoError and the volume is not negative).
Boolean operations
| Method | Result |
|---|---|
union(other) |
self joined with other |
difference(other) |
self with other subtracted |
intersection(other) |
overlap of self and other |
batch_boolean(others, op=OpType.Add) |
n-ary union, difference, or intersection |
other is either a pv.PolyData or a manifold3d.Manifold. Mixing is fine.
Transforms
| Method | Notes |
|---|---|
translate(t) |
3-vector |
rotate(r) |
XYZ Euler angles in degrees |
scale(s) |
scalar or 3-vector |
mirror(normal) |
reflect about a plane through the origin |
transform(matrix) |
3x4 column-major affine |
warp(f, batch=False) |
per-vertex callback (or vectorized with batch=True) |
Hulls
| Method | Notes |
|---|---|
hull() |
convex hull of this mesh's vertices |
hull_with(*others) |
convex hull of this plus other meshes |
Refinement and smoothing
| Method | Notes |
|---|---|
refine(n) |
subdivide every edge into n segments |
refine_to_length(length) |
adaptive subdivision until every edge is shorter than length |
refine_to_tolerance(tol) |
refine until geometric error is below tol |
smooth_out(min_sharp_angle=60, min_smoothness=0) |
smooth without explicit normals |
smooth_by_normals(normal_idx) |
smooth using stored vertex normals |
calculate_normals(normal_idx=0) |
compute and store per-vertex normals as point_data['Normals'] |
calculate_curvature(gaussian_idx=0, mean_idx=1) |
store Gaussian + Mean curvature as point arrays |
Splits and decomposition
| Method | Returns |
|---|---|
split(cutter) |
(inside, outside) PolyData pair |
split_by_plane(normal, offset=0) |
(positive, negative) PolyData pair |
trim_by_plane(normal, offset=0) |
the half-space on the side normal points toward |
decompose() |
list of disconnected components |
Minkowski
| Method | Notes |
|---|---|
minkowski_sum(other) |
self offset outward by other (rounded edges) |
minkowski_difference(other) |
self eroded inward by other |
3D to 2D
| Method | Returns |
|---|---|
slice_z(z=0) |
closed polylines at height z (PolyData with lines) |
project() |
silhouette projected onto the XY plane (PolyData with lines) |
Properties and queries
| Property / method | Returns |
|---|---|
volume |
signed volume |
surface_area |
total surface area |
genus |
topological genus (number of handles) |
bounds |
(xmin, xmax, ymin, ymax, zmin, zmax), matching PyVista order |
num_vert, num_edge, num_tri |
geometry counts after Manifold reconstruction |
is_empty, is_valid, status |
empty check, manifold validity, raw Error enum |
tolerance |
numerical tolerance Manifold is using |
original_id |
Manifold's tracking ID, or -1 |
min_gap(other, search_length) |
closest distance to another solid, capped at search_length |
Tolerance, simplification, properties
| Method | Notes |
|---|---|
simplify(tolerance) |
coarsen while keeping geometry within tolerance |
set_tolerance(tol) |
new mesh with updated tolerance |
set_properties(num_prop, f) |
rewrite per-vertex property channels via callback |
as_original() |
mark the result as a fresh original (assigns a new tracking ID) |
compose_with(*others) |
disjointly combine with other meshes (no boolean) |
Module-level helpers
For things that don't start from an existing mesh:
from pyvista_manifold import level_set, extrude, revolve, hull_points

# Iso-surface from a scalar field
iso = level_set(f, bounds=(xmin, ymin, zmin, xmax, ymax, zmax), edge_length=0.1)

# Extrude / revolve a 2D polygon
solid = extrude(polygons, height, n_divisions=0, twist_degrees=0, scale_top=(1, 1))
solid = revolve(polygons, segments=0, revolve_degrees=360.0)

# Convex hull of a raw point cloud
hull = hull_points(points)  # (N, 3) array
polygons is a single (N, 2) array or a list of such arrays representing a polygon-with-holes set.
For everything that has an obvious PyVista equivalent (pv.Cube, pv.Sphere, pv.Cylinder, etc.), use PyVista directly and chain through .manifold.
Conversion utilities
The accessor handles conversion automatically. Reach for these only when the accessor isn't enough:
import pyvista as pv
from pyvista_manifold import to_manifold, from_manifold

m = to_manifold(polydata, point_data_keys=['scalar'])  # PolyData -> Manifold
poly = from_manifold(m, property_names=['scalar'])  # Manifold -> PolyData
Per-vertex point arrays can be passed through Manifold as extra property channels via point_data_keys. Manifold linearly interpolates them across boolean cuts, and from_manifold unpacks them back into point_data.
Caveats
- Inputs must be manifold solids (closed, non-self-intersecting). Run
pv.PolyData.clean()and checkmesh.manifold.is_validif you're unsure. PyVista's downloaded example meshes vary:download_cow,download_horse,download_armadilloare manifold;download_bunny(the Stanford scan) is not. - All faces are triangulated and merged during conversion. The roundtrip preserves vertex coordinates for triangulated, deduplicated input but does not preserve cell-data arrays, except that
union,differenceandintersectioncarry each cell array both inputs hold onto the faces cut from it. - Output points and point-data property arrays are
float64: conversion goes through Manifold'sMesh64in both directions, so meshes far from the origin keep their precision. - Manifold has no built-in I/O. Use PyVista's readers and writers on the resulting PolyData.
Development
git clone https://github.com/pyvista/pyvista-manifold
cd pyvista-manifold
just sync          # uv sync --extra dev
just test          # pytest with coverage
just lint          # pre-commit run --all-files
just typecheck     # mypy
Image-regression tests run via pytest-pyvista. To re-seed the cache after intentional visual changes:
uv run pytest tests/test_image_regression.py --reset_image_cache
The hero images at the top of this README are produced by assets/render_hero.py.
Acknowledgements
- Manifold by Emmett Lalish and contributors.
- PyVista for the accessor system and the rest of the visualization stack.
License
MIT.
Metadata
Release files for pyvista-manifold 0.2.0
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | |
|---|---|---|---|
| pyvista_manifold-0.2.0.tar.gz | 3.1 MB | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| pyvista_manifold-0.2.0-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 3.1 MB
Release files / pyvista_manifold-0.2.0.tar.gz
| Download URL | pyvista_manifold-0.2.0.tar.gz |
|---|---|
| Size | 3.1 MB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
4d8484367ff705080a21b7e3df0d443272fa9bc8af6c87c658273613dd5b9b6a
|
|
BLAKE2b-256 checksum How to use checksums |
6fc968cf838c655e571d526952d8f47eada672108873c27000396e905b5f28bf
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.


PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Oct 18, 2026.
Transparency logRelease files / pyvista_manifold-0.2.0-py3-none-any.whl
| Download URL | pyvista_manifold-0.2.0-py3-none-any.whl |
|---|---|
| Size | 20.9 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
f3a6cc2895c028edc239bf47e062881958f52460b451d7f9f4916f360f36f0b6
|
|
BLAKE2b-256 checksum How to use checksums |
975da223a5975858403a048a8bb3ad8a142583a6cf3de3dc74885d6852411423
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Oct 18, 2026.
Transparency log













