
QuadrilateralFitter
This project is a fork of the original QuadrilateralFitter project. Modifications by Krzysztof Mizgała (2025). Licensed under the MIT License. The original Python code has been rewritten in C to boost performance.
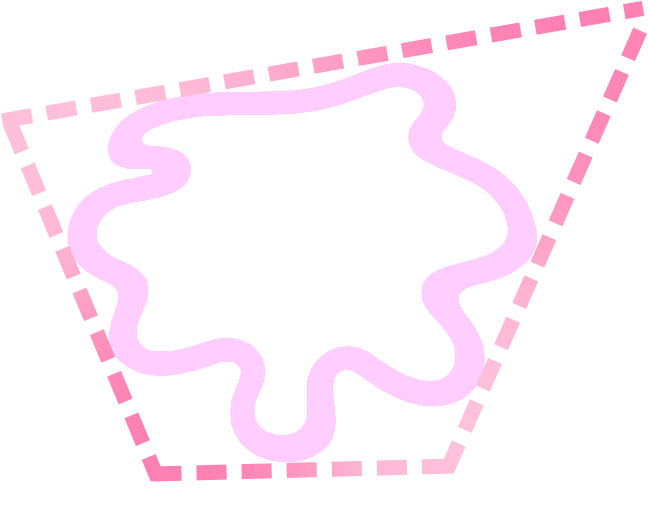
QuadrilateralFitter helps you find that four corners polygon that best approximates your noisy data or detection, so you can apply further processing steps like: perspective correction or pattern matching, without worrying about noise or non-expected vertex.
Optimal Fitted Quadrilateral is the smallest area quadrilateral that contains all the points inside a given polygon.
Installation
You can install QuadrilateralFitter with pip:
pip install quadfit
Usage
The simplest way to use QuadrilateralFitter is just one line:
from quadfit import QuadrilateralFitter

# Fit an input polygon of N sides and get the final quadrilateral directly
quad = QuadrilateralFitter(polygon=your_noisy_polygon).fit()
Optionally, you can trade a bit of accuracy for speed and determinism using the additional arguments of fit:
# Limit the number of initial combinations and fix RNG seed; choose stage with 'until'
quad = QuadrilateralFitter(your_noisy_polygon).fit(
  simplify_polygons_larger_than=30,
  start_simplification_epsilon=0.1,
  max_simplification_epsilon=0.5,
  simplification_epsilon_increment=0.02,
  max_initial_combinations=1000,
  random_seed=123,
  until="final",  # or "initial" / "refined"
)
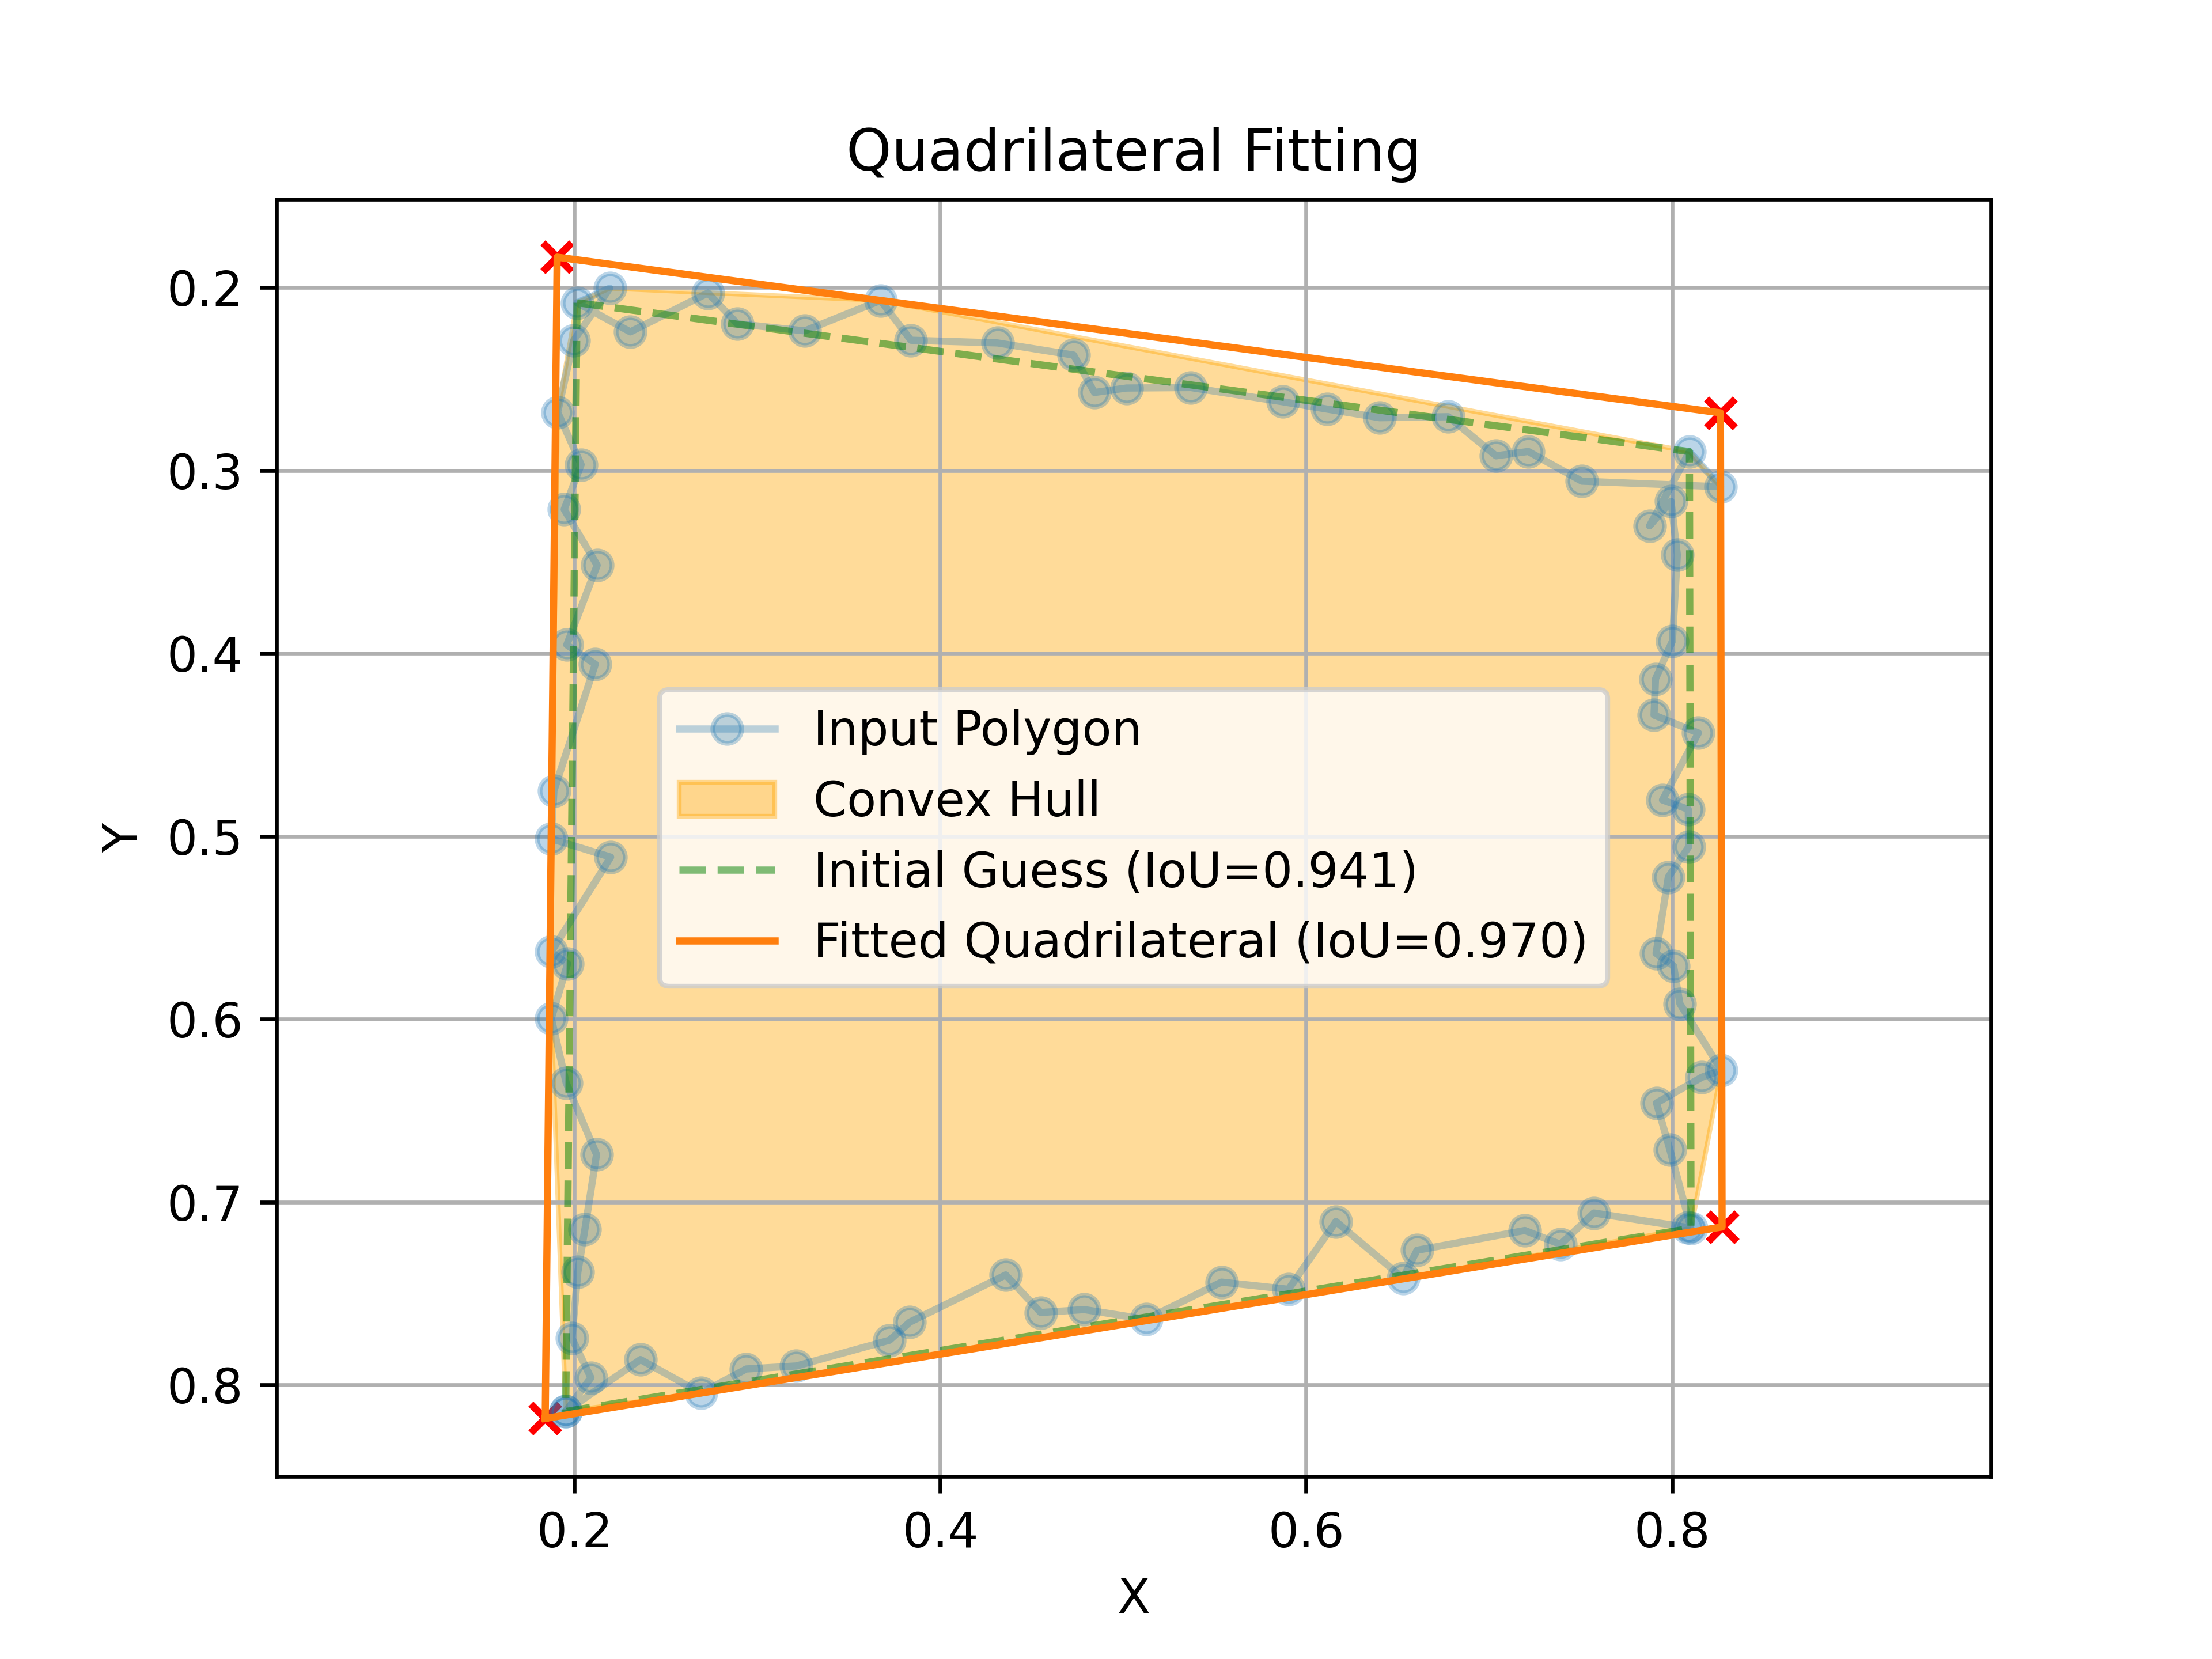
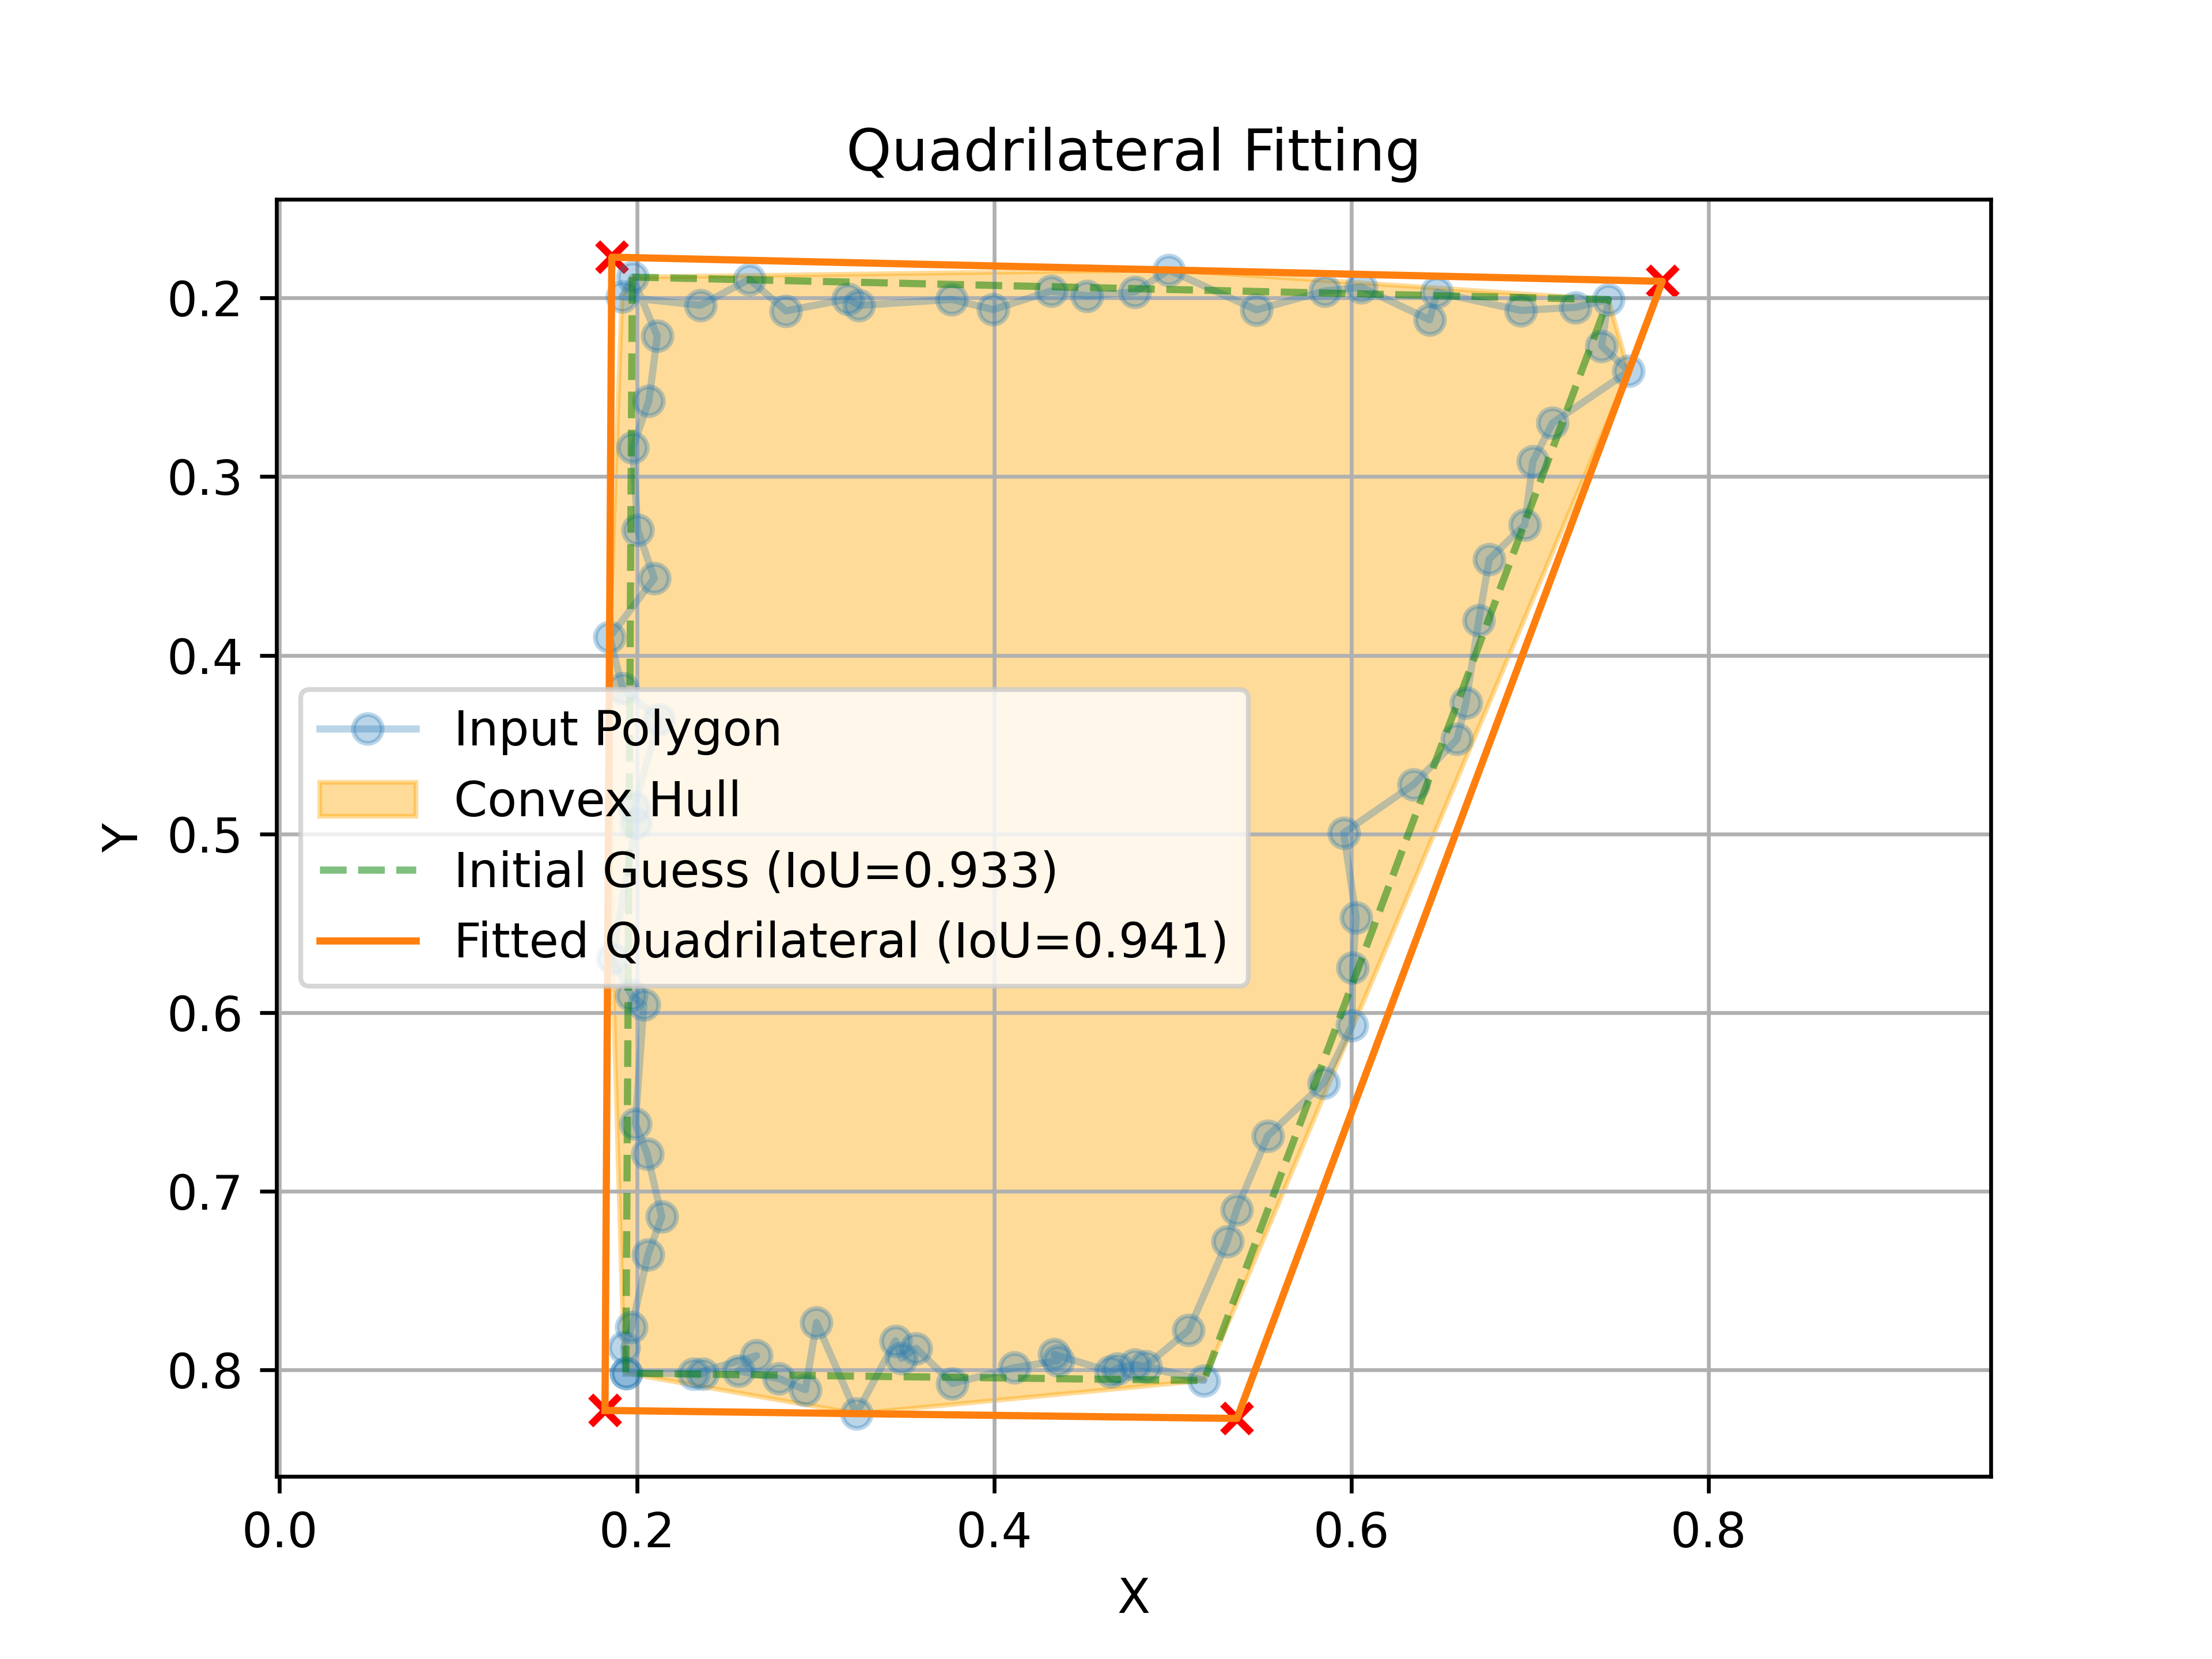
If your application can accept a quadrilateral that does not strictly include all input points, use the tighter initial guess with early stop:
initial = QuadrilateralFitter(polygon=your_noisy_polygon).fit(until="initial")
API Reference
QuadrilateralFitter(polygon)
Initialize the QuadrilateralFitter instance.
polygon: np.ndarray | tuple | list | object. Coordinates of the input geometry. Preferred:np.ndarrayof shape (N, 2) or list/tuple of(x, y). Also accepts objects exposing.exterior.coordsor.coords(e.g., Shapely geometries) via duck‑typing. Shapely is NOT required at runtime.
QuadrilateralFitter.fit → tuple of 4 (x, y)
Signature:
QuadrilateralFitter.fit(
    simplify_polygons_larger_than: int | None = 10,
    start_simplification_epsilon: float = 0.1,
    max_simplification_epsilon: float = 0.5,
    simplification_epsilon_increment: float = 0.02,
    max_initial_combinations: int = 300,
    random_seed: int | None = None,
    until: Literal["initial", "refined", "final"] = "final",
    auto_scale_simplification: bool = True,
    max_points_for_refinement: int | None = None,
) -> tuple[tuple[float, float], tuple[float, float], tuple[float, float], tuple[float, float]]
simplify_polygons_larger_than: If specified, performs a preliminary Douglas–Peucker simplification of the convex hull when it has more than this many vertices. This speeds up the process but may lead to a slightly sub‑optimal quadrilateral. Default: 10.start_simplification_epsilon,max_simplification_epsilon,simplification_epsilon_increment: Epsilon schedule for the Douglas–Peucker simplification.max_initial_combinations: Limits the number of candidate quadrilaterals tested when searching the initial guess. If 0 or larger than the total number of combinations C(N,4), a full search is performed. Otherwise, up to this many unique combinations are sampled randomly. Default: 300.random_seed: RNG seed for deterministic sampling whenmax_initial_combinationsis used. Default: None.until: Choose how far the pipeline should run for performance."initial"returns only the initial guess, skipping finetune/expansion."refined"runs TLS finetuning but skips final expansion."final"runs the full pipeline. Default:"final".auto_scale_simplification: IfTrue, scales Douglas–Peucker epsilon parameters by the input size (bounding box diagonal) when epsilons look relative (<= 1). Helps keep simplification consistent across scales. Default:True.max_points_for_refinement: Optional cap for the number of points used in the TLS finetuning stage. If the input has more points, a deterministic subsample is used (or RNG withrandom_seed). This can dramatically reduce runtime on very large point clouds with minimal accuracy loss. Default:None(use all points).
Returns: A 4-vertex quadrilateral (counter-clockwise) for the requested stage:
until="initial": best IoU vs convex hull (may not contain all points)until="refined": after TLS finetuninguntil="final": expanded to strictly contain the convex hull (default)
Real Case Example
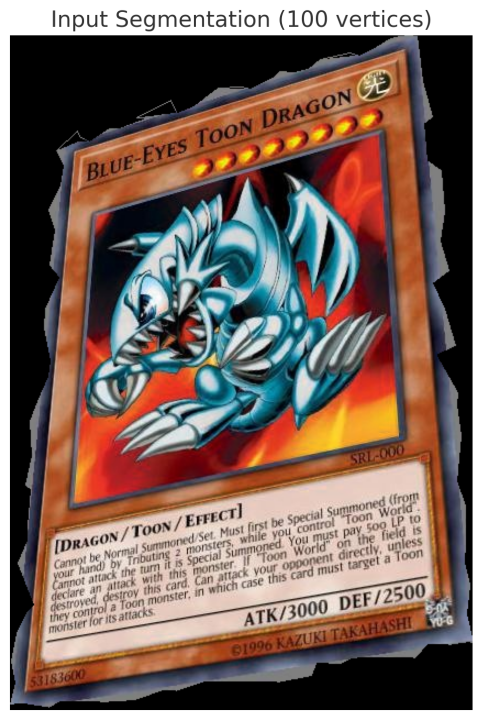
Let's simulate a real case scenario where we detect a noisy polygon from a form that we know should be a perfect rectangle (only deformed by perspective).
import numpy as np
import cv2

image = cv2.cvtColor(cv2.imread('./resources/input_sample.jpg'), cv2.COLOR_BGR2RGB)

# Save the Ground Truth corners
true_corners = np.array([[50., 100.], [370., 0.], [421., 550.], [0., 614.], [50., 100.]], dtype=np.float32)

# Generate a simulated noisy detection
sides = [np.linspace([x1, y1], [x2, y2], 20) + np.random.normal(scale=10, size=(20, 2))
         for (x1, y1), (x2, y2) in zip(true_corners[:-1], true_corners[1:])]
noisy_corners = np.concatenate(sides, axis=0)

# To simplify, we will clip the corners to be within the image
noisy_corners[:, 0] = np.clip(noisy_corners[:, 0], a_min=0., a_max=image.shape[1])
noisy_corners[:, 1] = np.clip(noisy_corners[:, 1], a_min=0., a_max=image.shape[0])
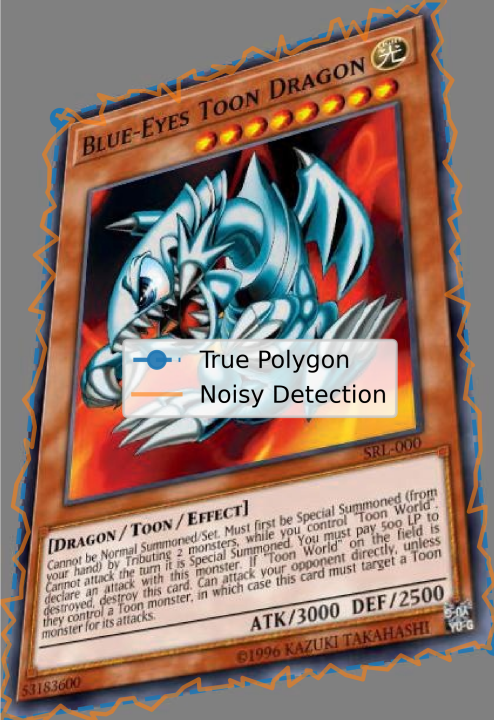
And now, let's run QuadrilateralFitter to find the quadrilateral that best approximates our noisy detection (without leaving points outside).
from quadfit import QuadrilateralFitter

# Define the fitter and compute desired stages
fitter = QuadrilateralFitter(polygon=noisy_corners)
fitted_quadrilateral = np.array(fitter.fit(until="final"), dtype=np.float32)
# Tighter quadrilateral (may exclude some points):
tight_quadrilateral = np.array(fitter.fit(until="initial"), dtype=np.float32)
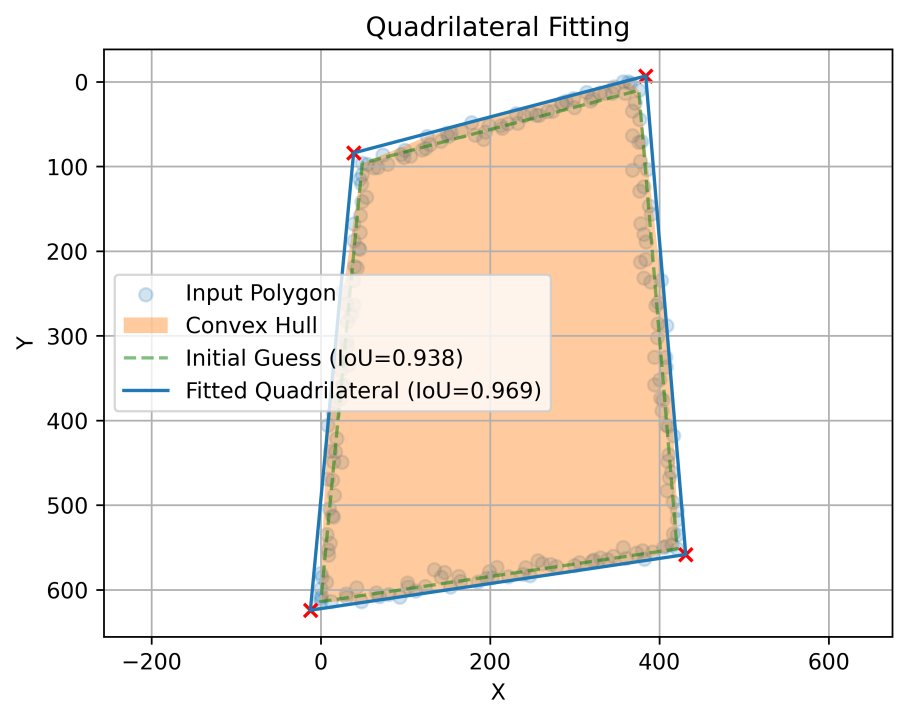
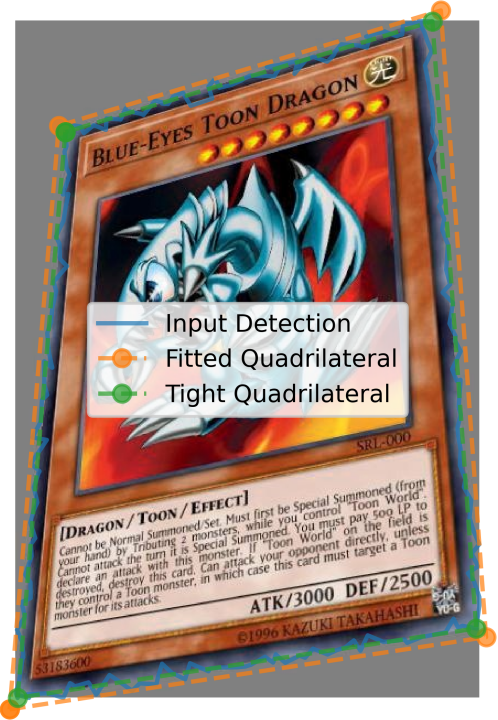
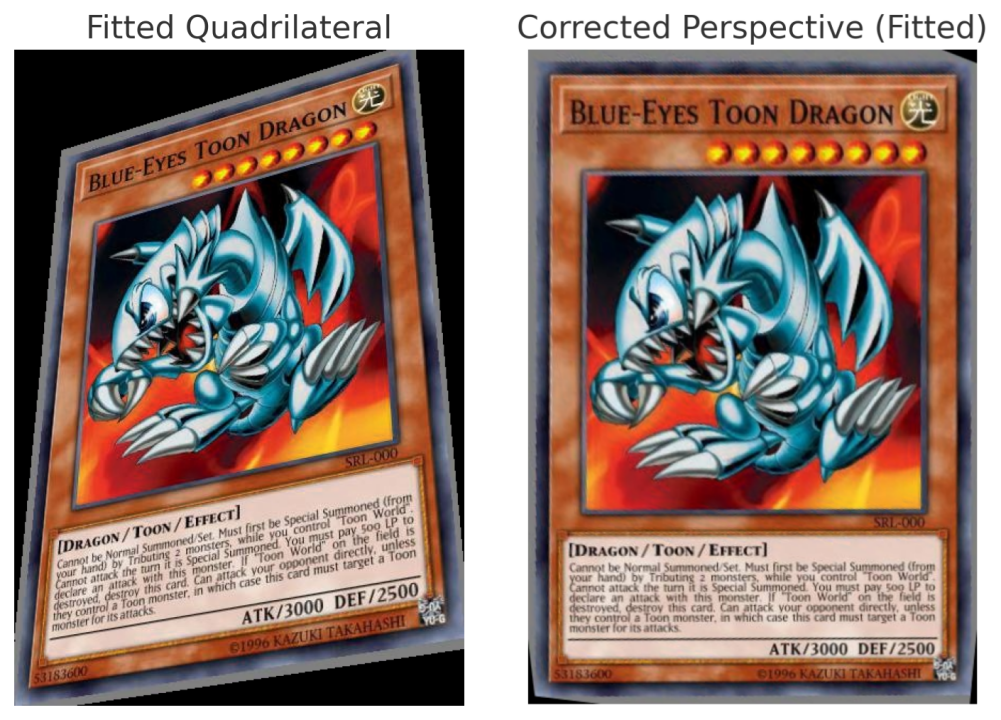
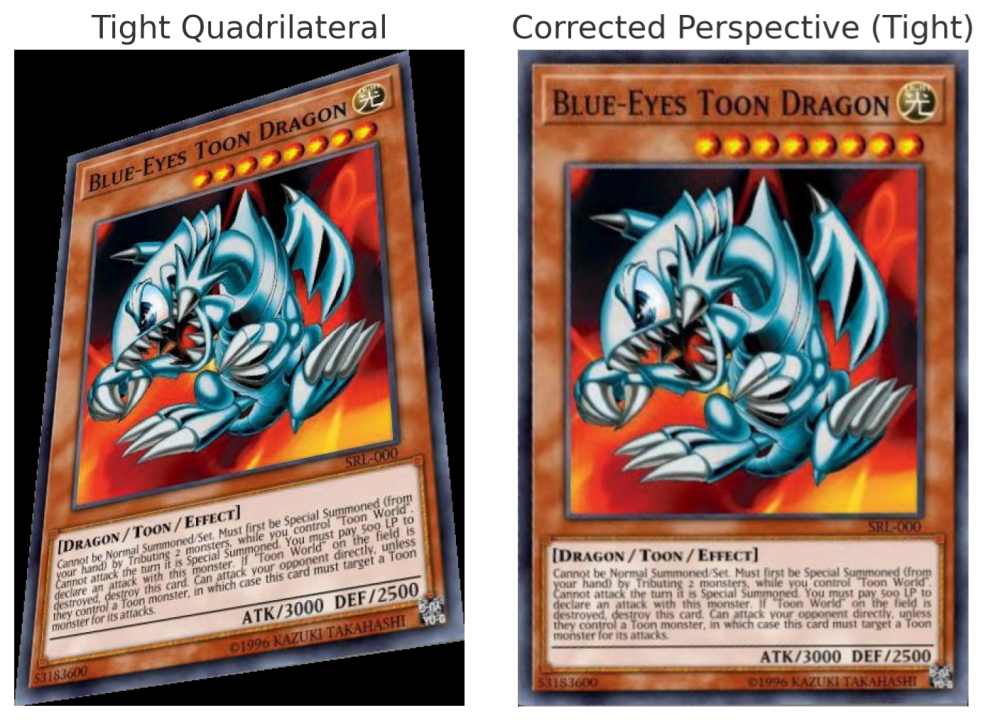
Finally, for use cases like this, we could use fitted quadrilaterals to apply a perspective correction to the image, so we can get a visual insight of the results.
# Generate the destination points for the perspective correction by adjusting it to a perfect rectangle
h, w = image.shape[:2]

for quadrilateral in (fitted_quadrilateral, tight_quadrilateral):
    # Cast it to a numpy for agile manipulation
    quadrilateral = np.array(quadrilateral, dtype=np.float32)

    # Get the bounding box of the fitted quadrilateral
    min_x, min_y = np.min(quadrilateral, axis=0)
    max_x, max_y = np.max(quadrilateral, axis=0)

  # Define the destination points for the perspective correction
  destination_points = np.array(((min_x, min_y), (max_x, min_y),
                   (max_x, max_y), (min_x, max_y)), dtype=np.float32)

    # Calculate the homography matrix from the quadrilateral to the rectangle
  homography_matrix, _ = cv2.findHomography(srcPoints=quadrilateral, dstPoints=destination_points)
    # Warp the image using the homography matrix
    warped_image = cv2.warpPerspective(src=image, M=homography_matrix, dsize=(w, h))
1 maintainer

Metadata
1 maintainer
Release files for quadfit 1.1.0
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | Provenance | Actions |
|---|---|---|---|---|
| quadfit-1.1.0.tar.gz | 23.6 kB | Without provenance | Details for quadfit-1.1.0.tar.gz |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Actions Reset |
|---|---|---|---|---|
| quadfit-1.1.0-cp311-cp311-win_amd64.whl | CPython 3.11 | CPython 3.11 | Windows x86-64 | Details for quadfit-1.1.0-cp311-cp311-win_amd64.whl |
Total release size: 67.3 kB
Release files / quadfit-1.1.0.tar.gz
| Download URL | quadfit-1.1.0.tar.gz |
|---|---|
| Size | 23.6 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
ec8ab6c6228f676a557264997afa3932cda0ba7de746d8720a81ed0c14751a2b
|
|
BLAKE2b-256 checksum How to use checksums |
873ab749dc5bb6ffda33780f9778d898e0c460272137fd59a64efb9632ff8e80
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/6.2.0 CPython/3.11.5
|
Release files / quadfit-1.1.0-cp311-cp311-win_amd64.whl
| Download URL | quadfit-1.1.0-cp311-cp311-win_amd64.whl |
|---|---|
| Size | 43.7 kB |
| Tags | CPython 3.11 Windows x86-64 |
|
SHA-256 checksum How to use checksums |
aa317f27009cc1b9ee3796f7591616d3f17136380708b629d1969615d52df8c2
|
|
BLAKE2b-256 checksum How to use checksums |
3ea8c7dd9feb8ccbcfe893bd5dada3b75f8e8a1bbcfb819f7eabbae682fa640d
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/6.2.0 CPython/3.11.5
|
Security for quadfit 1.1.0
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
No provenance found
None of the files in this release were uploaded with provenance metadata.
A note on package security
PyPI is a repository for distributing packages, not a service for auditing them. While third-party security researchers and our staff do their best to detect and remove malicious packages, PyPI cannot guarantee the quality, security or suitability of any given package.
To learn more about protecting yourself from malicious actors, visit our package security documentation.














